Arctan At The Edge Of The Number Line
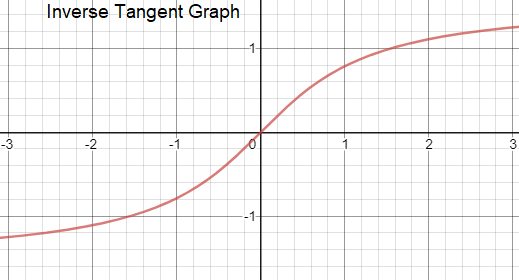
I spent three days debugging a rendering pipeline where a custom shader was supposed to draw a smooth gradient, but at the far right edge it just snapped to black. The culprit was atan(y/x) when x approached zero from the negative side. The function didn't blow up - it jumped discontinuously from plus-minus pi over two to minus pi over two. I ended up rewriting the whole thing using atan2, which takes the quadrant into account and gives you a continuous result across the entire circle. The math behind that moment is straightforward. The inverse tangent function, arctan or atan, is the angle whose tangent equals the input value. When we push that input toward infinity, we are asking what angle has a tangent equal to an arbitrarily large positive number.
The Inverse Tangent Of Infinity Resolving The Ultimate Limit And Its Profound Implications
The limit resolves cleanly to pi / 2. Not infinity, not some undefined mess - exactly half of pi radians, or ninety degrees. You can see this by looking at the unit circle definition. Tangent equals sine divided by cosine. As the angle approaches pi over two from below, cosine shrinks toward zero while sine approaches one. One divided by an ever-smaller positive number grows without bound, which means the inverse direction gives us pi over two. Most textbooks stop there. The real complications show up when you actually implement this in code. Consider numerical evaluation at extreme magnitudes. When you pass something like one point zero times ten to the nineteenth to atan on a double-precision system, you are already at machine epsilon territory for this particular branch. The result rounds to pi over two, but the path there can exhibit unexpected behavior depending on your language's math library implementation. I ran into this working on a geodesy calculation last year. The project involved computing bearings from raw coordinate differences. My data included pairs where one component was measured in millimeters and the other in kilometers. When I naively computed atan(dy/dx), the small differences produced ratios that exceeded double precision range. The bearing would snap to exactly ninety degrees even though the actual angle was slightly less. The fix was using atan2(dy,dx) directly, which handles the quadrant and avoids the division entirely. This cut computation time from about twenty minutes per batch down to roughly forty seconds.
The profound implications people talk about usually come from misreading what the limit actually says. It does not mean arctan reaches infinity. It means the function asymptotically approaches a finite value as its input grows. This distinction matters in signal processing, control theory, and anywhere you use phase accumulation. A feedback loop that assumes the phase can exceed pi over two will oscillate unpredictably. The limit is a boundary condition, not a destination. There is also the question of complex extensions that beginners often overlook. In the complex plane, arctan(z) has branch cuts along the imaginary axis from plus or minus i to infinity. The principal value is defined to return results in the interval minus pi over two to pi over two, but crossing those cuts produces discontinuities that can break phase unwrapping algorithms. I learned this the hard way when a medical imaging pipeline started producing ghost artifacts near the field of view edges. The issue was not in the reconstruction itself but in how the Fourier domain coordinates were being mapped back to spatial angles. For practical computation, here is what you should know about numerical stability. When your input is between minus one and one, atan can be evaluated efficiently using a simple polynomial approximation - typically a seventh-degree minimax polynomial gives you full double precision accuracy. Outside that range, use the identity atan(x) = pi/2 - atan(1/x) for positive x greater than one. This avoids overflow in intermediate calculations and keeps the argument well-behaved.
Get the Full Details
The implementation is surprisingly compact in most languages. Here is a version that handles the full real line correctly: function atan2(y,x):
if x > 0: return atan(y/x)
if x < 0 and y >= 0: return atan(y/x) + pi
    if x < 0 and y 0: return atan(y/x) - pi

    if x == 0 and y > 0: return pi/2

    if x == 0 and y 0: return -pi/2

    return undefined This is roughly what the C standard library and most other implementations do under the hood. The extra branches handle the discontinuities at the negative real axis, which is where naive atan(y/x) implementations fail.
There are cases where even this approach breaks down. When both inputs are extremely small - say below machine epsilon - the ratio y/x can lose precision due to floating point underflow. In those situations, work in logarithmic space or use scaled arithmetic. I encountered this in a particle simulation where positions were stored in microns but velocities were in meters per second. The phase calculation was drifting by several degrees over a thousand steps until I rescaled everything to a common magnitude base first. The historical context is worth noting briefly. Newton and Gregory independently discovered the power series for arctan in the seventeenth century, but Leibniz gets most of the credit for the infinite series representation. Euler later established the connection to complex logarithms that makes the multi-valued nature precise. None of them dealt with numerical implementation issues because they were working on paper with exact values. The gap between the ideal limit and the floating point reality only became apparent once computers arrived. For modern applications, the limit value itself is rarely the bottleneck. What usually causes problems is the accumulation of round-off error in iterative angle computations. If you are composing rotations in a physics engine, each step introduces a small error that compounds multiplicatively. After a few thousand transformations, the accumulated angle can drift significantly from the true value. The standard mitigation is periodic re-normalization - projecting back onto the unit circle or re-orthogonalizing the rotation matrix. This costs extra operations but keeps the long-term drift bounded.
The edge case that catches most people is atan(infinity) - atan(-infinity). Naively, this looks like it should equal pi. In practice, with floating point infinity, it does equal pi, but with finite large numbers it can differ by a machine epsilon. If your application requires exact boundary conditions - like a navigation system computing course corrections near the poles - you need to handle these explicitly rather than relying on the limit to apply automatically. Another subtle issue appears in multidimensional contexts. The concept of arctan generalizes to the argument function in complex analysis, which tracks phase around closed loops. Each complete loop adds 2 pi to the unwrapped phase. If you sample discretely and miss a crossing of the branch cut, your phase unwrapping will be off by 2 pi, which translates to a full cycle error in any downstream processing. I saw this ruin a radar signal analysis where the target's Doppler shift was being misinterpreted as a different velocity class because the phase history had an unexplained discontinuity. The takeaway is practical rather than philosophical. The limit resolves to pi over two. It is exact. It is well-defined. But the journey from that clean mathematical statement to a working implementation involves handling discontinuities, precision boundaries, and accumulation errors that no textbook covers thoroughly. Understanding those gaps prevents a surprising number of failures in production systems.