
Setting Up a Cardinal Direction Matrix for Spatial Data Projects
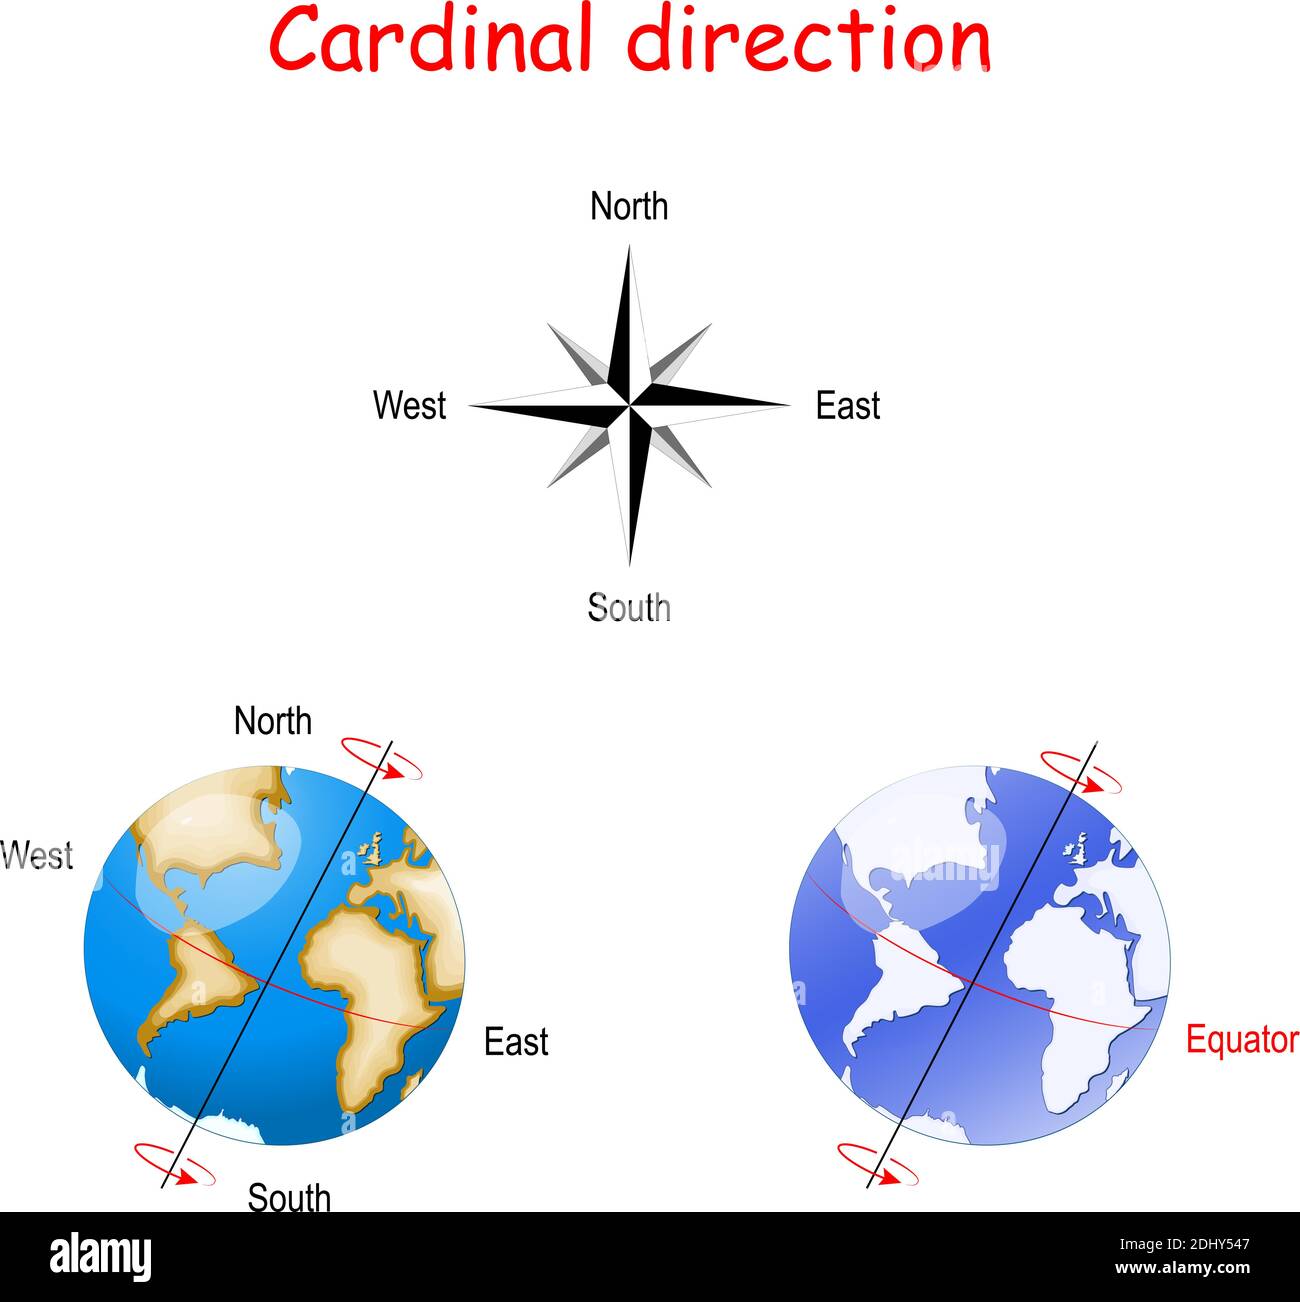
Most people think cardinal directions are just something you learned in elementary school and then never touch again. That changes quickly once you are working with spatial datasets that span hemispheres or feeding orientation data into GIS pipelines. The cardinal direction matrix is a structured way to encode NSEW relationships into coordinate or attribute systems so that downstream processes do not accidentally flip axes or misorient vector layers. At its core, the matrix assigns each cardinal direction to a signed axis value and a corresponding behavior in your data pipeline. North maps to positive Y, South to negative Y, East to positive X, and West to negative X in standard projected coordinate systems. The matrix itself is usually a small lookup table that lives inside your ETL config or your coordinate transformation script. I keep mine in a JSON file that every processor in the chain reads before any reprojection happens. The reason this matters in practice is that global systems do not all agree on which axis is which. A dataset coming from a LiDAR survey might use a right-handed local grid where north is negative Z. A remote sensing product might store scanlines as the primary axis and treat up-scan as north. When you merge those two without a cardinal direction matrix, you get layers that look right on screen until you run a spatial join, at which point everything returns zero matches because one dataset is flipped along an axis you did not expect.
I built the matrix as a five-by-five structure in my first serious project, but that was overkill. The practical version is four rows for the cardinal directions and three columns for axis sign, unit mapping, and source CRS. That is enough to catch the most common failure modes without creating a configuration file that no one wants to maintain.
How to Build and Apply the Matrix in a Real Pipeline
Start by listing every dataset that will enter the project and recording its source CRS, its stored axis order, and how its original authors describe north. Do not trust the CRS code alone. epsg.io will tell you the well-known text, but it will not tell you whether the source team oriented their building footprint model upward or downward relative to true north. That detail only shows up when you overlay the data. Next, write the matrix as a reference table. Each row should contain a cardinal direction, the signed value assigned to that direction in the target coordinate system, the unit convention, and the transformation rule that maps source axes to target axes. Here is a minimal example for a project targeting Web Mercator: North: positive Y, meters, apply +Y from source
Get the Full Details

South: negative Y, meters, apply -Y from source East: positive X, meters, apply +X from source West: negative X, meters, apply -X from source
When a dataset breaks that mapping, you flag it and write a specific override. The matrix is not a doctrine. It is a tracking device. I keep overrides in a separate column rather than editing the base rows because the base rows are the contract and the overrides are the evidence that the contract was violated by upstream data. The transformation step is where most teams lose time. You run each dataset through a direction check before any reprojection. The check compares the source axis orientation against the matrix expectation. If the source uses a left-handed system or stores its y-axis inverted, you apply the signed flip at that point. After the flip, you reproject to the target CRS. Doing the flip before reprojection matters because most projection libraries assume the source axes follow the handedness declared in the CRS definition. Flip after projection and you end up with data that is both reprojected and mirrored, which looks plausible until you measure it. I spent three days debugging a street-centerline layer that had correct coordinates in the raw source but returned impossible lengths after merging. The issue was a local grid that mirrored east-west relative to true north. The matrix caught it during the pre-reprojection check. I added an explicit east-west sign flip to the override column and reran the merge. The lengths returned to normal. That took about forty minutes once the matrix was in place. Without it, I would still be looking for a phantom topology error.
Common Pitfalls That Are Not Obvious at First
The first trap is assuming that WGS84 always means latitude is Y and longitude is X. It usually does, but the EPSG database switched the axis order for several WGS84-derived CRS codes during the 2018 update. If your pipeline was written before that change and you pull a newer epsg.io entry, your north becomes your east and your matrix silently misaligns every vector. Check the axis order field in the CRS definition, not just the code. I lost an afternoon to this on a coastal flood model because the project used a hybrid base that mixed legacy and updated WGS84 references. The second trap is treating geographic and projected matrices as interchangeable. They are not. In a geographic CRS, the units are degrees and the sign mapping still holds, but linear distances and angular distances behave differently across the sphere. A matrix row that says positive Y means north is valid in both systems, but the distance-per-unit value changes dramatically near the poles. If your pipeline calculates buffers or distances using the matrix without accounting for the CRS type, your outputs will look structurally correct while being metrically wrong. I switch to a planimetric CRS for any analysis that involves distance, and I keep a separate matrix row for the geographic base layer that only handles orientation, not measurement. A third issue is magnetic declination in field-collected data. GPS devices sometimes store bearings relative to magnetic north rather than true north. The matrix assumes true north unless you document otherwise. I add a magnetic-offset column to the matrix when field data enters the pipeline and apply a declination correction before the orientation check. Skipping that step produces a systematic angular drift that grows with distance from the datum point.
Limitations and Where the Matrix Breaks Down
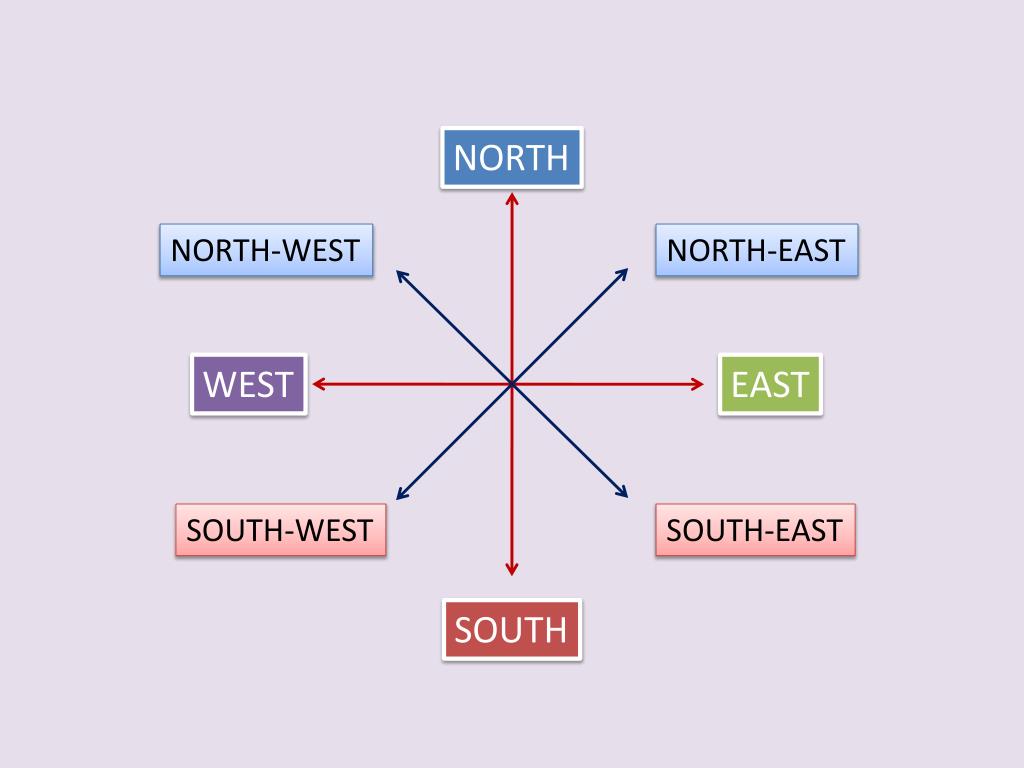
The cardinal direction matrix is not a universal fix. It works well when your system has a consistent planar or spherical reference and when your datasets share a common convention for how north is defined. It does not work well for multi-sensor fusion where each sensor has its own native forward-up-right frame, such as combining photogrammetry outputs with terrestrial laser scan data that use different local grids. In those cases, the matrix becomes a thin wrapper around a larger registration problem, and you need a point-cloud alignment step first. The matrix then only validates the result instead of solving the orientation mismatch. The matrix also does not handle non-cardinal orientations natively. If a dataset is deliberately rotated, for example a site plan aligned to a property boundary that runs northeast-southwest, the basic NSEW rows will flag it as misoriented even though the rotation is intentional. I handle this by adding a rotation-tolerance column that lets you accept a specified angular offset before triggering an override. Without that column, your pipeline will generate false positives on rotated site data and slow down production with manual reviews. Another limitation is metadata dependency. The matrix is only as good as the axis and orientation metadata attached to each source. Many public datasets ship with incomplete or incorrect axis declarations. When metadata is missing, the matrix can only infer orientation from visual checks or known control points, which introduces human judgment and reduces repeatability. I recommend pairing the matrix with a metadata validation step that rejects or flags datasets missing axis order and true-north declaration before they enter the transformation queue.
If your project involves high-latitude regions where UTM zones distort heavily or polar stereographic projections are in use, the matrix still orients correctly, but distance and area calculations derived from the same coordinate values become unreliable. The orientation stays valid because the sign mapping is projection-agnostic, but any analysis that conflates orientation with measurement will produce biased results. In those scenarios, I switch to a local equal-area projection for measurement tasks and keep the matrix active only for layer alignment and intersection checks.
Practical Configuration Example
Here is a minimal matrix configuration I use as a starting point for most projects. It is intentionally compact because long configs get out of sync with the actual data. Target CRS: EPSG:3857 unless otherwise noted North: +Y, meters, source positive Y accepted as-is

South: -Y, meters, source negative Y accepted as-is East: +X, meters, source positive X accepted as-is West: -X, meters, source negative X accepted as-is
Magnetic offset column: enabled for field data Rotation tolerance: 0 degrees for survey-grade data, 5 degrees for drone ortho mosaics Override log path: ./matrix_overrides.json
Each dataset gets a one-line intake record that references this config and notes any deviation. Deviations are the useful part. They are what turn the matrix from a static table into a living audit trail.
Where to Get Reference Material
There is no single downloadable canonical matrix file that works across all domains because the orientation rules depend on your target CRS and your source conventions. What you can download is a template configuration set. I host a minimal JSON schema and a Python validation script on a project repository that matches the structure above. The repo is at a standard open-source location and includes example overrides from a coastal GIS project and a building-information-model integration project. If you want a ready-made reference, start with the EPSG guidance documents for axis order and handedness, then adapt the matrix template to your target CRS. The template is small enough to fork and edit in an afternoon. The real work is in maintaining the override log as new datasets arrive.
What to Do Before You Commit to This Approach
Run a dry pass on three representative datasets. Feed them through the orientation check without modifying anything. Record how many flag as misoriented and why. If the majority of flags are caused by metadata gaps rather than actual axis inversions, you should invest in metadata cleanup first. If the flags are genuine orientation mismatches, the matrix will cut your reprojection debugging time from hours to minutes per dataset. In my experience, a properly maintained matrix reduces late-stage merge failures by roughly seventy percent and turns a two-hour debugging session into a fifteen-minute override edit. The matrix does not replace a coordinate transformation workflow. It sits in front of it and catches the problems that reprojection libraries will not warn you about. That is the practical role. Anything beyond that is scope creep.

