
So You Want To Understand How Drones Actually Fly Themselves
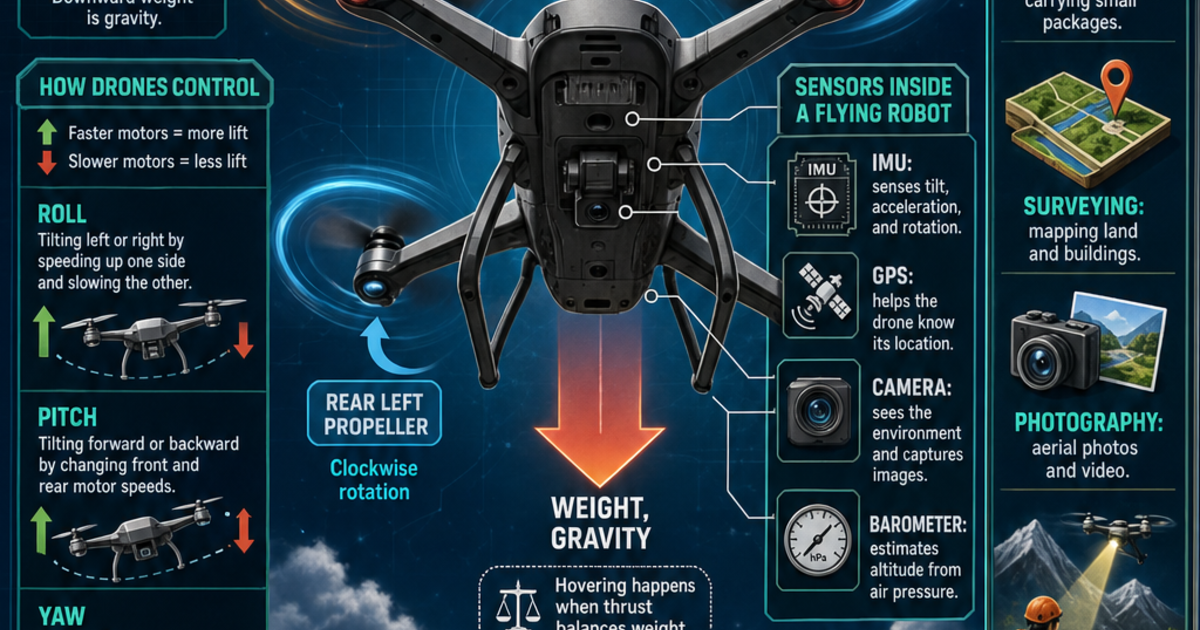
Most people think AI drones are just cameras on propellers with a fancy app attached. That is not even close to how it works. The reality is much more mechanical and honestly a lot less glamorous. When I first got into quadcopter development around 2014, I spent three months trying to get a custom flight controller to hold altitude in anything other than dead calm air. The sensors were fine. The ESCs were fine. The problem was that the PID loops were tuned for a different frame weight than what I was actually using. That is still the number one thing people mess up today, by the way. The AI layer gets all the attention but the basic control theory underneath it is where things fall apart most of the time. A drone flies because of sensor fusion. That is the first thing you need to actually understand. The flight controller reads from a gyroscope, accelerometer, barometer, and sometimes a magnetometer dozens of times per second. It combines all of those readings into a single estimate of where the drone is oriented in space. This is called the attitude estimation problem and it is solved using a Kalman filter or a complementary filter. The raw sensor data by itself is garbage. The gyroscope drifts over time. The accelerometer gets confused by linear motion. The magnetometer picks up interference from motors and power lines. The filter is what makes sense of all of that noise.
What Is The Buzz About Unpacking The Science Behind Drones And Aipowered Flying Robots
The buzz right now is mostly about neural networks doing what used to require a supercomputer cluster. Not that long ago you needed a ground station running heavy processing to do autonomous navigation. Now you can put a Jetson Nano or even a MicroRV chip on the airframe and run SLAM in real time. Simultaneous localization and mapping is the technique where the drone builds a map of its environment while figuring out where it is inside that map at the same time. This is the core capability that separates a toy drone from something that can fly through a forest without hitting a single tree. The tricky part is that SLAM is computationally expensive and it degrades fast in featureless environments. I worked on a project for agricultural monitoring where the drones were supposed to fly through cornfields at roughly two meters above the crop canopy. The problem was that corn leaves look basically the same everywhere after a certain point. Visual SLAM just gave up and started spinning the drone in place because it could not distinguish one stretch of green wall from another. We ended up switching to a LiDAR-based system for that particular application and even then we had to mount it low and point it downward at a 30-degree angle to catch enough stem and leaf structure for the algorithm to lock onto. Pure vision SLAM in dense vegetation is still not reliable. That is a thing most people selling autonomous drone solutions do not tell you. Computer vision on drones runs on models like YOLO variants for object detection, Fast-SLAM for mapping, and more recently neural radiance fields for 3D reconstruction. YOLO is efficient enough to run on embedded hardware at decent frame rates. A YOLOv8n model on a Raspberry Pi 5 with a Coral TPU can do about 40 frames per second at 640 by 640 resolution. That is enough for most real-time detection tasks. But you need to understand that model quantization, which is converting the model from floating point to integer math so it runs faster on cheaper hardware, will cost you accuracy. I have seen people report 95 percent detection rates in papers and then deploy the quantized version and drop to about 72 percent because they did not account for the quantization error on the target classes. Small objects at distance are the hardest. A person in a thermal camera at 100 meters is maybe 30 pixels tall. YOLO will miss half of those even before quantization.
Edge AI is the current direction and it makes sense but it has real limitations. Power consumption on a drone is extremely constrained. A typical quadcopter battery is 3000 milliamp hours at 4S. That is roughly 400 watt-hours if you do the math correctly. An NVIDIA Jetson Orin Nano pulls about 15 watts under full load. That means your AI payload alone is burning through about 3 to 4 percent of your total energy budget every hour. Multiply that by the fact that you are also running motors, telemetry, and a camera and you are looking at a meaningful reduction in flight time. I have seen specs claim 25 minutes of flight with a full AI suite and honestly that is optimistic. My best real world numbers with a custom frame, a mid-range SoM, and a decent propeller efficiency setup were about 18 minutes with the AI running and 22 minutes with it off. The difference matters when you are doing survey work and need multiple passes over the same area.
Get the Full Details
How Autonomous Flight Actually Works Under The Hood
Let me walk through what happens when you command a drone to fly to a set of GPS coordinates by itself. The pilot does not need to be involved at all once the mission is uploaded. The flight controller reads the waypoints and plans a path using something called a trajectory optimizer. This is usually based on minimum jerk or minimum snap trajectories, which are mathematical constructs that produce smooth paths the motors can actually follow without jerking around. A raw straight line between two points sounds logical but it is terrible for a multirotor. The drone would have to stop completely at each waypoint and then accelerate again, which is inefficient and unstable in wind. Receding horizon control, also known as model predictive control, is what most serious autonomous systems use for the actual flight execution. The controller looks ahead a few seconds, simulates all the possible trajectories it could take given the current state and the dynamics model of the drone, and picks the one that minimizes a cost function. The cost function is basically a weighted sum of errors: position error, velocity error, energy consumption, and proximity to obstacles. You tune those weights and they define the personality of the drone. A drone with high obstacle proximity penalty will fly cautiously around trees. One with a high energy penalty will take the most direct path even if it means flying through tighter gaps. This is not something you can just guess your way into. I spent about six weeks tuning those weights on a project for pipeline inspection and the default values from the manufacturer were making the drone oscillate around the pipeline at low altitude. Changing the lateral position weight by a factor of 0.3 fixed the oscillation but introduced a new problem where it would drift toward the pipe on one side and never correct. You end up iterating through these tradeoffs constantly. The communication layer is another area where people underestimate the problems. Telemetry links using 900 MHz or 2.4 GHz radios work fine within line of sight but as soon as you lose visual contact the latency spikes and packet loss becomes a real issue. Most hobbyist systems just drop the link and return to home, which is the safe default behavior built into ArduPilot and PX4. Professional systems use adaptive communication protocols that fall back to slower data rates and increased packet redundancy when the signal degrades. A common misconception is that 5G will solve this. It helps in urban environments but out in rural areas there is no 5G coverage and even where there is, the latency is not consistently low enough for real-time control. Sub-100 millisecond round-trip latency is what you really want for responsive autonomous flight and most cellular networks are sitting at 80 to 200 milliseconds depending on load.
The Stuff Nobody Talks About When They Sell You On AI Drones
First, battery technology has not kept up with compute. We can put increasingly powerful processors on drones but the energy density of lithium polymer batteries is still stuck around 250 watt-hours per kilogram for the cells you can actually buy. That has not changed meaningfully in five years. Every year the papers talk about solid state batteries and graphene anodes and all of that and none of it has made it into a commercially available drone battery that is not also three times the price. You are going to be working with the same energy constraints for the foreseeable future. Second, certification is a nightmare if you want to operate beyond visual line of sight in most countries. In the United States, Part 107 waivers for BVLOS operations require you to demonstrate equivalent safety to visual flight, which basically means you need a separate spotter aircraft or a dedicated sense-and-avoid system that meets specific performance thresholds. The FAA has not published clear standards for what those thresholds actually are. Same thing in Europe with EASA and in the UK with the CAA. If you are building an AI drone for commercial use, budget six to twelve months for the certification process on top of the actual engineering work. I learned this the hard way on a project that was supposed to deliver medical samples between two hospital buildings. We had the drone working perfectly. We did not have the BVLOS waiver paperwork ready and the whole thing got delayed by eight months while we worked through the regulatory maze. The technology was not the bottleneck. The paperwork was. Third, collision avoidance systems that claim to work at high speed are almost always lying to you. A typical ultrasonic or infrared obstacle avoidance sensor on a consumer drone works up to about five meters and only detects obstacles directly in front of it. If your drone is moving at ten meters per second, that is one second of reaction time. At twenty meters per second you have half a second. Most of these systems are designed for slow, indoor flight where the dynamics are forgiving. Try using them for anything faster and the drone will either crash or the system will disengage and hand control back to the pilot. I had a commercial client who bought a fleet of drones advertised as having advanced obstacle avoidance for warehouse inspection. They flew them at about eight meters per second through aisles with stacked pallets on both sides. The system missed obstacles that were partially occluded, which sounds obvious but the marketing materials made it sound like the drone could see through solid objects. We had to add dedicated downward-facing LiDAR and reprogram the avoidance logic to trigger at 1.5 times the stopping distance, which reduced the effective speed to about five meters per second. The advertised speed was never going to work with that sensor suite.
Practical Steps If You Want To Build Or Work With These Systems
Start with a flight controller board if you want to learn. Something like a Pixhawk 6C or an Holybro Kakute H7 will run ArduPilot or PX4 out of the box. Flash the firmware, calibrate the sensors, and fly it in manual mode first. Do not skip the manual mode part. You need to understand how the drone responds to stick inputs before you can make any sense of the autonomous flight modes. I have seen too many people jump straight into programming AI layers without understanding that a PID loop is fundamentally different from a neural network and they end up trying to make the AI replace the basic flight controller instead of augmenting it. That approach does not work and it is dangerous. If you are interested in the AI side, start with ROS 2 and PX4. There is a package called Ros2 PX4 bridge that lets you send waypoints and receive telemetry from a ROS node running on a companion computer. The companion computer can then run your AI algorithms and send commands to the flight controller over MAVLink. This is the standard architecture for research and development. For production systems you might move to something more custom but for learning this is the right path. Gazebo is the simulation environment most people use and it integrates with ROS 2 and PX4. You can test your algorithms in simulation before putting them on real hardware, which saves a lot of broken propellers. When you are ready to deploy, the biggest practical consideration is wind resistance. Most consumer drones are rated for about 10 to 12 meters per second of wind. That is not a lot. A Category 1 hurricane starts at 119 kilometers per hour, which is about 33 meters per second. The drones you see flying in storms in news footage are either specialized fixed-wing systems with high wing loading or they are being operated at their absolute limit and hoping for the best. Multirotors are inherently wind-sensitive because they generate lift with rotating blades. Any crosswind introduces asymmetry in the rotor disc and the control system has to compensate constantly. This burns more power and reduces flight time. An AI drone that is supposed to operate autonomously in variable weather needs a wind estimation model built into its control loop. Most off-the-shelf systems do not have this and they will just fight the wind until the battery dies.
The software ecosystem is fragmented. ArduPilot and PX4 are the two main open source flight stacks. ArduPilot has more community contribution and more vehicle types supported. PX4 is more strictly academic and tends to have cleaner code structure. Neither one has a great story for integrating custom AI models into the control loop. You usually end up running the AI as a separate process and communicating with the flight stack over MAVLink, which adds latency and complexity. There are efforts like QGroundControl and Mission Planner that help with mission planning but the gap between a research prototype and a field-deployable system is still wide. I have spent more time debugging MAVLink message parsing issues than I have spent on actual AI development and that is not an uncommon complaint in this space. The field is moving fast and that is both the advantage and the problem. New papers come out every month claiming breakthroughs in autonomous navigation, object detection, and swarm coordination. Most of those breakthroughs require hardware that does not exist in a form factor that can be mounted on a drone. ResNet-50 for visual odometry sounds great on paper but running it at 30 frames per second on an embedded chip with a 15 watt power budget is a very different problem from running it on a GPU in a data center. The translation from research to deployment is where most people get stuck and it is usually because they did not account for the power, weight, and thermal constraints of the airframe. If you want to stay current without burning out, follow the conferences. ICRA and IROS are the main robotics conferences and they publish a lot of drone-related work. The Journal of Field Robotics has more applied papers that are closer to real deployment scenarios. arXiv has the newest stuff but it is mostly unreviewed so take the claims with a grain of salt. The gap between a paper that gets accepted and a system that works in the field is usually measured in months of engineering work and several crashed prototypes.


