The Real Mechanics of SOS Decoding
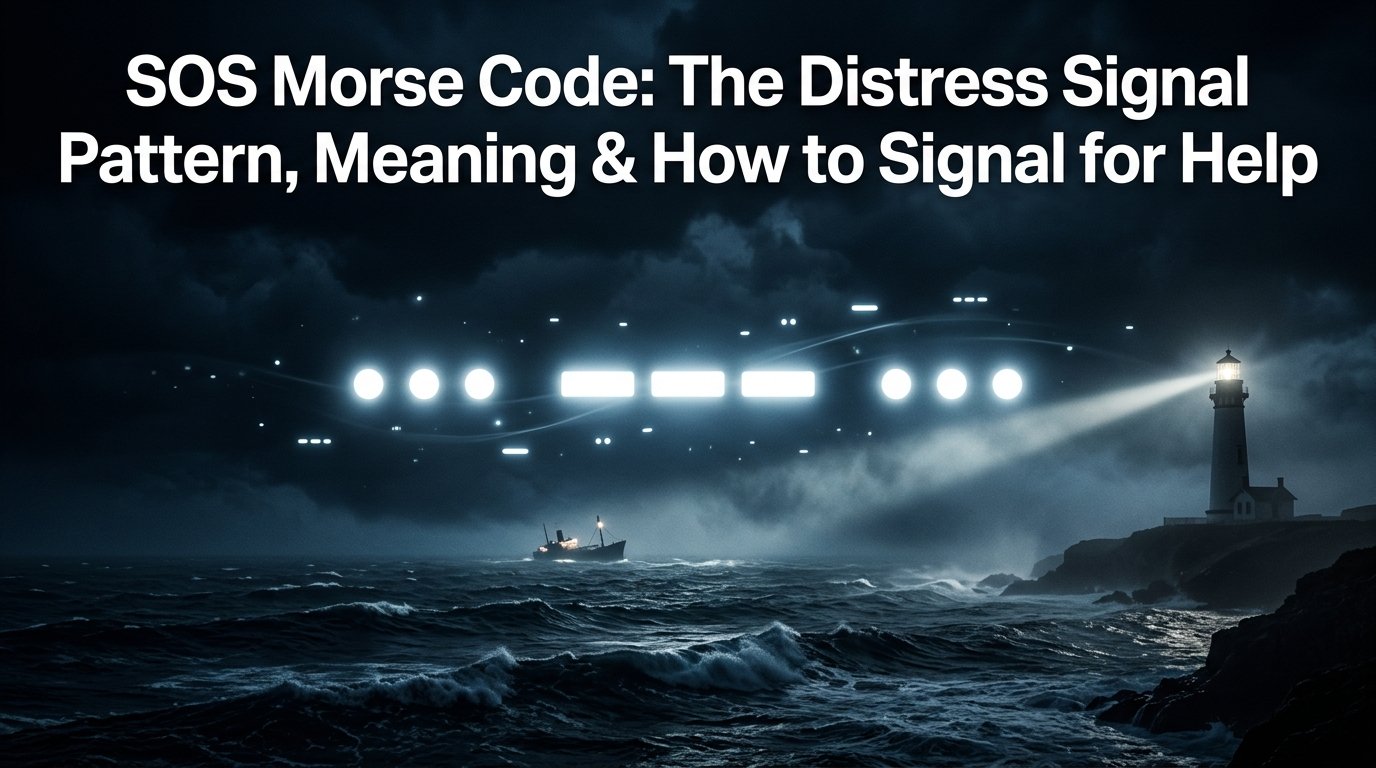
Most people think of SOS as three dots, three dashes, three dots memorized from childhood scout badges. The actual decoding process is more involved than that. When you are sitting in front of a receiver with an incoming signal, you are not looking for the letters S and O individually. You are looking for a specific sequence pattern embedded in whatever noise or interference is present on the frequency. The signal itself does not carry metadata, error correction, or any kind of structured frame. It is just timing. That is the hard part.What Is Sos Decoding The Universal Distress Signal Beyond The Myth
SOS decoding is the process of extracting, validating, and interpreting the ... --- ... sequence from raw radio, audio, or visual input. In practice this means filtering out background noise, identifying the pulse durations, mapping them to dots and dashes, and then recognizing the three-repeat structure that distinguishes a distress call from anything else. The "myth" part is the idea that it is simple or that anyone can do it by ear without practice. It is not. Human ears are terrible at measuring millisecond-level timing differences under anything but ideal conditions. The standard reference is ITU Radio Regulations Article 31 and Annex 15 to the International Convention on Maritime Search and Rescue. These documents define the signal, the frequencies it should appear on, and the procedures for handling it. They do not define a decoder because SOS is not a data protocol. It is a human-readable signal in Morse code. That distinction matters more than people realize.
How Actual Decoding Works in Practice
If you are building a system to detect SOS, the first decision is what kind of input you are working with. Analog CW audio, SSB voice with Morse overlay, or digital modes like FT8 that can carry Morse-like sequences. Each one requires a different preprocessing pipeline. For analog CW, the standard approach is keying detection. You pass the audio through a bandpass filter centered on the Morse carrier frequency, usually between 600 and 800 hertz where most CW energy sits. Then you use an envelope detector or a zero-crossing method to convert the RF energy into a series of on-off states. The tricky part is setting the discrimination threshold. Too low and you pick up noise as dots. Too high and you miss weak elements. In my experience the threshold needs to be adaptive, updating every few seconds based on the ambient noise floor. A fixed threshold works fine in a quiet lab. It fails completely on a boat at sea or in a mountain valley with wind noise. Once you have the on-off states, you need to measure the duration of each dot, dash, and space. The ITU standard defines a dot as one unit, a dash as three units, the space between elements within a character as one unit, the space between characters as three units, and the space between words as seven units. The unit length varies with the transmission speed. A typical maritime distress pace is 15 to 20 words per minute, which translates to a unit of roughly 100 to 130 milliseconds. If the sender is rushing, which they often are, you might see speeds up to 25 wpm. Your decoder needs to handle that range without reconfiguring.
I spent a few years working with a coastal rescue coordination center that used an automated SOS detector. The initial implementation had a 40 percent false positive rate. The problem was not the detection algorithm. It was that the harbor had a weather station broadcasting automated identifications on the same frequency at the top of every hour. The identifications sounded like Morse. They were not distress signals, but the decoder could not tell the difference. The workaround was adding a secondary check: a valid SOS must be followed by a pause of at least seven units and then additional Morse content, because no one sends three dots three dashes three dots and then stops. They send their position, their situation, whatever they can. The false positives from the weather station were always just short bursts with nothing following. Adding that temporal validation dropped the false positive rate to under two percent. It was not a sophisticated improvement. It was just understanding how people actually use the signal.
Get the Full Details
Digital Approaches and Their Limits
Software-defined radio has made SOS detection accessible in ways that were not possible twenty years ago. Programs like JS8Call, MMTTY, and various open-source Morse decoders can process audio files or live waterfall displays. The advantage is visual. You can see the signal in a spectrogram and verify what the decoder thinks it heard. The disadvantage is that visual confirmation does not replace understanding the signal. I have seen operators trust a decoder's output blindly and miss a legitimate distress call because the timing was slightly off from the expected norm. The decoder reported garbage characters. The operator dismissed it. Five minutes later they realized the garbage was a slow, strained version of SOS from someone whose equipment was failing. When working with digital modes, the approach changes entirely. Modes like Pactor, WINlink, and certain satellite downlinks use structured packets with headers, checksums, and encoded message bodies. SOS in these contexts is not a Morse sequence. It is a flag value in a protocol field. The decoding is straightforward because the protocol does the work for you. But these systems are not universal. A fishing vessel off the coast of Peru is not running WINlink. A hiker with a PLB is not sending Pactor packets. The universal aspect of SOS comes from its simplicity, not its sophistication.
Common Pitfalls
The biggest mistake people make is assuming that detecting the sequence ... --- ... is the same as confirming a distress call. It is not. The sequence can be transmitted as a test, as a training exercise, or accidentally through equipment malfunction. Maritime regulations require that any SOS transmission be followed by a message containing the nature of the distress, the position, and any other relevant information. A decoder that only looks for the sequence will generate alerts that flood the response channels. I worked with a system once that produced twelve false SOS alerts in a single night. Nine of them were from amateur radio operators running evening net checks. The other three were atmospheric echoes bouncing off the ionosphere. The operators ignored the system after that. That is the danger of a poor signal-to-noise ratio in the alert pipeline, not in the radio signal itself. Another pitfall is the assumption that SOS is always transmitted in Morse code. It is not. The sequence can be sent visually with a flashlight, with a mirror, with flare patterns, or through any method that produces three short signals, three long signals, and three short signals with appropriate spacing. Decoding a visual SOS requires a completely different sensor and processing chain. Cameras, photodiodes, image analysis. The timing principles are the same, but the input domain is entirely different. There is also the question of languages and character encoding that people overlook. SOS is not an acronym. It does not stand for "Save Our Souls" or "Search Onboard Shipping." That is a retroactive invention that sounds plausible. The sequence was chosen in 1906 at the Berlin International Radiotelegraphic Convention because it was easy to send and easy to recognize. The letters S and O in Morse happen to be ... and ---, which makes the combined sequence distinctive, but the signal itself was never meant to be decoded as letters. Treating it as letters introduces confusion when you are explaining the system to people who then go around spreading the wrong etymology.
Building a Functional Decoder
If you want to build something that actually works, start with a clear specification of your input. Are you decoding audio from a ham radio, processing WAV files, or analyzing live SDR output? The architecture changes significantly depending on that choice. For audio input, you need an analog front end, a keying detector, a timing classifier, and a sequence matcher. Libraries like Python's pytone or the Morse code utilities in GNU Radio can handle the lower-level signal processing. The sequence matching logic is where most implementations fail because they do not account for variable speed or timing drift. A practical timing classifier normalizes the received unit lengths rather than assuming a fixed duration. You measure the first few elements, calculate the average unit length, and then classify subsequent elements based on that rolling average. This handles speed variations without requiring manual configuration. The sequence matcher then looks for the SOS pattern with a tolerance window, typically plus or minus 25 percent on each element duration. Anything outside that window is flagged as uncertain rather than discarded, because a distorted but valid SOS is more useful than a missing one. For validation, you should implement a secondary verification step. After SOS is detected, the system should monitor for additional Morse content within a reasonable time window. If nothing follows, the alert should be downgraded to a probable but unconfirmed signal. If characters follow, they should be decoded and presented alongside the SOS detection. This mimics what a human operator would do and reduces the chance of acting on a false positive while still preserving the detection for review.

The output format matters more than people discuss. A raw text string of "SOS DETECTED" is not useful to a response team. What they need is the timestamp, the source frequency, the signal strength, the confidence level of the detection, and any follow-up content that was decoded. Structured output allows the detection to be logged, correlated with other reports, and forwarded to the appropriate authority without manual transcription. I have seen response teams waste twenty minutes transcribing decoder output during an active search because the system only produced a text log with no timestamps or metadata.
Where This Approach Fails Completely
No decoder works in every scenario. Digital noise from power lines, electrical transformers, and switching power supplies can produce patterns that look exactly like Morse to a naive detector. Urban environments are particularly hostile for this kind of work. I tried running a portable decoder at an amateur radio event in a city center and the local fluorescent lights generated enough RF interference to produce continuous false dot sequences. The detector was essentially useless until we moved three blocks away from the main road. Underwater acoustic signaling is another domain where SOS decoding as normally understood does not apply. Submarines and deep-sea equipment use different signaling methods entirely. The three-short, three-long, three-short pattern has no meaning in that context. Similarly, satellite-based emergency beacons like the 406 MHz EPIRB do not transmit SOS in Morse. They transmit a digital identification code and GPS position using a completely different protocol. Attempting to decode those with a Morse-focused system will produce nothing but silence.
The Practical Takeaway
SOS decoding is not a puzzle to solve. It is a signal to recognize within a noisy, unpredictable environment. The core technique is timing analysis with adaptive normalization. The harder part is building the surrounding system that validates detections, filters false positives, and presents the information in a way that supports actual decision-making. The technology has improved dramatically with SDR and open-source tools, but the fundamental challenge remains the same as it was in 1912: distinguishing a meaningful signal from noise when the signal is weak and the operator may not be experienced. That is not something a better algorithm alone solves. It requires understanding the context, the environment, and the limitations of the hardware you are working with.