The thing nobody tells you about getting started with these systems
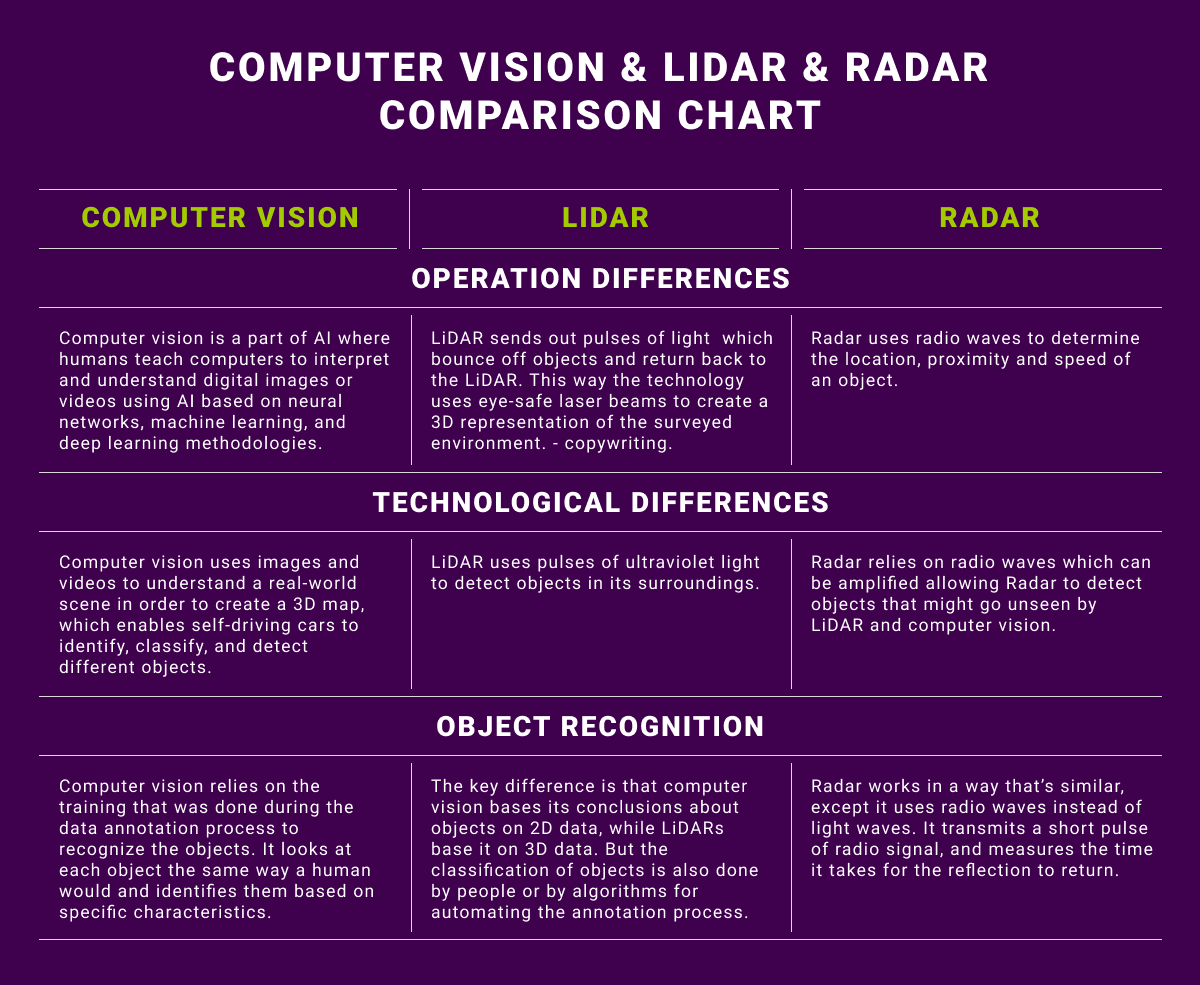
Most people walk into this thinking they need to pick one and stick with it for life. That is not how it works in practice. The reality is messier, cheaper if you plan right, and involves a lot more cabling than the marketing videos show. Camera-based perception stacks use stereo pairs or monocular rigs with deep learning models eating frames at 30 to 60 hertz. Lidar stacks spin or flash lasers and measure time-of-flight or phase shift. One gives you colour and texture. The other gives you direct metric depth. Pick whichever matches your actual deployment environment, not whichever looks better in a demo reel. I learned this the hard way running a warehouse AGV project back in 2019. We had chosen a pure vision approach because the parts list was cheap. The site had fluorescent lights that flickered at 120 hertz, which meant our 60 hertz camera was capturing rolling banding that destroyed the feature tracker. Depth estimates jumped around by half a metre every time someone flipped a breaker. We switched to a cheap 2D lidar and a single global shutter camera running at a synced exposure. The fix was adding a trigger line from the lighting controller to the camera, which eliminated the banding entirely. Total cost of that retrofit was about two hundred dollars in parts and a weekend of integration work.
Where each modality actually breaks
Cameras fail in low light, heavy rain, fog, and when textures are repetitive. A blank concrete wall is basically invisible to most feature-based stereo systems. It also fails when glare from sun or headlights washes out the sensor. You can add IR illuminators, but then you are building a night vision system, not a camera system, and you need to recalibrate everything when the illuminators age. Lidar fails when the surface absorbs the wavelength instead of reflecting it. Black fabric, matte black plastic, and certain types of glass will eat a 905 nanometer laser pulse and give you nothing. A common mistake is assuming you can trust lidar readings near dark objects without validating them. I once had a client assume their 128-channel mechanical lidar could see through a window into an office. It could not. It just returned the glass surface at varying distances depending on the angle and the smear pattern. The resulting map had floating ghost geometry everywhere. The counter-intuitive part is that a mid-range lidar often outperforms a high-end camera rig in structured indoor environments. It sounds backwards until you remember that cameras need training data that matches your exact lighting conditions. A LiDAR point cloud from today will look roughly the same next year. A camera model trained in summer daylight will drift badly in winter when the sun angle changes.
How to actually fuse them without overcomplicating things
Start simple. Do not build a full probabilistic fusion stack on day one. Run each sensor independently. Get the camera producing bounding boxes or depth maps. Get the lidar producing a clean point cloud. Then do a basic temporal sync and a handoff rule. If the lidar has a confident hit within range, use it. If it returns no return or a low-confidence measurement, fall back to the camera estimate. This logic alone covers most edge cases in controlled environments and took me about four hours to implement on a Raspberry Pi 5 with a Realsense D435i and a RoboSense Bpearl Mini. When you are ready to go deeper, use an extended Kalman filter for state estimation. The camera gives you a noisy but rich measurement. The lidar gives you a sparse but metrically accurate one. The EKF merges them into a single state vector. You do not need a factor graph or a full SLAM pipeline unless you are building a mapping system from scratch. For tracking and navigation, the EKF is usually sufficient and runs at real-time rates on commodity hardware. Calibration is where most people waste weeks. Intrinsic calibration for both sensors should come first. Then do a rigid body transform between the camera and the lidar frame. Use a calibration target that works for both modalities. A checkerboard gives you nothing for lidar. A sphere array or a specially printed planar target with retroreflective markers works better because you can detect it in both colour images and point clouds. Run the calibration at multiple distances and orientations. A single static calibration will drift as the mounts flex. Recheck every few months if the vehicle or rig sees vibration.
Get the Full Details

Choosing hardware based on your actual constraints
If you are building for an outdoor autonomous vehicle in variable weather, a solid-state lidar around 1550 nanometers paired with a global shutter camera is the safest bet. The longer wavelength penetrates fog and rain slightly better. The global shutter avoids rolling distortion during fast motion. Expect to spend between five and fifteen thousand dollars on the sensor suite alone. If you are doing indoor logistics or warehouse automation, a 2D or low-channel 3D lidar combined with an RGB camera is more than enough. The environment is controlled. The distances are short. You do not need long-range detection. A ~1,500 dollar lidar and a ~300 dollar camera will handle most pick-and-place navigation tasks without breaking a sweat. For consumer robotics or educational projects, a depth camera like an Intel RealSense or an OAK-D unit is the fastest path to something that works out of the box. These give you decent depth at short range without any custom calibration. They will not replace a professional setup, but they save you three months of R&D when you are prototyping.
Pitfalls that will quietly ruin your project
Assuming resolution is the same thing as accuracy. A 12-megapixel camera and a 128-line lidar both say 128 or 12 million. One is giving you spatial density. The other is giving you angular resolution. They are not interchangeable metrics. A lidar with poor angular resolution will miss a narrow pole. A camera with high resolution but bad stereo baseline will miss the same pole at range because the disparity is below the depth resolution limit. Ignoring sync. If your camera and lidar are not time aligned, your fusion will produce ghost objects whenever anything moves. Even a 50 millisecond offset matters at vehicle speeds. A 50 ms error at 5 metres per second is a 25 centimetre position error. Use a hardware trigger or a PTP grandmaster clock if your setup supports it. Software sync via NTP is not good enough for anything faster than walking speed. Over-relying on simulation. Isaac Sim, CARLA, and Gazebo are useful, but they do not model sensor noise accurately. A lidar point cloud in simulation looks clean. In the field, you get stray reflections, multipath noise, and sporadic missing returns. Validate every fusion parameter in the real world before you commit to a deployment. Simulation numbers are optimistic by design.
A practical walkthrough for a basic setup
Mount the camera and lidar on a rigid bracket. Keep the distance between them small to reduce extrapolation error. Connect both to a compute unit via USB 3.0 or GigE, depending on the model. Install the vendor SDKs. Open a terminal and pull a point cloud from the lidar. Open another and pull a camera frame. Verify that both streams are timestamped correctly. Run the calibration routine with your chosen target. Record the transform matrix. Save it to a config file. Write a simple ROS node or Python script that subscribes to both topics, applies the transform to the point cloud, and publishes a fused frame. Test it standing still first. Then test it with slow movement. Then test it under the lighting conditions you will actually deploy in. If the fused output looks reasonable, add your tracking or navigation logic on top. If it does not, check the timestamps, recheck the calibration, and look for mechanical flex in the mount. The problem is almost never the algorithm. It is usually the hardware or the sync.

This approach will get you a working system in a week if you plan it correctly. It will take three months if you skip calibration or ignore sensor sync. The difference is not intelligence. It is discipline.