Where Faraday's Law Actually Breaks Down And What People Miss
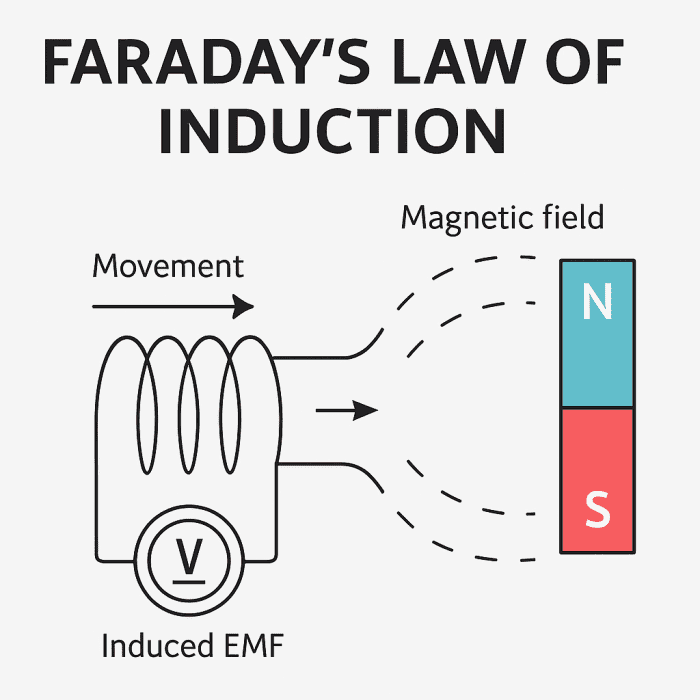
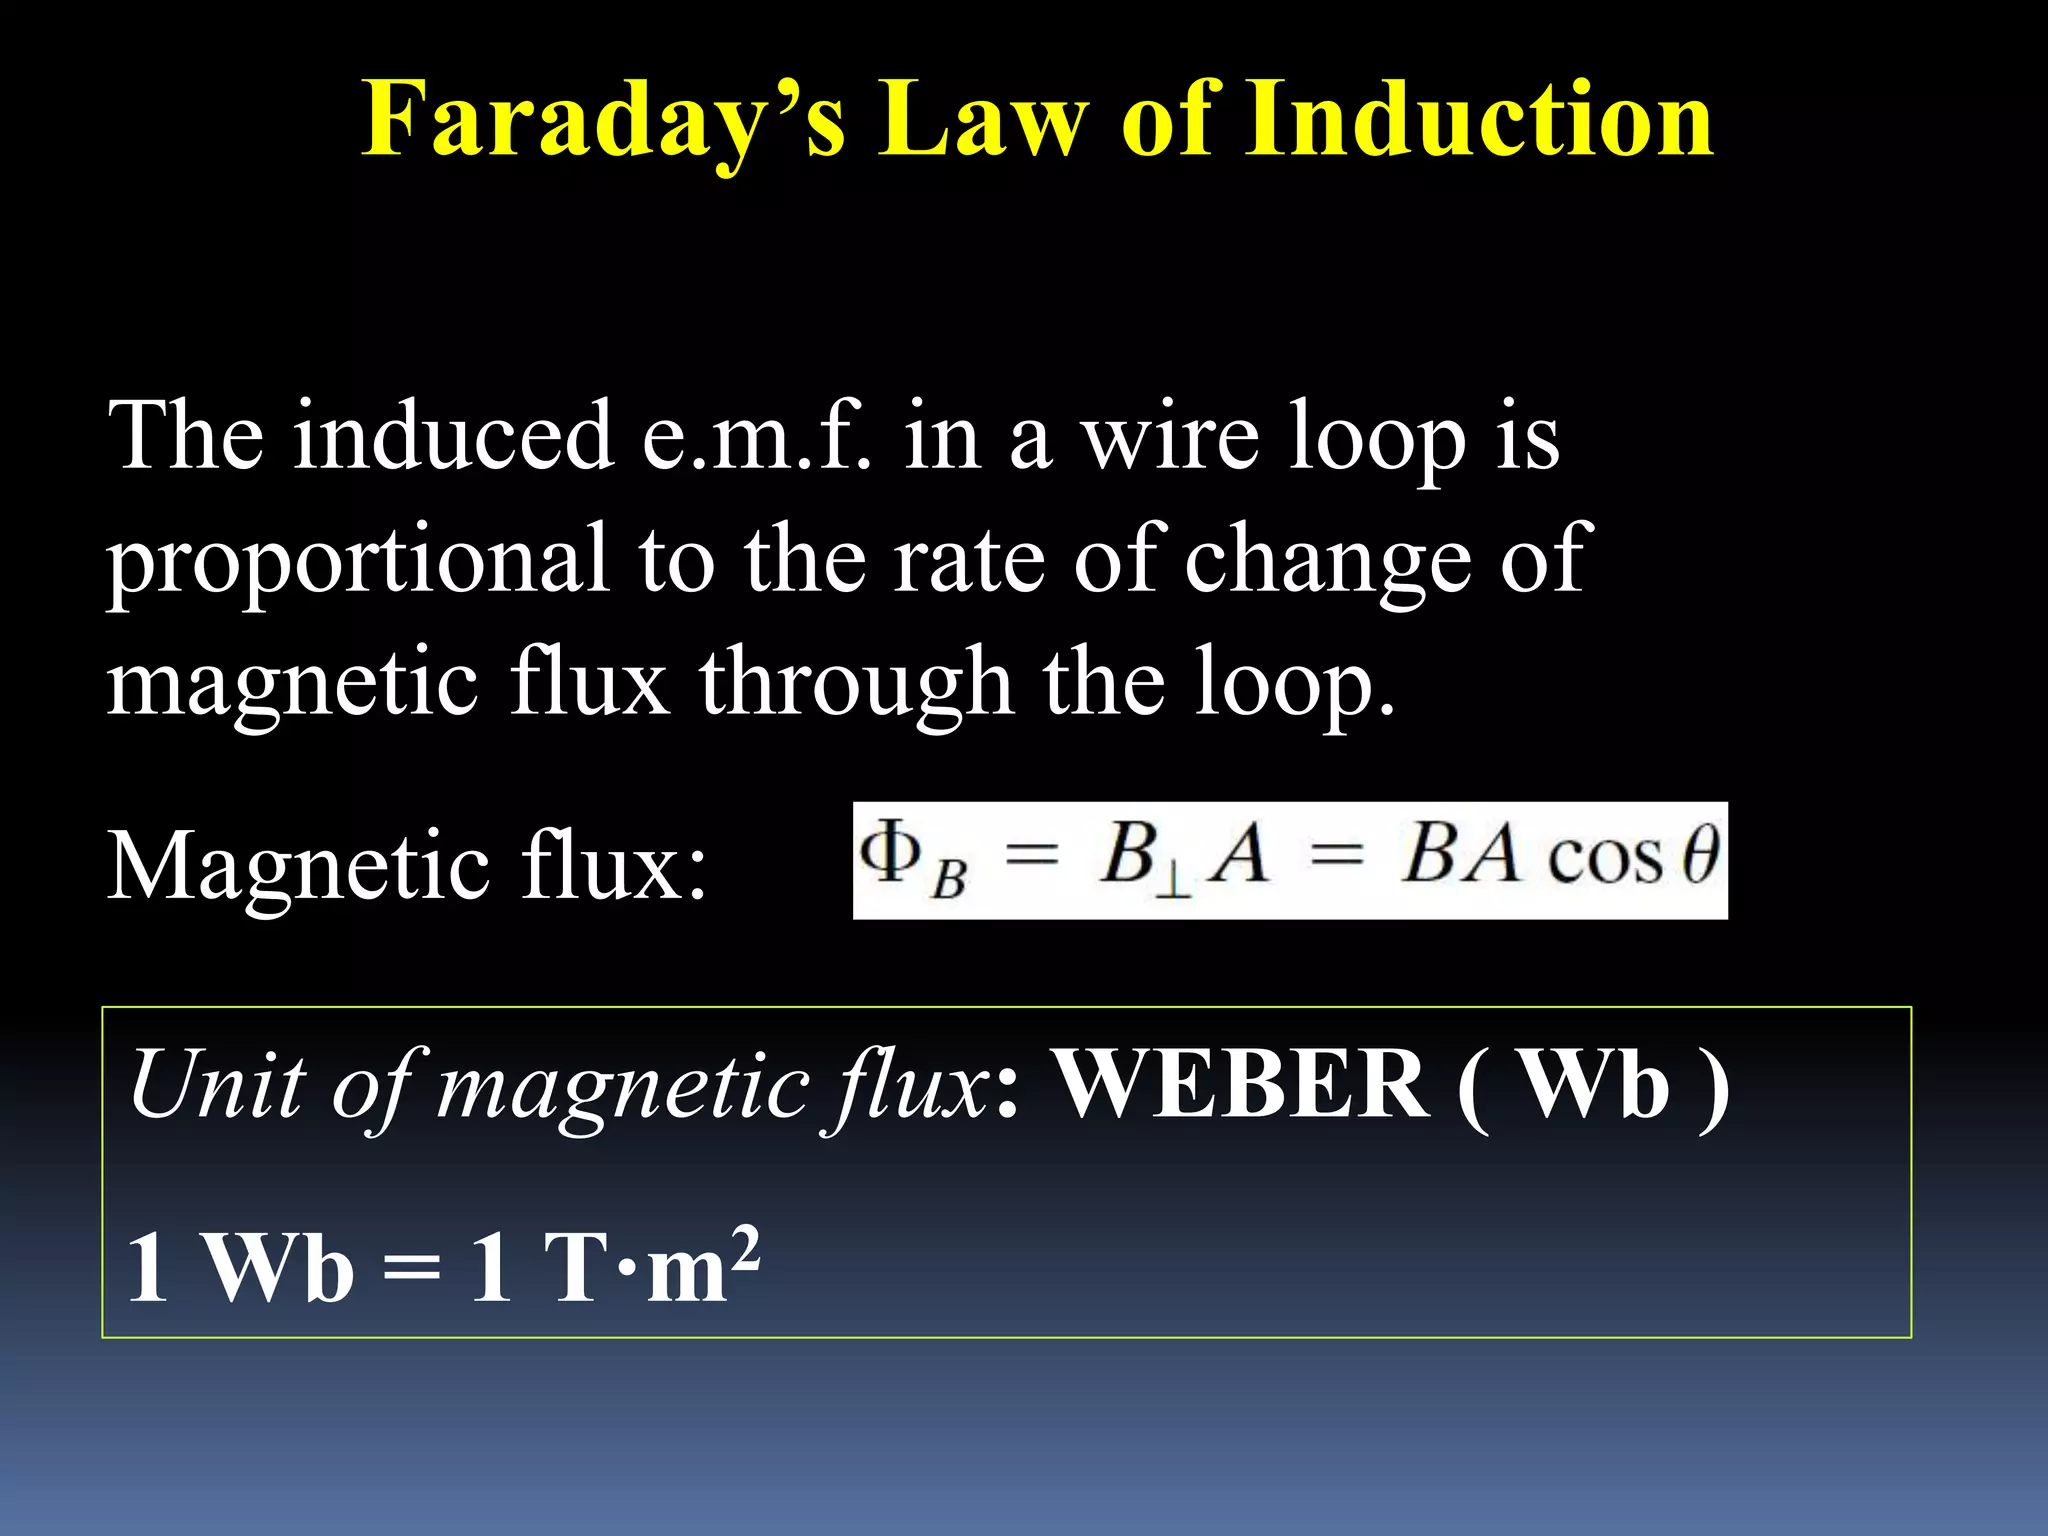
You learn Faraday's law as EMF equals the negative rate of change of flux linkage, and that works fine until you try to apply it to anything that involves actual physical motion of the conductor, or non-uniform fields, or cases where the loop boundary moves in a way that creates ambiguity about what area you are integrating over. I spent several years debugging induction-based sensor systems, and the failures always traced back to one thing: people treating the flux rule as if it were universally applicable without understanding the conditions required for it to hold. The "M" most people are really looking at when this comes up is the magnetization vector in the constitutive relation for magnetic materials. When you write the magnetic flux density as B equals mu naught times H plus M, and then substitute that into the integral form of Faraday's law, the magnetization term quietly introduces an additional contribution that standard textbooks barely mention. The induced EMF around a closed loop becomes the line integral of the electric field equals the negative time derivative of the surface integral of B dot dA, and if M is spatially varying or time-varying, that changes the effective flux in ways that pure vacuum calculations won't predict. This is especially relevant when your system contains ferromagnetic cores, soft magnetic materials, or any medium where the magnetization responds nonlinearly to the applied field. The practical consequence nobody warns you about is that in materials with significant magnetic hysteresis, the relationship between the applied current and the resulting flux is not single-valued. You drive a coil with a sinusoidal current, and the flux waveform is distorted by the hysteresis loop of the core material. The induced voltage is proportional to the derivative of this distorted flux, which means even a clean sine wave current can produce a noticeably asymmetric voltage response. I measured this directly in a prototype transformer design last year where the calculated secondary voltage was consistently 8 to 12 percent higher than predicted using only the linear permeability value from the datasheet. The fix was to characterize the core material under actual operating conditions and use a Steinmetz-based model rather than relying on the nominal mu value.
Another edge case that causes real problems is when the magnetization itself changes with position inside the material. If you have a graded magnetic material, or a core where the flux density varies significantly across the cross section, the local M is different at every point, and the simple assumption that flux is uniform across the winding area breaks down. I ran into this when designing a custom inductor for a switching power supply. The toroidal core had a measurable gradient in remanent magnetization from the manufacturing process, and the effective inductance varied by about 6 percent between cores from the same batch. The workaround was to measure each unit individually and sort them by actual inductance rather than trusting the geometry-based calculation. There is also the question of reference frames, which is where things get genuinely confusing. The motional EMF contribution, which some formulations call the v cross B term, is real and measurable, but it is only apparent when the circuit boundary moves. In a stationary frame, you transform it into a transformer EMF by recognizing that the moving conductor experiences a changing flux. Both descriptions give the same numerical result, but picking the wrong frame can make a problem look impossible. I once spent three days trying to model a sliding contact generator using only the flux rule without accounting for the fact that the circuit topology was changing with time. Switching to the Lorentz force approach on the moving conductor resolved it in about twenty minutes. If you are working with materials that have high permeability, the magnetization term dominates the B field contribution, and you need to account for it explicitly. The standard approach is to use finite element analysis software, but that is expensive and slow for iterative design work. A reasonable approximation for quick calculations is to treat the core as having an effective permeability that includes the magnetization contribution, where mu effective equals mu naught times the relative permeability, and then adjust for saturation using the B-H curve of the actual material. This gets you within about 5 percent for most engineering applications, which is usually sufficient for early-stage design.
The downside of relying on magnetization corrections is that they introduce frequency dependence. At high frequencies, the effective permeability drops due to domain wall resonance and eddy current losses within the core material. If your operating frequency is above a few kilohertz for ferrite cores, or above a few hundred hertz for powdered iron cores, the simple static M model becomes unreliable. In those cases, you need complex permeability data from the manufacturer, and you should treat the magnetization as a complex quantity with both real and imaginary parts representing energy storage and loss respectively. I should mention that the flux rule itself has well-known failures even in idealized setups. The classic example is a circuit where part of the loop is a sliding bar on rails, and the area enclosed by the circuit changes while the magnetic field remains constant. Some introductory texts present this as a separate case from the transformer EMF, but they are actually the same phenomenon viewed from different reference frames. The real failure mode appears when the loop is not a well-defined mathematical curve, or when the magnetic field is singular somewhere in the plane of the loop. In those cases, the line integral of the electric field and the rate of change of flux can give different answers, and you need to go back to the full Maxwell-Faraday equation in differential form rather than relying on the integral flux rule. For anyone actually working with this stuff, the most useful thing to keep in mind is that Faraday's law in its basic form assumes a stationary loop in a time-varying magnetic field, or a moving loop in a static field, but not both simultaneously without careful treatment. When magnetization enters the picture, you are dealing with a medium that can store and dissipate magnetic energy, and the induced EMF reflects both the external field changes and the internal response of the material. The simplest practical rule is to compute B from the total H field including the magnetization contribution, integrate B over the actual flux path, and take the time derivative. This handles most real-world cases correctly, and it avoids the common mistake of ignoring the material response entirely.
Get the Full Details