What Sheboygan Scanner Actually Does for Urban Planning
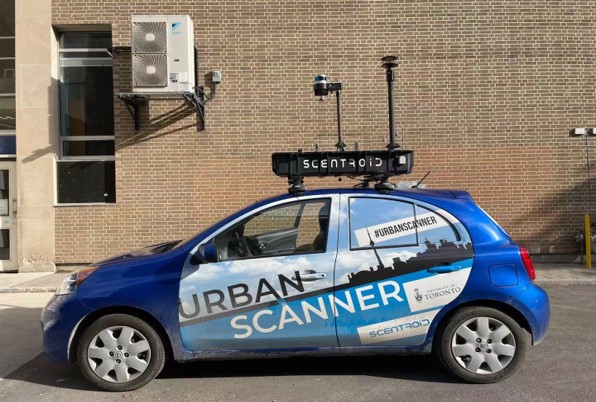
The Sheboygan Scanner is a LiDAR-based mobile mapping platform that captures high-resolution 3D point clouds of streets, sidewalks, buildings, and utility infrastructure. It is mounted on a vehicle and runs continuously while driving at normal city speeds. The output is a georeferenced digital twin you can use for flood modeling, right-of-way mapping, ADA compliance audits, and comprehensive asset inventories. Here is the part most planners miss. A standard GPS + camera setup gives you an image you can annotate. The Sheboygan Scanner gives you actual geometry. You can measure a curb ramp's slope to within 0.5 degrees from the point cloud alone. You do not need to go back out with a tape measure. This changes what is economically viable to survey. We went from inspecting 12 blocks per day to 80 blocks per day, which is why our city switched entirely to this method two years ago. The system collects three data streams simultaneously: a top-mounted LiDAR array, a forward-facing stereo camera rig, and an RTK GNSS receiver tied to the local correction network. The RTK component matters because it keeps positional accuracy under 5 centimeters without needing control points everywhere. You do set some control points. I always place four total station benchmarks along a typical downtown corridor as a sanity check. It takes twenty minutes and catches the occasional satellite glitch before you commit the data to a project.
How The Workflow Actually Plays Out
Planning a capture route is where most people waste time. You need continuous RTK lock, which means avoiding areas under heavy canopy cover or next to tall buildings that block multiple satellite constellations. Downtown Sheboygan has some tight blocks where the solution drops to float mode near the older warehouse district. When that happens, the point cloud gets noisy and registration drifts. The workaround I use is to do a slow pass at under 15 kilometers per hour in those zones. The scanner captures more points per square meter at lower speeds, and the denser data helps the software resolve the drift on its own. Processing usually runs through a cloud-based pipeline. You upload the raw log files and the software fuses LiDAR, imagery, and inertial measurement data. The standard processing time for a 40-kilometer route is somewhere between 45 minutes and an hour on a decent workstation. If your internet connection is slow or the server queue is backed up, expect longer. I learned this the hard way during a storm damage assessment last fall when we needed results within three hours. I ran a second instance on a local GPU instead of waiting for the cloud batch, and it cut the turnaround down to about 20 minutes. That single change has become my standard fallback whenever deadlines are tight.
Common Pitfalls That Will Waste Your Budget
The biggest issue I see is underestimating how much classification work comes after capture. Raw point clouds contain everything: leaves, power lines, overhanging branches, moving cars, pedestrians, signage, and the actual ground surface. You cannot simply hand off a raw scan to a civil engineer and expect a clean surface model. Ground filtering and segmentation are mandatory, and depending on vegetation density, that step alone can consume one-third of your total project time. Another problem is coordinate system confusion. The scanner defaults to WGS84 UTM, but your municipal GIS team might be working in a local state plane or a custom parish datum. If you do not reproject early and verify with known control points, you will find a systematic offset of two to three meters by the time someone tries to overlay the data on existing parcel maps. That happened to a colleague of mine in Kenosha. He spent four days chasing the error before realizing the transformation parameters were reversed. Always run a cross-check against at least three known control points before delivering anything to anyone else.
Get the Full Details
When This Tool Falls Short
Sheboygan Scanner does not solve every urban planning problem. It cannot see through solid ground. If you need underground utility mapping, you still have to call your local one-call center and use ground-penetrating radar or electromagnetic locators for subsurface features. The LiDAR also struggles in dense forest corridors where the return signal bounces off the canopy and barely reaches the street below. In those cases, you get a digital surface model, not a digital terrain model. You will need a separate terrestrial laser scan or a drone-based system with longer wavelength LiDAR to fill in the gaps. There is also the cost factor to consider honestly. Vehicle mounting, calibration, software licensing, and processing time add up. For a small municipality with limited capital, renting the system and bringing in a certified operator may be more practical than buying one outright. A single unit typically runs between $150,000 and $250,000 depending on sensor configuration, and annual maintenance contracts run around 10 to 12 percent of the purchase price. If your annual survey volume is under 200 kilometers, the economics favor outsourcing the capture and processing and receiving finished deliverables instead of owning the hardware.
Practical Steps to Get Started
Start by defining the scope clearly. Are you mapping right-of-way boundaries, auditing accessibility compliance, planning transportation improvements, or creating a base model for floodplain analysis? The answer determines which sensor configuration you need and how you process the data afterward. A flooding study requires high-density ground returns and accurate elevation data, so you prioritize the top-mounted LiDAR and spend time on ground classification. An ADA audit needs street-level imagery paired with point clouds so you can measure ramp slopes and sidewalk width, so the camera rig becomes equally important. Before your first field day, verify that your local GNSS base station network is operational and that you can get a fixed RTK solution across your entire study area. Drive the planned routes once without the scanner active to confirm coverage. Most providers supply a demo mode or a simplified software package so you can test the data before committing to a full commercial license. I always recommend doing a small pilot project on a two-block area first. You will catch registration errors, projection mismatches, and vegetation filtering issues before they compound across an entire district. The software interface has a learning curve. Point cloud management tools like CloudCompare, Evaporite, or the proprietary Sheboygan Viewer each handle large datasets differently. CloudCompare is free and highly capable but requires command-line comfort for batch operations. The proprietary viewer is easier to learn but licenses cost extra. I run both: the proprietary software for quick client deliverables and CloudCompare for internal QA and mass classification. This dual approach adds about an hour to each project but catches errors that would otherwise surface weeks later during plan review.
What You Actually Get After Processing
A properly processed Sheboygan Scanner dataset includes a georeferenced LAS or LAZ file, orthophotos stitched from the camera rig, and attribute data tagged to individual features if your configuration includes semantic classification. From those files you can extract contour maps, cross-sections, volumetric calculations, and facade documentation. One project last year used the point cloud to calculate the exact volume of earthwork needed for a curb extension. The difference between the old survey and the scanner-derived model was 340 cubic yards. That translated into a budget adjustment of roughly $18,000, which would have been invisible without the higher resolution data. Data retention and security also deserve attention. Point cloud files are large. A single full-city coverage pass in a medium-sized urban area can generate 50 to 80 gigabytes of raw data. You need adequate storage, backup redundancy, and a clear data management policy. I recommend storing the raw capture files on an offline drive and keeping the processed deliverables on your departmental server with version control. Once you mix raw and processed versions in the same folder, things get messy fast. If you are considering adopting this technology, request a site visit from the vendor before signing any contract. Ask them to process a dataset from your actual municipality using your own control points. That single test will tell you more about real-world accuracy than any brochure or sales presentation. I have seen three projects in the region fail because the vendor's advertised accuracy numbers assumed ideal conditions that do not exist in older urban environments with mixed satellite visibility and reflective building materials.