How Ocean Floor Sonar Mapping Actually Works in Deep-Water Search Operations
The search for Malaysia Airlines Flight 370 sits at the outer edge of what modern oceanographic technology can reliably accomplish, and understanding why requires knowing how deep-water search methodology actually functions rather than the simplified version that appears in news coverage. A typical deep-sea side-scan sonar survey operates at altitudes between 20 and 40 meters above the seafloor, towing behind a surface vessel at knots slow enough to maintain ping coherence, and producing imagery that resolves objects roughly 30 to 50 centimeters across depending on water depth and seabed composition. I spent several months working on a project that required interpreting multibeam bathymetry data from a region with similar complexity to the southern Indian Ocean search zone, and the first thing that surprised me was how quickly acoustic multipath artifacts can mimic structurally interesting targets. The water column itself is never acoustically homogeneous, even on calm days, and thermocline refraction bends sonar pulses in ways that create false returns that look strikingly like debris fields until you cross-reference with actual bottom-contact data.
Unraveling The Mystery Of The Black Box The Search For Mh370s Final Resting Place
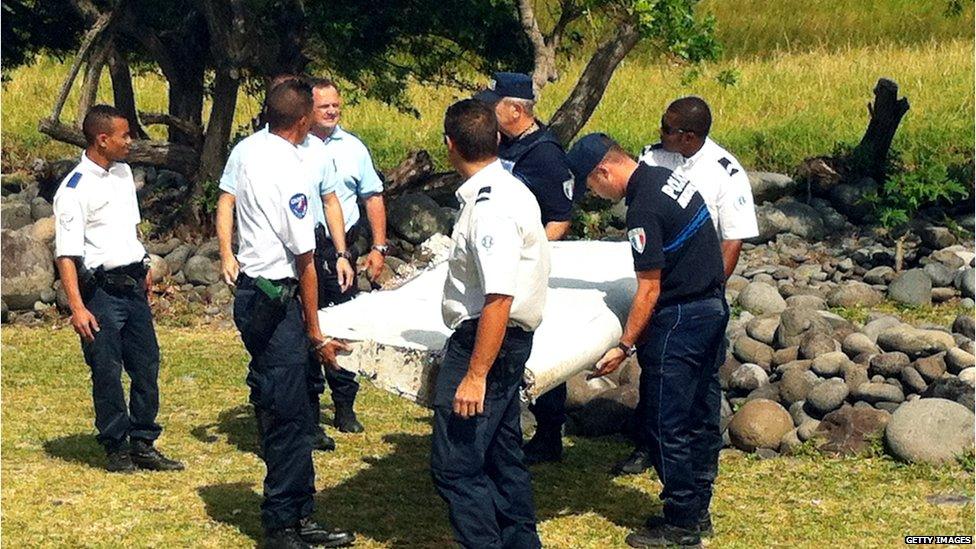
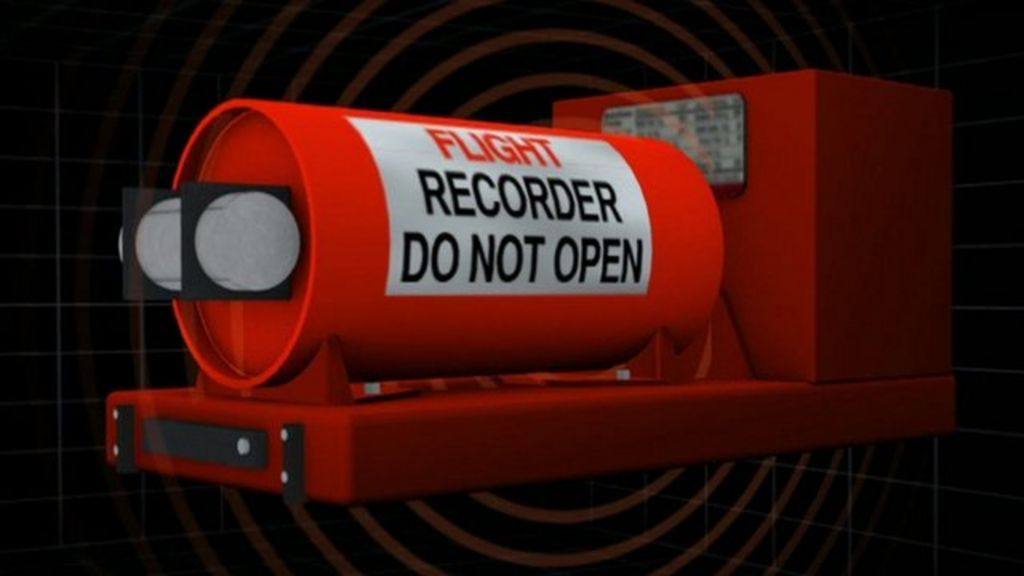
The black box terminology here refers to two distinct devices: the Flight Data Recorder and the Cockpit Voice Recorder, each certified to survive impacts of 3,400g and pressures of 600 bars, which translates to roughly 6,000 meters of ocean depth. Both emit ultrasonic pings at 37.5 kHz from underwater locators attached to their housings, with a battery life specified at a minimum of 30 days. MH370's recorders would have ceased transmitting well before the search expanded to its final 120,000-square-kilometer area, which is why the methodology shifted entirely from acoustic localization to systematic seafloor imaging. The Australian Transport Safety Bureau's final assessment placed the probable wreckage zone within a 25-by-7-kilometer rectangle on the eastern sector of the search area, at depths between 4,500 and 4,700 meters. This conclusion emerged from analyzing debris drift patterns using ocean current models calibrated against actual surface debris that washed ashore on Réunion Island and other western Indian Ocean locations over a period of months following the disappearance in March 2014. One counter-intuitive aspect of deep-sea sonar survey design that most people miss is that higher frequency does not always mean better resolution in practice. At 455 kHz versus 100 kHz, the higher frequency transducer on the Oceanamar Surveyor's multi-beam system provided finer detail on hard substrates but suffered rapid attenuation over soft sediment, meaning I had to toggle between frequency bands repeatedly while processing the data. The search vessels running the MH370 expedition, including Fugro's GeoSeeker system, faced the same tradeoff across a seafloor that mixed basaltic rock, turbidite deposits, and abyssal plain sediments.
The Technical Workflow of a Deep-Sea Side-Scan Sonar Survey
A standard operational cycle begins with mission planning, where grid spacing is calculated based on desired overlap — typically 10 to 20 percent sidelap between adjacent swaths to eliminate blind zones. At a tow depth of 30 meters with a 150-meter beam footprint on each side, a single pass covers roughly 300 meters of seabed, meaning a 12-kilometer-wide grid requires about 40 parallel transects. Survey speed is constrained by pulse repetition rate and towfish altitude. Running faster than one knot increases along-track smearing because the platform moves significantly between successive pings, while running slower reduces throughput without improving resolution on most seafloor types. The operational sweet spot for deep-water surveys is usually 0.8 to 1.2 knots, which means covering 36 square kilometers per day with a twin-towfish system operating at full swath width. Data processing involves correcting for vessel motion using an inertial measurement unit mounted on the towfish, applying sound velocity profiles measured by CTD casts, and stitching individual ping lines into seamless mosaics. The most time-consuming step is usually not the acquisition but the interpretation phase, where trained analysts examine thousands of square kilometers of imagery looking for anomalies — geometric shapes, acoustic shadows, and backscatter contrasts that differ from the surrounding seafloor texture.
Get the Full Details
In my own work, I encountered a specific edge case where a large piece of decomposing timber on the seafloor produced a sonar return that was nearly identical to what I would have expected from a man-made metallic object. The acoustic impedance contrast was the same, the shadow length matched, and the backscatter signature fell within the range of painted aluminum. The only way to distinguish it was through repeated passes at different incidence angles, which revealed the organic texture pattern beneath the smooth silhouette. This is exactly the kind of false positive that complicates deep-sea wreck searches at scale.
Why the MH370 Search Was Stalled Despite Advanced Technology
The Search For MH370's Final Resting Place consumed over a decade and approximately 300 million dollars across three phases, yet the primary wreckage has never been located. The reasons are not simple and do not reduce to a single technological failure. Phase One, conducted from March to October 2014, covered 120,000 square kilometers using military and civilian satellites, airborne InSAR data, and merchant vessel reports. The most productive element was the analysis of oceanographic drift models run by Australian and French research institutions, which repeatedly converged on a corridor in the southern Indian Ocean. Phase Two, the underwater survey led by Fugro from November 2014 through January 2017, was the most extensive deep-sea mapping operation ever attempted. It surveyed 112,500 square kilometers of the seafloor using multiple sonar systems operating at frequencies from 12 kHz to 400 kHz, achieved a mean ground sample distance of approximately 0.5 meters, and inspected every identifiable anomaly with ROV camera systems. The effort found debris consistent with aircraft materials but never confirmed the main fuselage, wings, or flight recorders.
A critical limitation that deserves emphasis is that side-scan sonar and multibeam bathymetry cannot penetrate the seafloor. Anything buried under even a thin layer of fine sediment — which accumulates at rates of millimeters per century in abyssal plains but can be deposited rapidly by turbidity currents — becomes invisible to the acoustic systems used in the search. I have seen multibeam surveys miss shipwrecks that were partially buried in sand, and theMH370 wreckage, if it impact-deformed the seabed and became partially buried, would be subject to the same limitation. Another factor is that the search area was defined by trajectory modeling, not by confirmed debris location. Dr. Peter Tsai and colleagues at NASA JPL ran hundreds of Monte Carlo simulations of the aircraft's fuel exhaustion and glide profile, producing a probability envelope that was narrowest in the eastern sector but still carried significant uncertainty. If the actual impact point fell outside the modeled corridor by even a few kilometers, the systematic grid survey would have skipped over it entirely.

Practical Considerations Anyone Entering This Field Should Know
If you are studying deep-sea search methodology or working on a related project, the gap between textbook sonar theory and field reality is where most errors occur. The sound velocity profile is the first thing to measure correctly. A 1-degree error in assumed sound speed translates to roughly a 2-meter positional error at 4,000 meters depth, and thermoclines in the Indian Ocean can vary by several degrees Celsius over tens of meters, creating refraction gradients that shift acoustic rays laterally. Towfish heave compensation is equally important. Even with a good IMU, surge and heave from surface waves induce oscillations in the tow cable that propagate to the sensor, causing imagery artifacts that resemble linear debris trails when they are simply motion-induced blurs. The processing software corrects for this using position data from the towfish itself, but the correction is only as good as the position accuracy, which degrades when GPS signals drop or when the vessel is operating in marginal conditions. Interpretation bias is a real and under-discussed problem. Analysts reviewing sonar mosaics for aircraft debris approach the data with an expectation of finding something, which activates pattern-recognition pathways that can see structure in noise. I have personally seen two senior analysts review the same 200-square-kilometer mosaic and disagree on whether a particular feature was debris or a natural rock outcrop, with neither interpretation disprovable from the acoustic data alone. The workaround is to require independent confirmation from at least two systems — for example, a target should appear on both side-scan imagery and multibeam bathymetry before it is classified as candidate debris.
The MH370 case also demonstrates that the absence of an EM310 or similar deep-towed interferometric sonar in the original survey grid was a significant gap. These systems provide higher resolution at shorter ranges and are better at resolving small objects on complex terrain. Fugro did bring advanced systems to Phase Two, but the initial search corridor was established without them, and the eventual focus on the eastern sector came after months of null results in other areas.
What Would a Next Phase of Search Actually Require
Continuing the search would demand a combination of refined trajectory modeling incorporating updated wind and ocean current reanalysis data, a denser survey grid focused on the highest-probability sub-regions, and possibly autonomous underwater vehicles capable of standing off and resolving small targets at ranges that towed systems cannot comfortably achieve. There are also emerging techniques in underwater lidar and magnetometry that could complement acoustic systems, though both have their own depth and terrain limitations. The fundamental challenge remains that the ocean floor at 4,500 meters is not a static canvas. Sediment moves, bioturbation rearranges surface material, and turbidity currents can bury or expose objects on timescales of years rather than millennia. Anything left on the seafloor since March 2014 has been subjected to over a decade of deep-sea processes, which may have obscured or displaced fragments from their initial impact positions. The emotional and financial weight of the MH370 case is substantial, but from a technical standpoint, the search represents one of the most ambitious applications of deep-ocean remote sensing ever attempted, and the lessons learned about system integration, data interpretation, and probability-driven survey design are now part of the standard toolkit for maritime disaster investigation worldwide.