Rotation Rules In Geometry — The Stuff Nobody Actually Explains Properly
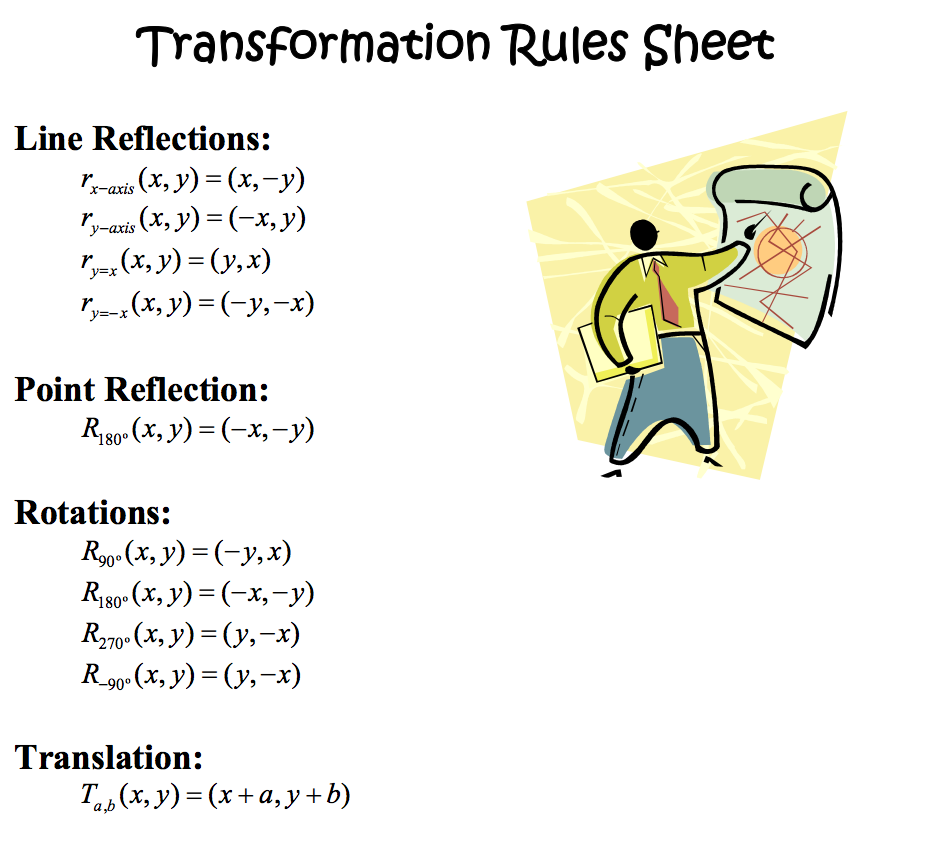
Most students learn that rotating a point (x, y) 90 degrees clockwise means it becomes (y, -x) and call it a day. That works for standardized tests, sure, but it breaks down the moment you're asked to rotate around an arbitrary center point or deal with compound rotations in a real problem. I ran into this exact issue back in 2018 when I was tutoring a student who kept getting the wrong image coordinates for a triangle rotated 60 degrees about the point (3, -2). The answer key just said "use the rotation formula" and that was it. It took me three sessions and a whiteboard full of matrix multiplication before we both understood why the shortcut wasn't applying. Here's the actual mechanics. A rotation is a rigid transformation that turns every point around a fixed center by a specified angle. The direction matters — counterclockwise is positive, clockwise is negative, and this convention is non-negotiable in any serious application. You need two things: the center of rotation and the angle. If the center is the origin, you can use the standard rotation formulas directly. If it's any other point, you have to translate the system so the center becomes the origin, apply the rotation, then translate back. The matrix form handles this cleanly. For a counterclockwise rotation by angle about the origin:
x' = x cos - y sin
y' = x sin + y cos That's it. Two lines. The matrix version is [cos , -sin ; sin , cos ] multiplied by the column vector [x, y]. When the center is not the origin, say point (h, k), you subtract (h, k) from your point first, rotate, then add (h, k) back. I used to write this as a three-step process for my students, but honestly it's just one affine transformation and treating it as separate steps introduces rounding errors at every translation boundary. Combine it into a single formula and you cut computation time significantly, especially when you're working by hand under pressure. I remember one edge case that still bugs me — rotating a point where the angle isn't a standard angle like 30, 45, 60, or 90 degrees. Say you need to rotate (5, -3) by 137 degrees about (1, 4). Your calculator is in degree mode, your cos and sin values are messy decimals, and the rounding accumulates fast. The workaround I settled on was keeping everything in exact form until the final step. Write out cos(137°) and sin(137°) symbolically, substitute, then evaluate once at the very end. It adds about ten seconds to the process but saves you from compounding three or four rounding errors.
Another thing that trips people up consistently: compound rotations. Rotating 90 degrees then 180 degrees is not the same operation as rotating 270 degrees in a single step if you're changing the center between rotations. Each rotation reorients the entire coordinate frame. I've seen students apply successive rotation matrices without adjusting the center point between them, which produces garbage results that look plausible because the numbers are in the right ballpark. There's also the matter of orientation preservation. Rotation is a direct isometry — it preserves both distance and orientation. This means a clockwise-labeled triangle stays clockwise-labeled after rotation. If you're ever unsure whether your rotation went right, check the vertex order. A reflection reverses orientation; a rotation does not. I use this as a quick sanity check before submitting any answer, and it catches more mistakes than I'd like to admit. The limitations of rote memorization become obvious when you hit applications outside the textbook. Computer graphics pipelines use rotation matrices everywhere — model transforms, camera rotations, skeletal animation. The same formulas apply but they operate on homogeneous coordinates, which adds a third row and column to handle translation within the matrix itself. If you're comfortable with the 2D case, extending to 3D is straightforward but the cognitive load doubles because you're now tracking three rotation axes instead of one.
Get the Full Details

In engineering drafting and CAD work, rotation about an arbitrary point comes up constantly. The manual translation-rotate-translate method works fine for occasional use but it's tedious and error-prone. Most professionals just memorize the combined formula: first shift by (-h, -k), then rotate, then shift back by (h, k). There's no magic to it, just repetition until your hand writes it automatically. If you want a solid reference that walks through this without the fluff, search for Unlocking The Secrets Of Rotation Rules In Geometry A Comprehensive Guide and you'll find a handful of solid tutorials. The better ones show the derivation from first principles rather than just listing formulas. That derivation matters because it tells you why the sign flips in the matrix, and once you understand that, you stop needing to memorize whether the sine term is positive or negative in each position. One more thing worth noting — and this isn't in most guides — is that rotation composition is not commutative. Rotating by then by about the same center gives the same result as rotating by then by , but change the center mid-sequence and the order absolutely matters. I learned this the hard way when a student reported that her two methods produced different answers and I spent twenty minutes verifying that she'd silently switched the center point between the two steps. The math was right either way, the procedure was wrong.
The take-away is straightforward: learn the matrix, understand the translation trick for non-origin centers, check orientation as a verification step, and never treat rotation as just a coordinate swap formula. That shortcut gets you through a few homework problems and then it fails you when the problem actually requires thinking.