Getting Real With Kinetic Friction
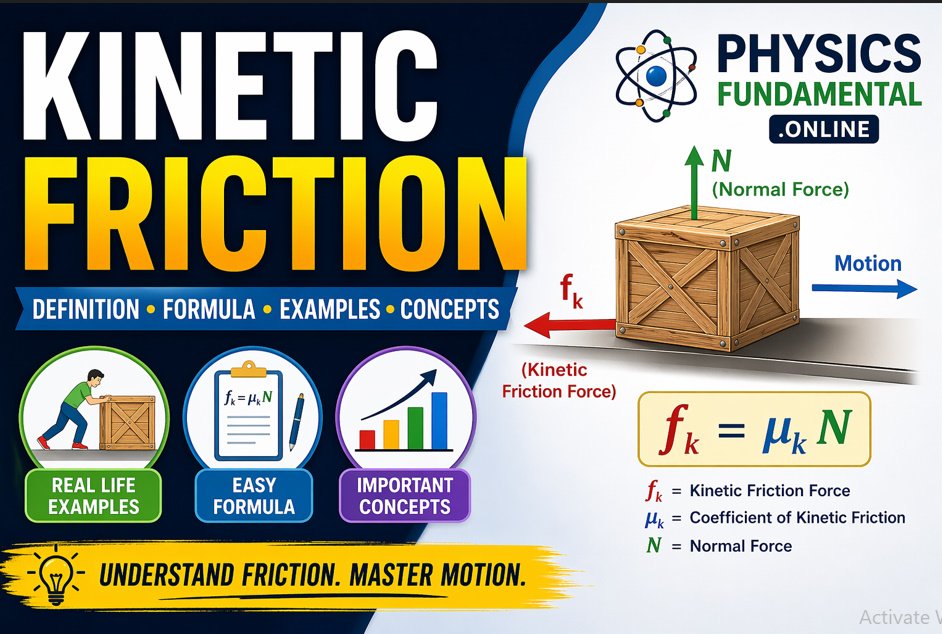
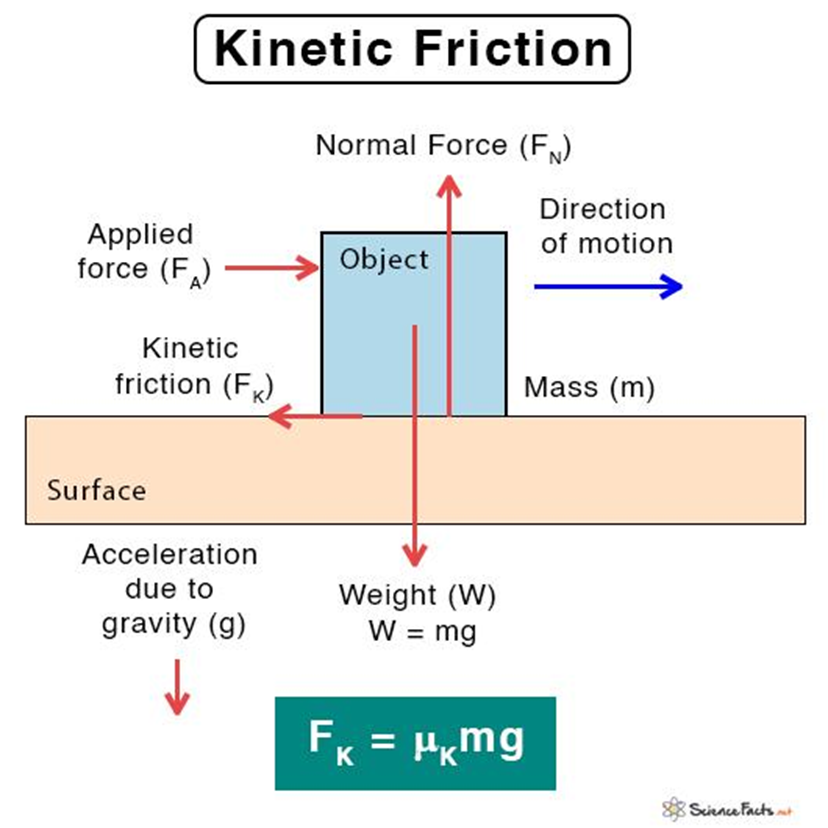
Kinetic friction is one of those topics every physics student encounters, yet most never truly understand it beyond plugging numbers into a basic equation. The standard approach works fine for introductory problems, but real-world applications require a more nuanced view. I spent years working with mechanical systems where friction calculations weren't just academic exercises—they determined whether equipment would operate safely or fail catastrophically. Here's what actually matters when you move past the textbook version. The foundational equation is straightforward: f_k = _k × N. The kinetic friction force equals the coefficient of kinetic friction multiplied by the normal force. That's it. Not complicated. But the real question isn't whether you can memorize that formula—it's whether you actually know what each term represents and when the simple version breaks down. _k, the coefficient of kinetic friction, is dimensionless. It varies between surfaces in contact. Steel on steel might give you around 0.57 for static friction and 0.46 for kinetic. Rubber on concrete could be 0.8 or higher. These aren't fixed constants you look up and trust forever. They change with temperature, surface roughness, contamination, and even the speed at which surfaces move relative to each other. I learned this the hard way on a conveyor system where the calculated friction values assumed dry, clean steel rollers. In practice, the facility had oil mist in the air from nearby machinery. The actual coefficient dropped to roughly 0.12, not the 0.46 we designed around. The rollers slipped constantly. We ended up replacing the entire bearing system and sealing the area rather than trying to adjust the formula. Sometimes the workaround isn't recalculating—it's changing the physical setup entirely.
N, the normal force, is often mistakenly treated as simply mg, the weight of the object. This assumption only holds on a horizontal surface with no other vertical forces acting. Tilt the plane, add a downward push, or suspend part of the weight, and N changes. On an incline at angle , N becomes mg × cos(). Miss that and your friction calculation will be wrong by enough to cause real problems. I once saw a bridge inspection report where a cable tension calculation ignored the normal force reduction on a sloped section. The math looked fine until someone actually tested the system under load. The cables were underspecified by nearly 20 percent. Correcting it required rerouting the cables, not just re-papering the numbers.
When The Standard Formula Isn't Enough
The simple model assumes two important conditions that rarely hold in practice. First, it assumes the coefficient of friction is independent of sliding velocity. Second, it assumes the contact area doesn't matter. Both assumptions are simplifications, and they simplify in ways that sometimes mislead. For most common materials, kinetic friction decreases slightly as velocity increases. This is the Stribeck effect, and it matters when precision matters. In machinery design, the transition from static to kinetic friction—the moment slipping begins—often produces a jump in force. This is called stick-slip, and it's responsible for everything from violin sounds to the squeal of brake pads to the jerky motion of poorly lubricated sliding doors. If you're designing anything that involves controlled sliding motion, ignoring this behavior will result in a mechanism that feels unreliable even though your math checks out on paper. Another common misconception is that kinetic friction always opposes motion. Technically, it opposes relative motion between surfaces. Consider a box sitting on the bed of an accelerating truck. The friction force on the box points forward, in the direction of acceleration, because it's preventing the box from sliding backward relative to the truck bed. The formula still applies—f_k = _k × N—but understanding which direction the force acts requires drawing a free body diagram, not just applying a memorized rule. I see this mistake constantly in engineering entrance exams and in early career engineering work. Students and juniors alike will calculate the magnitude correctly and then point the force in the wrong direction because they didn't identify the relative motion properly.
Get the Full Details
Practical Calculation Steps
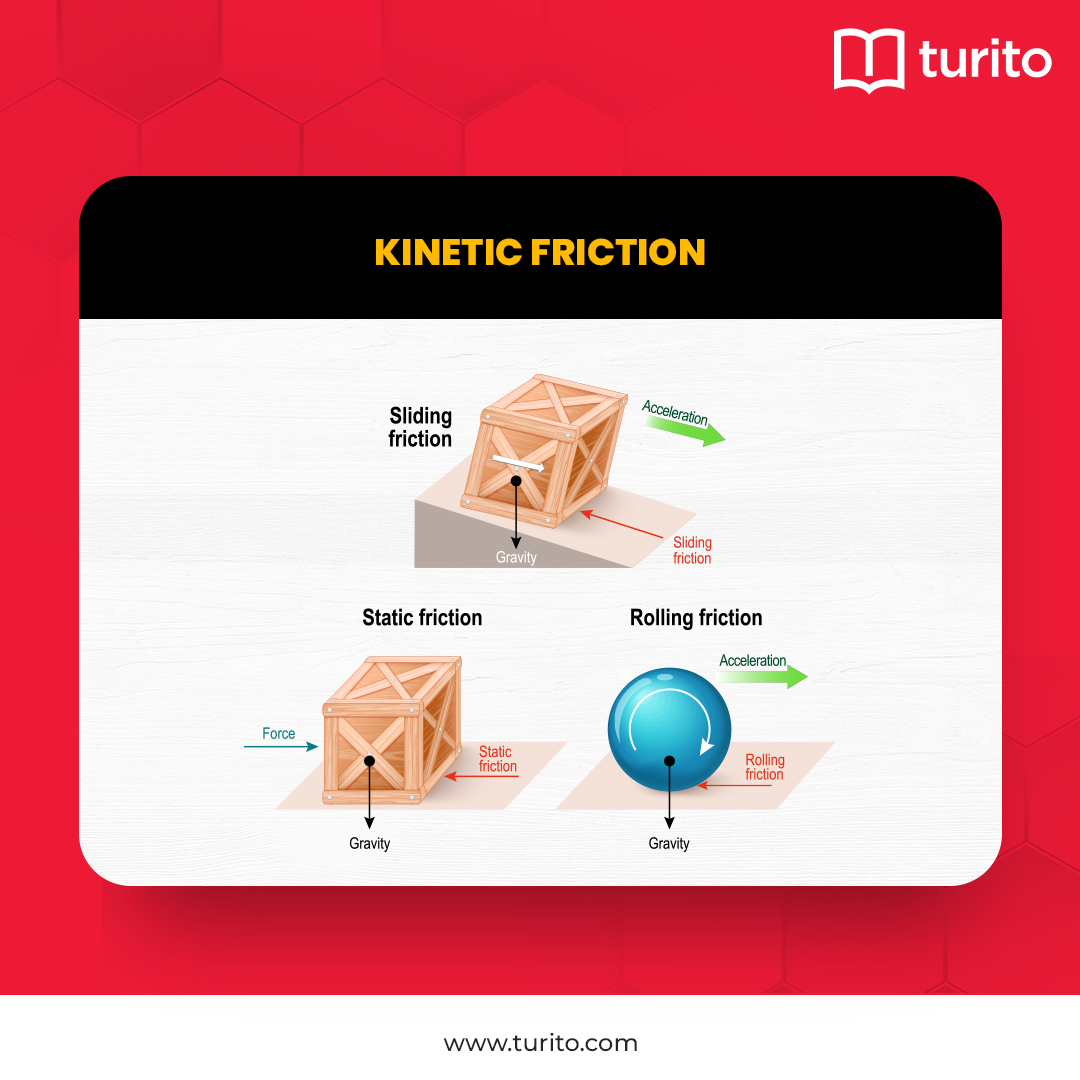
Work through kinetic friction problems systematically. Identify every force acting on the object. Draw a free body diagram. Resolve forces into components parallel and perpendicular to the contact surface. The perpendicular component gives you the normal force. Multiply that by the correct coefficient. The result is your kinetic friction force, directed opposite to the relative velocity between surfaces. When dealing with inclined planes, remember that both the gravitational component and the normal force depend on the angle. The parallel component of gravity pulling the object down the slope is mg × sin(). The normal force is mg × cos(). Kinetic friction opposing the motion is _k × mg × cos(). Whether the object accelerates down the plane depends on comparing these two forces. If mg × sin() exceeds _k × mg × cos(), the object slides and accelerates. If they're equal, it moves at constant velocity. If the friction force is larger, the object wouldn't actually be sliding—meaning you should have been using static friction, not kinetic. This last point is critical. Static and kinetic friction use different coefficients, and the static coefficient is almost always higher. Before applying the kinetic formula, verify that motion is actually occurring or that you've been asked to find the friction during motion. Using _k when the object is stationary gives you the wrong answer every time. I've corrected this error in multiple design reviews where the original analysis assumed continuous sliding but the system was actually operating in a static or stick-slip regime.
Common Pitfalls and Where Calculations Fail
The biggest issue with the kinetic friction formula isn't misapplication of the equation itself. It's using it when the underlying assumptions no longer hold. At very high pressures, the linear relationship between friction force and normal force can break down. Materials deform plastically, contact mechanics change, and the coefficient you measured at low load won't apply at high load. This matters in brake design, clutch systems, and any application involving heavy contact pressures. Temperature is another factor most calculations ignore. Friction generates heat. As surfaces warm up, material properties shift. Polymers soften. Metals expand. Lubricants thin out. A coefficient measured at room temperature can be completely wrong at operating temperature. I worked on a system where the friction coefficient dropped by roughly 30 percent once the bearings reached thermal equilibrium. The initial calculations were based on cold-weather tests. The system performed acceptably during short test runs but degraded noticeably during sustained operation. The fix wasn't a better formula—it was adding thermal shielding and recalibrating the friction expectations for steady-state conditions. Surface contamination is probably the most common practical problem. Dust, moisture, oxidation, and debris all alter friction coefficients unpredictably. If you're relying on a published coefficient value for a real design, assume it could be off by 25 to 50 percent unless you've tested it under your actual operating conditions. Testing is straightforward enough—set up a simple sled test with a force gauge and measure the force required to maintain constant velocity. It takes an afternoon and gives you data that's actually relevant to your situation instead of someone else's.
The formula f_k = _k × N remains useful precisely because it's simple. But simplicity has a cost. When you need accuracy beyond rough estimates, the model stops being sufficient and you need to account for velocity dependence, temperature effects, surface conditions, and contact geometry. There's no single improved formula that covers all these cases. The best approach is understanding the limits of the basic model and knowing when to supplement it with empirical testing or more sophisticated analysis.