The Math That Actually Matters in Real Machines
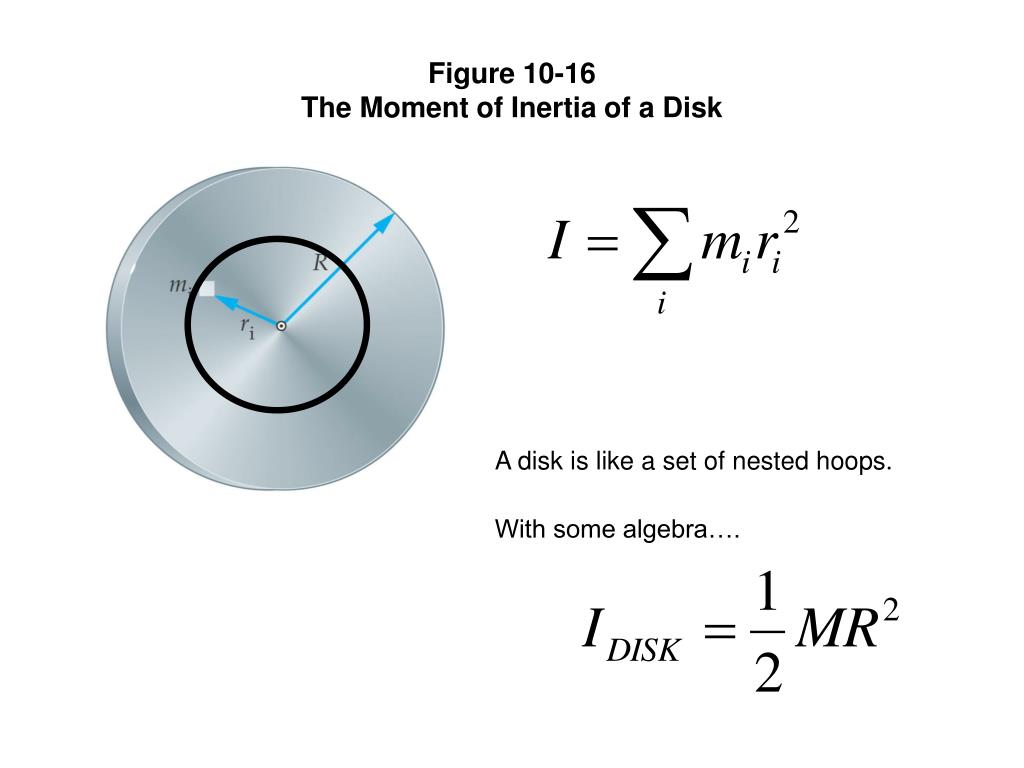
Rotational inertia for a solid disk is I = ½MR². Everyone learns that in first-year physics. What they don't teach you is how much headache it causes when your flywheel design doesn't match the actual mass distribution of the manufactured part. I've spent more years than I care to count seeing engineers treat a disk as a point mass at its rim and wonder why their motor stalls during acceleration cycles. The difference between using M·R² and ½MR² is a factor of two. That's not a rounding error. That's the difference between a system that works and one that burns out its drive in three weeks.Unlocking Reality How Rotational Inertia Of A Disk Shapes Our Mechanical World
The reason this matters extends well beyond textbook problems. Every rotating component in a mechanical system — drive shafts, pulleys, flywheels, turbine rotors, even the spindle on a CNC mill — carries rotational inertia that directly affects how much torque the motor needs, how fast the system can accelerate, and how much energy gets stored for later use. Flywheels are where this shows up clearest. You want a flywheel to store kinetic energy, and that energy is KE = ½I². Since I scales with the square of the radius, moving mass outward has a dramatic effect. A thin rim flywheel stores roughly twice the energy of a solid disk of the same mass and outer radius. That's why actual flywheels for energy storage are often ring-shaped rather than solid.Here's where people go wrong: they calculate inertia based on nominal dimensions and assume uniform density. Real cast or machined disks aren't perfectly uniform. There are keyways, bore offsets, mounting flanges, and material porosity that shift the center of mass slightly and change the effective inertia. I once spent two days debugging why a prototype flywheel consistently underperformed its simulated response by about eight percent. Turns out the manufacturer had a slightly oversized central hub on the casting that added concentrated mass near the axis — which actually *reduces* the effective I compared to a uniform disk. The fix was running a CAD model with the as-built geometry and remeasuring the bore and hub diameters before recalculating.
How to Account for This in Your Design Work
Don't rely on the textbook formula alone. If you're designing anything that accelerates or decelerates a disk regularly, you need to model it as it actually exists. Start with a CAD model. Most modern packages — SolidWorks, Fusion, even FreeCAD — will compute the mass properties automatically. Export the moment of inertia values about the axis of rotation. This accounts for holes, fillets, non-uniform sections, and everything else that makes a real part different from a perfect geometric primitive. Then add any attached components. A disk rarely spins alone. Pulleys bolted to it, keys, set screws, coupling hubs — each contributes its own inertia. The parallel axis theorem handles this: I_total = I_disk + I_attachment + m_attachment × d², where d is the distance from the attachment's center of mass to the main rotation axis.For quick estimates in the field, the solid disk formula works fine if you know you're within ten percent tolerance. But if you're sizing a motor for a production system, that ten percent becomes a thermal problem. Motors that are undersized by even fifteen percent on inertia mismatch will trip on overcurrent during repeated start-stop cycles, and the thermal damage compounds over time. I've replaced more than one burned-up stepper motor because someone used the point-mass approximation instead of the actual calculated inertia.
Counter-Intuitive Things You Should Know
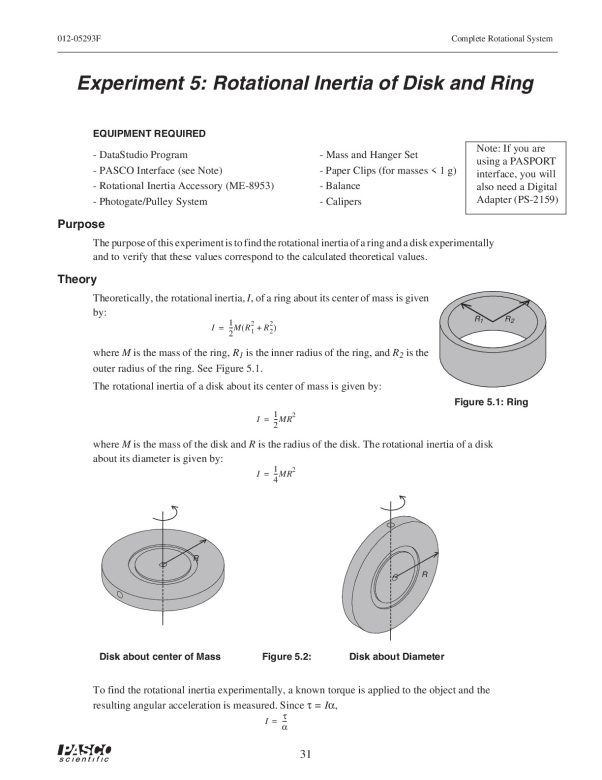
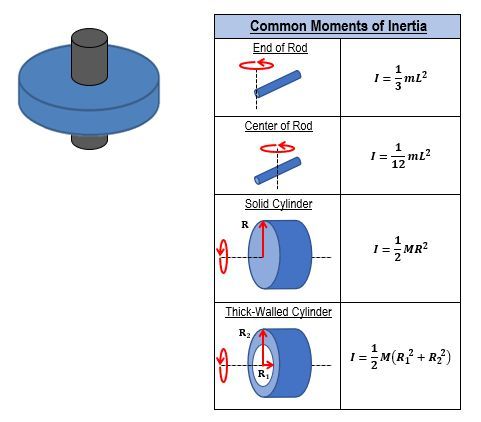
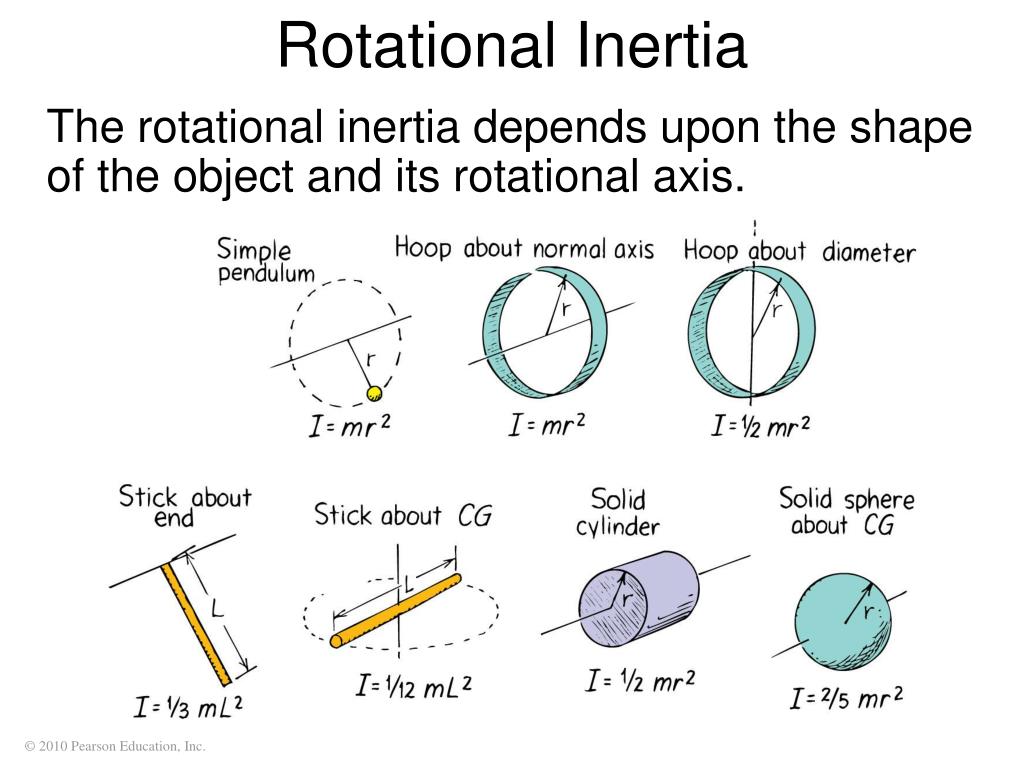
One thing beginners miss is that rotational inertia isn't just about how heavy something is. It's about how that mass is distributed relative to the rotation axis. A light disk with most of its mass at the rim can have higher inertia than a heavier disk with mass concentrated near the center. I've seen this bite people in gear ratio selection — they pick a lighter flywheel thinking it'll respond faster, but because the mass is spread toward the rim, the system actually accelerates slower than expected compared to a slightly heavier disk with a more centralized mass profile. Another thing: the formula I = ½MR² only applies to a uniform solid disk rotating about its central perpendicular axis. If the disk is rotating about a diametral axis (like a coin spinning on a table), the inertia is ¼MR². If it's an annular disk — a flat ring with inner radius R and outer radius R — the inertia is ½M(R² + R²). These are common configurations and using the wrong formula is a frequent source of error.When This Approach Breaks Down
The biggest limitation is that rotational inertia calculations assume rigid bodies. At high rotational speeds, especially above 10,000 RPM for larger disks, centrifugal forces cause the disk to expand slightly. This shifts mass outward and increases the effective inertia during operation. For precision applications like flywheel energy storage systems operating at tens of thousands of RPM, this elastic deformation can change the inertia by several percent. You need finite element analysis to model this properly, not a hand calculation. Another failure mode: disks with significant thickness relative to their radius don't behave like ideal planar bodies. The inertia changes depending on which axis you're considering, and bending modes can couple with rotational dynamics in ways that simple inertia calculations won't predict. If your disk is thicker than about ten percent of its radius, you should run a modal analysis or at minimum consult a reference on thick rotor dynamics.For most shop-floor applications — conveyor drives, standard flywheels, machine tool spindles operating below 5,000 RPM — the basic inertia calculations are sufficient. But if you're pushing into high-speed or high-precision territory, the simplified models stop being reliable and you need to move to simulation tools. No amount of manual calculation will replace a proper FEA run when you're dealing with that kind of regime.
Get the Full Details