The Basics Most People Skip
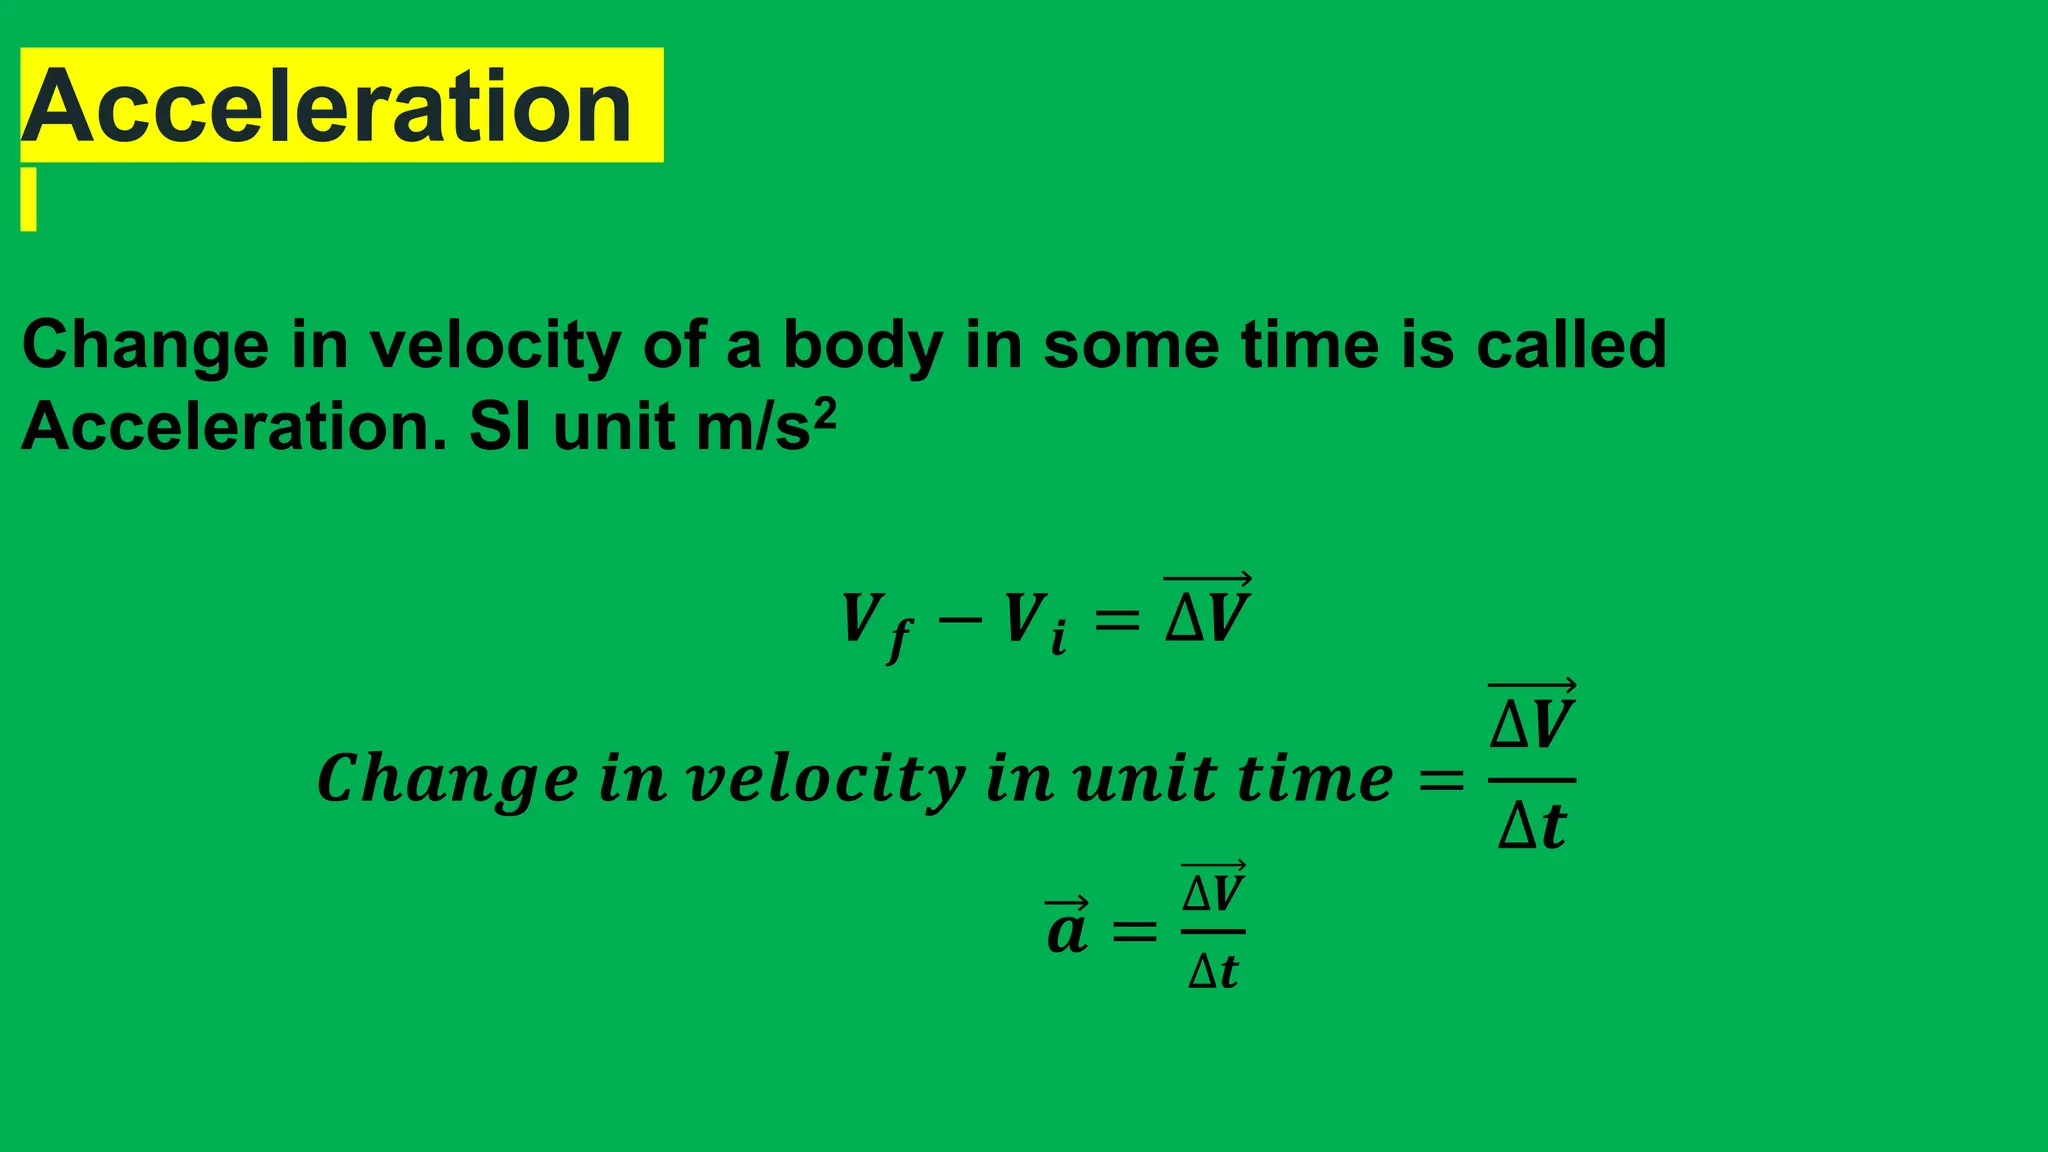
Acceleration is simply the rate of change of velocity over time. The equation is a = (v_f - v_i) / t, where a is acceleration, v_f is final velocity, v_i is initial velocity, and t is the time interval. That's it. It sounds straightforward until you try to apply it to anything that isn't a textbook problem. I spent years watching people mess this up because they confuse speed with velocity. Speed is scalar. Velocity is vector. If a car goes around a circle at a constant 60 mph, it's still accelerating because the direction keeps changing. The speedometer doesn't lie, but the acceleration equation does capture that change. People skip that detail every single time.
Unlock The Secrets Of Motion Understanding The Equation For Acceleration
Here's how the equation actually works in practice. You measure the initial velocity, you measure the final velocity, you measure the time between those two measurements, and you plug the numbers in. The result tells you how many meters per second the velocity changes every second. That's the unit: m/s². But the real world is messier than that. I worked on a project once where we were measuring the deceleration of a heavy machine tool sliding to a stop on an air bearing. The theoretical acceleration equation gave us one answer, but our sensor data kept showing a different value. Turns out the issue was that the air bearing wasn't perfectly level. Even a half-degree tilt added a gravitational component that corrupted the readings. We had to use a laser inclinometer to measure the tilt angle, calculate the gravitational component (g times the cosine of the angle), and subtract it from our raw data before applying the acceleration equation. Without that correction, our results were off by about 8%.
Where Beginners Go Wrong
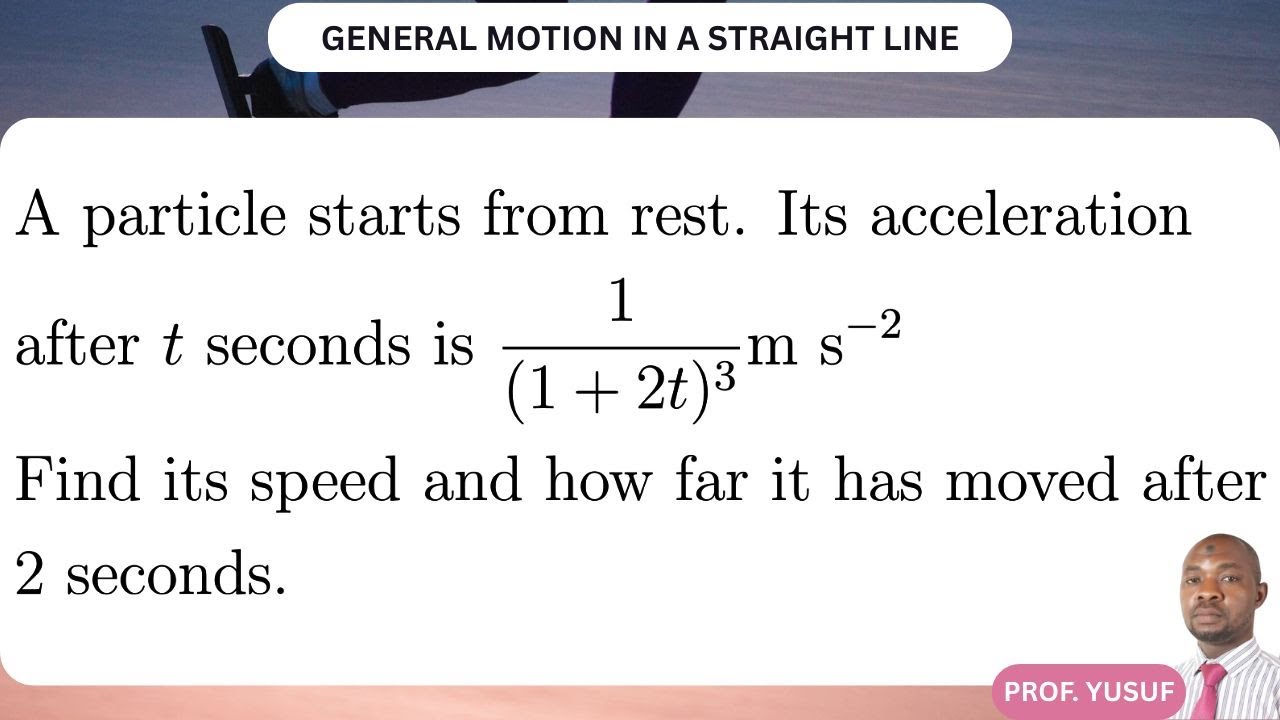
The biggest mistake I see is treating acceleration as always positive. When an object slows down, the acceleration is negative relative to the direction of motion. But whether that's "deceleration" or just negative acceleration depends entirely on your coordinate system. I've seen people argue about this for hours when it's purely a sign convention problem. Another common error is mixing up the units. If your time is in milliseconds but your velocity is in meters per second, you need to convert. A lot of people miss that and end up with answers that are a thousand times too large or too small. Write down your units at every step. It takes three extra seconds and saves you from debugging the wrong thing later. There's also the assumption that acceleration is constant. The basic equation a = (v_f - v_i) / t only gives you average acceleration over the time interval. If the acceleration is changing, you need calculus. The instantaneous acceleration is the derivative of velocity with respect to time, or the second derivative of position. In real engineering work, acceleration is rarely perfectly constant. Motors have ramp times. Friction varies. Air resistance kicks in at higher speeds.
Get the Full Details
Practical Application With Real Data
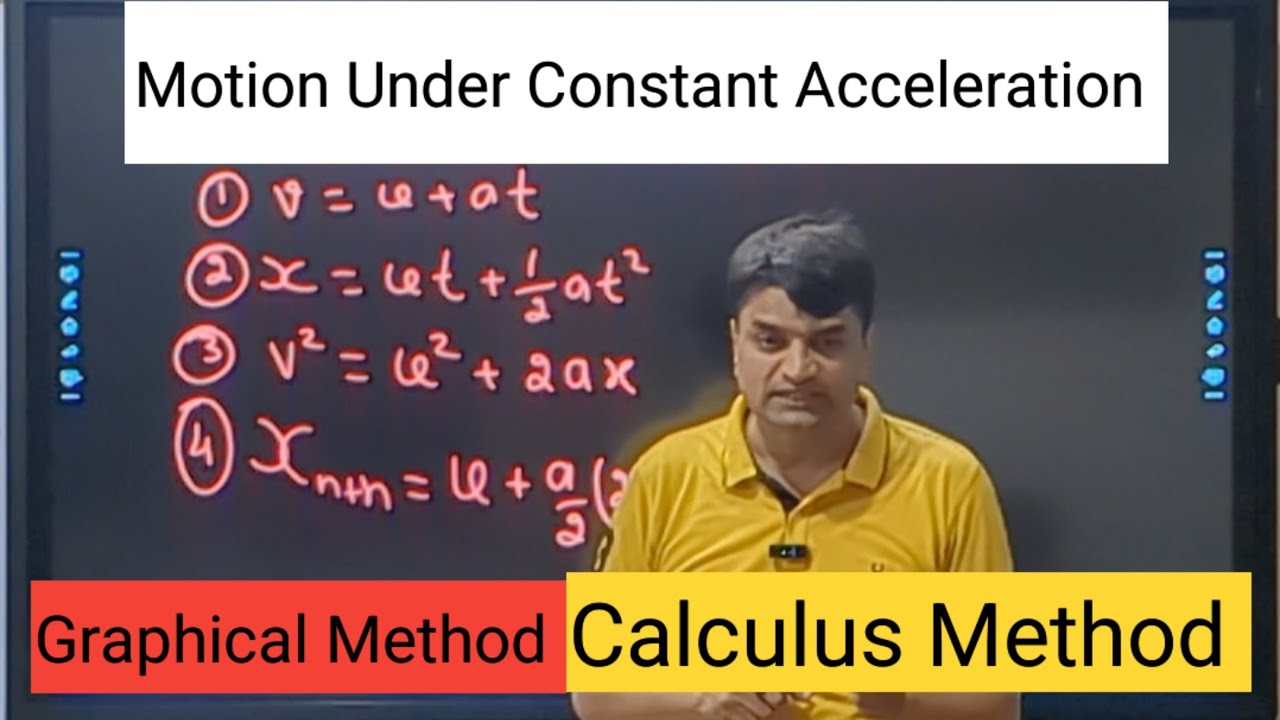
Let's work through a realistic example. Say you're testing a conveyor belt and you want to know how quickly it can accelerate a 50-kilogram package without it slipping. You measure the package moving from rest to 2.5 meters per second in 0.8 seconds. Using the equation, that's (2.5 - 0) / 0.8 = 3.125 m/s². Now you need to check if the friction between the package and the belt can handle that. The maximum static friction force is _s times the normal force, which is _s times mg. For a typical rubber-on-metal interface, _s might be around 0.6. So the maximum acceleration without slipping is _s times g, which is about 5.9 m/s². Your calculated acceleration of 3.125 m/s² is well below that threshold, so the package won't slip. Now here's the edge case nobody talks about. If the belt has any vibration or surface irregularities, the effective friction coefficient drops. I once had a client who got consistent slips even though the math said they should be fine. The problem was microscopic surface waviness on the belt that reduced the effective coefficient of friction by roughly 15%. They solved it by adding a textured rubber coating. Always test under actual operating conditions, not just on paper.
Limitations You Need to Know
The acceleration equation breaks down in several scenarios. First, at speeds approaching the speed of light, you need relativistic mechanics. The classical equation gives wrong answers, and the errors grow significantly above about 10% of light speed. For most practical purposes on Earth, this isn't a concern, but it matters in particle physics and satellite systems. Second, in non-inertial reference frames, you get fictitious forces. If you're calculating acceleration from inside an accelerating car, you need to account for the frame's own acceleration. This is why passengers feel pushed back into their seats. The equation still works, but you have to include those pseudo-forces in your analysis. Skip this and your results will be wrong in any rotating or accelerating system. Third, the equation assumes you can measure velocity and time accurately. In the real world, sensors have noise, latency, and finite resolution. A cheap accelerometer might have a noise floor of 0.01 g, which means small accelerations get lost in the signal. For precision work, you need to filter the data, and filtering introduces its own delays and distortions. I always recommend averaging multiple readings and using a calibration weight to verify your sensor before trusting the numbers.
When the acceleration equation simply won't cut it, you move to numerical integration methods or simulation software. For complex motion with varying forces, tools like MATLAB Simulink or even basic Python with scipy.integrate can model the system far more accurately than plugging numbers into a single equation. It takes more setup time, maybe 30 to 45 minutes for a first model, but it pays off when the physics gets complicated.