Converting Complex Numbers to Polar Form
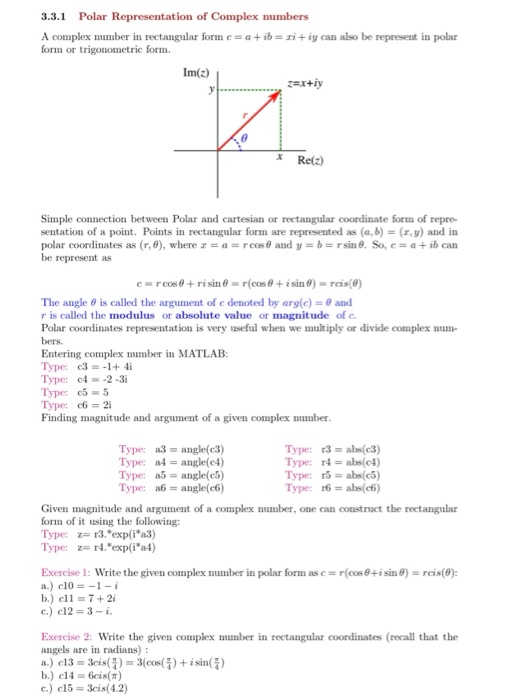
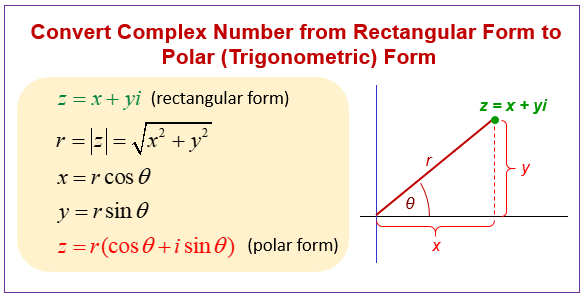
Most people struggle with the same basic mistake when switching from rectangular to polar coordinates. I ran into this repeatedly teaching engineering undergrads. The math itself is straightforward, but getting the angle right tripped up over half my students in their first encounter with complex analysis. Here's what actually works. Polar form expresses a complex number using magnitude and direction instead of horizontal and vertical components. The notation z = r·e^(i) or z = r(cos + i sin ) captures the same point on the complex plane as z = x + yi, just from a different perspective. When you're doing circuit analysis or signal processing, the polar version is usually much cleaner to work with. Multiplication becomes trivial compared to rectangular form where you have to expand binomials every time. The conversion requires two calculations. First, the magnitude is simply the square root of x squared plus y squared. Second, the angle comes from the arctangent of y over x. That sounds simple until you hit the quadrant problem.
Here's where beginners consistently get burned. The standard atan function only returns angles between negative and positive ninety degrees. If your complex number sits in the second or third quadrant, the calculator gives you the wrong answer. I learned this the hard way during a graduate controls course when my Bode plot was completely off by one hundred eighty degrees. Turns out I'd been feeding negative real parts into a plain arctangent without adjusting for the quadrant. The fix is using the atan2 function, which takes both the y and x coordinates as separate arguments and returns the correct angle across all four quadrants. Most programming languages and modern calculators support this. Python's math.atan2(y, x), MATLAB's atan2(y, x), even spreadsheet software like Excel has ATAN2. If you're doing this by hand, you need to apply logic: if x is negative, add or subtract one hundred eighty degrees depending on whether y is positive or negative. Let me walk through a concrete example. Say you have the complex number z = -3 + 4i. The magnitude calculation is straightforward. Negative three squared is nine, four squared is sixteen, sum is twenty-five, square root is five. That part never causes problems.
The angle is where it gets interesting. Raw arctangent of four divided by negative three gives approximately negative fifty-three point one degrees. But that's the angle for positive three minus four i, which lives in the fourth quadrant. Our number is actually in the second quadrant because the real part is negative and the imaginary part is positive. The correct angle is one hundred eighty minus fifty-three point one, which equals one hundred twenty-six point nine degrees or roughly two point two one radians. So the polar representation is five times e to the power of two point two one i. Or written in trigonometric form, five times cosine two point two one plus i sine two point two one. There's another subtlety worth noting. The polar form isn't unique. You can add or subtract any multiple of two pi from the angle and still describe the same complex number. In practice, we usually restrict theta to either negative pi to positive pi or zero to two pi depending on the application. Control systems engineers typically prefer the former range. Signal processing folks often use the latter.
Get the Full Details

I should mention the edge case that catches everyone off guard. What happens when x equals zero? The magnitude is just the absolute value of y, which is fine. But the angle becomes undefined in the mathematical sense because division by zero isn't allowed. In practice, if x is zero and y is positive, the angle is ninety degrees or pi over two. If x is zero and y is negative, the angle is negative ninety degrees or negative pi over two. The atan2 function handles this correctly by design. Conversely, when both x and y equal zero, you have the origin. The magnitude is zero, but the angle is completely meaningless. Any angle you pick describes the same point. This is why you sometimes see polar form exclude the zero case or treat it as a special situation. Another practical consideration is precision. When you're converting back and forth between forms repeatedly, rounding errors accumulate. If your original coordinates are measurements with limited precision, carrying extra significant figures through intermediate steps prevents compounding inaccuracies. I typically keep at least four or five significant digits during conversion and round only at the final step.
The reverse conversion from polar to rectangular uses basic trigonometry. Multiply the magnitude by cosine theta to get the real part and by sine theta to get the imaginary part. This direction never has quadrant issues because you start with the angle already positioned correctly. One common application I encounter frequently isphasor notation in AC circuit analysis. Voltage and current values that oscillate sinusoidally get represented as complex numbers in polar form. Converting impedance values from rectangular to polar lets you apply Ohm's law directly. A voltage phasor divided by an impedance phasor means dividing the magnitudes and subtracting the angles. Much simpler than working through the full complex division in rectangular form. There are tools that automate this. Online converters, spreadsheet functions, programming libraries. But understanding the underlying geometry matters because automated tools can't catch conceptual mistakes. If your converted result has a negative magnitude with a positive angle, something's wrong. Magnitudes in polar form should always be non-negative real numbers. If your angle lands in the wrong quadrant, your conversions will propagate errors through every subsequent calculation.
The polar representation also reveals structure that rectangular form obscures. Looking at z = 5e^(2.21i), you immediately see the magnitude and direction. This decomposition is essential for understanding stability in control theory, frequency response in signal processing, and eigenvalue analysis in linear algebra. The rectangular form z = -3 + 4i hides this geometric intuition behind arithmetic. For anyone learning this material, practice with boundary cases. Convert numbers on the axes. Convert numbers with equal real and imaginary components. Convert the zero case. These exercises expose the quirks that general position examples don't reveal. The conversion process itself takes about two minutes once you know the procedure. The real time investment is building the intuition for why the angle shifts between quadrants and when special handling applies.