Kinetic Energy Explained From First Principles
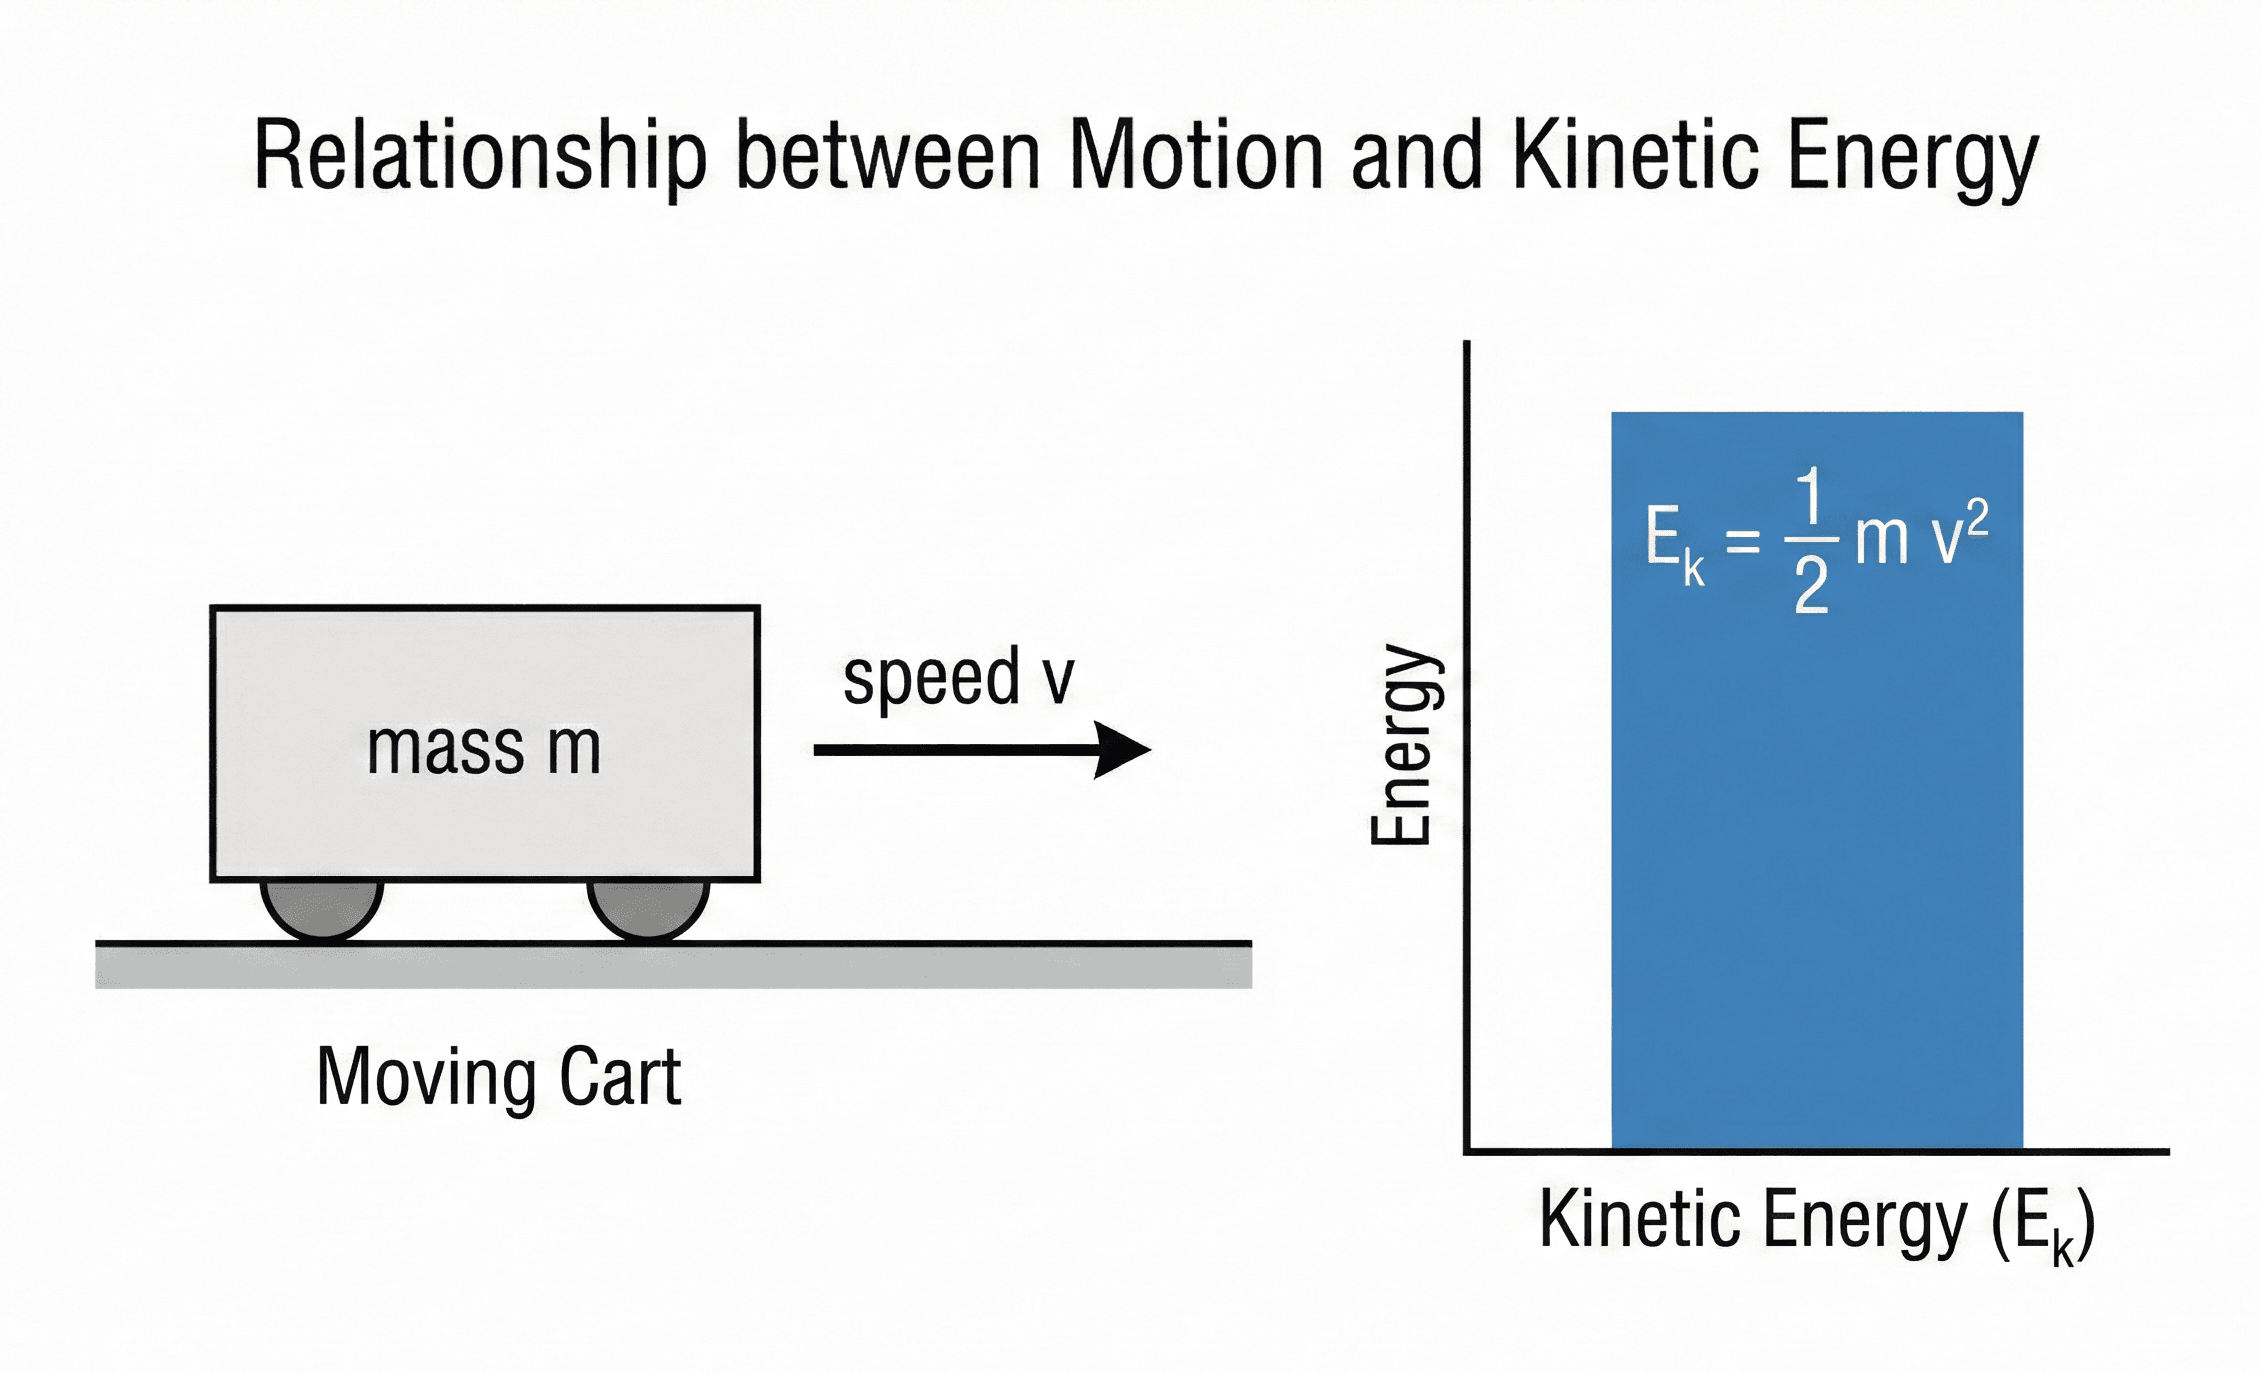
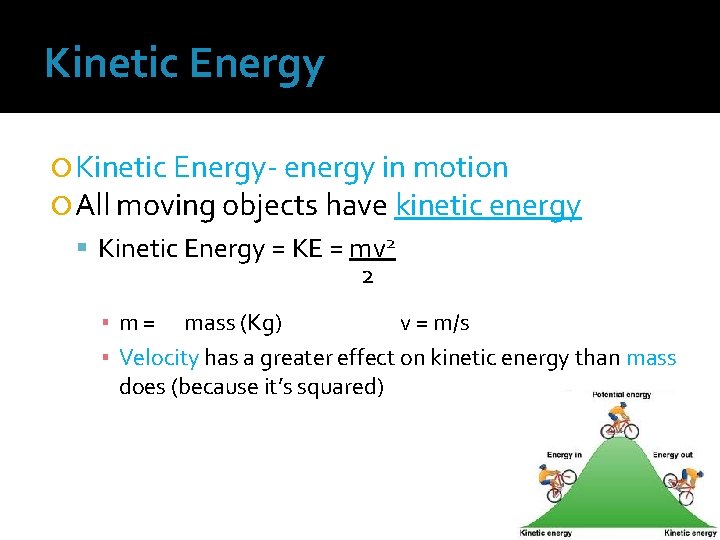
Kinetic energy is the energy an object possesses because it is moving. The formula is straightforward: KE = ½mv². Mass in kilograms, velocity in meters per second, result in joules. That is all there is to the basic equation. But anyone who has actually worked with moving parts knows the equation is where things get interesting, not where they get simple. Here is what most people miss about kinetic energy. Velocity is squared. That means doubling your speed quadruples your energy. Tripling speed increases it nine times. This is not a subtle effect. It is why a car going 60 mph does not just take twice as long to stop as one going 30 mph. It takes four times the braking distance, all else being equal. Understanding this relationship changes how you approach almost any problem involving moving objects. I once spent three days troubleshooting a simulation where energy was not conserving between frames. The math checked out on paper. The code looked clean. The issue was that I was calculating velocity in kilometers per hour while the rest of the system expected meters per second. The v² term amplified the unit mismatch by a factor of over a million. Converting properly fixed it immediately. This kind of thing happens all the time in physics simulations and robotics projects. Always verify your units before you trust your results.
Translational kinetic energy applies to objects moving in a straight line. Rotational kinetic energy applies to spinning objects and uses a different but related formula: KE = ½I², where I is the moment of inertia and is angular velocity. The same squaring principle applies to angular velocity, which is often overlooked when people first work with rotating systems. In practice, most real objects have both types of kinetic energy simultaneously. A rolling wheel carries translational energy from moving forward and rotational energy from spinning. A thrown football does the same thing. When you are calculating total kinetic energy for any practical system, you need to account for both. Missing one component can throw your entire calculation off significantly. Work-energy theorem is another concept worth understanding practically. The work done on an object equals the change in its kinetic energy. This is more useful than the basic formula in many engineering situations because it lets you work backward from desired energy changes to figure out what forces and distances you need. Braking systems, spring mechanisms, and impact absorbers all rely on this principle directly.
One counter-intuitive point: kinetic energy is frame-dependent. An object has different kinetic energy depending on who is measuring it. A passenger on a train considers their coffee cup stationary. Someone on the platform sees that same cup moving at the train's speed. Both measurements are correct. This matters enormously when analyzing collisions or energy transfers between reference frames, and it is a common source of confusion in dynamics problems. There are scenarios where the classical kinetic energy formula breaks down entirely. At velocities approaching the speed of light, you need relativistic kinetic energy: KE = ( - 1)mc², where is the Lorentz factor. For most engineering work this is irrelevant, but particle accelerators, GPS satellite calculations, and certain astrophysics problems require it. Using the classical formula at high velocities produces dramatically wrong answers, and the error grows exponentially as velocity increases. Another practical limitation: kinetic energy calculations assume rigid bodies in introductory treatments. Real materials deform. Some kinetic energy converts to heat, sound, and permanent deformation during impacts. The coefficient of restitution quantifies this energy loss in collisions. A superball and a lump of clay at the same speed and mass carry identical kinetic energy, but their collision behaviors are completely different because of how much energy they absorb versus conserve.
Get the Full Details
If you are building a project involving moving parts, here is what actually works. Start with the energy budget. Calculate total kinetic energy at your maximum operating speed. Then determine how that energy needs to be dissipated or controlled. This approach catches problems that force-based analysis misses, especially in systems with variable speeds or complex motion profiles. The formula for kinetic energy will always give you the right number for the right conditions. The trick is knowing which conditions apply and catching the edge cases where something simple-looking hides a real complication.