What Actually Happens When Two Objects Slam Together
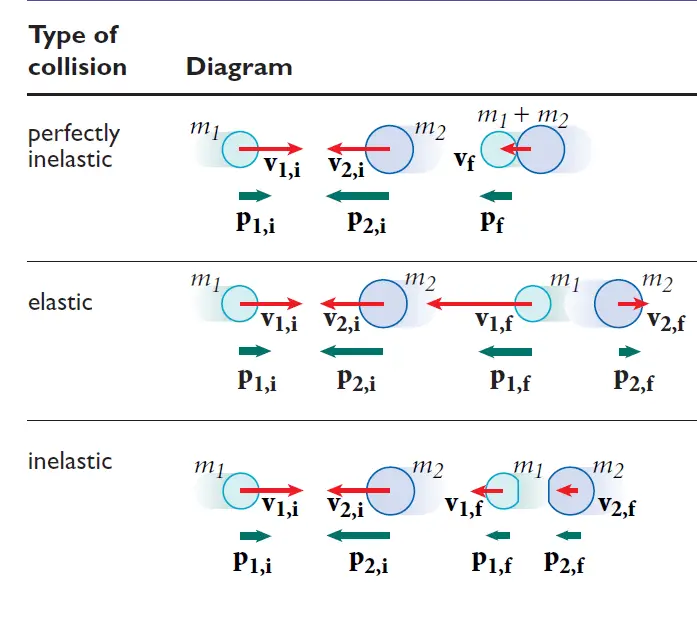
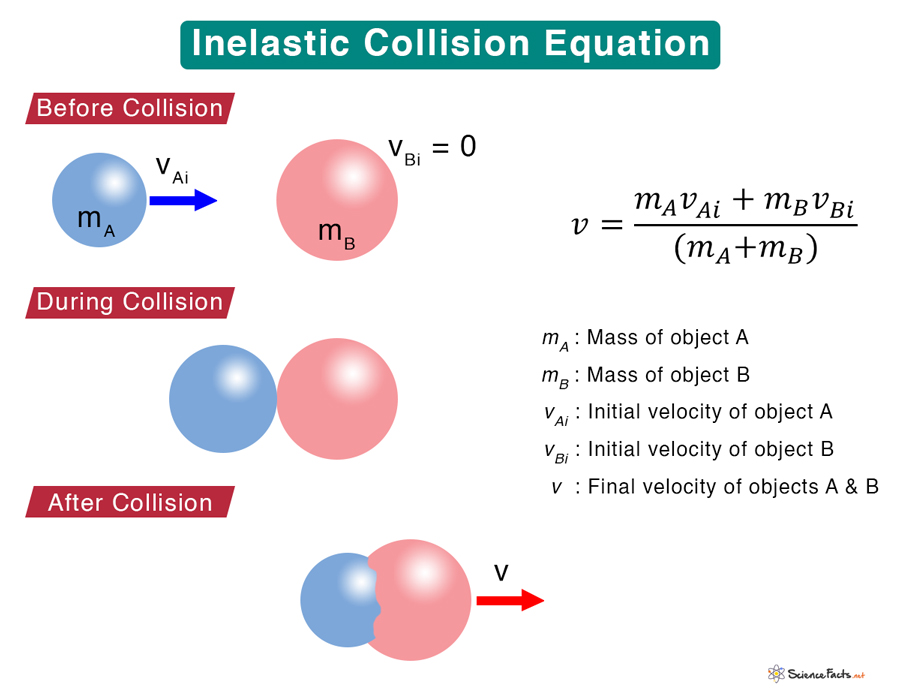
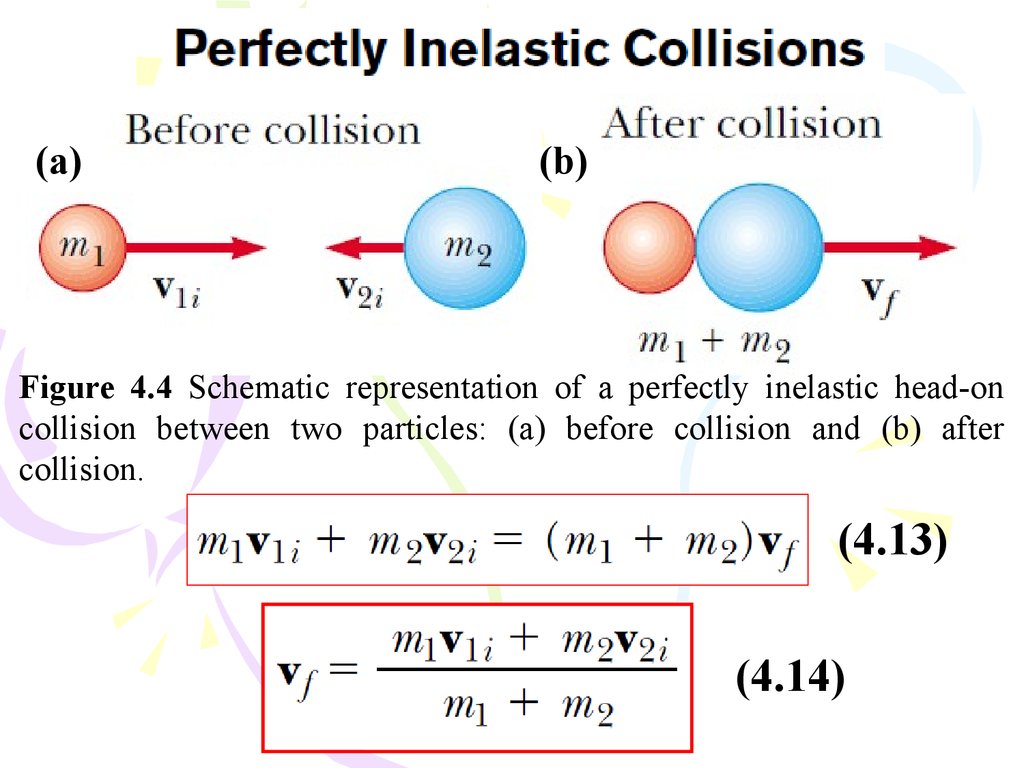
Inelastic collisions are where momentum stays intact but kinetic energy gets eaten by deformation, heat, or sound. That's the textbook definition anyway. The practical side is messier. When I'm working with these formulas in simulation work, the real challenge isn't plugging numbers into an equation—it's knowing which quantities are actually conserved and which ones just vanish quietly. Start with momentum conservation because that's the anchor. The total momentum before impact equals the total momentum after impact, period. Written out: m1v1_initial + m2v2_initial = (m1 + m2)v_final. That v_final is shared velocity—the two objects stick together and move as one mass afterward. This only applies to perfectly inelastic collisions where the objects actually coalesce. Partially inelastic collisions use a coefficient of restitution variable instead, which changes the math considerably. Kinetic energy is where things get interesting. Before collision: KE_initial = ½m1v1² + ½m2v2². After collision: KE_final = ½(m1+m2)v_final². The difference between those two values is the energy lost to deformation and other non-recoverable forms. In a perfectly inelastic collision, energy loss is maximized for the given masses and velocities. That doesn't mean all kinetic energy disappears—it means the maximum possible amount is converted out of the kinetic form while still obeying momentum conservation.
I remember working on a vehicle crash simulation project a few years back where a compact car striking a stationary truck at moderate speed produced results that didn't match my calculations. The formula predicted a certain final velocity and energy loss, but the simulation was showing something different. The problem turned out to be that the simulation included rotational dynamics and structural buckling that the basic two-object formula completely ignores. The workaround was applying the collision formula to get the baseline translational results first, then layering in rotational impulse equations and a separate energy dissipation model for structural deformation. You can't just solve the basic formula and call it done when real-world objects bend, twist, or fragment.
Deriving the Final Velocity Equation
The algebra is straightforward but people skip steps and make arithmetic errors. Take the momentum equation and solve for v_final directly. Since both masses share the same velocity after impact, you factor it out: v_final = (m1v1_initial + m2v2_initial) / (m1 + m2). That's it. One division away from your answer. The trap most people fall into is forgetting that velocity is a vector quantity. Direction matters. If two objects are moving toward each other, one velocity is negative relative to the other. Set a positive direction first—let's say right is positive—and stick with it throughout the entire problem. For energy loss calculations, subtract the final kinetic energy from the initial kinetic energy. The result should always be positive if you've done everything right, representing energy removed from the kinetic system. A negative energy loss value means you made an error somewhere, usually in the velocity sign convention or the final velocity calculation itself.
Get the Full Details
When the Formula Breaks Down
The standard inelastic collision formula assumes isolated systems with no external forces during the collision event. In reality, friction, gravity, and surface interactions often play a role. If the collision happens on a rough surface during the brief impact window, the external impulse from friction is usually small enough to ignore since collisions last milliseconds. But if you're analyzing post-collision sliding behavior, friction becomes the dominant factor and the basic formula alone won't get you there. Another common failure point: the formula treats objects as point masses. Real objects have rotation, internal vibration modes, and varying material properties. A rubber ball and a steel ball with identical masses and velocities will produce different energy losses on impact due to material damping characteristics. The basic formula can't account for that. You'd need experimentally determined coefficients of restitution for each material pairing, and even then, that coefficient varies with impact speed and temperature. If you need higher fidelity than the basic formula provides, consider using a coefficient of restitution approach where e = (v2_final - v1_final) / (v1_initial - v2_initial). For perfectly inelastic collisions, e equals zero. For elastic collisions, e equals one. Real-world objects fall somewhere between. This approach gives you two solvable equations—momentum conservation and the restitution definition—which lets you solve for both final velocities independently rather than assuming they stick together.
The numbers don't lie, but they also don't tell the whole story. The formula works within its assumptions. Beyond that, you're doing engineering, not physics homework.