
Measuring Frequency Shifts Without Going insane
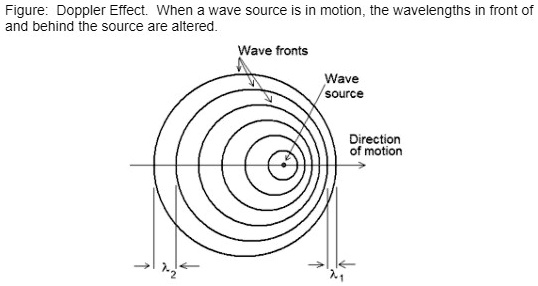
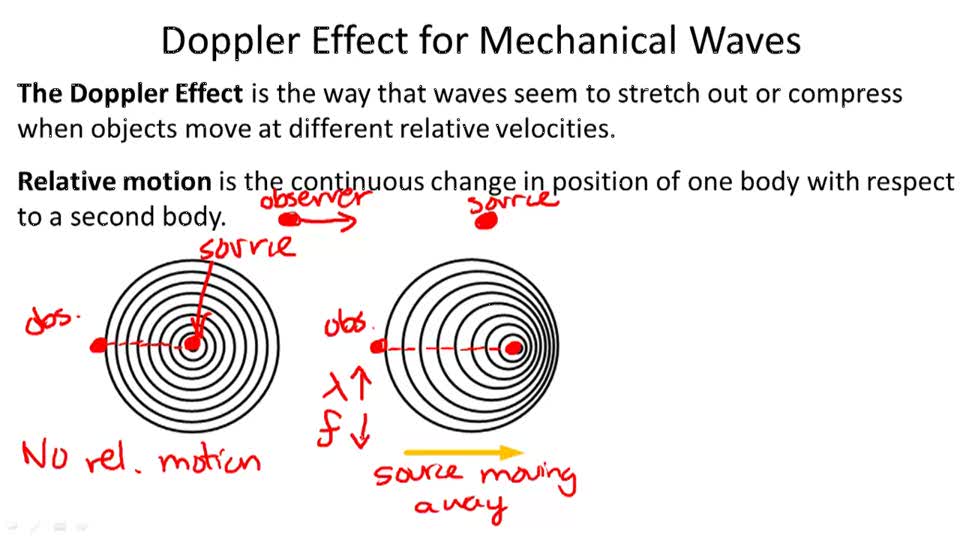
I spent three weeks trying to get accurate velocity data from a moving vehicle using a simple ultrasonic transceiver setup, and the readings were all over the place. Turned out I was measuring the Doppler shift correctly, but I kept forgetting that the angle of approach matters. When the target isn't moving directly toward or away from your sensor, you get a cosine error that skews everything. Once I started accounting for that, the data stopped looking like nonsense and started looking like physics. What you are dealing with is straightforward enough to state in one sentence, but applying it in practice is where people run into trouble. A wave source moving relative to an observer changes the perceived frequency. If the source is approaching, the waves get compressed and the frequency goes up. If it is receding, the waves stretch out and the frequency drops. That is the core of it. Nothing magical. The formula most people reach for is f_observed = f_source × (v ± v_observer) / (v v_source). The signs depend on direction. Approaching source means you subtract in the denominator, which raises the result. Receding means you add, which lowers it. It is easy to remember if you just think about compression and stretching. But you need to know which velocity belongs in which part of the fraction, and mixing those up is the most common mistake I see.
Why It Matters in Real Work
Doppler shift is not just a textbook problem. It shows up in radar guns, medical ultrasound, weather forecasting, and even astronomy. Astronomers use redshift and blueshift to tell whether a star or galaxy is moving toward or away from us. Police radar uses it to measure your speed. Echocardiography uses it to measure blood flow velocity. Each of these applications has its own quirks and failure modes. One thing beginners consistently miss is that the Doppler effect only applies along the line of sight. Motion perpendicular to the observer produces no shift at all. I once had a colleague who was trying to measure the rotational speed of a wheel by mounting a sensor off to the side. The readings were useless because the contact points on the wheel were moving transversely most of the time. He needed a different approach entirely, which ended up being a reflective tape mark and a timing gate. Much simpler once he stopped fighting the geometry.
Setting Up a Practical Measurement
If you want to build something that measures Doppler shift, the basic setup is a transmitter, a receiver, and a way to compare frequencies. A continuous wave radar module like the PB01 or the SR-04 will not give you clean Doppler data on its own. You need something that can output a beat frequency or at least let you analyze the phase change over time. A microcontroller with an ADC running at a decent sample rate, maybe 100 kHz or higher depending on your target speed, will work. Here is a quick rundown of steps that actually work: 1. Pick your carrier frequency. Lower frequencies like 2.4 GHz are easier to work with but give less resolution on speed. Higher frequencies like 24 GHz or 77 GHz give better velocity resolution but require more expensive components.
Get the Full Details

2. Generate a continuous wave and split it into a reference path and a transmitted path. 3. Receive the reflected signal and mix it with the reference signal. The mixer outputs the difference frequency, which is your Doppler shift. 4. Filter and amplify the mixed signal. Then feed it into your ADC or frequency counter.
5. Convert the measured frequency back to velocity using v = (f_d × c) / (2 × f_source × cos(theta)), where f_d is the Doppler shift, c is the speed of light, f_source is your carrier frequency, and theta is the angle between the sensor's line of sight and the target's velocity vector. The factor of 2 in there is because the wave travels to the target and back. Forward path gets shifted once, return path gets shifted again. That doubles the effect compared to a one-way measurement.
The Problem I Ran Into
About a year ago I was building a Doppler-based flow meter for a liquid system. The theory was solid. The issue was noise. Water systems are full of echoes, multipath reflections, and structural vibrations that mask the actual Doppler signal. My first prototype produced readings that varied by plus or minus 30 percent even when the flow was perfectly steady. That is not acceptable for any kind of measurement work. The fix came down to three changes. First, I moved the transducers closer to the pipe wall and used a couplant gel to eliminate the air gap. Air interfaces reflect most of the ultrasonic energy and create garbage signals. Second, I switched from a simple frequency counter to a Goertzel algorithm running on the microcontroller. That gave me much better frequency resolution at the specific tone I was looking for without having to process the entire spectrum. Third, I added a bandpass filter centered on the expected Doppler frequency before the ADC stage. That cut out a lot of the broadband noise from pump vibrations and electrical interference. After those changes, the accuracy dropped to within about 3 percent of a calibrated reference. Not perfect, but good enough for the application. The remaining error was mostly from the angle of the transducers and slight variations in the speed of sound due to temperature fluctuations in the fluid.
Common Pitfalls That Wreck Your Readings
Sensor placement is the biggest source of error. If your transmitter and receiver are not properly aligned, or if the target is not in the main lobe of the beam, you will pick up reflections from unintended surfaces. Those spurious signals can shift your measured frequency in unpredictable directions. Always check your signal strength and signal-to-noise ratio before trusting a measurement. Another issue is multipath interference. In an enclosed space, the wave bounces off walls, floors, and objects before reaching your receiver. The Doppler shifts from those multiple paths overlap and interfere with each other. This is particularly bad in indoor environments with metal surfaces. If you are working in a lab or workshop with a lot of reflective material around, you may need to add absorptive shielding or move the setup to a more controlled space. Temperature affects the speed of the wave in the medium. For ultrasonic measurements in air, a 10 degree Celsius change shifts the speed of sound by roughly 6 meters per second. That means your calculated velocity will drift if the temperature is not stable or compensated for. I usually just slap a temperature sensor near the transducer and apply a correction factor in software. It takes about two lines of code and eliminates a significant source of error.
When Doppler Measurements Fail Completely
There are scenarios where this approach just does not work. If the target is moving slower than the wavelength of your carrier divided by twice the measurement time, the Doppler shift becomes smaller than your frequency resolution. You simply cannot detect it. For example, with a 40 kHz ultrasonic sensor and a sampling rate of 100 kHz, your frequency resolution is about 100 Hz. A target moving at 1 cm per second might only produce a shift of 20 Hz, which is below your detection threshold. In those cases you need a lower frequency carrier or a longer observation window. Similarly, if the target is too small or has too low a reflectivity, the returned signal will be too weak. Radar cross section matters. A smooth sphere reflects differently than a rough corner reflector. I learned this the hard way when trying to detect small plastic parts on a conveyor belt. The ultrasonic signal bounced right past them. Switching to a ground-penetrating radar module with a wider bandwidth fixed the problem almost immediately. Another hard limit is angular ambiguity. If your target is moving at an angle, you measure only the radial component. A car passing directly in front of your sensor at 60 degrees off broadside will register at about half its actual speed. This is not a bug in the physics, it is a fundamental limitation of the technique. You either need to constrain your measurement geometry or accept the cosine error and correct for it if you know the angle.
Practical Applications Worth Knowing
LIDAR and radar speed detection are the most common uses. Police radar guns operate in the K band or Ka band, typically around 24 GHz. They transmit a continuous wave and measure the beat frequency from the reflection. Accuracy is usually within 1 or 2 mph for targets moving above 20 mph. Below that, the Doppler shift gets very small and noise dominates. Astronomical redshift is another major application. Distant galaxies show spectral lines shifted toward the red end of the spectrum because they are moving away from us. The shift is proportional to their recessional velocity, and for sufficiently distant objects, this is how we measure the expansion rate of the universe. Hubble's law relates redshift to distance. The numbers get complicated at cosmological scales where relativistic effects matter, but the basic principle is the same. Medical Doppler ultrasound measures blood flow by detecting frequency shifts in reflected ultrasound waves. The transducer sends pulses at around 2 to 10 MHz and analyzes the returning echoes. Blood cells act as moving reflectors. The frequency shift is proportional to blood velocity. This is noninvasive and widely used for checking arterial stenosis, valve function, and fetal heart monitoring. The main challenge is distinguishing the blood flow signal from tissue clutter, which is why modern systems use pulse wave Doppler and color flow mapping to separate the signals.
Alternatives When Doppler Is Not the Right Tool
If your application involves very slow movement or stationary targets where Doppler provides no useful signal, consider using time-of-flight measurement instead. Laser triangulation, ultrasonic ranging, or capacitive sensing can all measure position and displacement without relying on frequency shift. These methods have their own trade-offs but they fill the gap where Doppler simply cannot operate. For high-precision velocity measurements in controlled environments, a laser Doppler vibrometer is the gold standard. It uses interferometry to measure vibration and velocity with sub-micron resolution. The downside is cost. These instruments typically run several thousand dollars and require a stable optical setup. But if you need accuracy in the micrometer per second range, nothing else comes close. Acoustic flow meters based on transit time difference rather than Doppler shift are another option for liquid flow measurement. They measure the difference in travel time between upstream and downstream acoustic pulses. This approach is less sensitive to flow profile disturbances and tends to be more accurate in turbulent conditions. I switched one of my projects from Doppler to transit time and saw the repeatability improve from about 5 percent to under 1 percent.
Resources for Building Your Own Setup
If you want to experiment with Doppler measurements on a budget, the Texas Instruments IWR6843AOP is a good starting point. It is a 60 GHz millimeter-wave radar sensor with an integrated microcontroller and processing capabilities. The price is around 30 to 50 dollars depending on quantity. There are plenty of community projects and application notes available online. Texas Instruments also provides a radar studio software suite for visualizing raw radar data. For ultrasonic applications, the MAXBotix LV-MaxSonar series gives you analog or serial output with built-in signal processing. It is not a raw Doppler sensor, but it demonstrates the principle well and can be used for basic velocity estimation if you take derivative measurements over time. Cost is about 15 dollars per unit. Open source firmware projects like the one on GitHub under the name DopplerRadar provide reference implementations for ESP32-based systems. They use the 24 GHz ISM band and demonstrate real-time speed detection with an OLED display. The code is functional but not production-grade. You will need to adapt it for your specific use case.
Bottom Line
The Doppler effect is one of those physics principles that is simple to understand and finicky to implement. The equations are clean. The real world is not. Angle errors, multipath reflections, temperature drift, and signal-to-noise limitations will all test your setup at some point. The key is understanding where each failure mode comes from and having a plan to mitigate it before you start building. Measure carefully, verify your assumptions about geometry and environment, and do not trust a single reading. Average multiple samples, check your signal quality metrics, and validate against a known reference when possible. The difference between a working prototype and a broken one is usually a detail that someone overlooked because the theory looked simple on paper.


