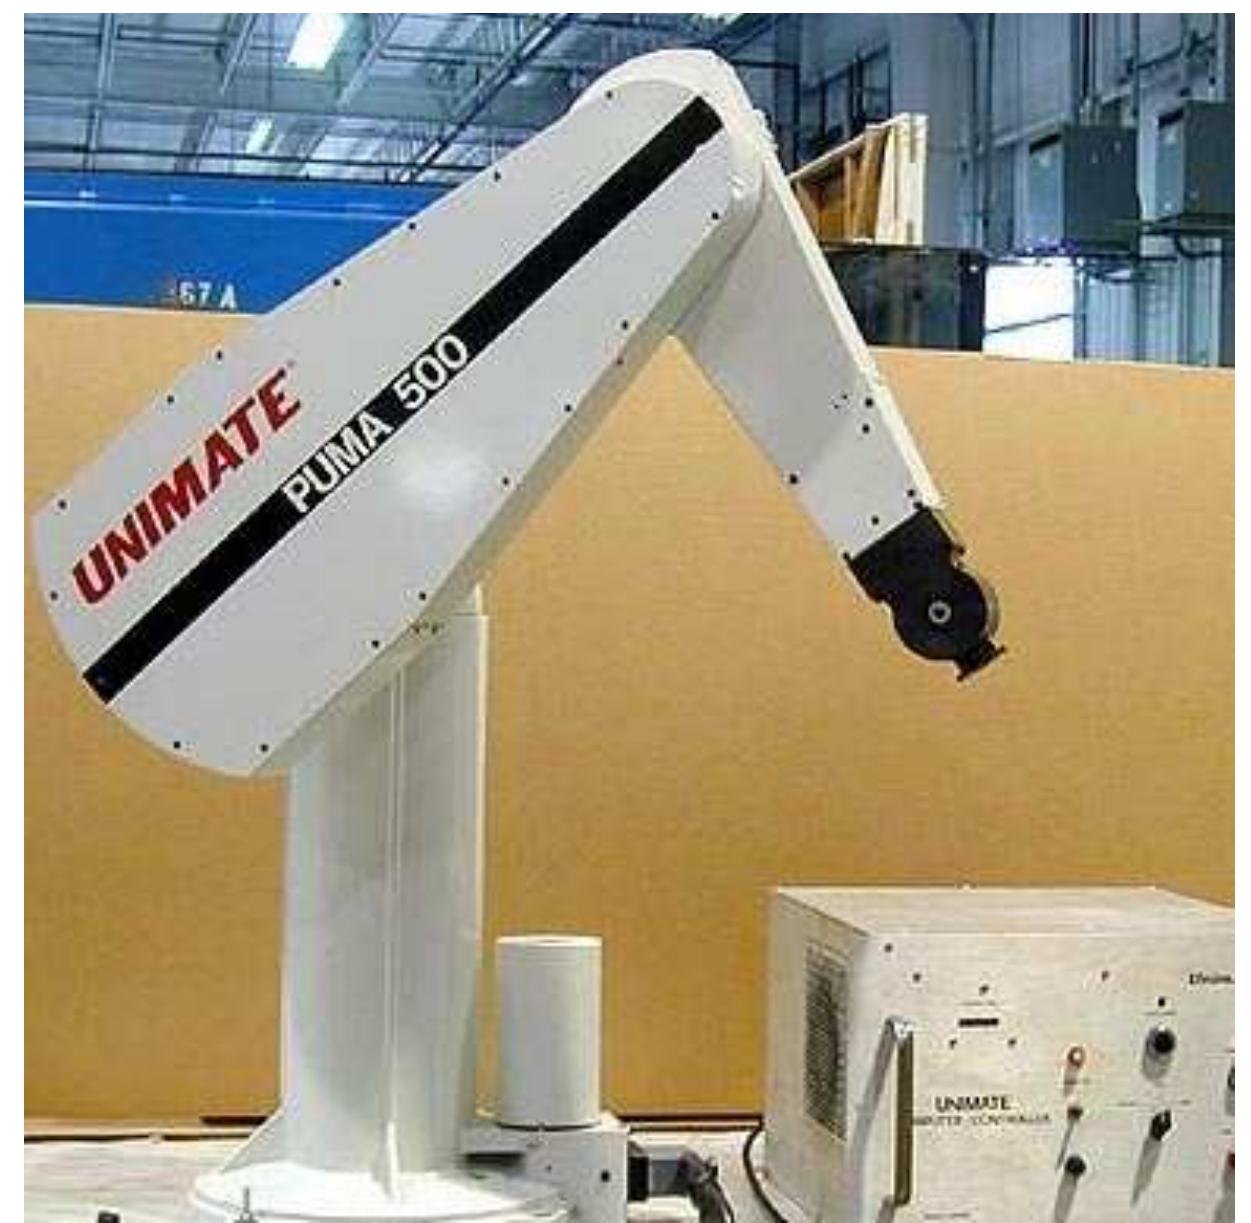
How Unimate Actually Stayed Upright
Unimate wasn't balanced by design. It was balanced by workaround. The original 1961 General Motors installation ran on a basic hydraulic system with minimal feedback loops. What people call the "balance revolution" wasn't a single breakthrough — it was years of incremental fixes that came after the robot kept tipping over during production runs. I spent about three years troubleshooting a pair of late-model Unimates at a foundry in Ohio. We ran them 24/7 moving molten metal die castings. The first month, one of them knocked itself over twice. Not because of software. Because the hydraulic cylinders warmed up, expanded slightly, and the arm's center of mass shifted just enough to change the reaction forces at the base during high-speed retractions.
The Unimate Balance Revolution How This Pioneering Robot Is Redefining Stability And Precision In Automation
The actual mechanism behind Unimate's stability improvements deserves more specificity than it gets. The robot used a counterweighted hydraulic arm with mechanical stops, not the kind of active balance control you'd see in modern servo systems. There was no real-time gyro feedback compensating for load shifts. What there was, instead, was generous overbuilding of the base structure and a deliberate low center of gravity — the whole unit sat on a 2,000-pound concrete pad that you bolted to the floor. The real innovation came from how engineers learned to work around the hydraulic drift. Here's the part most histories skip: the hydraulic fluid temperature directly affected positioning repeatability. In summer, when the shop hit 95 degrees, the fluid expanded and the arm would drift about 0.030 inches over a four-hour cycle. In winter, cold fluid made the cylinders respond slower, and the arm would undershoot by roughly the same amount. Operators didn't fix this with better sensors. They fixed it by running a warmup cycle before each batch and then adjusting the mechanical stops by feel. One specific problem we dealt with involved payload asymmetry. The Unimate was rated for a 250-pound arm payload, but the die castings we were handling averaged about 180 pounds each. The issue wasn't the weight — it was that the casting's center of gravity shifted depending on which side of the mold it came out. A normal part was fine. A part with a slightly uneven flash pattern on one edge created an off-balance moment that the hydraulic system fought against on every extension stroke. Over time, this caused the base bolts to loosen. We solved it by welding a small steel plate to the mounting flange on the end effector, adding about eight pounds of counterweight on the opposite side of the grip. Cost: twelve dollars and twenty minutes. Result: zero base bolt failures for the next eighteen months.
Another thing nobody talks about is the compliance advantage of hydraulic arms over early servos. People treat Unimate's hydraulic "slop" as a. It wasn't always. When you're handling hot, slightly warped die castings that vary by a fraction of an inch from piece to piece, a fully rigid servo arm would jam or apply destructive force. The hydraulic system's natural compliance let the arm yield slightly under pressure. It meant fewer crushed parts and fewer broken end effectors. We ran the Unimate with the hydraulic pressure set about 200 psi lower than the manufacturer's spec and it handled our parts better at that setting than at the recommended level. The precision story is more complicated. Unimate's positional repeatability was roughly ±0.005 inches under ideal conditions. That was good for 1960s standards and adequate for die handling. But "ideal conditions" required a level floor, stable hydraulic supply pressure, and the warmup cycle I mentioned. Without those, you were looking at ±0.020 inches or worse. Modern robotic arms achieve ±0.001 inches or better under similar conditions, and they do it with closed-loop servo feedback and encoder-based position correction. If you're trying to implement something like this on legacy equipment today, the main limitation is that the original Unimate hydraulic architecture doesn't support retrofitting modern servo motors without a complete redesign of the arm structure. The linkages, the cylinder placements, the mounting points — they're all dimensioned for hydraulic actuation. You can swap in electric actuators, but you'll need custom adapter plates and probably a new control system. The mechanical stops that served as hard-position references won't work with servo drives. You'd need to add encoders and build a new homing routine.
Get the Full Details

For most people looking at Unimate-era robots now, the practical path isn't rebuilding them into modern systems. It's understanding what made them work despite their limitations and applying those principles to newer installations. The key insight is that balance in industrial robotics isn't just about the robot itself — it's about the interface between the robot, the payload, the environment, and the mounting structure. Fix just one of those and the others become the weak point. The hydraulic drift problem I described still shows up in modern plants that run old equipment in uncontrolled environments. Temperature-sensitive hydraulic systems in buildings without climate control will always have the same repeatability issues Unimate had. The workaround hasn't changed much: warmup cycles, periodic recalibration of mechanical references, and if you need tighter tolerance, insulate or climate-control the area around the robot. Nothing more dramatic than that.