Trigonometry isn't magic. It's just coordinates that rotate.
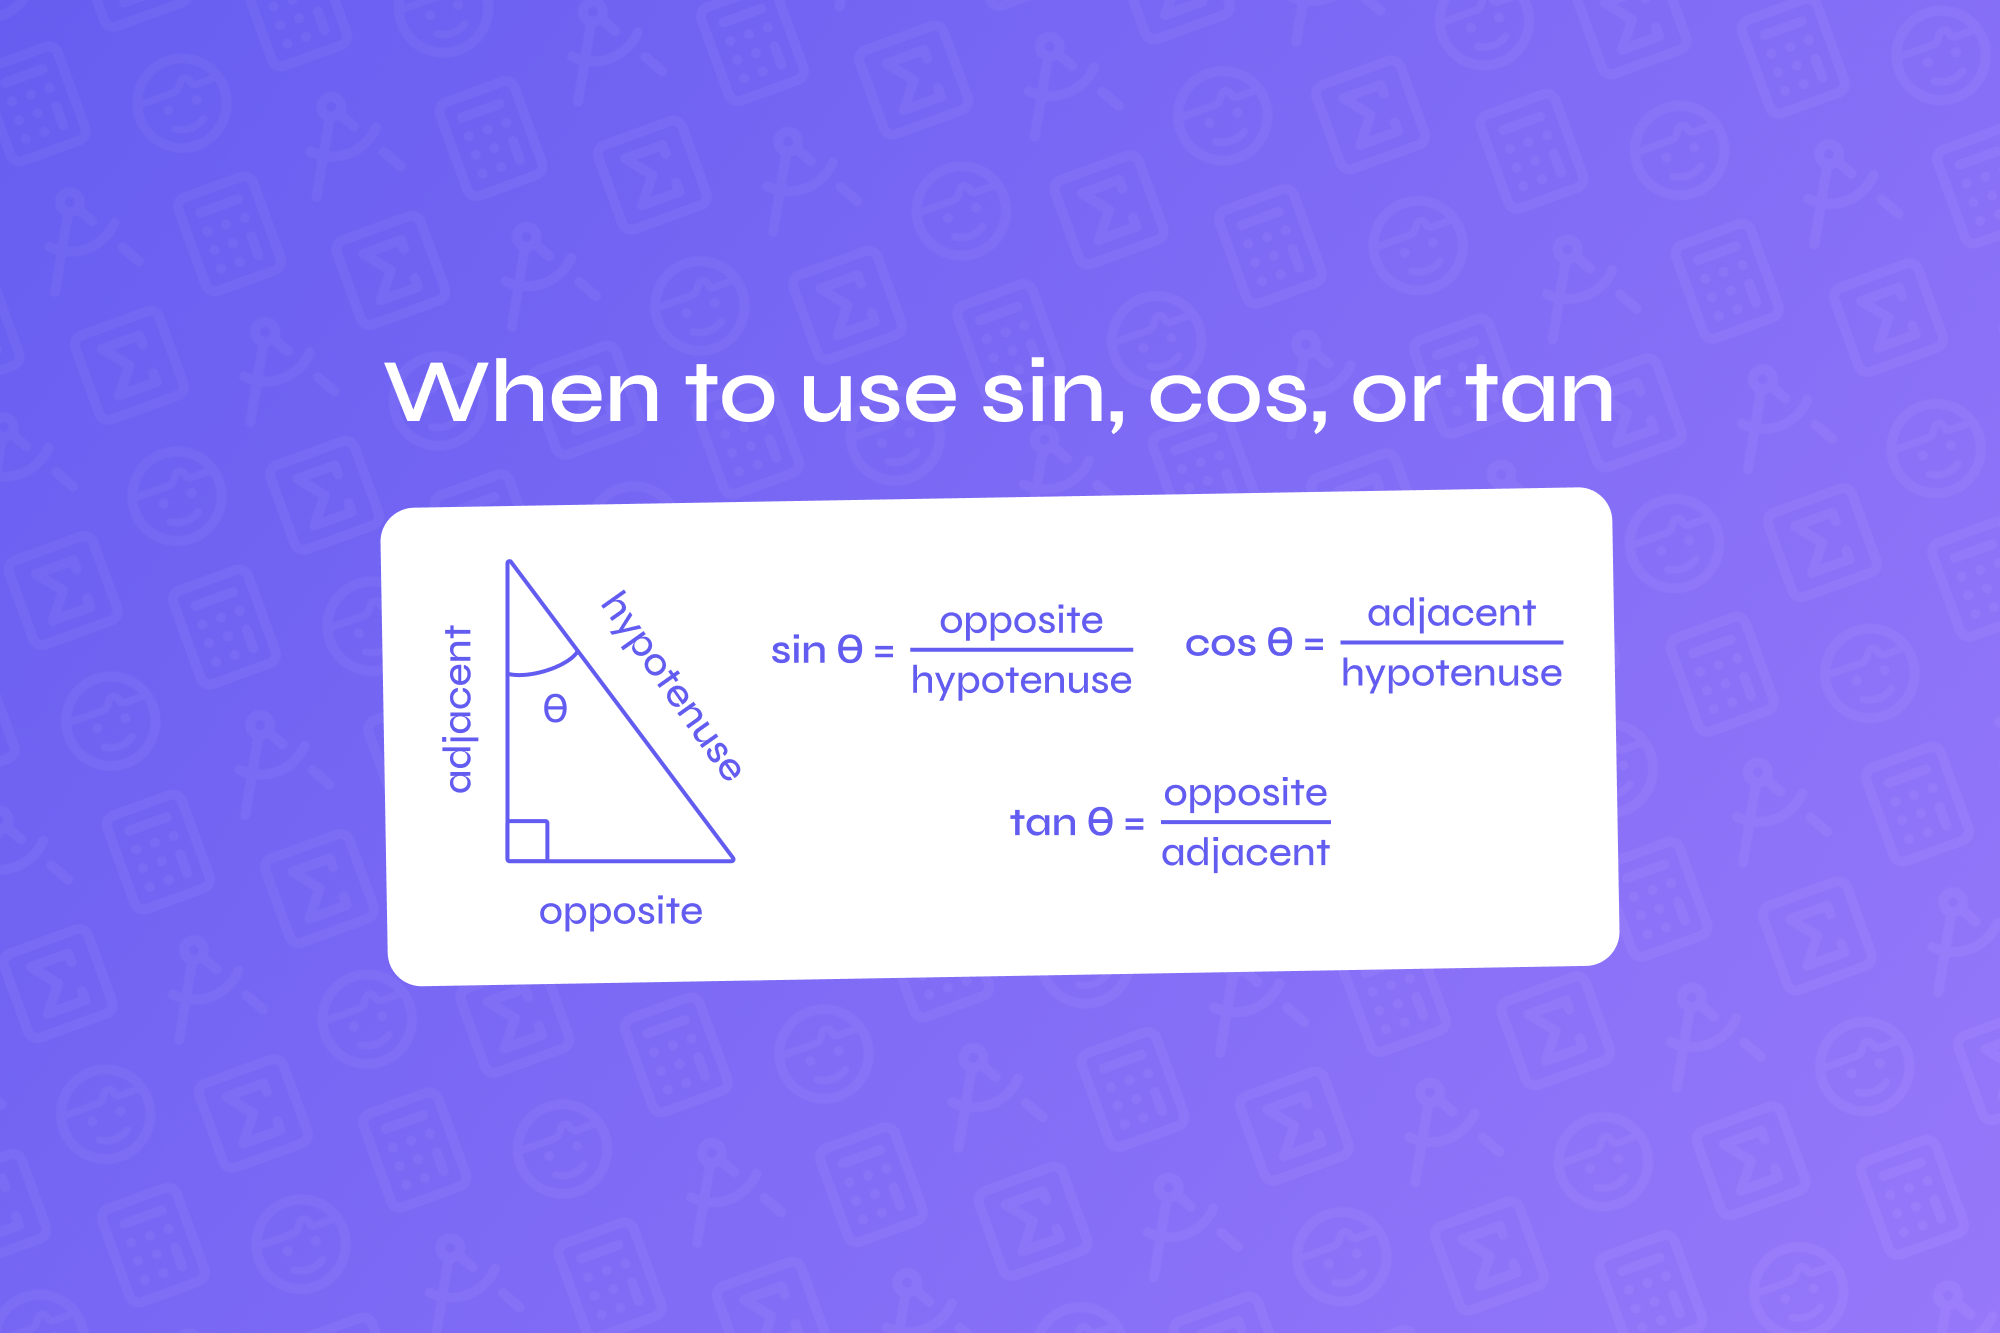
I spent three years debugging a CNC machine where the interpolation algorithm kept drifting on arc cuts. Turned out the compensation table was being read in gradians instead of degrees, and nobody had noticed because the error only manifested above 47 degrees of rotation. That's the thing about cosine and sine — they're not mysterious. They're boring. Until you need them precise. Most people encounter trigonometry through right triangles. Opposite over hypotenuse. SOH CAH TOA. That's useful if you're measuring a ladder against a wall. It's almost useless if you're trying to understand why your robotic arm overshoots its target by two millimeters on the fourth joint. The real understanding comes from the unit circle. Not the triangle version. The circle version. A point traveling around a circle of radius one at constant angular velocity. The x-coordinate at any moment is the cosine of the angle. The y-coordinate is the sine. That's it. Everything else is just rearranging these two numbers for different purposes.
Tangent is the ratio of sine to cosine. Geometrically, it's the length of the line segment from the point on the circle straight down to where the radius extension hits the vertical tangent line at one, zero. It's what blows up when cosine hits zero. Which happens at ninety degrees and two hundred seventy degrees. That's why tangent is undefined there and why engineers designing suspension systems avoid placing loads near those angles.
The stuff nobody explains in textbooks
Here's what I learned after ten years of working with this. The most common mistake isn't mixing up which function is which. It's forgetting that these functions are continuous, periodic, and exist independently of any triangle. You can have a cosine value for an angle of negative three hundred degrees. You can have one for a complex number argument. The definitions still hold. Another thing: most people think they need to memorize the values. They don't. They need to understand the symmetries. Cosine is even. Sine is odd. That means cosine of negative theta equals cosine of theta, and sine of negative theta equals negative sine of theta. This saves you half the work in pretty much every derivation. The co-function identities — sine of ninety minus theta equals cosine of theta — just reflect the fact that the legs of a right triangle swap roles when you look at it from the other acute angle. That's all. No magic. The double angle formulas are just the law of cosines applied twice, or derived from the angle addition formulas by setting beta equal to alpha. Sine of two alpha equals two sine alpha cosine alpha. Cosine of two alpha equals cosine squared alpha minus sine squared alpha, which also equals two cosine squared alpha minus one, or one minus two sine squared alpha. Three forms. Use whichever one cancels terms in your particular problem.
Get the Full Details

Working Through A Real Problem With The Ultimate Guide To Understanding And Mastering Cos Sin Tan
Let me walk through something practical. I was calibrating a lidar system last year that measured distances by timing phase shifts between transmitted and received sine waves. The raw output was in voltage proportional to sine of the phase difference. I needed to convert that to distance, then to Cartesian coordinates for point cloud generation. The first issue was that the sensor had a nonlinear response near the zero-crossings. The sine approximation sin theta equals theta works well within about ten percent error up to roughly thirty degrees, but the calibration points were spaced at twenty degree intervals across the full two pi range. Using the small angle approximation everywhere introduced systematic error that compounded through the coordinate transform. The workaround was to fit a piecewise cubic spline to the calibration data rather than applying the inverse sine globally. Inverse sine, or arcsin, has a restricted domain of negative one to one and ranges from negative ninety to ninety degrees. Beyond that, you lose information about which quadrant the angle was actually in. The lidar didn't tell you whether the target was in front or behind based on voltage alone. But combining the sine channel with a cosine channel from the quadrature detector resolved the ambiguity completely.
This is where understanding what the functions actually represent matters more than memorizing identities. Cosine and sine aren't just numbers you plug into formulas. They're projections. When you decompose a rotating vector into components, you're using these functions exactly as they were defined: coordinates of a point on the unit circle. Everything else — wave equations, Fourier transforms, AC circuit analysis — is just applying that same projection principle in different domains.
Where this breaks down
I should be honest about the limitations. Trigonometric identities work beautifully in Euclidean space. They stop working directly on curved surfaces. If you're dealing with spherical geometry — GPS coordinates, orbital mechanics, navigation over long distances — you need spherical trigonometry, which uses different formulas. The law of cosines for sides on a sphere involves cosine of the angular separation between two points, not their planar distance. Numeric precision is another issue. When angles approach ninety degrees and you're computing cosine using Taylor series expansion in floating point arithmetic, you lose significant digits. Cosine of eighty-nine point nine nine nine degrees is approximately zero point zero zero zero one seven four five. In single precision, that's getting close to the noise floor. If your application requires sub-millimeter accuracy at grazing angles, use the complementary angle identity and compute sine of the small angle instead. Sine of zero point zero zero one degrees is more stable numerically than cosine of eighty-nine point nine nine nine degrees. There's also the problem of degrees versus radians. Calculus doesn't care about degrees. The derivative of sine of x equals cosine of x only when x is in radians. If you're differentiating sine of pi x over one hundred eighty, you get pi over one hundred eighty times cosine of pi x over one hundred eighty. The chain rule doesn't care about your preference. Just be consistent and convert early if you're working in degrees.
The shortcuts that actually matter
After years of using these functions daily, here are the few identities I keep in my head instead of looking up. The Pythagorean identity: sine squared plus cosine squared equals one. This shows up constantly and saves you from computing both functions when you only need one. If you know cosine and need sine, just take the square root of one minus cosine squared. Pick the sign based on the quadrant. The sum to product formulas are useful when you're simplifying expressions with multiple angles. Sine of alpha plus sine of beta equals two sine of alpha plus beta over two times cosine of alpha minus beta over two. This converts addition into multiplication, which is often easier to work with analytically. Euler's formula is the one that connects everything. E to the i theta equals cosine of theta plus i sine of theta. It's not just elegant. It's practical. When you're working with complex exponentials in signal processing or quantum mechanics, this identity lets you convert between trigonometric and exponential forms instantly. The cosine and sine become the real and imaginary parts of a rotating complex number. That's why phasor notation works in AC analysis. It's Euler's formula in disguise.
Common Pitfalls That Cost Me Hours
Arc tangent has a notorious two-argument form for a reason. The standard atan function returns values between negative ninety and ninety degrees. It can't distinguish between an angle in the first quadrant and one in the third quadrant because tangent has the same value at both. I once spent four hours tracking down a bug where a steering controller was commanding opposite turns because the code used single-argument atan instead of the two-argument atan2 that considers the signs of both the sine and cosine components separately. Another trap: power reduction identities. Cosine squared theta equals one plus cosine of two theta over two. This looks simple but people frequently drop the factor of two inside the argument or forget the division outside. Write it out once on paper and you'll never make that mistake again. The most subtle issue is assuming periodicity where it doesn't apply. Sine and cosine repeat every two pi. Tangent repeats every pi. But inverse sine, inverse cosine, and inverse tangent don't have the same periodicity. They're functions by definition — each input maps to exactly one output. The restricted range of arcsin being negative pi over two to pi over two isn't a limitation you can ignore. It's a feature that makes the inverse well-defined. If you need all solutions to an equation like sine of x equals one half, you write x equals pi over six plus two pi n or x equals five pi over six plus two pi n, where n is any integer. Don't just write arcsin of one half and stop.
Practical computation tips
If you're implementing these functions yourself rather than using a library, the CORDIC algorithm is worth knowing about. It computes sine and cosine using only shifts and additions, which matters on embedded systems without floating point hardware. The basic idea is to rotate vectors through a sequence of predefined angles whose tangents are powers of two, building up the desired angle step by step. Each iteration halves the angular error. After about seventeen iterations, you get double precision accuracy. For quick mental approximations, the Taylor series works fine for small angles. Sine of theta is approximately theta minus theta cubed over six plus theta to the fifth over one hundred twenty. Cosine is approximately one minus theta squared over two plus theta to the fourth over twenty-four. Stop at the term you need. For angles up to about twenty degrees in radians, the first two terms give better than one percent accuracy. Beyond that, add the next term or switch to a lookup table with interpolation. When working with measured data rather than theoretical angles, remember that real sensors have offset, scale factor error, and misalignment. A properly calibrated system measures cosine and sine of the same angle from quadrature encoders and checks that sine squared plus cosine squared equals one within tolerance. If it doesn't, you have gain imbalance or DC offset that needs correction before any downstream computation. The identity becomes a self-test rather than just a mathematical curiosity.
The range reduction technique is essential for accurate computation across all angles. Most library implementations first reduce the input angle to the range of negative pi over two to pi over two using the periodicity and symmetry properties, then apply a minimax polynomial approximation optimized for that smaller interval. This is why you should never implement your own sine function by blindly truncating a Taylor series at large arguments. The series converges everywhere, but the number of terms needed grows with the magnitude of the input, and floating point rounding errors dominate before you reach the desired precision.
Applications beyond the classroom
Lidar and radar signal processing use these functions for phase-based distance measurement. The returned signal is mixed with a reference sine wave, and the resulting DC component after low-pass filtering is proportional to the cosine of the phase delay, which is proportional to the round-trip time, which is proportional to distance. This is how FMCW radar works. The same principle applies to acoustic ranging, optical interferometry, and any coherent detection scheme. Vectors in computer graphics rely on these functions for rotation. A two-dimensional rotation matrix contains cosine and sine of the rotation angle in specific positions. Multiplying a point by this matrix rotates it around the origin. Extending to three dimensions requires composing rotations about different axes, which introduces the non-commutativity that makes Euler angles problematic for interpolation. Quaternions avoid this by encoding the axis and angle separately, but the underlying sine and cosine values are still what determine the rotation magnitude. Fourier analysis is built on these functions because sine and cosine are eigenfunctions of the second derivative operator. That means their second derivatives are proportional to themselves, with the proportionality constant being negative the frequency squared. This property makes them the natural basis for solving linear differential equations with constant coefficients, which describe everything from spring-mass systems to electromagnetic wave propagation to heat diffusion. No other pair of functions has this property, which is why Fourier chose them and why they remain indispensable.
AC electrical engineering uses phasors, which are complex numbers whose magnitude is the RMS voltage or current and whose argument is the phase angle. Impedance combines resistance and reactance into a single complex quantity, and Ohm's law generalizes to V equals IZ using complex arithmetic. The real power dissipated in a resistor is the product of RMS voltage, RMS current, and cosine of the phase angle between them. That cosine factor is the power factor, and correcting it with capacitors or inductors reduces transmission losses. This is a direct application of the geometric interpretation of cosine as the projection of one rotating vector onto another.

When to use which identity
If you're simplifying an expression with products of sines and cosines, use the product to sum formulas. If you're adding angles, use the sum and difference formulas. If you're dealing with squared terms, use the power reduction or Pythagorean identities. If you have a ratio and need to eliminate the denominator, multiply by the conjugate and apply the difference of squares, which often reveals a Pythagorean identity underneath. For solving equations, isolate the trigonometric function first, then apply the appropriate inverse function, but always account for all solutions within the requested interval by using the periodicity and symmetry properties. Draw the unit circle if you're uncertain about the quadrant. A quick sketch prevents more algebraic mistakes than any amount of memorization. The addition formulas can be derived from the distance formula on the unit circle or from Euler's formula by expanding the product of two complex exponentials. Knowing the derivation helps you remember the formulas better than rote memorization. Sine of alpha plus beta equals sine alpha cosine beta plus cosine alpha sine beta. Cosine of alpha plus beta equals cosine alpha cosine beta minus sine alpha sine beta. Notice the sign flip. Sine adds, cosine subtracts. This pattern holds for the difference formulas too, with the signs reversed because cosine is even and sine is odd.
What I Wish Someone Had Told Me Sooner
The most important insight isn't a formula. It's the recognition that sine and cosine are the same function shifted by ninety degrees. Cosine of theta equals sine of theta plus ninety degrees. This single observation unifies half the identities in the subject. Every co-function identity follows from this shift. Every symmetry property becomes obvious when you see that the cosine graph is just the sine graph moved left by a quarter period. This perspective makes the entire subject feel less like a collection of unrelated facts and more like a coherent system built from two core functions and their geometric relationship to circular motion. Understanding also means knowing when these tools are the wrong answer. Numerical integration of oscillatory integrals using naive sampling can fail catastrophically if the sampling rate doesn't satisfy the Nyquist criterion relative to the oscillation frequency. Adaptive quadrature or specialized Filon-type methods handle this better. Trigonometric interpolation suffers from Runge-like phenomena at high frequencies unless you use sufficient sampling points. Spectral methods avoid this by working in the frequency domain directly rather than trying to fit polynomials through oscillatory data. The bottom line is that cosine, sine, and tangent are not abstract concepts pulled from nowhere. They describe rotation, oscillation, projection, and periodicity. Once you see them as coordinates of circular motion rather than ratios in right triangles, most of the identities fall out naturally from the geometry. The formulas are summaries of relationships that are already visible if you draw the circle and track the point as it moves.