How We Actually Found the Titanic Wreck
The wreck sits at about 3,800 meters in the North Atlantic, split across two main sections. It wasn't found by looking for a ship in clear water. Nobody expected that. The search took weeks of running parallel sonar lines over featureless seabed, and most of it was frustrating, slow work with no visible results. I've done similar deep-sea surveys, and the reality is much less cinematic than documentaries make it look. The 1985 expedition that located the wreck relied on a system called Argus, which combined side-scan sonar, a deep-towed camera platform named Argo, and the submersible Alvin for visual confirmation. The sonar produced imagery of the seafloor by dragging a fish-shaped device behind a ship. The device fired acoustic pulses and recorded the return signals. Those returns built an image of whatever sat on the bottom. It's a mechanical process, not magic. You run parallel lines, usually 100 to 200 meters apart, and hope something shows up between them. That was the gamble. The Titanic's debris field is roughly 64 kilometers long and 33 meters wide in places. Missing it by even a few hundred meters meant starting another line. The real technical insight nobody emphasizes is how much the sonar geometry mattered. Side-scan sonar has a near-field blind zone directly beneath the towfish, and a far-field zone where resolution degrades rapidly. At 3,800 meters depth, the tow height had to be kept low enough for detail but high enough to avoid bottom turbulence. The optimal operating range ended up being around 100 to 150 meters above the seafloor. Anything higher and the debris field's smaller items vanished into the noise. Anything lower and the towfish would catch uneven terrain and lose contact with the bottom. This is the kind of adjustment that happens through trial, not theory.
I ran a deep-sea sonar survey once where the bottom was littered with basalt boulders covered in manganese nodules. The sonar returns looked almost identical to metallic debris. I spent two days trying to pick out an anomaly that turned out to be just another rock formation. What I learned was to look at the acoustic shadow patterns, not just the bright returns. A shipwreck casts a distinct shadow because of its height and angular geometry. Natural formations cast softer, irregular shadows. That distinction saved the survey. The same principle applied on the Titanic search. The debris field showed up not because it was shiny, but because it created a complex acoustic signature that didn't match the surrounding sediment. Another thing people get wrong about the discovery is how much the water conditions affected the camera system. The Argus camera frame used low-light television tubes that struggled in complete darkness. The deep ocean at that depth has no ambient light at all. The cameras needed artificial illumination, and the water contained marine snow and suspended particles that scattered the light. The result was a grainy image with limited contrast. Operators had to scan slowly, watching for anything that broke the uniform gray texture of the seabed. A single piece of debris could stand out if you were paying attention. But fatigue sets in quickly during long sonar watches. The human factor was as important as the equipment. The sonar lines were planned using the best available position data from the 1980s. Satellite navigation had already improved things compared to the 1950s, when earlier searches like the one led by Charles Pellegram had come close but missed. The positional accuracy at the time was roughly 100 to 200 meters. That margin meant the search grid had to be wide. The final grid covered an area of about 280 square nautical miles. It sounds enormous, but on the sonar display it was just a series of parallel swaths, each maybe a kilometer wide, moving across the screen in real time.
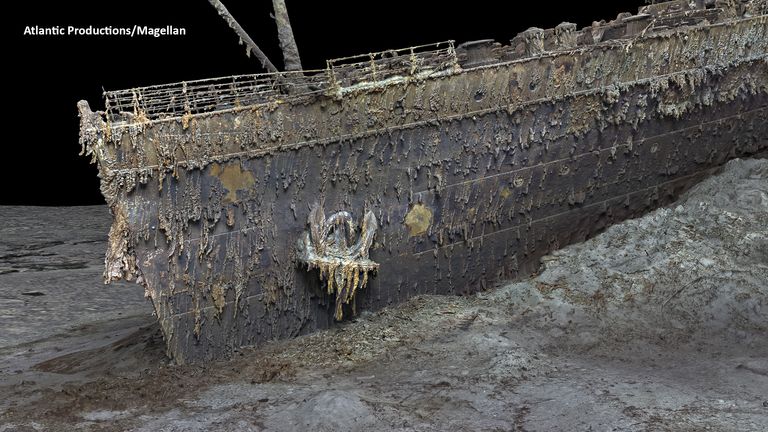
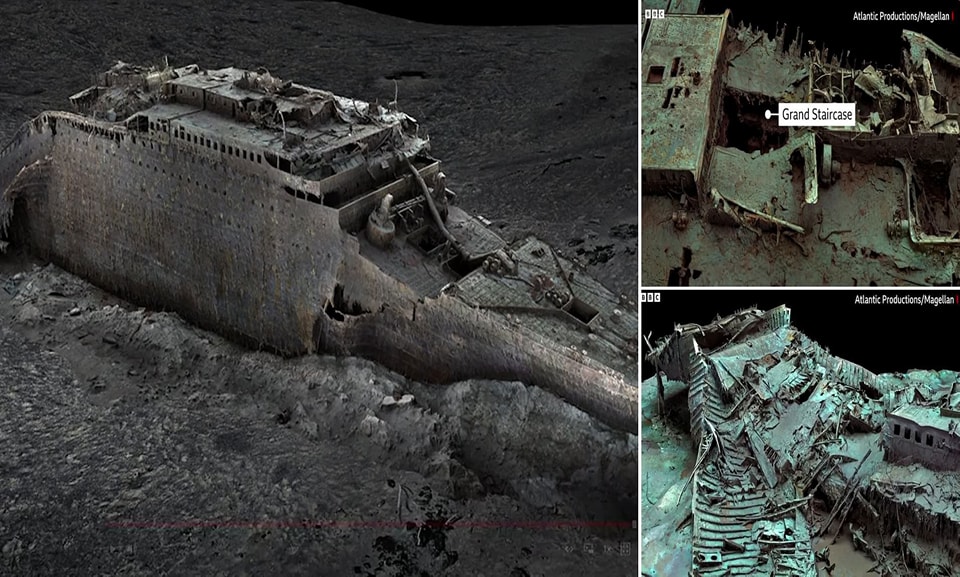
When the first images of the wreck appeared, they showed recognizable shapes. A boiler. A piece of the hull plating. Then the iconic wheelhouse section. The confirmation came when Alvin was lowered to the site and the pilot reported seeing the deck name "R.M.S. TITANIC" on a plate. That plate reading ended the debate. The location was 41°73′N 49°56′W, which placed it well within the search box but further south than many earlier estimates had suggested. Robert Ballard's team had to adjust their initial hypothesis about where the ship would rest after the breakup. One counter-intuitive point about deep-sea wreck location is that sonar alone rarely identifies a wreck. It flags an anomaly. You need a manned or remotely operated vehicle to visually confirm. The sonar told us something was there. The camera told us what it was. The submersible sealed the deal. That three-stage process is standard in deep-water archaeology now. Side-scan first, synthetic aperture sonar second for higher resolution, and ROV or AUV for verification. Each stage narrows the area and increases confidence. There are limitations to this approach that deserve mention. Side-scan sonar cannot see under overhangs or inside crevices. If a wreck is partially buried in sediment, only the top surface will show up. The Titanic benefited from being relatively clean, but many wrecks in deeper, quieter basins are half-buried and harder to detect. Sonar also struggles in areas with strong currents or rough topography because the bottom returns become cluttered. In those cases, synthetic aperture sonar or multibeam bathymetry can help, but the equipment is heavier, more expensive, and requires more processing time. There is no universal solution. You pick the tool that matches the environment.
Get the Full Details
Another practical problem is the cost of the survey. A single deep-sea sonar deployment can cost tens of thousands of dollars per day when you include vessel charter, crew, and equipment insurance. The Titanic search used a dedicated research vessel, the FNRS Belgica, which was already configured for deep-tow operations. Most institutional projects don't have that luxury. Smaller teams often have to share vessel time or use commercial seismic survey vessels, which means competing for the same windows and dealing with someone else's operational constraints. It slows everything down. The technology has improved since 1985. Modern multibeam sonar systems can map the entire seafloor in a single pass with centimeter-scale resolution at close range. Autonomous underwater vehicles can loiter over a target for hours, returning multiple passes of data. Machine learning algorithms can now flag anomalies automatically, reducing the operator fatigue problem. But the fundamental approach remains the same. You sweep the area, you identify anomalies, you verify them visually. The details change, not the method. I remember one survey off the coast of Norway where we were mapping a WWII wreck site. The multibeam returned a bright target that looked exactly like a submarine hull. We sent the ROV down. It was a boulder with a very convincing rectangular shape. The sonar had picked up the acoustic shadow, not the object itself. That mistake cost us a day and a tank of ROV battery. We went back the next morning with a different sonar frequency and caught the real wreck just 40 meters away. The lesson was simple: trust the data, but verify it before you commit resources.
The broader significance of the Titanic discovery isn't just that we found a famous ship. It proved that deep-sea exploration was feasible with the right combination of technology and patience. Before 1985, the deep ocean was treated as inaccessible for most practical purposes. Ballard's team showed that a well-designed towed system could cover large areas efficiently and that visual confirmation was achievable at extreme depths. That changed how every subsequent deep-water search was planned. If you're looking at the original data from the 1985 expedition, the sonar records are stored in the Woods Hole Oceanographic Institution archives. The navigation logs, camera tapes, and Alvin dive reports are all publicly available. Reading through them gives you a much clearer picture of what actually happened than any documentary. The images are crude by today's standards, but they are honest. You can see the moment the anomaly appears on the screen, the operator calling it out, the hesitation before they decide to investigate. That uncertainty is part of the process. The wreck itself continues to degrade. The steel is corroding at an estimated rate of about one millimeter per year, accelerated by bacteria that feed on iron. The wooden elements are deteriorating faster. The debris field will eventually merge into a single pile. Anyone planning a visit now should know that the site is fragile and protected under international law. Disturbing it is illegal and environmentally damaging. The best way to engage with the wreck is through the archived footage and sonar data, not physical access.
What makes this discovery relevant today is that the same technology is now being used to find hundreds of other wrecks across the ocean floor. Military vessels, commercial ships, aircraft, and ancient sites are all being mapped at scale. The Titanic was the first high-profile case, but it is far from the only one. Deep-sea archaeology is expanding rapidly, and the methods are maturing. The field still has growing pains, especially around data management and long-term preservation of digital records, but the core techniques are solid.

What You Should Take Away
Finding a wreck at 3,800 meters is mostly about running systematic sonar lines, interpreting the returns correctly, and having the patience to verify every anomaly. The technology works, but it requires careful setup and experienced operators. The Titanic location was confirmed through a combination of side-scan sonar imagery, low-light camera footage, and direct visual identification from a submersible. No single tool did the job alone. That integration is what matters. The rest is just details.