Understanding Sin(0) Without the Fluff
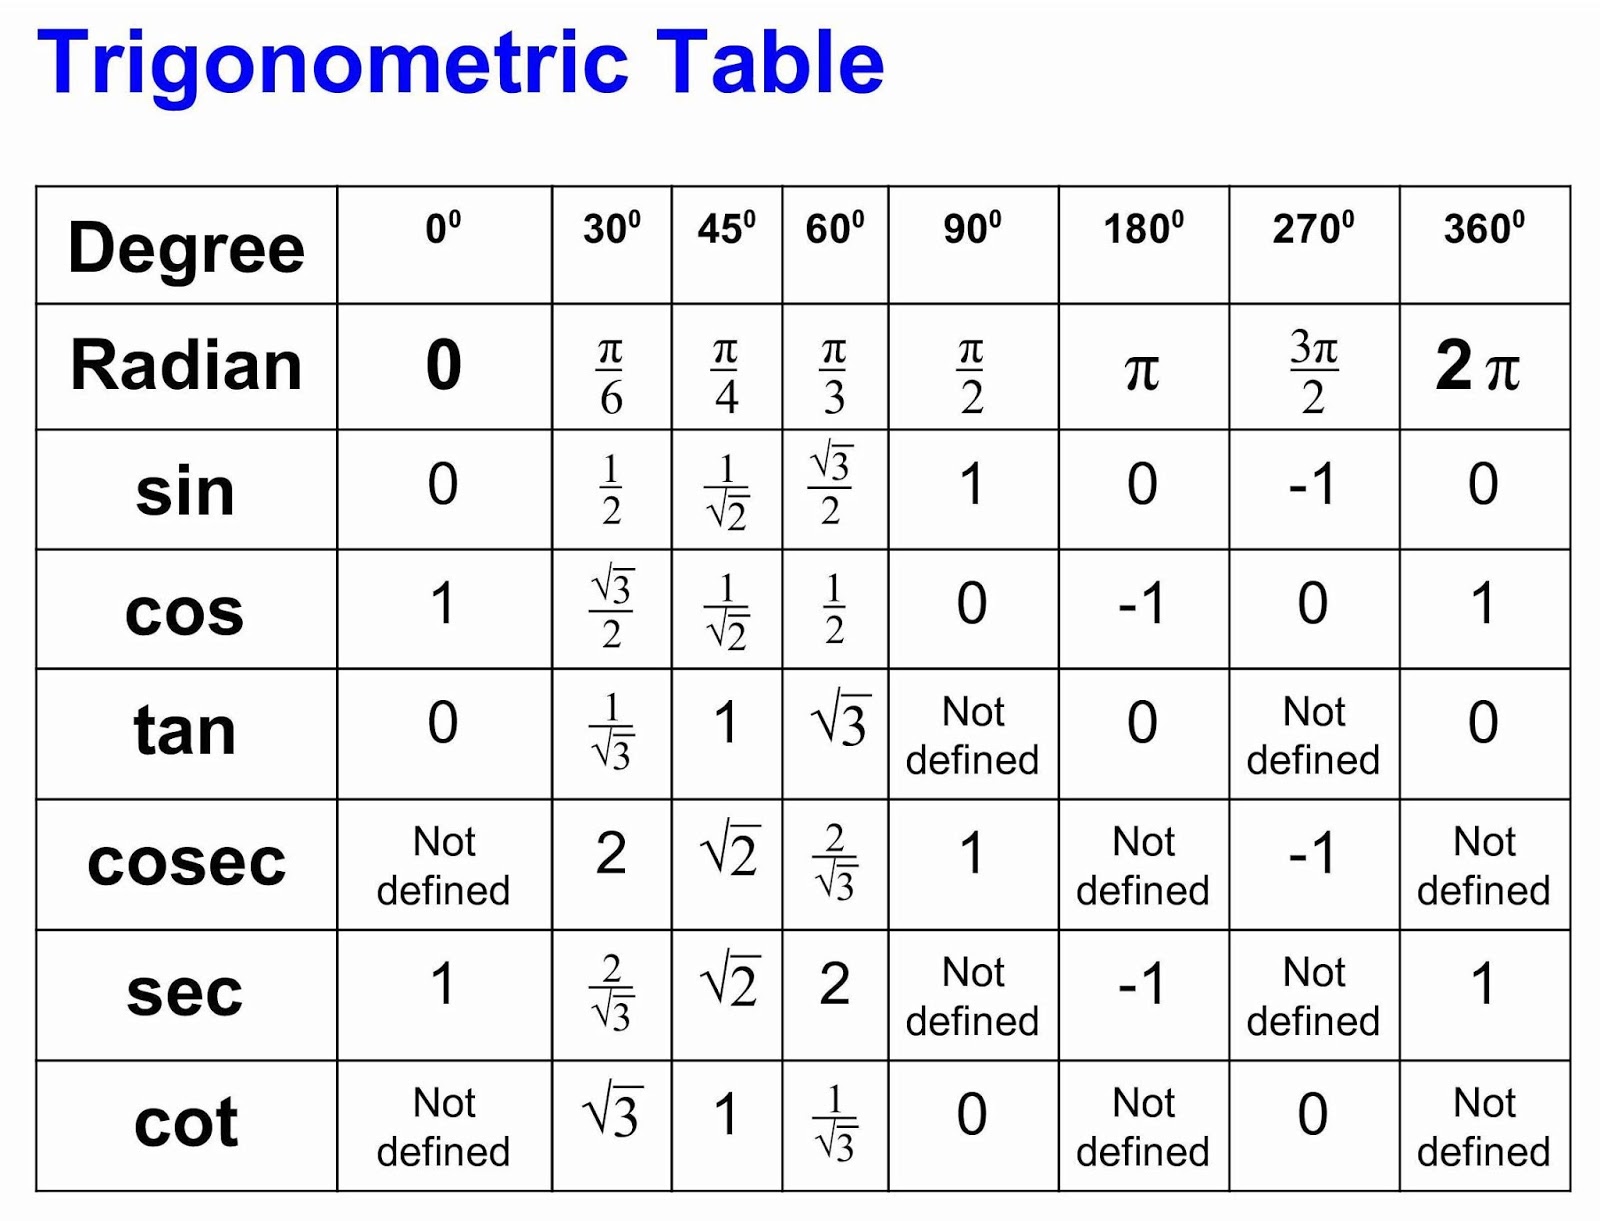
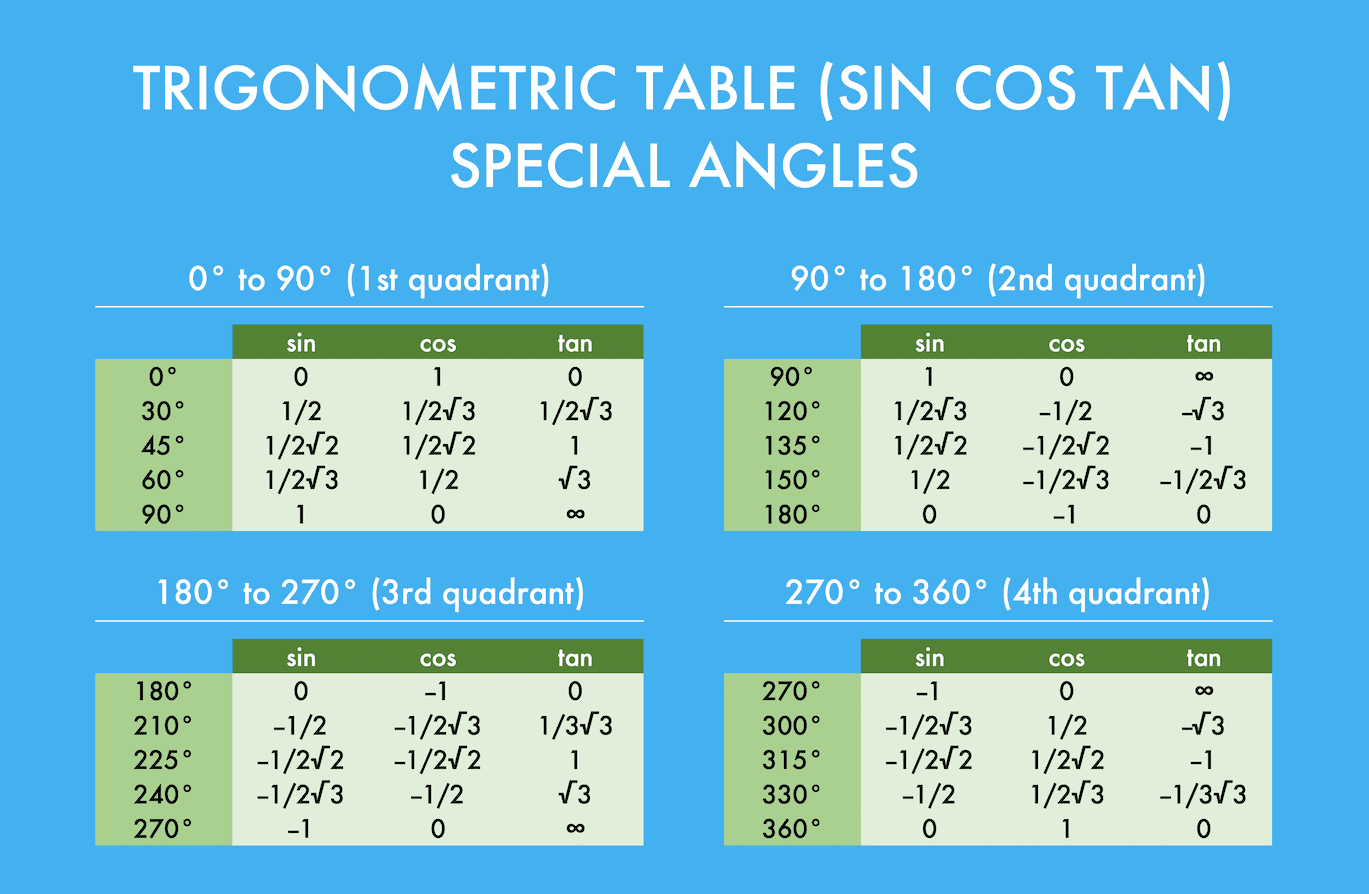
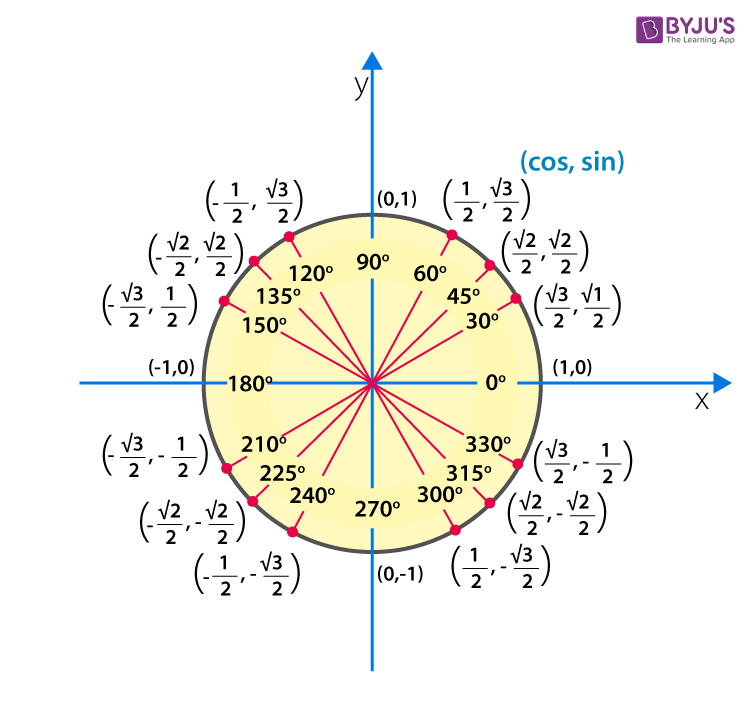
The sine of zero is zero. That is the entire answer. You will see it written in every trigonometry textbook within the first week of the course, usually as part of a table alongside cos(0) = 1 and tan(0) = 0. Most students never actually think about why that is the case, and frankly, you do not need to dig deeper unless you are doing something that requires it. But when you do, the explanation is straightforward enough that I will walk through it. The sine function comes from the unit circle, which is just a circle with a radius of one centered at the origin. When you pick an angle theta and draw a line from the origin out to the edge of the circle, the sine of that angle is the y-coordinate of the point where the line hits the circle. At zero degrees, the line points straight along the positive x-axis. The point on the circle is (1, 0). The y-coordinate is zero. Therefore sin(0) = 0. That is it. There is no deeper mystery here.
The Sine Of 0 Why The Cornerstone Trigonometric Value Is 0 And What It Means
I spent several years working on simulation software where trigonometric calculations ran constantly. Every physics update, every animation frame, every rotation matrix involved sine and cosine calls. One afternoon, a colleague was debugging a graphics engine that had started producing jagged, incorrect rotations on certain objects. The error traced back to a degenerate case where a rotation angle collapsed to exactly zero due to accumulated floating-point rounding. The code assumed that whenever sin(theta) equaled zero, it could skip the rotation entirely. But due to how the engine handled identity matrices versus actual zero rotations, the object still needed its transform updated through a different code path. Skipping it caused the render to pull stale transformation data, which produced the jitter. The fix was not mathematical. It was a matter of keeping the zero-angle case inside the normal rotation pipeline instead of branching it out as a special optimization. I learned to never assume sin(0) being zero meant you could avoid the computation entirely. In production systems, that assumption breaks things in subtle ways. Beyond the basic unit circle definition, there are a few things people miss about sin(0). First, the derivative of sine at zero is one. That is because cos(0) equals one, and the derivative of sin(x) is cos(x). This matters in numerical methods and Taylor series approximations. If you are approximating sin(x) for small angles using just x, you are using the first-order Taylor term, and the approximation is sin(x) x when x is near zero. This is why engineers use the small-angle approximation in everything from pendulum problems to control theory. The error at x = 0.1 radians is about 0.167 percent, which is negligible for most practical purposes. At x = 0.5 radians, the error climbs to roughly five percent, and that starts to matter.
Another nuance that trips people up involves radians versus degrees. If you compute sin(0) in a system that interprets the input as degrees, you still get zero. But if you compute sin(1) assuming degrees when the function expects radians, you get a wrong answer without any warning. This is one of the most common bugs in scientific computing, and it has nothing to do with sin(0) specifically. It is about the input convention. Just always check what your function expects. I have also seen people get confused about why tan(0) is defined while tan(/2) is not. Tangent is sine divided by cosine. At zero, you get 0/1, which is fine. At /2, you get 1/0, which is undefined. The boundary behavior at /2 is where tangent blows up, not at zero. Zero is the safest point in the entire sine-cosine-tangent family. All three functions are well-behaved there. That is why it shows up so often as a boundary condition in proofs and numerical algorithms. There is a practical downside to relying on sin(0) = 0 as an early-exit condition in performance-critical code. Some hardware architectures and vectorization libraries handle zero-angle inputs efficiently anyway. Adding an explicit conditional check can sometimes slow things down because branch prediction gets confused. If you are writing a shader or a SIMD loop that processes thousands of angles per frame, the conditional to skip the sine call might cost more than just letting the instruction pipeline run through it. Modern GPUs are very good at parallel computation, and branching in that context is expensive. Profile before you optimize.
Get the Full Details

Another limitation worth noting is that sin(0) being exactly zero only holds in exact arithmetic. In floating-point computation, if your angle is computed through a series of operations, you might end up with something like 1.11e-16 instead of exactly zero. This happens all the time in physics engines and game development where angles accumulate over many frames. Calling sin on a value that close to zero will return a number close to zero, but it might not be exactly zero. If your code then checks for exact equality to zero, it will fail. Always use a tolerance-based comparison instead of == when dealing with floating-point results of trigonometric functions near zero. Here is a concrete example of what I mean. Say you are writing a 2D graphics library and you need to rotate a sprite by a small angle every frame. The angle comes from an angular velocity multiplied by a delta time. Over many frames, floating-point drift means the accumulated angle will never be exactly a multiple of 2. When you compute sin of that angle, you will not get exactly zero even at what should be the starting position. If you use that sine value as a position offset, the sprite will drift imperceptibly. Not noticeably, but measurably. Over thousands of frames, that drift adds up. The workaround is to normalize the angle back to the [0, 2) range each frame and then check if the normalized value is within a small epsilon of zero. If it is, snap the angle to exactly zero and proceed. This is called angle wrapping or angle normalization, and it is standard practice in any real-time simulation code. If you need a quick reference, the key values around zero are: sin(/6) = 0.5, sin(/4) 0.707, sin(0) = 0, sin(/4) 0.707, sin(/6) = 0.5. These are the values you will use most often. Memorizing them helps more than you would expect, especially when you are doing mental estimates or checking whether a computed result is in the right ballpark.
The Maclaurin series for sine is sin(x) = x x³/3! + x/5! x/7! + ... When x = 0, every term is zero. The series converges to zero immediately. This is a good sanity check if you ever implement your own sine function for an embedded system with no math library. Truncating the series after the first term gives you x, which is the small-angle approximation I mentioned earlier. Including the third term gives you x x³/6, which is accurate to about 0.02 percent for angles up to 0.5 radians. For most engineering applications, that is sufficient and avoids the overhead of calling a full transcendental function. I have seen some beginners try to derive sin(0) using right-triangle definitions, and that approach runs into trouble. In a right triangle, the sine of an angle is the opposite side divided by the hypotenuse. When the angle approaches zero, the opposite side shrinks to zero length. The ratio goes to zero. But at exactly zero, the triangle collapses into a line segment, and a degenerate triangle is not really a triangle anymore. The unit circle definition handles this cleanly because it does not require a triangle at all. It works at every angle, including zero and negative angles, without breaking down. That is why the circle definition is preferred in higher mathematics and why you should think of it as the primary definition rather than an alternative one. One more thing that occasionally comes up is the relationship between sin(0) and complex numbers. Through Euler's formula, e^(i) = cos() + i·sin(). When = 0, this gives e^0 = 1 + 0i, which confirms that cos(0) = 1 and sin(0) = 0. This is not just a coincidence. It is a consistency check that ties together exponential functions, trigonometry, and complex analysis in a single elegant identity. If you are working in signal processing or control systems, you will encounter this relationship constantly. Knowing that sin(0) = 0 in that context means the imaginary part of e^(i·0) vanishes, leaving only the real part equal to one.
If you want a reliable resource to reference, Khan Academy has a clear section on unit circle trigonometry, and the Pauls Online Math Notes at Tutorial Room cover the Taylor series derivations in detail. For the implementation side, the C standard library's math.h functions are well-tested and follow IEEE 754 guidelines. The glibc implementation of sin() uses a polynomial approximation with range reduction, and it handles the zero case correctly. If you are rolling your own, do not skip the range reduction step. Computing sin() directly on large angles without reducing them to [/4, /4] first produces catastrophic precision loss. That last point deserves emphasis because it is a genuine pitfall. Someone might write a quick sin() function for a project and test it with a few small angles. It works fine. They deploy it. Then a user passes in an angle of 10,000 radians, and the result is garbage. Range reduction is not optional. It is the reason general-purpose math libraries are careful about how they handle their input domain before applying any approximation. The same issue exists for cos(), tan(), and all the other trigonometric functions. The zero case is trivial, but the large-angle case is where things go wrong. At the end of the day, sin(0) = 0 is simple. The simplicity is the point. It is the anchor that all the other trigonometric properties build around. Without that fixed reference, the entire system loses its meaning. In practical terms, you just need to remember to use the right units, handle floating-point near-zero cases with tolerance checks, and do not skip range reduction when implementing your own functions. Everything else follows from there.