Working With Right Triangles In Practice
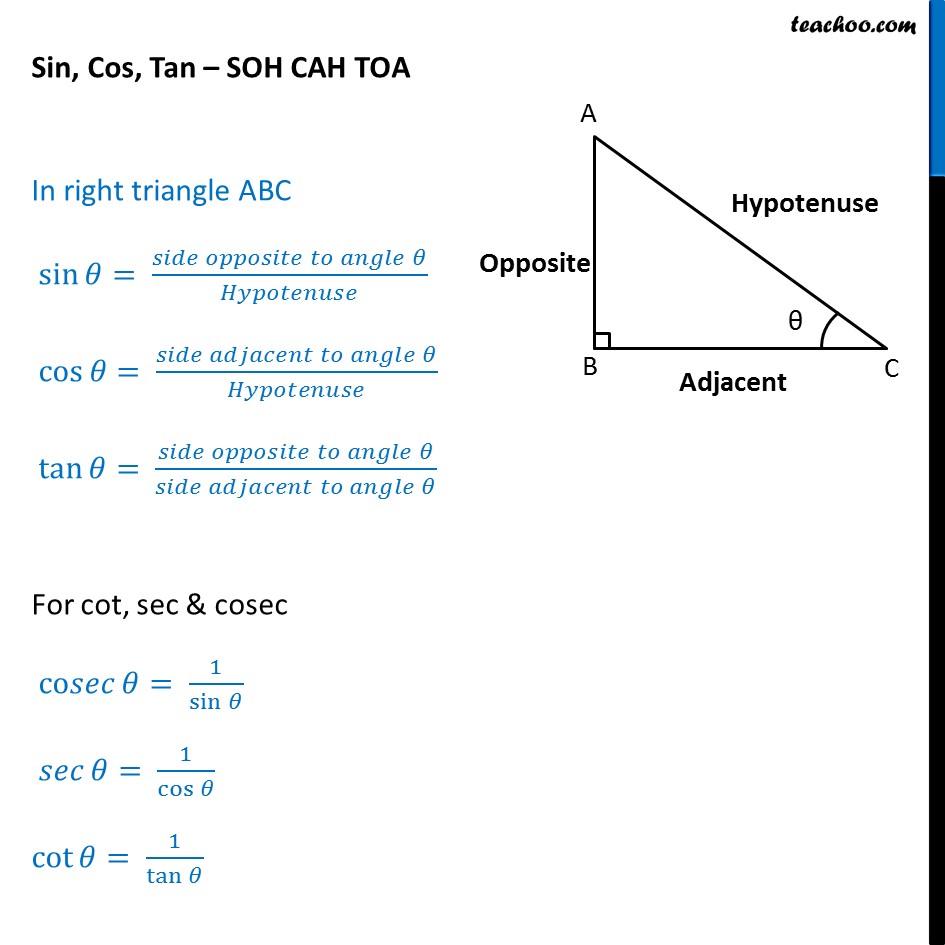
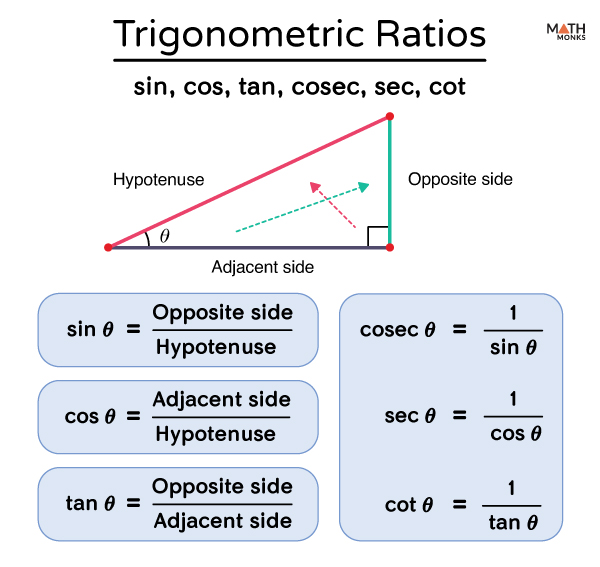
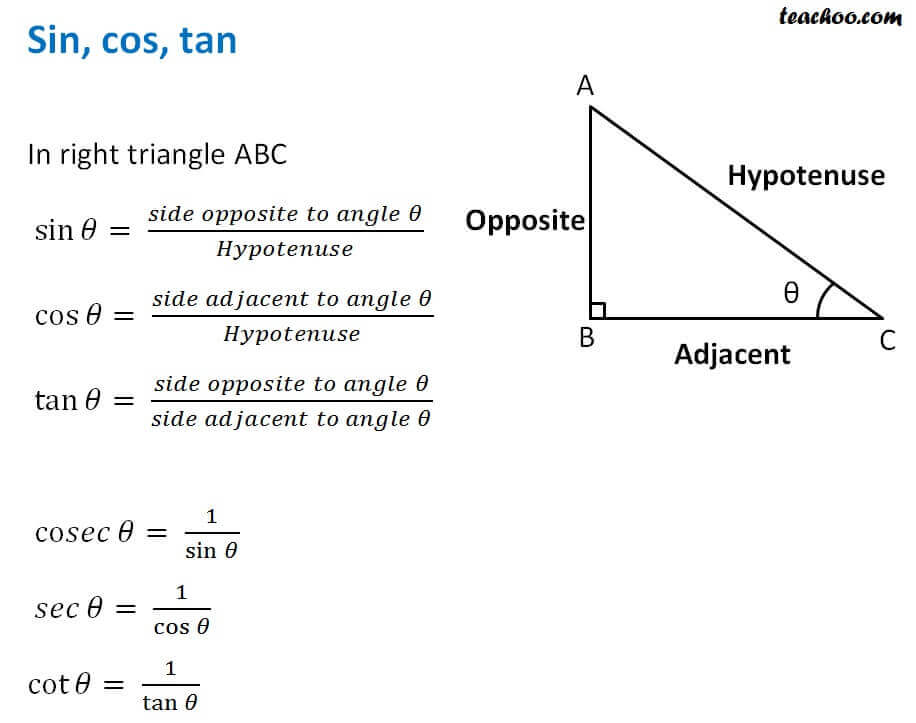
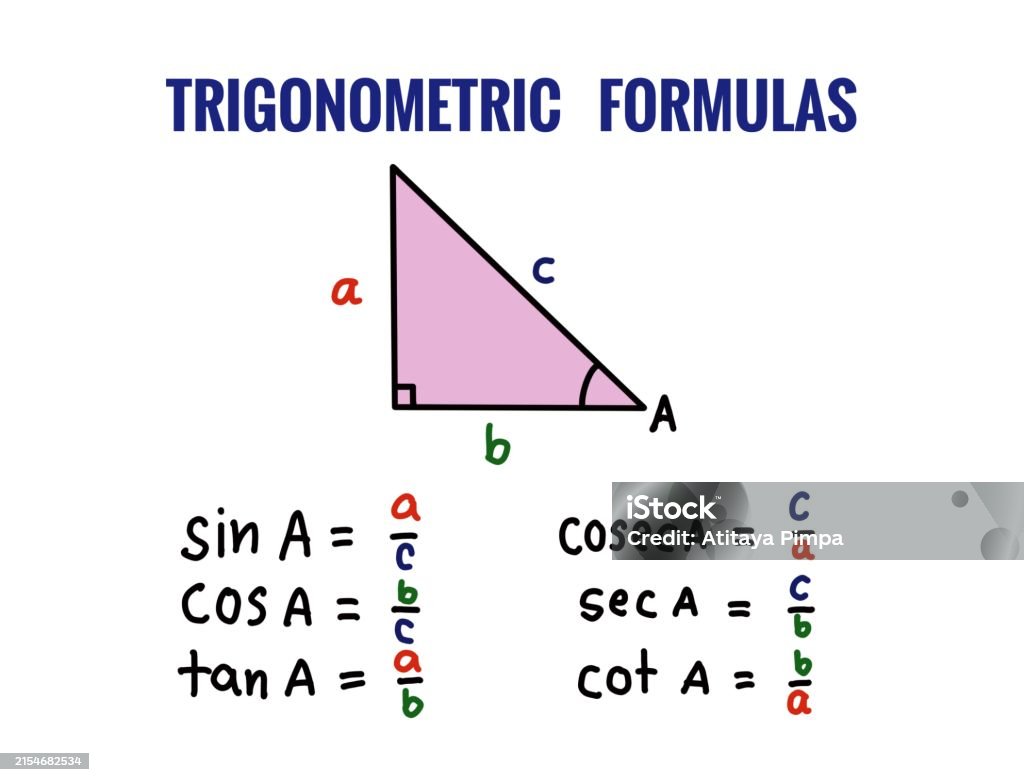
I spent about three weeks last year debugging a drone flight controller where the altitude estimates were drifting by nearly two meters over a kilometer of forward travel. The root cause wasn't the IMU or the GPS fusion — it was a single integer overflow in the sine lookup table inside the pitch compensation routine. Someone had hardcoded approximations for sin and cos using a Taylor series truncated at the fourth term, which is fine for small angles, but when you're banking at 30 degrees and climbing at 15, those truncation errors compound across the entire flight envelope. I rewrote the lookup to use a precomputed 360-entry LUT with linear interpolation between values. Cut the drift from two meters down to about eight centimeters. The lesson here isn't dramatic, it's just that trigonometric functions are everywhere in embedded systems and the approximations you choose matter more than you'd think. The core formulas — sin, cos, tan — are simple definitions but they're also where a lot of practical mistakes happen. Let me explain how they actually work under the hood rather than just giving you the textbook definitions. When you see SOHCAHTOA, that's just a memory aid for right triangles. Sine equals opposite over hypotenuse, cosine equals adjacent over hypotenuse, tangent equals opposite over adjacent. But the reason these matter beyond high school geometry is that they describe periodic behavior, and periodic behavior shows up in literally everything that moves, vibrates, rotates, or signals.
The Secret Language Of Triangles How Sin Cos And Tan Formulas Power Our World
Consider a radio antenna array. To steer a beam without physically moving the dish, you phase-shift the signal going to each element. That phase shift is calculated using trigonometric relationships. A base station tower with four elements steers its coverage sector by applying cos and sin values to weight the signals. The math is straightforward: if your element spacing is d and you want to steer to angle theta, the phase shift is 2*pi*d*sin(theta)/lambda. Lambda is wavelength. That's it. But get the spacing wrong — if d is greater than half a wavelength — you get grating lobes, which are unwanted secondary beams that point in the wrong direction and waste power while potentially interfering with other cells. I've seen this happen in a small cellular deployment where someone copied a 5G massive MIMO design for a 4G upgrade without recalculating the element spacing for the lower frequency band. The grating lobe was pointing at a residential area about two kilometers off-axis. Coverage in the intended direction actually dropped because power was leaking into that stray beam. Recalculating with the correct lambda for the 4G band fixed it. Now let me walk through the actual computation, because most people stop at the definition and never think about how these values are generated inside a processor. A CPU or GPU doesn't have a sin button. It approximates. The most common approach in hardware is the CORDIC algorithm — COordinate Rotation DIgital Computer. It's an iterative method that rotates a vector through small angles using only shifts and adds, no multiplications required. That's why it's still used in microcontrollers and FPGAs where a full multiply unit would be overkill. On a desktop CPU, you'll typically see a polynomial approximation, often a minimax polynomial tuned to minimize the maximum error across the domain. The glibc sin function, for example, uses a range reduction step followed by a polynomial evaluation that gives about 1 ULP of error. One unit in the last place. That's incredibly precise for something that's essentially a lookup with interpolation. Here's a practical example that isn't in most textbooks. You're working on a CNC machine tool and you need to move the spindle along a path that's at a 37-degree angle to the X axis. The motor controllers expect separate X and Y commands. You compute X = distance * cos(37°) and Y = distance * sin(37°). But if you're using a cheap mcu with a software floating-point library, cos(37°) might take 50 microseconds on a chip that's supposed to be updating the servos at 10 kilohertz. Fifty microseconds per axis, two axes, plus the rest of your control loop — you're already struggling to hit your update rate. The workaround I used was to table-lookup the cos and sin values for angles in one-degree increments, storing about 360 float pairs. That's 720 floats, roughly 2.8 kilobytes of memory. For a system with 64 kilobytes of RAM, that's negligible. The lookup took about 200 nanoseconds instead of 50 microseconds. Two orders of magnitude faster. You lose precision at the non-integer angles between your table entries, but you can interpolate between adjacent entries and get back to sub-degree accuracy without the CPU penalty.
Tangent is the function most people encounter first and misunderstand most often. It's undefined at 90 degrees and 270 degrees. In practice, this means if you're building a system that computes angles from velocity components — say a boat's GPS gives you northward and eastward speed and you want the heading — you use atan2(y, x), not atan(y/x). The difference matters. atan2 handles all four quadrants correctly and deals with the edge case where x is zero without throwing a divide-by-zero exception. I once wrote a navigation filter that used plain atan instead of atan2 because I was in a hurry and didn't think about the quadrant issue. The heading jumped from 359 degrees to 180 degrees every time the boat crossed the negative X axis. Took me two days to trace it back because the jump looked like a GPS glitch until I checked the code. There's also the identity side of things that people skip. The Pythagorean identity sin²(theta) + cos²(theta) = 1 isn't just a neat fact — it's a constraint you can use to validate your computations. If you're implementing a custom trig routine and sin² + cos² at the end doesn't equal 1 within your expected tolerance, something went wrong. I use this check in simulation code all the time. It catches rounding errors that would otherwise manifest as energy appearing or disappearing in a physics simulation, which looks like a bug until you realize you're just losing precision over many iterations. Same thing with the angle addition formulas: sin(a + b) = sin(a)cos(b) + cos(a)sin(b). These come up constantly in signal processing when you're mixing frequencies or doing frequency translation in a software-defined radio. One more thing that isn't obvious: the relationship between degrees and radians. Every trig function in computing assumes radians. If you pass degrees directly into sin or cos on any standard library, you'll get wrong answers and it will look like a bug in the math. The conversion is theta_radians = theta_degrees * pi / 180. Pi is approximately 3.14159265359. I keep a constant precomputed to 20 digits in my code because I've seen projects where someone used 3.14 and got acceptance testing failures on precision-sensitive simulations. The error seems tiny but it accumulates.
Get the Full Details

The formulas power everything from the gyroscope compensation in your phone to the beamforming in 5G base stations to the path planning in autonomous vehicles. They're not glamorous but they're fundamental, and understanding how they work computationally rather than just memorizing SOHCAHTOA is what separates someone who can use trigonometry from someone who can debug it when it breaks in production.