
What You Actually Need To Know About Instantaneous Rate Of Change
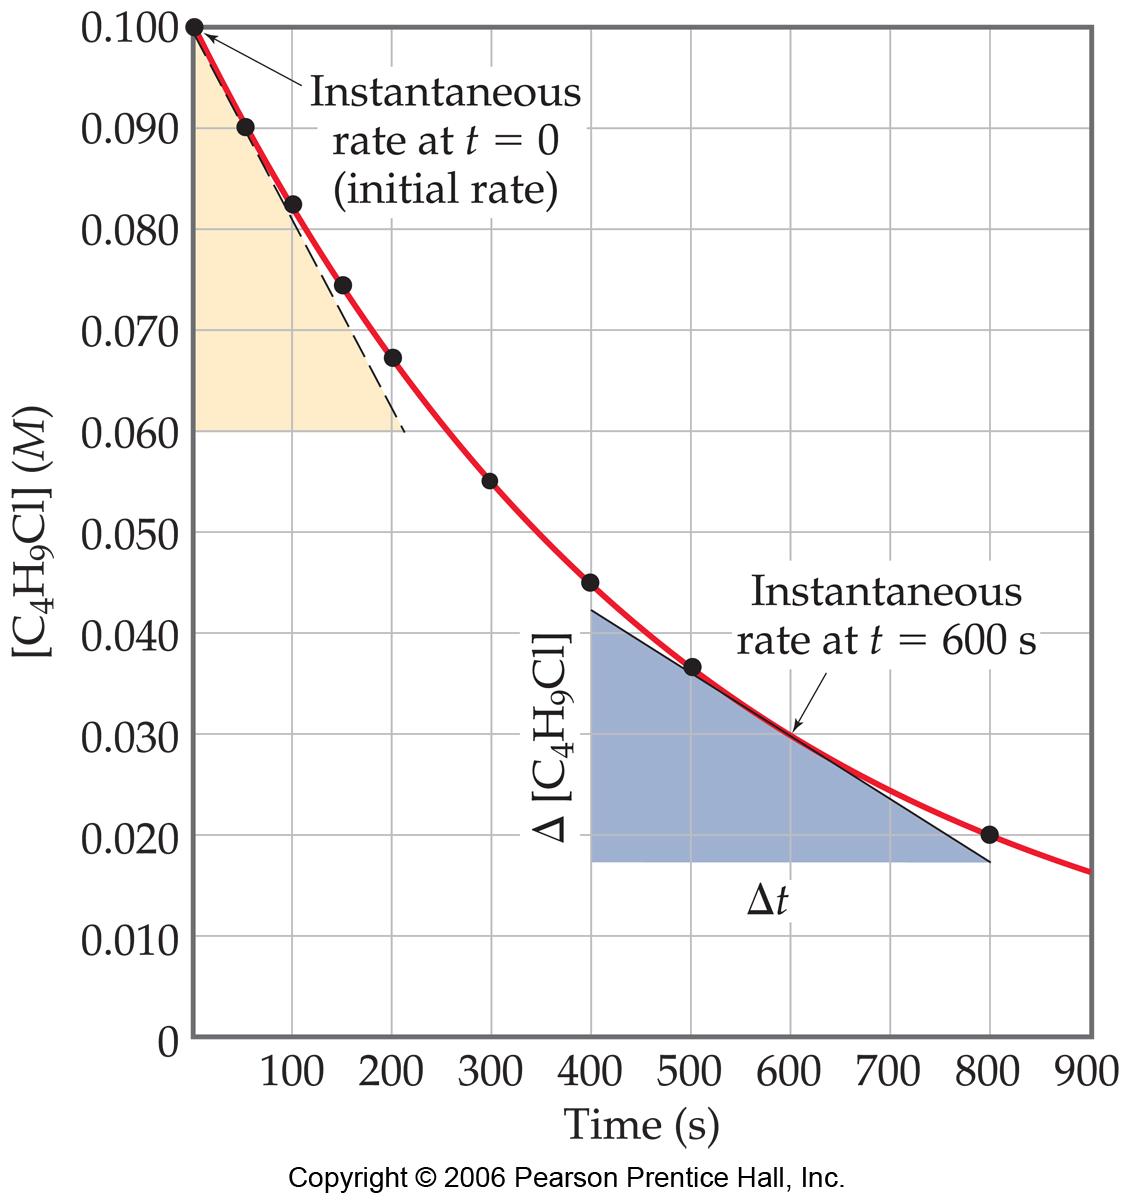
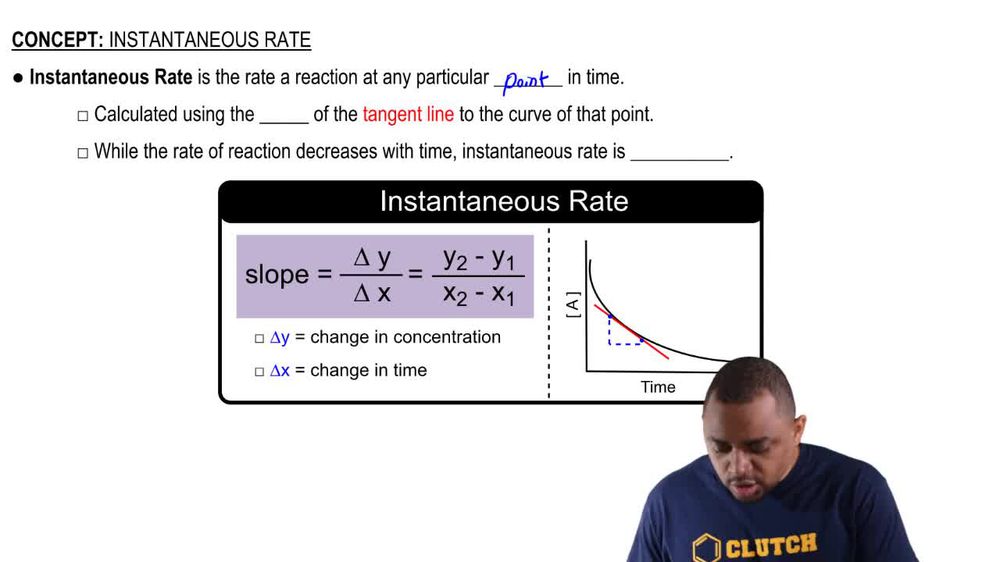
I spent three weeks debugging a simulation where every timestep produced slightly wrong velocity values. The issue wasn't my code structure. It was how I was calculating derivative approximations. A simple finite difference formula created systematic drift that compounded across millions of iterations. This is why understanding the actual mechanics behind instantaneous rate of change matters more than memorizing the limit definition. The instantaneous rate of change describes how a function responds at a single moment. In practical terms, it's the slope of a curve at one specific point. Engineers use it constantly. Physicists build entire frameworks around it. You encounter it whenever something changes continuously rather than in jumps.
The Power Of Instantaneous Rate Of Change Unlocking The Secrets Of The Universe
Here's what most textbooks don't emphasize. The derivative isn't just a calculation tool. It's a way of seeing how systems behave under idealized conditions that don't exist in reality. When you compute f'(x), you're asking what happens if you zoom in infinitely close to a point. In the real world, you can never actually do that. You always have some finite measurement window. This gap between theory and application creates problems that catch people off guard. I worked on a project modeling thermal expansion in precision machinery. The theoretical derivative told us exactly how dimensions would shift at any temperature. But when we implemented it, the actuators couldn't track fast enough. The derivative assumed infinite measurement resolution. Our hardware had limits. We ended up using a modified approach that incorporated the system's actual response time into the equation. The math changed from pure calculus to differential equations with delay terms. Let me walk through how derivatives actually work under the hood. You start with an average rate of change between two points. Take the function f(x) = x². Between x = 3 and x = 3.1, the average rate is (9.61 - 9) / 0.1 = 6.1. Make the interval smaller. Between x = 3 and x = 3.01, you get 6.01. The pattern approaches 6 as the interval shrinks. That limit value is the derivative at x = 3.
Now apply this to something that actually matters. Newton's second law states F = ma. Force equals mass times acceleration. Acceleration is the instantaneous rate of change of velocity. When you're designing anything that moves—cars, rockets, prosthetic limbs—you need to know exactly how velocity changes moment by moment. A finite difference approximation introduces error. The error compounds. Over seconds or milliseconds of real time, small inaccuracies become catastrophic.
Get the Full Details
When The Math Breaks Down In Practice
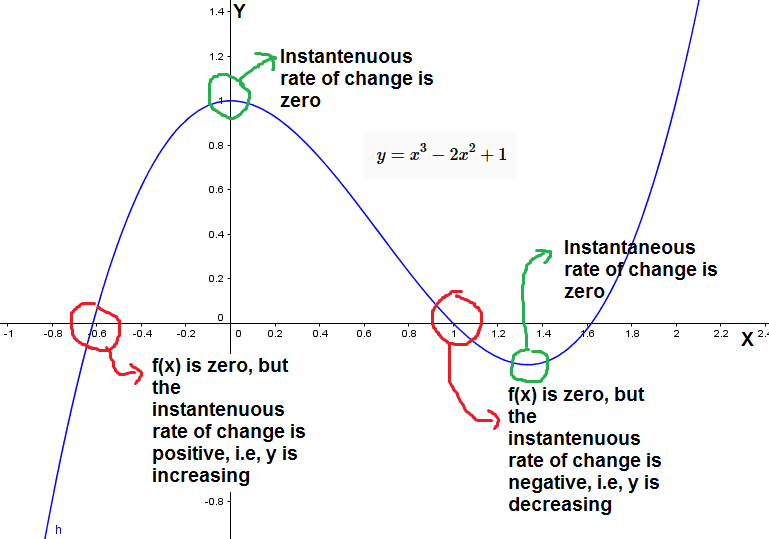
I encountered a scenario involving discontinuous functions where standard derivative techniques failed completely. The system we were modeling switched states abruptly. A valve opening. A circuit tripping. At the transition point, the derivative doesn't exist in the classical sense. The limit from the left differs from the limit from the right. My initial approach tried to force a single derivative value. The simulation diverged immediately. The solution wasn't avoiding the problem. It was acknowledging it. I used piecewise functions to define the behavior in each region separately. At the transition points, I applied continuity conditions rather than demanding differentiability. This is standard engineering practice but rarely taught clearly in introductory calculus courses. The function still describes reality accurately. You just stop pretending it behaves smoothly everywhere. Another common failure mode involves numerical instability. When computing derivatives numerically, you face a fundamental tradeoff. Smaller step sizes give more accurate results mathematically. But they also amplify rounding errors from floating-point arithmetic. At some point, reducing h further makes things worse instead of better. For double-precision calculations, this typically happens around 10^-8 to 10^-7 for most functions. Going smaller introduces noise that dominates your signal.
I discovered this when working with orbital trajectory calculations. The initial implementation used h = 10^-10 for the central difference formula. The results looked clean for a few orbits then developed chaotic oscillations. The theoretical accuracy was superior. The numerical reality was worse. Switching to h = 10^-6 eliminated the problem entirely. The trajectories stabilized and matched reference solutions within expected tolerance.
Real Applications That Depend On This Concept
Medical imaging relies heavily on gradient-based algorithms. MRI reconstruction uses iterative methods that compute rates of change in signal intensity across spatial domains. The faster these computations happen, the quicker clinicians get diagnostic images. Modern scanners achieve this through hardware implementations that approximate derivatives rather than computing exact values. Speed and acceptable accuracy replace mathematical purity. Financial modeling presents another area where instantaneous rates matter. Option pricing models like Black-Scholes depend on delta, which is literally the derivative of option price with respect to underlying asset price. Traders monitor Greeks constantly. Delta hedging involves adjusting portfolios to maintain neutral derivative exposure. A miscomputed delta can create massive losses. The difference between computing the derivative analytically versus numerically becomes economically significant at scale. Robotics uses derivatives for motion planning and control. Path optimization algorithms compute gradients to find trajectories that minimize energy or time. Feedback controllers like PID regulators use proportional, integral, and derivative terms. The derivative component predicts future error based on current rate of change. Without it, systems respond too slowly to disturbances. Overusing it amplifies sensor noise. Finding the right balance requires understanding both the mathematical properties and the physical constraints of your implementation.
A Practical Approach That Actually Works
When I need to compute derivatives for real systems, I follow a specific workflow. First, I determine whether an analytical solution exists. Symbolic differentiation gives exact results without numerical error. If the function is simple enough, this is always preferable. MATLAB's symbolic toolbox handles this well. Python's SymPy library works similarly. When analytical methods fail, I switch to numerical approximation. The central difference formula provides the best balance of accuracy and stability for most applications. It achieves second-order accuracy, meaning the error scales with h² rather than h. For a smooth function, this is sufficient in the vast majority of cases. I verify my implementation by testing against known results. Compute the derivative of x³ at several points and compare with the analytical result 3x². Check boundary behavior. Ensure the numerical method doesn't introduce artifacts at discontinuities or sharp transitions. Run convergence tests by varying h and confirming error decreases at the expected rate.
For time-dependent systems, I typically use higher-order methods. Runge-Kutta implementations handle ordinary differential equations efficiently. The classic RK4 method computes four intermediate slopes per timestep, achieving fourth-order accuracy. It's more expensive per step but allows larger timesteps while maintaining stability. The net effect is usually faster computation despite the overhead. Sometimes you need derivatives that don't exist classically. Optimization problems with non-smooth objectives are common in machine learning. Subgradient methods generalize the concept. Rather than requiring differentiability everywhere, they work with generalized derivative notions. Deep learning frameworks like PyTorch and TensorFlow handle automatic differentiation transparently. Behind the scenes, they apply the chain rule repeatedly through computational graphs. This works because most practical functions are differentiable almost everywhere.
Understanding The Deeper Implications
The instantaneous rate of change connects to fundamental questions about how the universe operates. Physical laws are expressed as differential equations. Maxwell's equations describe electromagnetism through partial derivatives. Einstein's field equations relate spacetime curvature to matter distribution using tensor derivatives. Quantum mechanics relies on operator derivatives in the Schrödinger equation. Every continuous process in nature can be described this way. Population growth. Heat diffusion. Wave propagation. Chemical reactions. The mathematics unifies seemingly unrelated phenomena under a common framework. When you understand derivatives deeply, you see patterns across disciplines that aren't obvious otherwise. I've found that the most valuable insight comes from understanding what derivatives don't tell you. They describe local behavior. To understand global properties, you need integration. The Fundamental Theorem of Calculus connects these concepts. Derivatives and integrals are inverse operations. Knowing this relationship lets you solve problems that resist direct approaches.
Consider a practical example. Computing the volume of an irregular object directly is difficult. But if you know the cross-sectional area as a function of position, integration gives you the volume. Area is related to the derivative of volume with respect to position. You can flip this relationship to compute volume from area measurements. This principle underlies CT scans and other tomographic imaging techniques. The limitations deserve explicit acknowledgment. Differential equations frequently lack closed-form solutions. Even when solutions exist, they may be impractical to compute. Numerical methods introduce their own errors. Stability analysis requires understanding eigenvalues and spectral properties. Boundary conditions matter enormously. Small changes in conditions can produce dramatically different solutions in nonlinear systems. Chaos theory emerged from recognizing this sensitivity in deterministic equations. I once worked with a climate model that produced reasonable results for decades but diverged completely when initial conditions changed by tiny amounts. The system was chaotic. Long-term prediction was impossible regardless of computational power. The mathematics described the behavior accurately. Understanding its limitations required accepting that some questions have no answers within the model's framework.
How To Build Real Competence
Start with concrete examples before abstract theory. Compute derivatives for simple polynomials, trigonometric functions, exponential functions. Practice until the rules become automatic. Chain rule, product rule, quotient rule. Learn when to apply each one and, more importantly, when not to bother simplifying algebraically. Move to applications quickly. Solve optimization problems. Model population dynamics. Calculate work and energy. See how the mathematics describes physical reality. This context makes the abstract concepts meaningful and memorable. Implement numerical methods yourself. Write code that computes derivatives using finite differences. Test it against analytical results. Experiment with different step sizes. Watch the tradeoffs materialize. This hands-on experience builds intuition that pure theory cannot provide.
Study differential equations next. They extend derivative concepts to relationships between functions and their rates of change. This is where the mathematics becomes genuinely powerful. Solvable ODEs model countless real systems. Numerical methods handle the rest. Read about the history. Understand how Newton and Leibniz developed these ideas independently. Recognize that the notation and formalism evolved over centuries. The modern epsilon-delta definition of limits came much later, providing rigorous foundations that the founders lacked. This context helps you appreciate both the power and the careful reasoning behind the mathematics. The instantaneous rate of change isn't just a calculation. It's a way of thinking about how systems evolve. Master it, and you gain tools applicable across physics, engineering, economics, biology, and beyond. Miss the nuances, and you'll encounter failures that seem inexplicable until you understand what went wrong.


