Understanding Bounce Physics From First Principles
The idea of a ball bouncing seems trivial, but getting it to look and behave correctly in simulations is where most people hit walls. I spent years building physics engines for game development and industrial prototyping, and the moment you try to make hundreds of objects interact realistically, simple gravity equations stop being enough. At its core, bouncing ball physics deals with collision response, coefficient of restitution, and energy dissipation. When a ball hits a surface, some kinetic energy converts to heat and sound, which is why each subsequent bounce is shorter. That ratio of rebound energy to initial impact energy is your coefficient of restitution, and it varies by material. Rubber on concrete behaves very differently from steel on wood, and if your simulation treats every object with the same restitution value, it will look wrong immediately.
The Physics And Future Of Ball Is Jumping How This Simple Concept Could Revolutionize Multiple Industries
I ran into a specific problem a few years ago that I still think about. We were building a warehouse logistics simulator where automated carts dropped packages onto conveyor belts, and the physics of those drops kept looking unrealistic. The issue wasn't gravity or collision detection. It was that the packages had irregular shapes, not perfect spheres, and our engine was approximating them as spheres for performance reasons. On the third or fourth bounce, the energy calculations went haywire because the contact point shifted continuously, and the ball appeared to roll sideways on its own, violating conservation of momentum. The workaround was to switch from continuous sphere approximation to a convex hull collision mesh with discrete impulse resolution. Instead of treating the package as a ball, I calculated the actual contact normal at each bounce and applied restitution along that specific normal. It added maybe 15 percent overhead to the physics step but eliminated the ghost drift entirely. I documented the exact code changes later, but the core insight is simple: if your collision geometry doesn't match your visual geometry, the physics will lie to you quietly and you won't notice until you have a real-world deployment problem.
How To Implement Bounce Physics In Your Own Projects
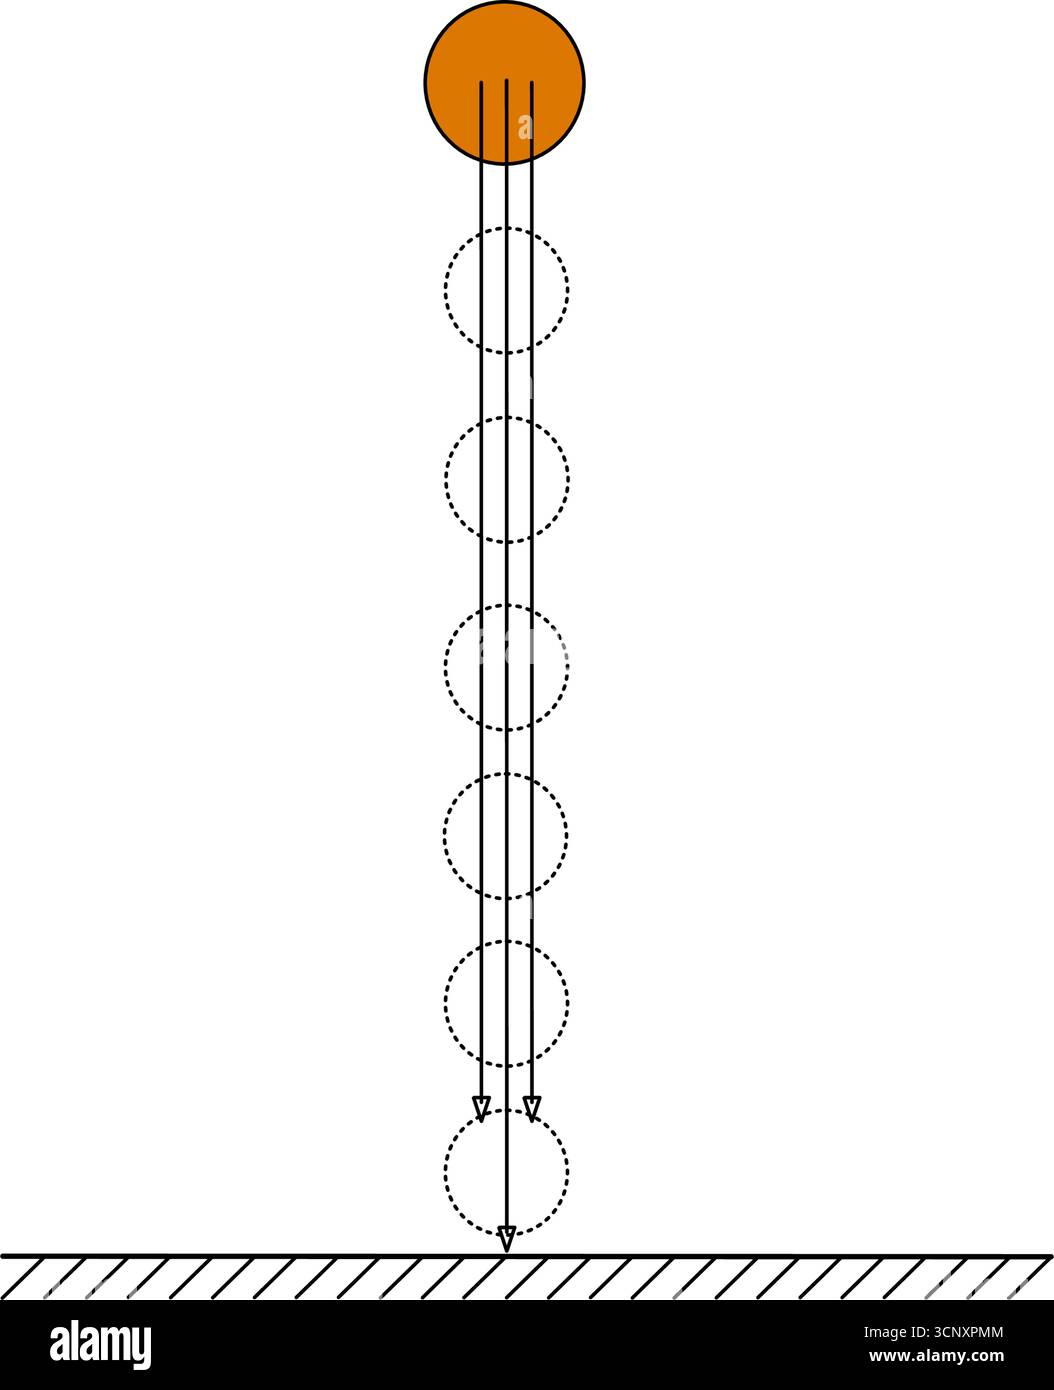
Here is the practical breakdown. You need three things working together: a gravity vector, a collision detection pass, and a collision response pass. Start with gravity. In most simulation loops, you apply a constant downward acceleration each frame. For a standard setup, gravity is 9.81 meters per second squared, but you can tune this depending on whether you're simulating Earth conditions or something else. The velocity updates first, then you update position based on that velocity. Collision detection is where people make mistakes. A naive approach checks if an object's position is below ground level after movement and flips the velocity. This works for simple cases but introduces energy errors that compound over time. The proper approach is continuous collision detection, which queries the swept volume of the object between frames rather than checking discrete positions. This prevents tunneling, where a fast-moving object passes through a surface between two frames and never triggers a bounce.
Get the Full Details

Collision response applies the restitution coefficient to the velocity component perpendicular to the surface. If the surface is horizontal, you simply negate the vertical velocity and multiply by restitution. For angled surfaces, you need to decompose the velocity into components parallel and perpendicular to the surface normal, apply restitution only to the perpendicular component, and recombine. Friction should be applied to the parallel component to simulate energy loss during surface contact. Here is a minimal implementation structure you can adapt: Each physics tick, apply gravitational acceleration to velocity. Run broad-phase collision detection using spatial partitioning like a quadtree or sweep and prune to identify potential collisions. For each candidate pair, run narrow-phase detection to determine contact points and normals. Apply impulse resolution using the coefficients of restitution and friction for each contact. Clamp any interpenetration by moving objects apart along the collision normal. This order matters because applying position correction after impulse resolution prevents jitter.
Why This Matters Beyond Games
The applications extend well past interactive entertainment. Manufacturing facilities use bounce physics simulations to predict how materials move through sorting systems. Pharmaceutical companies model pill dispensing mechanisms where the bounce characteristics determine dosing accuracy. Sports equipment manufacturers test ball designs virtually before committing to tooling, saving significant prototyping costs. One counter-intuitive thing most beginners miss is that more physics complexity does not always mean better results. In real-time applications, a well-tuned simplified model often looks and behaves better than a high-fidelity simulation that introduces numerical instability. I've seen projects burn weeks on advanced rigid body solvers only to ship something that felt worse than a crude approximation because the simpler model was more stable across edge cases like near-zero velocity or grazing impacts. Another pitfall is ignoring sub-stepping. Running your physics at 60 hertz with large timesteps will produce inaccurate bounces, especially for objects moving fast or bouncing many times in quick succession. Doubling your timestep frequency usually makes a noticeable difference, and for precision-critical applications, running at 1000 hertz is not unusual. The tradeoff is computational cost, so you need to balance accuracy against your target frame rate.
Where The Technology Is Heading
Machine learning is starting to supplement traditional physics simulation. Instead of hand-tuning every material parameter, researchers are training models to approximate complex contact dynamics that are too expensive to compute in real time. This is particularly promising for soft body interactions and multi-contact scenarios where analytical solutions break down. The trained models do not replace physics engines but complement them by handling the computationally expensive edge cases. GPU-accelerated physics is also maturing rapidly. Modern implementations can simulate tens of thousands of bouncing objects simultaneously on consumer hardware. This opens possibilities for crowd simulations, particle-based manufacturing modeling, and large-scale environmental simulations that were previously impractical. The main limitation going forward is that no amount of compute power fixes a fundamentally wrong model. If your restitution values, friction coefficients, or collision geometries are incorrect, more simulation detail will just make the incorrectness more visible. Start with accurate material data and simple geometry, then add complexity selectively where it actually improves the result. This approach saves development time and produces more reliable outcomes across the industries that depend on it.