Planes Are Boring Until You Try To Use Them
The first time I ran into trouble with a plane equation was in a graphics project where I needed to figure out whether a ray actually hit a triangle or passed just above it. The math on paper says a plane is all points (x, y, z) that satisfy ax + by + cz = d for some constants a, b, c, d. That sounds straightforward enough. Then you write the intersection test and suddenly you are multiplying three-component vectors and dividing by zero when the ray runs parallel to the surface. I learned the hard way that the normal vector (a, b, c) cannot be zero-length. If it is, the plane equation collapses and you end up testing against a nonsensical constraint. My workaround was to explicitly reject zero-length normals before computing anything and clamp the result to a valid unit normal when it existed. That saved me hours of debugging later.
The Meaning Of Plane In Math Unlocking The Flat Surface That Defines Space
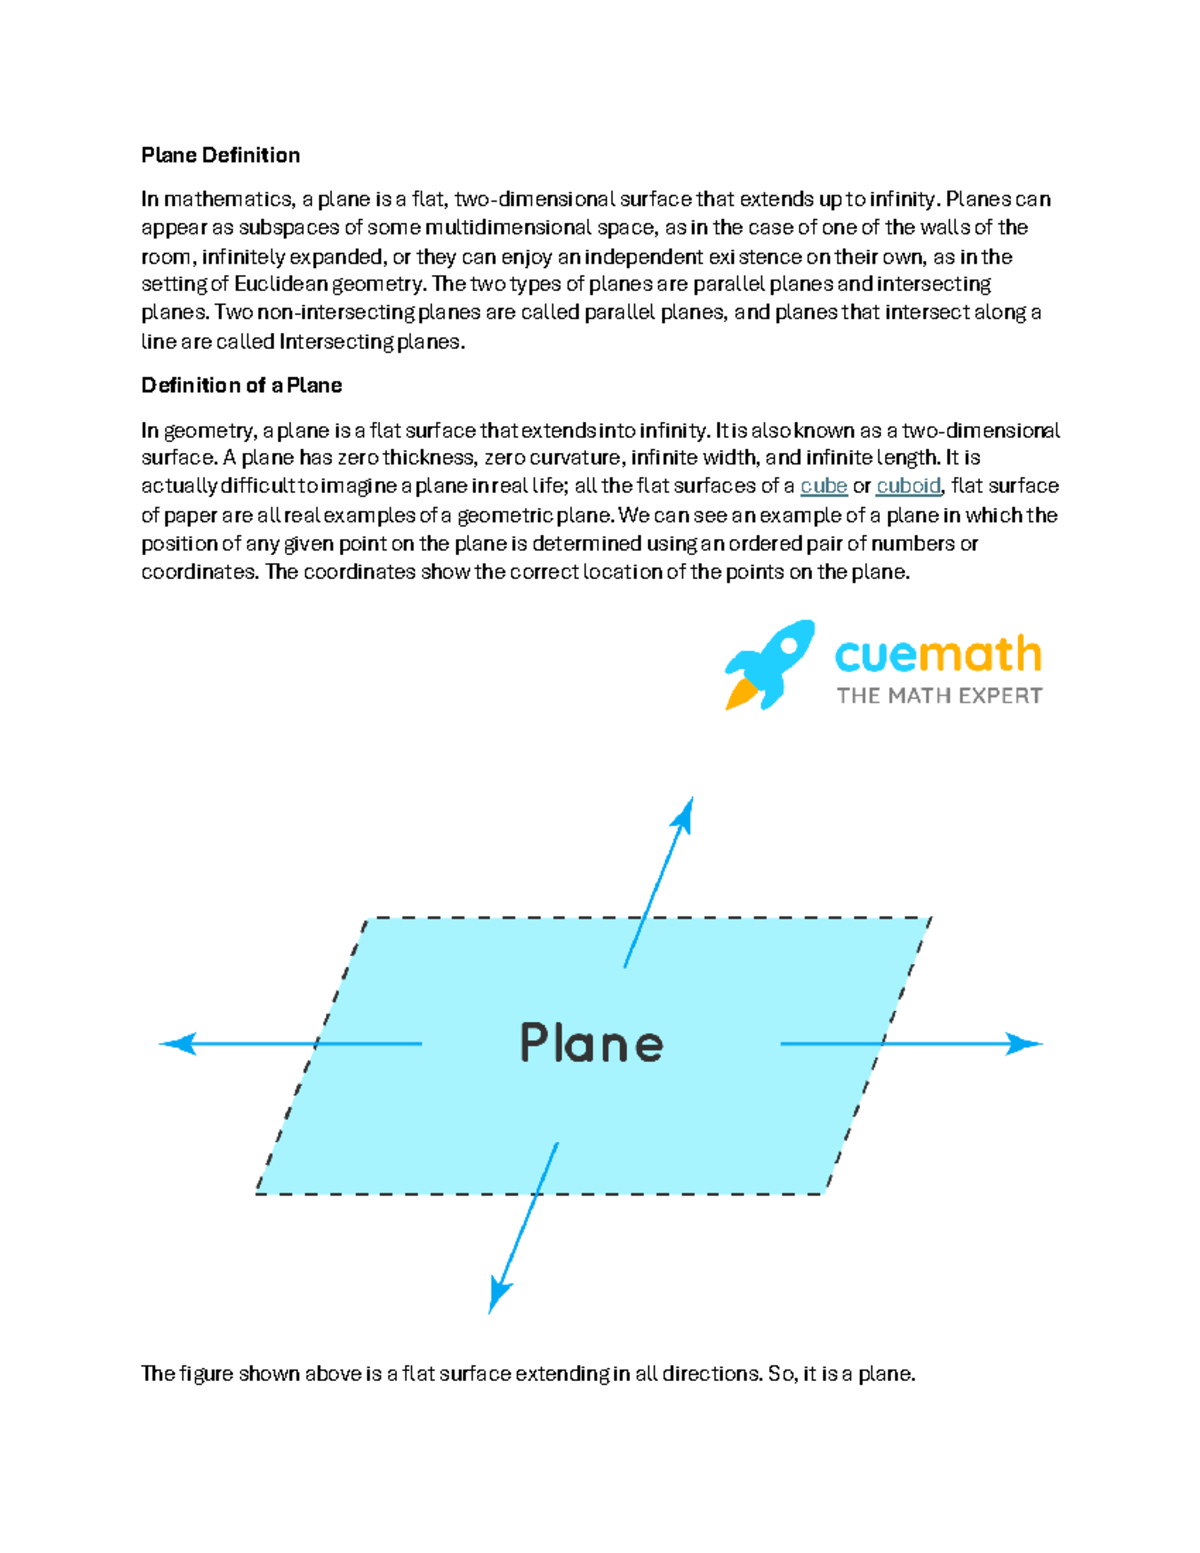
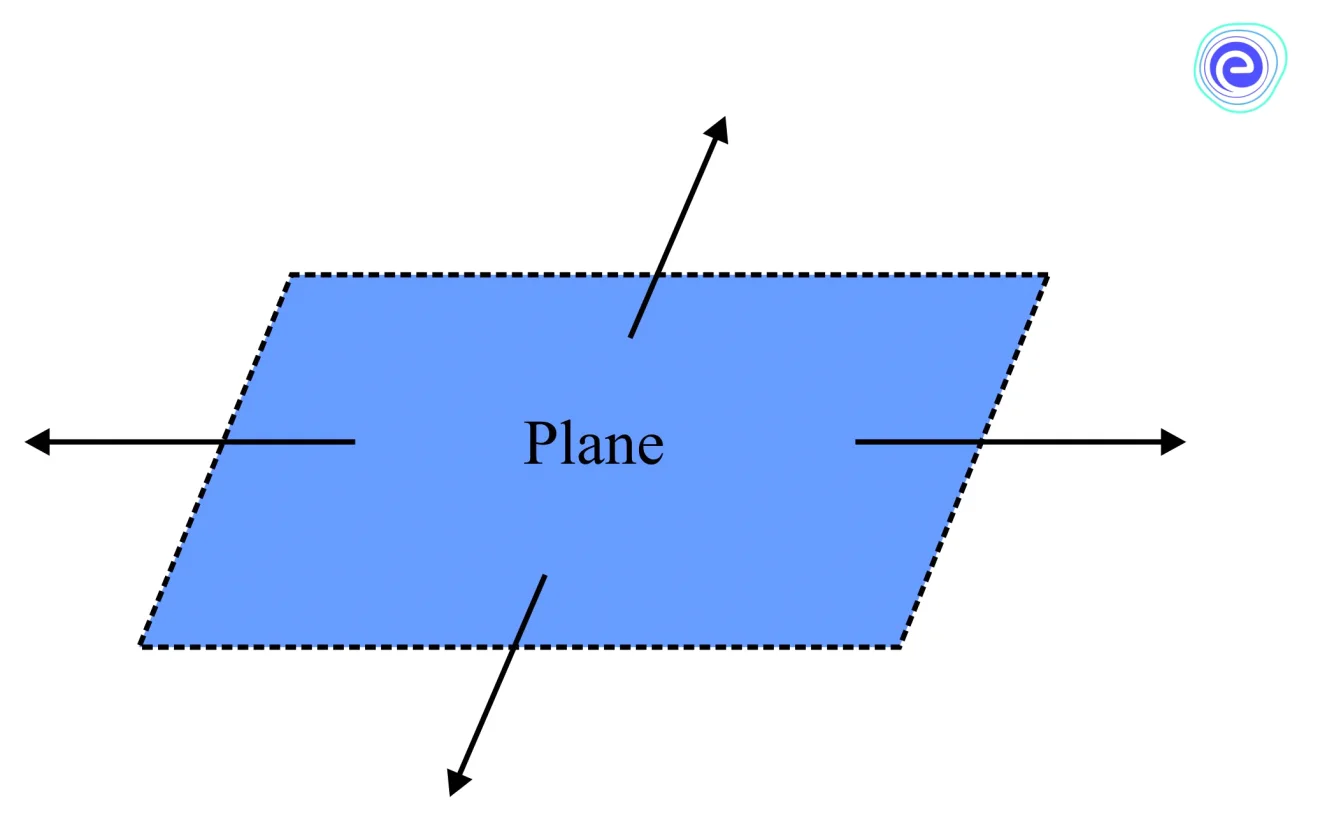
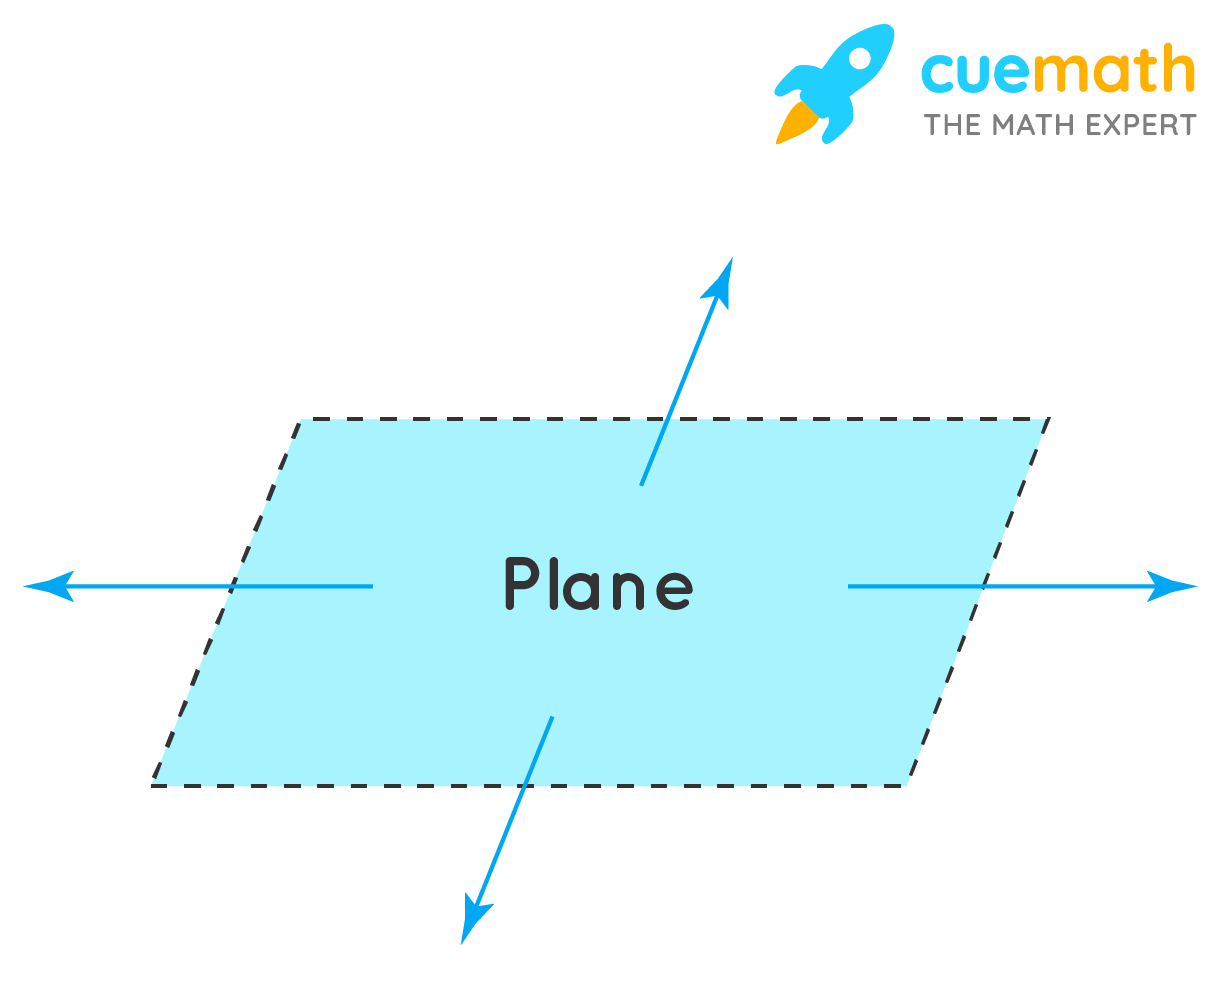
In geometry a plane is a two-dimensional flat surface that extends forever in every direction. Unlike a polygon, it has no edges, no boundary, and no thickness. When you introduce it into three-dimensional space, it splits the room into two half-spaces: one where ax + by + cz > d and another where ax + by + cz
d. This separation is what makes planes useful in collision detection, rendering pipelines, and even basic CAD work. The point-normal form is ax + by + cz = d, where (a, b, c) is the normal vector and d is the signed distance from the origin scaled by the normal length. I prefer the implicit form over the parametric form because it gives me an immediate sign test. If the result is positive, the point is on one side. If it is negative, the point is on the other. That is enough for most quick culling tasks without building a full basis transformation. The parametric form uses two direction vectors u and v anchored at a base point P: any point is P + s*u + t*v for real scalars s and t. This is better when you need to interpolate inside the surface or generate samples. It is also the form most people see in computer graphics textbooks, which is why you will find it everywhere in tutorials. The tradeoff is that you have to normalize u and v if you want distances to be meaningful.
How To Work With A Plane In Practice
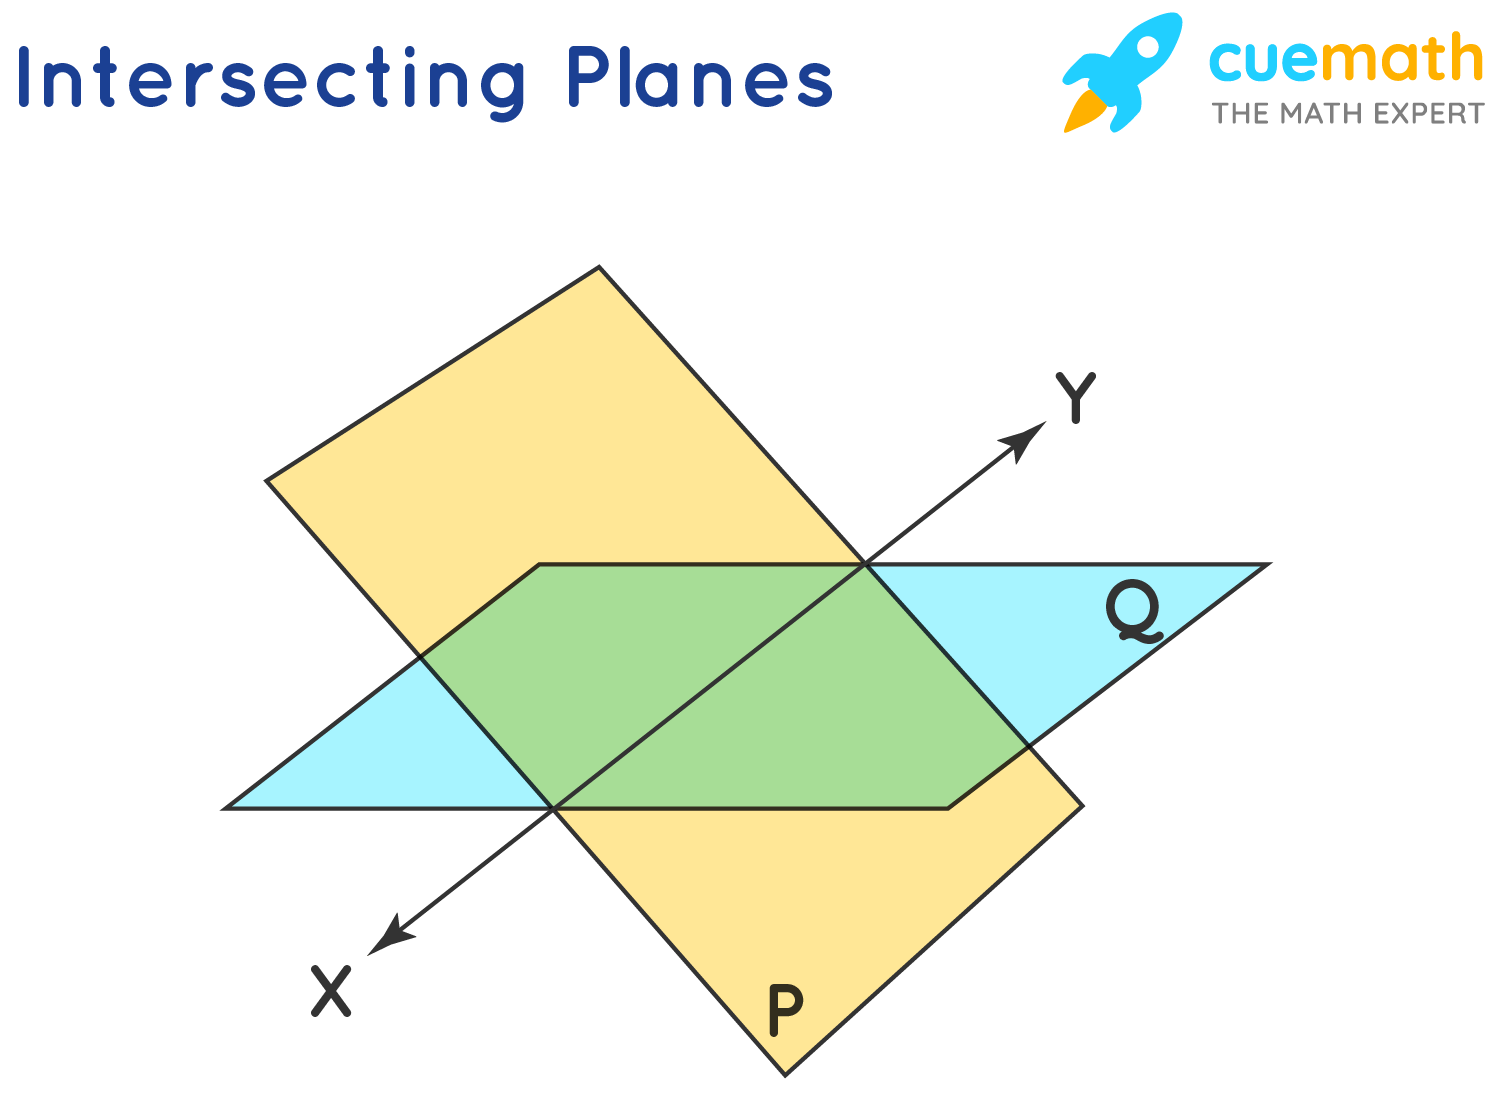
Most problems start with finding the distance from a point to a plane. The formula is |ax0 + by0 + cz0 d| / sqrt(a² + b² + c²). If you skip the normalization step, the distance value will be wrong and your collision threshold will drift. I usually precompute the normal's inverse length once and reuse it. That cuts the per-frame cost from a square root to a single multiplication, which adds up over thousands of points. Intersection with a line is another common task. Given a ray origin O and direction D, the parameter t at which the ray hits the plane is (d O·N) / (D·N). The denominator here is the dot product of the ray direction and the plane normal. If that dot product is near zero, the ray is parallel and there is either no intersection or the ray lies entirely in the plane. I handle the parallel case by checking if abs(dot) is below a small epsilon and returning failure instead of dividing. A common pitfall is assuming that two planes always intersect in a line. In parallel planes, they either do not intersect at all or coincide completely. The cross product of their normals tells you whether they are parallel. If the cross product has near-zero length, the normals are aligned and the planes are either identical or disjoint. This is why I always compute the cross product before attempting to solve for an intersection line.
Get the Full Details

Edge Cases That Break Naive Code
One problem I encountered was when a plane equation had floating-point drift after repeated transformations. If you rotate or translate a plane by composing matrices incorrectly, the normal can lose orthogonality and the distance term d can accumulate error. The fix is to re-orthogonalize the normal after each transform using Gram-Schmidt or a simple cross-product correction with a second basis vector. Another issue is the case of degenerate triangles in mesh processing. When three vertices are collinear, the plane they define is unstable because the cross product of two edge vectors becomes zero. I found that checking the squared length of the cross product before normalizing prevented the algorithm from producing garbage normals. If the squared length is below a threshold like 1e-12, I skip the triangle entirely. Some libraries expose plane constructors that take three points and compute the normal internally. Those are convenient but they hide the fact that the resulting normal may not be unit length. If you use the plane for distance tests without normalizing first, your results will be off by a factor equal to the normal's magnitude. I make a habit of verifying the length and normalizing immediately after construction.
When A Plane Is Not The Right Tool
Planes work well for half-space tests, ray intersection, and basic geometric culling. They fail when you need to model curved surfaces or when the surface is only defined over a bounded region. In those cases you should switch to parametric surfaces, implicit functions, or mesh representations. A plane assumes infinite extent, which means it cannot represent a finite face without additional clipping logic. If you are working in projects where precision matters, such as finite element analysis or computational geometry, you may find that plane-based approaches accumulate round-off error over many iterations. In those scenarios exact arithmetic or symbolic libraries can help, though they slow the code down significantly. I usually accept a small tolerance band around the plane instead of demanding exact containment. Another limitation is that a single plane cannot represent folds, corners, or non-planar topology. If your geometry includes bent surfaces, you will need multiple planes or a different representation entirely. I have seen people try to approximate curved meshes with planar patches, but the approximation error grows quickly as curvature increases. For high-quality results, stick to the native surface type.