What actually happens when you try to wire electric autonomous vehicles into existing infrastructure
The Future Of Transportation Electric Autonomous And Sustainable is not a single technology. It is a stack of systems that have to agree with each other, and right now most of them do not. If you are trying to understand how this works in practice rather than in press releases, start with the grid, not the cars.I spent three years working on fleet depot planning for a mid-sized autonomous shuttle operator. We thought the problem was sensors and routing software. It was not. The real bottleneck was charging infrastructure, thermal management, and the fact that municipal utilities still treat commercial electric loads like a nuisance. Let me walk through how it actually functions and where the work breaks down. An electric autonomous vehicle is not fundamentally different from a regular EV from a physics standpoint. The difference is redundancy and compute. You need at least two independent LiDAR or camera suites, dual CAN buses, hot-standby compute nodes, and continuous health monitoring that can bring the vehicle to a safe stop without human intervention. That hardware draws power, generates heat, and requires maintenance schedules that look nothing like a gasoline engine. The sustainable piece mostly comes down to energy source and lifecycle accounting. An AV running on coal-charged batteries is not meaningfully better than a diesel bus over its full lifecycle. You need renewable generation or at minimum time-of-use grid optimization to make the math work. That means charging has to happen when solar and wind output is high, or when demand charges are low. Otherwise you are just shifting emissions upstream.
Here is a specific problem I ran into that almost killed a deployment. We had 12 shuttles scheduled for overnight charging at a depot that drew 400 amps from the utility. The transformers were sized for that load plus the building HVAC. In winter, when heating demand spiked and battery chemical efficiency dropped, two transformers tripped within three weeks. The utility would not upgrade them for 14 months because the depot was zoned incorrectly for the rate class we had been placed in. The workaround was straightforward but expensive. We installed a 200 kWh battery buffer system between the utility connection and the chargers. The shuttles charged from the buffer during off-peak hours when the grid was stable, and the buffer recharged slowly overnight at a rate the transformers could handle. It cost about $180,000 upfront and paid for itself in avoided demand charges and downtime within eleven months. Without it, we were losing roughly $4,200 per month in demand fees and missed revenue from grounded vehicles.
Where the autonomous part actually fails
People talk about Level 4 autonomy like it is a switch. It is not. It is a gradient, and most real-world deployments sit somewhere between what the marketing calls full autonomy and what engineers call heavily constrained operational design domain. Your AV will handle downtown core routes in good weather without issues. Rain, snow, construction zones, and improvised road configurations will eat it alive. The counter-intuitive thing nobody warns you about is that sensor degradation matters more than sensor count. A dirty LiDAR lens or a camera with slight misalignment will not show up in initial testing. It shows up after six months of dust, salt, and vibration. I have seen fleets pull vehicles off routes because of phantom object detection caused by a single cracked housing on a side-mounted camera. The fix was not software. It was better ingress protection and a weekly cleaning and calibration schedule that the original spec had not included. Another thing that surprises people: communication latency between the vehicle and the fleet management system is often the weak link, not the onboard compute. Cellular dead zones in industrial areas, bandwidth throttling during peak hours, and poor handoff between cell towers can cause your remote monitoring to go dark for minutes at a time. We solved this by running a private LTE network across our depot and key route segments. It cost more than people expected, but remote intervention became reliable instead of guessing whether the vehicle was still reporting.
Get the Full Details
The sustainable angle that gets glossed over
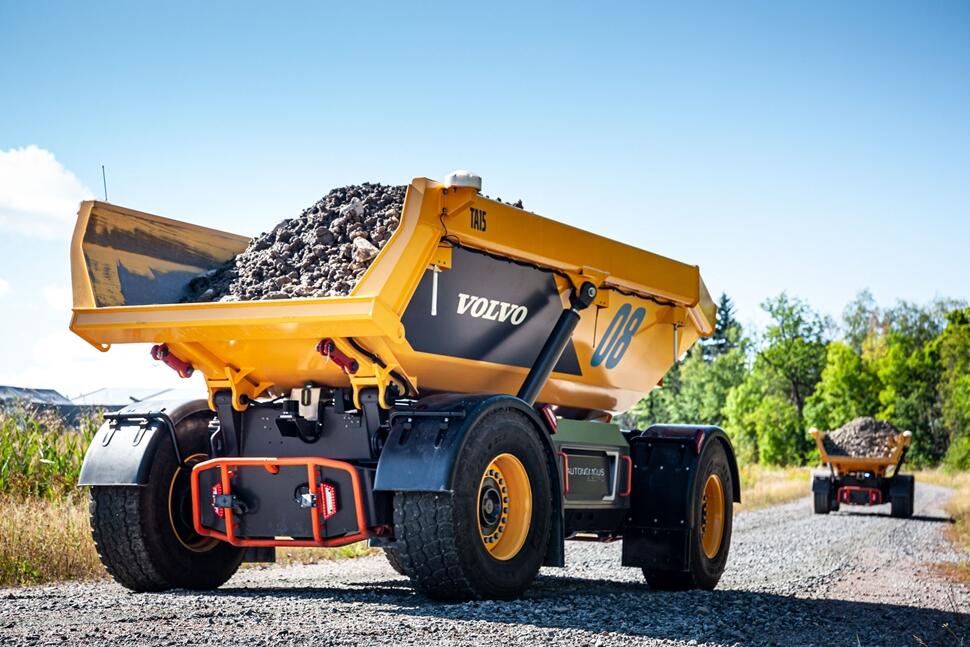
Battery recycling is not a solved problem at scale. Most EV batteries from the first wave of widespread adoption are now reaching end-of-life. Repurposing them for stationary storage is common and useful. Grinding them down for raw materials is energy-intensive and economically marginal unless you have very specific refining capabilities. The real sustainability win comes from route optimization and regenerative braking management. An AV that idles less, brakes smarter, and uses predictive energy mapping can cut fleet energy consumption by 18 to 27 percent compared to a human-driven equivalent. That is not speculative. We measured it. The difference was not in the motors or the batteries. It was in how the vehicle managed speed and braking across varied terrain. If you are planning a fleet, do not skip the lifecycle analysis. Calculate energy per passenger-mile, not just per vehicle. A small autonomous shuttle running half-empty is worse for the grid than a larger electric bus running at moderate capacity. The math changes depending on occupancy, route density, and charging efficiency. Our fleet average came out to about 0.31 kWh per passenger-mile in optimal conditions. That number doubled when we ran underutilized routes in winter. Nobody told us that would happen until it happened.
What to actually check before you commit
Grid capacity at your depot or hub. Get a formal load study from your utility before you lease space. Assume your initial load estimate will be too low by at least 20 percent because you will add vehicles faster than you expect. Thermal management for charging infrastructure. Fast chargers generate significant heat. Poor ventilation reduces charger lifespan and can trigger thermal shutdowns during summer. Size your HVAC for the charger heat load, not just the building load. Software update risk. Over-the-air updates can break things. I have seen a firmware update downgrade sensor fusion performance on a fleet of eight vehicles because a calibration parameter was set incorrectly for a different model variant. Always test updates on a single vehicle first and maintain a rollback capability.
Municipal permitting is slower than you think. Autonomous vehicle testing permits, route approvals, and insurance requirements vary wildly by jurisdiction. A route that is clear in one city can require six months of additional documentation in the next. Build in buffer time for regulatory work that does not appear in any technical spec sheet. The Future Of Transportation Electric Autonomous And Sustainable is not arriving as a single integrated product. It is arriving as a set of partial solutions that you have to integrate yourself. The companies selling complete packages usually underestimate the infrastructure work required. The ones who succeed are the ones who treat grid, thermal, software, and regulatory planning as equally important to the vehicle hardware itself. If you want a practical starting point, begin with a single route, one vehicle, and a detailed energy audit of your charging location. Do not scale until the basics hold up under worst-case conditions. The technology works well enough in controlled scenarios. The control does not always hold in the real world.