Charting the Wreck: What It Actually Takes
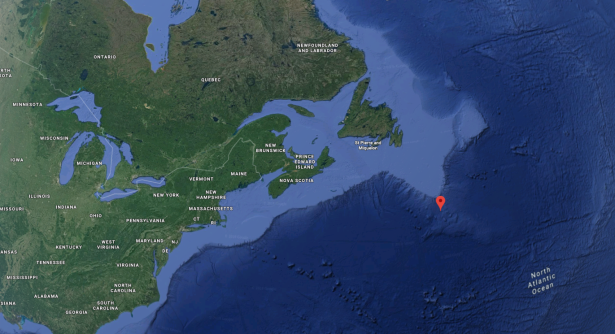
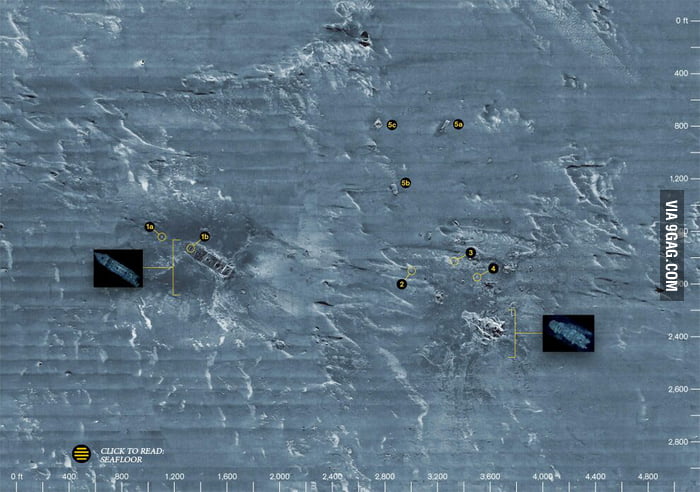
Locating and mapping the Titanic isn't a matter of dropping a pin on a chart and calling it done. The wreck sits in one of the most data-sparse stretches of the ocean floor, roughly 3,800 meters down off the coast of Newfoundland. Getting there and making a reliable record of the site requires combining several mapping techniques, because no single tool covers everything you need. The coordinates most people cite come from the 1985 discovery survey led by Robert Ballard's team at WHOI. The primary position they logged was around 41°43'55"N, 49°56'45"W, with a small margin of error that has been refined over subsequent surveys. That coordinate is a product of the navigation systems available at the time, which relied on Doppler and later GPS positioning. If you're working with those original survey data today, you'll want to be aware that the accuracy is limited by 1980s technology. Modern surveys using GPS-anchored positioning can do better, but the published position is still the standard reference point. The real work of charting the wreck began with sidescan sonar. The NOAA and Woods Hole teams used long-range acoustic imaging systems towed behind ships to scan the seafloor. The Titanic's bow and stern sections, separated by about 600 meters, showed up clearly as high-contrast targets against the sediment. Sidescan gives you texture and shape, but it doesn't tell you depth directly. For that you need multibeam bathymetry.
Multibeam sonar was used extensively in the mid-to-late 1990s during the 1987 and 1993 expeditions. It produces a gridded elevation model of the seafloor, which is what most people think of when they imagine a nautical chart of the wreck site. The resolution you get depends heavily on the vessel and the system. The Kongsberg-Simrad EM300 used in later surveys could produce ground resolutions in the range of a few tens of centimeters at that depth, which is good enough to resolve structural features but not detailed enough for small artifacts without supporting imagery. Photogrammetry is where the chart gets precise. Once you have a general map, you move to underwater cameras and video systems. The idea is simple: you take overlapping photographs from different angles and stitch them together into a three-dimensional model. This is how you get measurements like the length of the debris field, the dimensions of the boiler, or the position of a specific piece of hull plating relative to the main deck. The 2010 and 2019 expeditions used high-resolution camera systems mounted on ROVs to produce photogrammetric reconstructions that are now the most detailed visual records we have of the site. I've spent time working with similar deep-sea photogrammetry setups on shipwreck sites at shallower depths, and the same principles apply. The main challenge at 3,800 meters is not the water pressure on the equipment, it's visibility and data handling. At that depth, the light scattering is minimal but the particulate matter in the water column can still degrade image quality. You end up relying on artificial lighting, and the ROV's lights can create backscatter if you're not careful about positioning. I once spent two days trying to get usable stereo pairs on a different wreck because the current was stirring up fine sediment from the seafloor whenever the ROV hovered too long in one spot. The workaround was to use short bursts of video instead of continuous recording and to fly slightly above the bottom, angling the cameras downward rather than keeping them level. Same thing applies here, just amplified by the depth.
There's a common misunderstanding about what the Titanic's location chart actually represents. It's not a single static map. The site has been surveyed multiple times over four decades, and each survey produces a slightly different dataset. The debris field itself has changed. There is documented evidence of the wreck deteriorating over time due to bacterial corrosion, a process that accelerated after the initial discovery. The 1986 survey noted conditions that looked quite different from what was observed in 2004 and again in 2019. Any chart you use needs to be dated, and you should treat older surveys as historical records rather than current references. Another practical issue that people running their own surveys don't always account for is coordinate frame compatibility. The original 1985 position was recorded in a geodetic datum that's not perfectly aligned with modern WGS84. If you're taking those coordinates and plugging them into a modern GIS or charting system without applying a proper transformation, you'll be off by several meters. It might not sound like much until you're trying to register a sonar target to a specific point on a photogrammetric model. The fix is straightforward: always check what datum your source data uses and apply the appropriate shift. For North Atlantic deep-water work, NAD83 to WGS84 transformations are well documented and usually small, but they matter when precision is the goal. If you're looking to access the actual survey data, NOAA's National Centers for Coastal Science maintains a significant portion of the multibeam and sidescan sonar datasets from the Titanic expeditions. The data are available through their ERDDAP servers and can be downloaded in standard formats. The R/Moss Legacy program also released a complete archive of the 1986 footage and surveys. For the photogrammetric models, the data released by the Woods Hole Oceanographic Institution and subsequent imaging teams tends to be distributed through academic channels rather than a single public portal. You'll need to track down the specific publications and see what supplementary data the authors made available.
Get the Full Details

One thing the charts don't show well is the uncertainty in the positioning. Every sonar ping and every camera frame has some error associated with it, and at this depth the errors compound. Sound velocity profiles change with depth, temperature, and salinity, which affects how sonar travels and where the system thinks it's pointing. The water column at the Titanic site has a thermocline that shifts seasonally, and that can introduce small but measurable biases in the multibeam data. Most published charts smooth over these issues, but if you're doing any kind of quantitative analysis on the wreck's position or dimensions, you need to factor in the positioning uncertainty. It's usually on the order of a meter or two for well-constrained positions, but it can be worse in areas with limited GPS coverage or when relying on older acoustic navigation systems. The debris field itself extends roughly 2 kilometers in a northeast to southwest orientation, which aligns with the ship's final heading based on the impact trajectory analysis. Mapping the full extent of the debris requires systematic grid surveys rather than random exploration. You lay out parallel survey lines with enough overlap to ensure complete coverage, then process the data to create a unified map. The spacing between lines depends on the swath width of your sonar system, but for detailed work at this depth, line spacing of around 100 to 200 meters with 30 to 50 percent overlap is typical. That gives you clean coverage without unnecessary redundancy. For anyone actually planning a survey of the site, the biggest constraint is access. The Titanic sits on the International Seabed Authority's designated site, and access is tightly regulated. Permits are required from both the Canadian government and, under the 2000 agreement between the United States and Canada, coordinated oversight of the wreck site. You can't just send a submersible and start mapping. The permitting process alone can take years, and the cost of a deep-diving expedition is measured in the tens of millions. Most of the charting that has been done was funded by government agencies or large institutions with the budget and legal standing to operate at that depth.
If you're working from shore and trying to assemble a composite view of the wreck site using publicly available data, the process is more manageable. You'd pull the multibeam grids from NOAA, overlay the sidescan sonar mosaics, and then register the photogrammetric models to the acoustic data using common reference points like the wheelhouse, the bridge wing, or the anchor on the forward deck. These hard, identifiable features serve as control points that tie the different datasets together. The result isn't as clean as a purpose-built survey, but it's close enough for most practical purposes and it doesn't require a research vessel.