Rolling Without Slipping: What Actually Happens When Something Rotates And Translates At The Same Time
Most people learn about rolling as a combo of translation and rotation, which is technically correct but misses the part that actually matters for engineering. The key constraint is the no-slip condition, and it only holds when static friction is sufficient. Once you cross that threshold, everything changes — the object starts sliding, the energy equations break, and your calculations are wrong by however much kinetic energy you dumped into heat. I spent three days debugging a conveyor belt system where rollers were supposed to run at a fixed angular velocity without any slip. The spec sheet said the coefficient of friction between the roller surface and the belt was 0.4, which should be more than enough for the calculated loads. It wasn't. The issue wasn't the bulk friction coefficient — it was the contact patch geometry. The roller had a hard rubber coating that flattened under load, turning what should have been a line contact into a narrow rectangle. The effective radius shrank by about 2 percent across the patch, which introduced a tiny but cumulative slip that compounded over the 40-meter span. My workaround was swapping to a polyurethane liner with a higher Shore A hardness and a narrower cross-section that maintained a true line contact even under the maximum expected load. Slip dropped to practically zero, and the whole system ran smooth.
The Definition Of Rolling Mechanics Physics And Realworld Applications
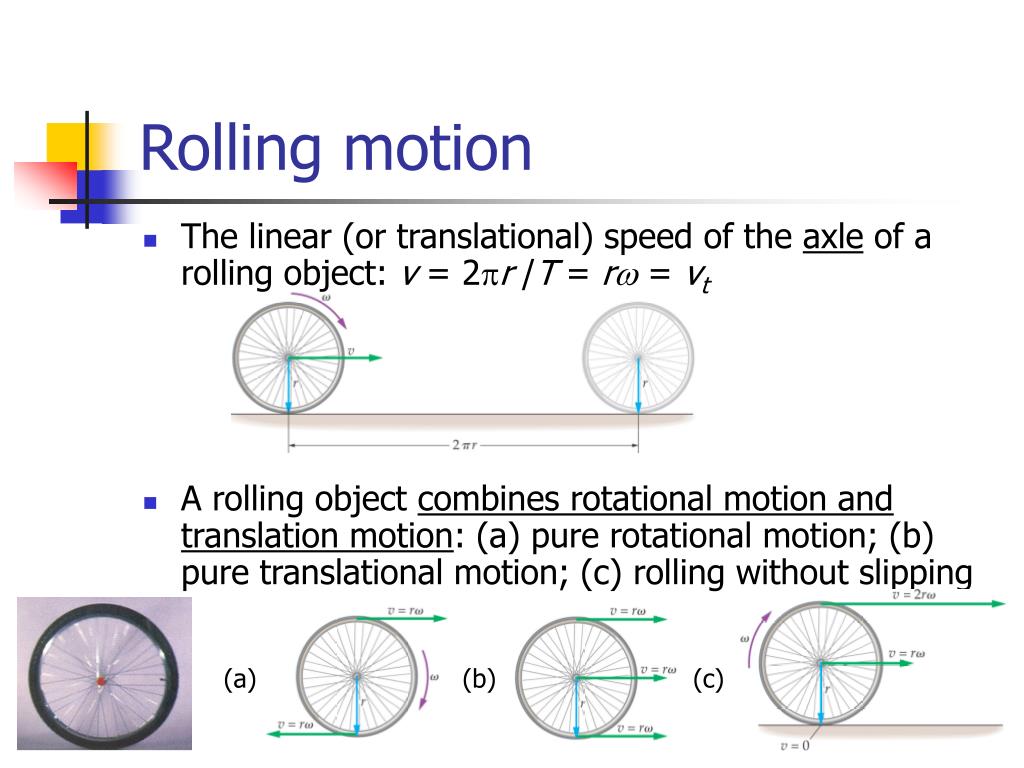
Rolling mechanics sits at the intersection of translational and rotational dynamics. An object rolling without slipping has its center of mass moving at velocity v while simultaneously rotating at angular velocity , and the two are locked together by the geometric constraint v = R, where R is the radius. This constraint is what makes rolling interesting — it couples linear and angular quantities so you can solve problems with a single degree of freedom instead of two independent ones. The energy picture is straightforward but easy to get wrong if you forget which terms belong where. A rolling object has translational kinetic energy, one-half m v squared, plus rotational kinetic energy, one-half I omega squared, where I is the moment of inertia about the center of mass. For a solid cylinder, I equals one-half m R squared, so the rotational term becomes one-quarter m v squared, meaning the total kinetic energy is three-halves times one-half m v squared, or simply one-and-a-half times the translational part. A hoop, by contrast, has I equal to m R squared, so its rotational energy equals its translational energy and the total is m v squared — twice the translational contribution. This difference is why a solid cylinder rolls down an incline faster than a hoop of the same mass and radius, even though gravity accelerates both equally. The distribution of mass matters, not the total mass. Static friction does no work in pure rolling, which is counter-intuitive for people who associate friction always with energy loss. The point of contact is instantaneously at rest relative to the surface, so the friction force acts through zero displacement and transfers no energy. It only provides the torque needed to maintain the no-slip condition. If you remove static friction entirely — say, by placing a rolling object on a perfectly frictionless surface — it will slide without rotating, and all the potential energy converts to translational kinetic energy with no rotational component.
Here is where beginners typically trip up. They write the force equation as m a equals m g sine theta minus friction, and the torque equation as I alpha equals friction times R, then substitute alpha equals a over R and solve. This works for the no-slip case, but it breaks the moment the required friction exceeds mu sub s times the normal force. The maximum static friction is mu sub s m g cosine theta, and the friction required to maintain rolling is m a over 3 for a solid cylinder on an incline. Set them equal and you get the critical angle: theta sub max equals arcsin of 3 mu sub s over 1 plus mu sub s squared. Beyond that angle, the cylinder slips, and the simple energy method no longer applies.
Get the Full Details

Real-World Systems Where Rolling Mechanics Determines Performance
Ball bearings are the most common application, and they reveal the subtleties of rolling friction better than almost anything else. The idealized model treats a ball bearing as pure rolling contact with zero energy loss, but real bearings lose energy through hysteresis in the contacting materials, micro-slip at the contact patches, and viscous drag in the lubricant. For a standard deep-groove ball bearing under moderate load, the rolling resistance coefficient is typically between 0.001 and 0.003, meaning you lose roughly 0.1 to 0.3 percent of the normal force as resistive torque per revolution. In a high-precision spindle running at 10,000 RPM, this translates to several watts of heat generation even with perfect lubrication, and that heat changes the clearance, which changes the friction, which changes the heat — a feedback loop that limits precision at high speed. Vehicle tires operate in a regime where pure rolling is the exception, not the rule. Even on dry pavement at cruising speed, a tire deforms continuously as it rotates, creating a contact patch where the tread elements bend and unbend. This hysteresis loss is the dominant source of rolling resistance in passenger cars, typically accounting for 5 to 15 percent of the engine's output at steady highway speed. The European tire label rates rolling resistance on a scale from A to G, where an A-rated tire saves roughly 0.3 liters of fuel per 100 kilometers compared to a G-rated tire at the same driving conditions. Over the lifetime of a car, that difference is meaningful, but the trade-off is that lower rolling resistance often means less wet grip, because the same polymer compounds that reduce hysteresis also reduce the tire's ability to conform to micro-roughness on wet roads. Wheelchair design is another area where rolling mechanics has direct human impact. A manual wheelchair user on a smooth indoor surface might expend 5 to 10 watts to maintain cruising speed, mostly overcoming rolling resistance in the wheels and bearings. Switch from hard casters to soft pneumatic tires, and that number can double or triple on the same surface, because the softer material deforms more and loses more energy per revolution. This is why indoor competition wheelchairs use rigid polyurethane tires and sealed ceramic bearings — every watt counts when you are propelling yourself for hours. Outdoor users face a different problem: rough surfaces introduce vibrations that increase effective rolling resistance through impact losses, and the optimal tire choice shifts toward a compromise between deformation loss and vibration damping.
Gear systems present a different rolling mechanics problem. involute gear teeth theoretically roll against each other along the line of action, but in practice there is a combination of rolling and sliding throughout the engagement cycle. The sliding velocity is zero only at the pitch point, where the two tooth profiles have the same tangential velocity. Away from that point, one tooth slides against the other, and the sliding friction generates heat and wear. For a standard 20-degree pressure angle gear pair, the sliding-to-rolling ratio varies from infinity at the start and end of engagement to zero at the pitch point. This is why gear lubricants contain friction modifiers — they reduce the sliding component specifically, because rolling friction is already minimal and removing it entirely would not improve efficiency meaningfully.
When The Simple Model Fails And What To Do About It
Large-deformation rolling is where the classical no-slip model breaks down most visibly. Consider a train wheel on a rail. The contact patch is roughly elliptical, maybe 10 millimeters long and 5 millimeters wide for a typical loaded freight car, and the stresses in that patch are in the gigapascal range. Hertzian contact theory predicts the patch size and pressure distribution, but it assumes elastic materials and small deformations relative to the geometry. Real train wheels and rails are not perfectly elastic — they work-harden, develop surface cracks, and eventually fatigue. The rolling resistance of a steel wheel on a steel rail is remarkably low, around 0.001, but that number increases dramatically if the rail has a flat spot or if the wheel develops a harmonic profile, which happens after thousands of kilometers of service on uneven track. Soft-surface rolling introduces another failure mode. A bicycle on sand or a wheelchair on grass does not obey the simple v equals R omega constraint in any useful way, because the surface deforms and the effective rolling radius changes continuously. The resistive force is no longer proportional to the normal force through a constant coefficient — it depends on the sinkage depth, which depends on the tire pressure, the tire width, the surface density, and the speed. Empirical models like the Wollny equation or the BSP model estimate this resistance, but they require measured parameters for each surface type and are not generalizable. If you are designing a vehicle for off-road use, you will spend more time characterizing the terrain than optimizing the drivetrain. Camber and alignment errors create a subtle rolling resistance that is easy to overlook. A wheel that is tilted even a few degrees from vertical does not roll straight — it traces a cone, and the outer edge of the contact patch travels faster than the inner edge. This differential velocity creates lateral slip within the contact patch, which generates heat and wear and increases rolling resistance. In automotive applications, camber error of just 0.5 degrees can increase tire wear by 10 to 15 percent over 20,000 kilometers. In industrial roller systems, misalignment is the leading cause of premature bearing failure, because the uneven load distribution creates a stress concentration that initiates subsurface fatigue cracks.

The boundary between rolling and sliding is not always sharp. In tire dynamics, the concept of slip ratio quantifies how far an actual wheel deviates from pure rolling. A slip ratio of zero means pure rolling, a slip ratio of one means the wheel is locked and sliding, and values between zero and one represent partial slip where some portion of the contact patch is adhering while another portion is sliding. This partial slip region is where braking and acceleration forces are generated, and understanding it is essential for ABS and traction control. The peak braking force typically occurs at a slip ratio of around 0.1 to 0.2, not at zero slip, because some micro-slip is needed to activate the full friction potential of the tire-road interface.
Practical Calculation Workflow
When you need to analyze a rolling system, start by checking whether the no-slip condition is satisfied before you write any energy equations. Calculate the required static friction from the torque equation, compare it to mu sub s times the normal force, and only proceed with the coupled equations if the inequality holds. If it does not, switch to a kinetic friction model with independent translation and rotation equations, and accept that energy is no longer conserved in the mechanical system — some of it is dissipating as heat at the contact patch. For energy-based problems, identify the constraint first. If the object rolls without slipping, you can express everything in terms of a single variable, usually the center-of-mass displacement or the rotation angle. The effective inertial mass becomes m plus I over R squared, which for a solid cylinder is 1.5 m, for a hoop is 2 m, and for a sphere is 7 sub minus sign 5 m. This effective mass determines how the object accelerates down an incline: a sub equals g sine theta divided by 1 plus I over m R squared. Heavier objects do not roll faster — the mass cancels out, and only the shape factor I over m R squared matters. For power loss estimation in real systems, measure or look up the rolling resistance coefficient for your specific material and surface combination, then multiply by the normal force and the velocity to get the resistive power. For a 1,000-kilogram vehicle with rolling resistance coefficient 0.015 cruising at 25 meters per second, the power loss is 1,000 times 9.81 times 0.015 times 25, which is about 3.7 kilowatts, or roughly 5 horsepower. This is a significant portion of the total power required at highway speed, and it is why tire pressure monitoring systems exist — under-inflation increases the contact patch area, which increases hysteresis loss, which increases fuel consumption by 1 to 3 percent per 10 percent drop in pressure below the recommended value.
The limitations of this entire framework are worth stating plainly. Rolling mechanics as commonly taught assumes rigid bodies, isotropic materials, and clean dry contacts. None of these assumptions hold in real engineering systems. Surfaces are rough, materials are viscoelastic, contacts are contaminated, and loads are dynamic. The simple equations give you a starting point and a qualitative understanding, but quantitative predictions for real systems require empirical correction factors, finite element analysis, or direct measurement. If someone tells you they calculated the rolling resistance of a system and got a number that matched measurement within 5 percent without any experimental validation, they are either very lucky or they adjusted their model until it fit.