What a Plane Actually Is
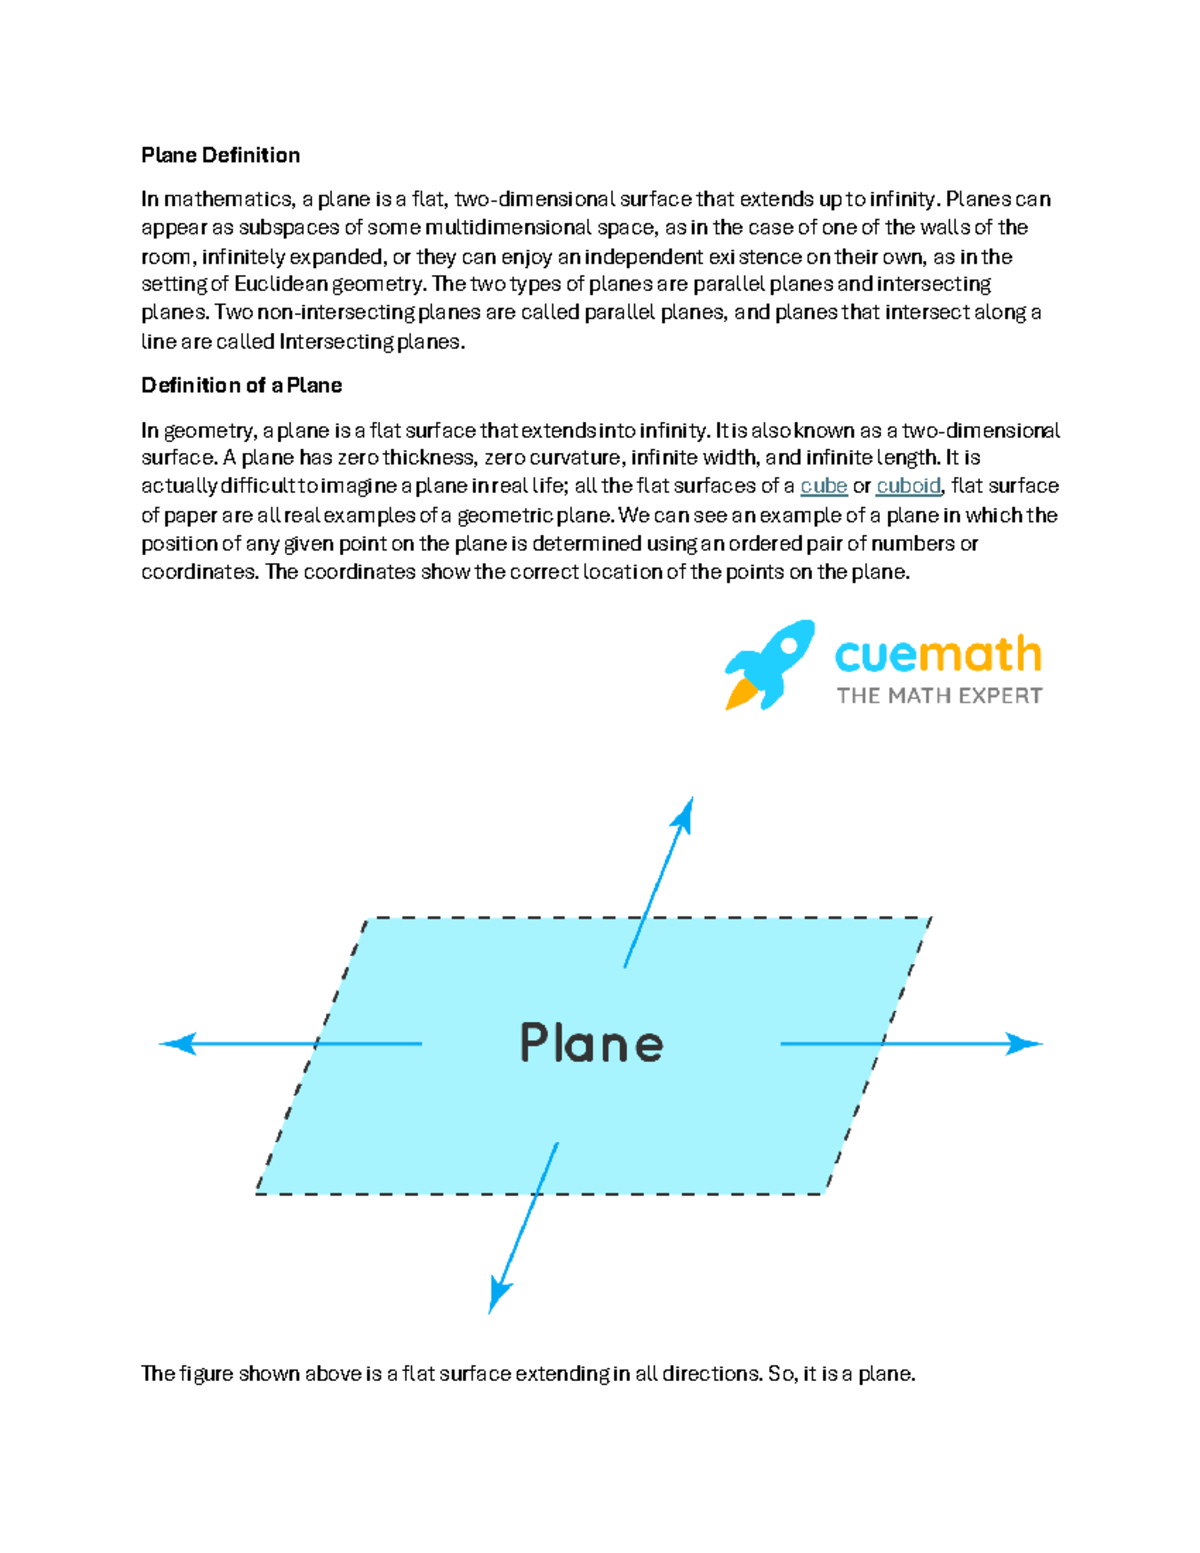
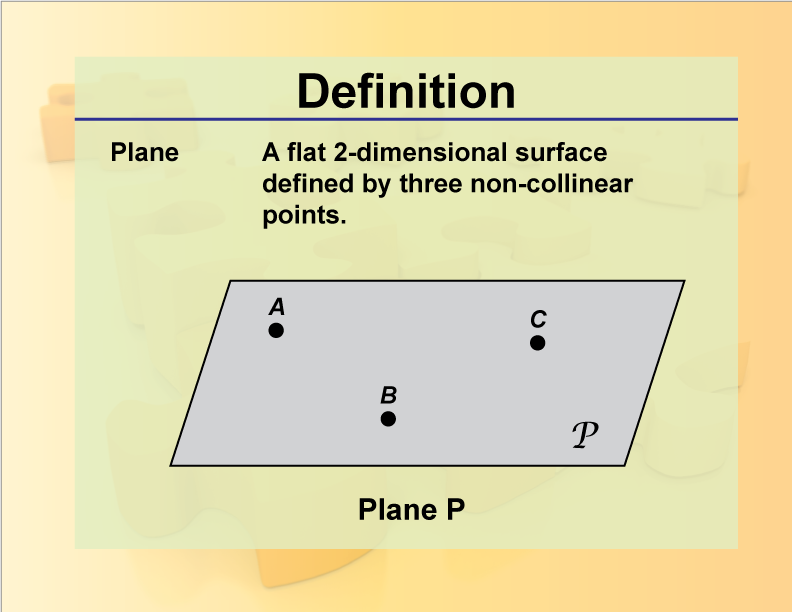
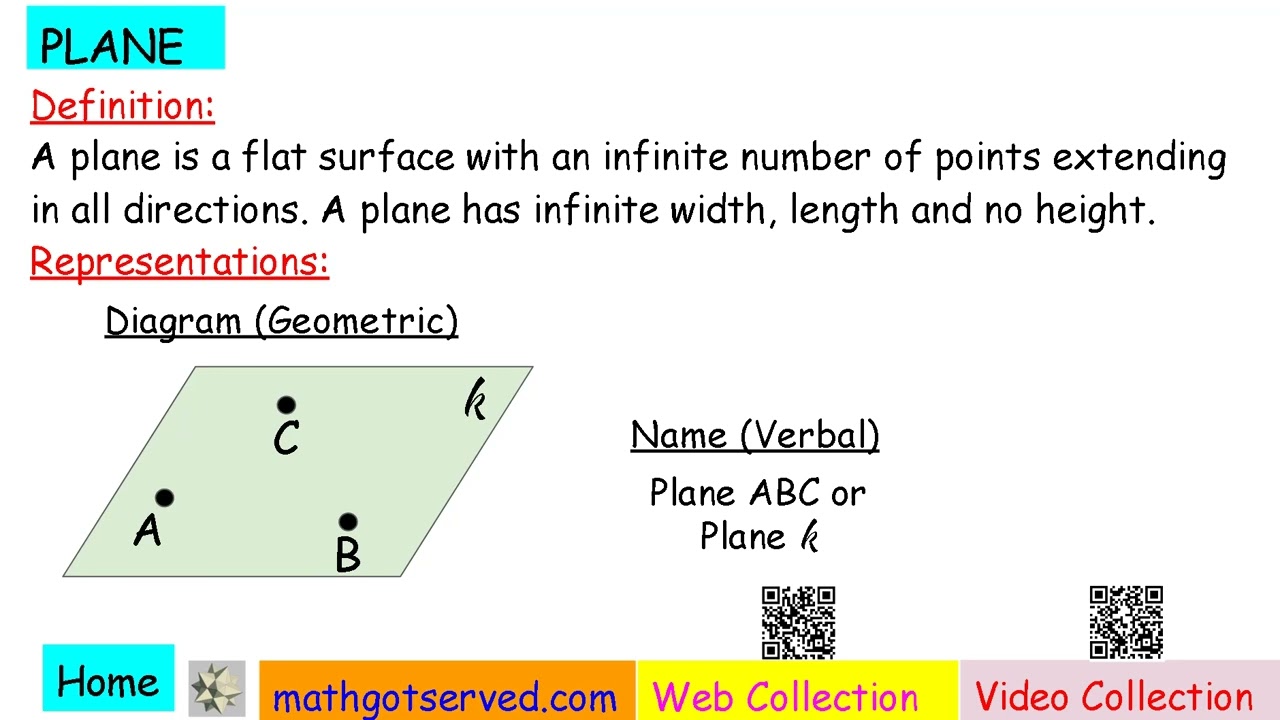
A plane is a flat, two-dimensional surface that extends infinitely in every direction. It has no thickness, no edges, and no curvature. In Euclidean geometry, it is the foundational object everything else gets built on. You can define it using three non-collinear points, or you can write it as a linear equation in three variables. Both approaches describe the same thing. The equation of a plane in standard form is ax + by + cz = d, where a, b, and c are the components of the normal vector to that plane. The normal vector is perpendicular to every line lying within the plane. If you have the normal and one point, you can write the equation immediately. If you have three points, you find the normal by taking the cross product of two vectors formed from those points. That is the practical workflow.
The Definition Of Plane In Mathematics Unlocking The Flat World Of Geometry
I remember sitting in a grad-level computational geometry course and getting burned by this exact issue. The professor gave us a problem where three points were supposed to define a unique plane, but they were nearly collinear. The cross product of the two difference vectors returned a normal with components on the order of 10^-8. When I fed that into the plane equation and then tried to compute distances from other points to that plane, the results were garbage. Floating-point noise dominated the answer. The plane existed mathematically, but numerically it was unstable. The workaround was straightforward. I normalized the normal vector after computing it, then used the point-normal form directly instead of expanding into ax + by + cz = d. That kept the scaling consistent and prevented the division from blowing up. For cases where the points were even closer to collinear, I switched to a singular value decomposition approach to find the best-fit plane rather than relying on the cross product at all. It added maybe thirty seconds of compute time per plane, but the results stopped being nonsense. Here is the step-by-step process I use now when I need to work with planes practically. Given three points P1, P2, and P3:
Step one, compute two direction vectors. Subtract P1 from P2 to get vector v1, and subtract P1 from P3 to get vector v2. Step two, take the cross product of v1 and v2 to get the normal vector n. Step three, normalize n so its magnitude is one. Step four, plug the normal and any of the three points into the point-normal form: n · (r - P1) = 0, where r is any point (x, y, z) on the plane. Expand that to get ax + by + cz = d, where d equals the dot product of the normal and P1. A concrete example. Let P1 = (1, 2, 3), P2 = (4, 0, 1), and P3 = (2, 5, 0). Vector v1 is (3, -2, -2). Vector v2 is (1, 3, -3). The cross product gives n = (12, 7, 11). Normalizing that gives approximately (0.756, 0.441, 0.694). The value of d is 0.756(1) + 0.441(2) + 0.694(3) = 3.538. So the plane equation is roughly 0.756x + 0.441y + 0.694z = 3.538. Check it against P2 and P3 and it holds. One thing beginners consistently miss is the difference between a plane and a flat polygon. A plane extends forever. A triangle, a square, a polygon with any number of sides is a bounded region that lies on a plane. When people say "the plane of the triangle," they are really talking about the infinite plane that contains that triangle. The triangle itself is just a subset of that plane.
Get the Full Details
Another nuance that causes trouble is the relationship between parallel planes and the normal vector. Two planes are parallel if and only if their normal vectors are scalar multiples of each other. They do not need to have the same normal direction exactly. If one plane has normal (2, 4, 6) and another has normal (-1, -2, -3), those planes are parallel. The signs and magnitudes differ, but the direction is the same or opposite. This matters when you are checking whether a line intersects a plane or runs parallel to it. If the direction vector of the line is perpendicular to the normal of the plane, the line is either parallel to the plane or it lies entirely within it. You need an additional check to distinguish between those two cases. The most common pitfall I see in practice is assuming that any two vectors in a plane are sufficient for a clean cross product. If your points are nearly collinear, the cross product collapses. Even if they are not obviously collinear, if your coordinates span very different scales, like one axis in the thousands and another in fractions, the resulting normal will be numerically unstable. Rescaling your coordinates before computing the plane is almost always worth the effort. Planes also appear constantly in computer graphics, CAD, and robotics. In ray tracing, intersection tests between a ray and a plane are computed using the same normal-vector dot product. In robotics, you might define a workspace plane from three calibration points and then project sensor data onto it. The math is identical regardless of the application, but the failure modes change. Graphics pipelines break when the normal is zero-length. Robotics breaks when sensor noise makes the three calibration points slightly non-coplanar. In that last case, there is no single plane that passes through all three points exactly, and you have to decide whether to use a least-squares fit or just pick two points and hope the third is close enough.
The least-squares approach for non-coplanar points is simple enough that there is no excuse for skipping it when the data is noisy. You set up a 3-by-3 system from the covariance matrix of the points, extract the eigenvector corresponding to the smallest eigenvalue, and that eigenvector is your best-fit normal. It gives you the plane that minimizes the sum of squared perpendicular distances from all points to the plane. This is what happens under the hood when geometric modeling software auto-generates a plane from a cloud of points. There are scenarios where the plane model simply fails and you should admit it. If your data is curved, fitting a plane will give you a result, but it will be wrong. A sphere, a cylinder, a parabola rotated around an axis, any of those will produce a "plane fit" with a measurable error. The residual distances from the points to the fitted plane will be large relative to the scale of the data. Before you commit to a plane, look at the distribution of residuals. If they are random and small, you are fine. If they show a pattern, your surface is not flat and you need a different model. For most practical work, knowing how to compute a plane from three points, how to handle edge cases where those points are nearly collinear, and how to verify that a plane is actually a reasonable model for your data is sufficient. The theory behind it is clean. The implementation is where things get interesting.