
What Cyberphysical Systems Actually Are
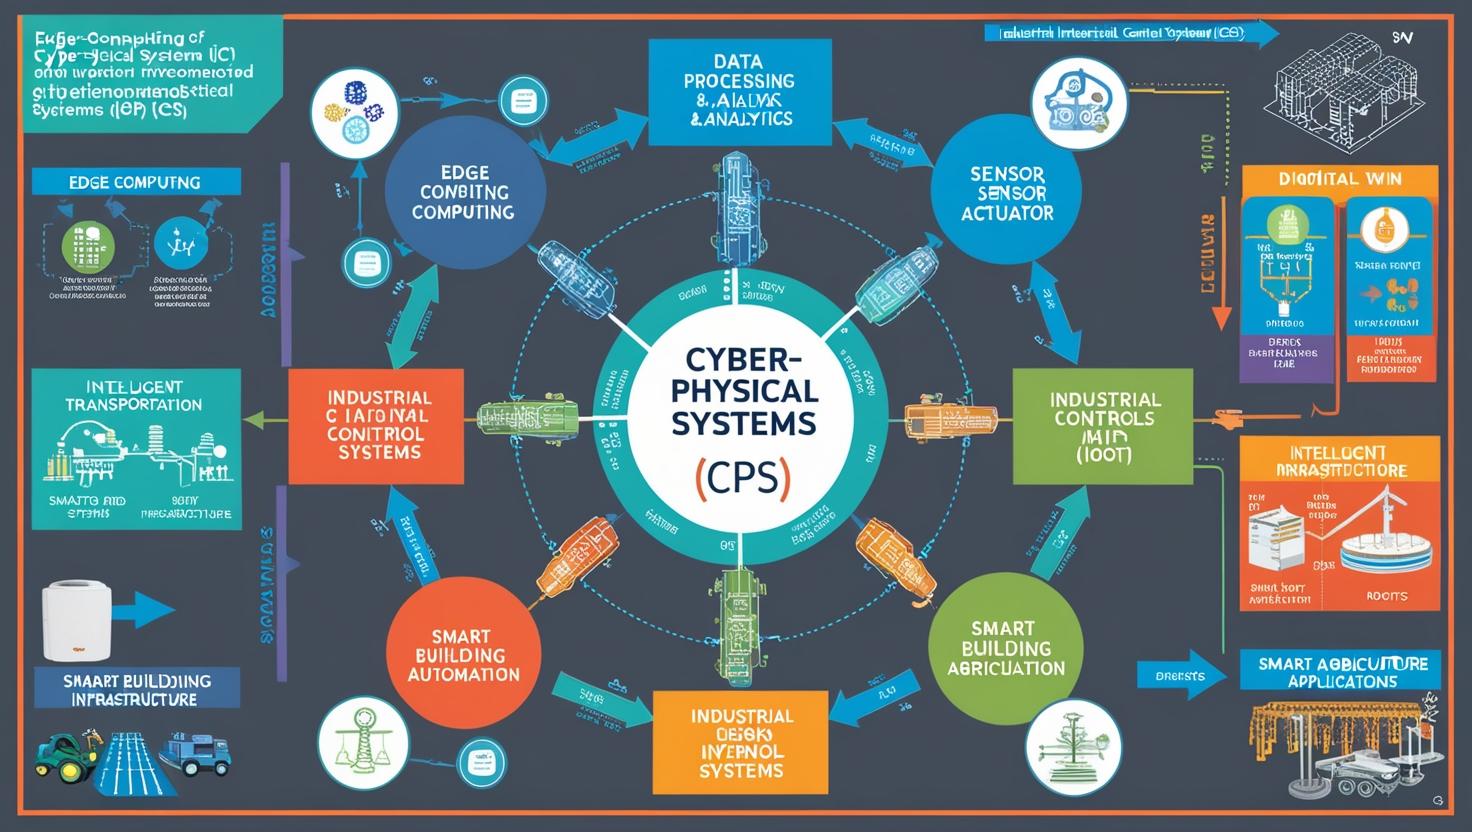
Cyberphysical systems are where software meets the physical world in a way that matters. You have sensors feeding data into computational logic, and that logic sends commands back out to actuators. That loop is the whole thing. It sounds simple until you try to build one that doesn't fail every few hours. The term gets thrown around a lot in marketing decks. The reality is more specific. A cyberphysical system needs tight coupling between the digital and the physical, real-time responsiveness, and enough autonomy to make decisions without waiting for a human. Industrial robots, autonomous vehicles, smart grids, and medical devices like insulin pumps all fit. They're not just embedded systems either. The cyber side actively monitors and adjusts the physical side, sometimes with machine learning layers that change behavior over time.
Understanding The Critical Role Of Cyberphysical Systems In Future Technologies
Looking at where the industry is heading, these systems are becoming the backbone rather than a peripheral feature. Every major technology trend — edge computing, digital twins, autonomous infrastructure — depends on them. You can't have a functional digital twin without the cyberphysical system feeding it live data. You can't run edge inference meaningfully without sensors and actuators closing the loop. The shift is happening because the cost of connectivity and computation keeps dropping while the need for real-world automation keeps rising. Manufacturing lines that used to rely on hardwired PLCs are now running on cloud-connected controllers with predictive maintenance baked in. Buildings that once adjusted HVAC on fixed schedules are responding to occupancy, weather, and energy pricing simultaneously. The critical role comes from the fact that these systems are the only thing making those integrations actually work instead of staying as separate silos. I spent roughly six months troubleshooting a cyberphysical deployment in a warehouse automation project where the problem wasn't the software or the hardware individually. It was the timing. Our RTOS was handling the control loop fine, but the sensor data coming from the LiDAR array had variable latency depending on network congestion. Some frames arrived 12 milliseconds late, others 40. The path planning algorithm assumed synchronized input. It wasn't getting it. We ended up implementing a hardware timestamp bridge on the sensor bus and adding a jitter buffer that discarded anything older than 25 milliseconds before passing it to the planner. The system ran stable after that. Without that workaround, the robots would have made decisions based on stale spatial data and occasionally collided with racking.
How to Design One That Actually Works
Starting a cyberphysical project means making a lot of decisions before you write a single line of code. The biggest mistake I see is people prototyping the control logic first. That's backwards. You need to understand the physical constraints before anything else. Step one is defining the latency budget. This is the maximum time allowed between a physical event occurring and the system responding to it. It varies wildly by application. A drone stabilizing flight might need sub-10 millisecond loops. A smart thermostat adjusting temperature doesn't care about anything faster than 30 seconds. Getting this wrong means either building an over-engineered system or shipping something that can't keep up with reality. Your latency budget drives everything downstream — sensor selection, processing architecture, communication protocols, you name it. Step two is mapping the sensor-actuator chain. Every physical measurement you need has a component attached to it, and every action you want to take requires an actuator. List them all. Note their specs, their failure modes, their noise characteristics. I've seen projects blow their budgets because someone assumed a $15 IMU would give clean enough data for balance control. It doesn't. A decent MEMS IMU has drift issues that become catastrophic within minutes without sensor fusion, and even then you're working with limitations.
Get the Full Details
Step three is choosing your communication architecture. This is where most teams get tangled up. You're dealing with multiple data streams at different priorities. High-frequency sensor reads need to reach the controller fast. Lower-frequency telemetry can go over standard networking. Mixed-criticality networks are the standard approach here. You might run CAN bus or EtherCAT for the real-time control layer and TCP/IP for everything else. Just make sure the separation is enforced. A buggy diagnostic endpoint shouldn't be able to starve your control loop of bandwidth. Step four is building the digital representation. Whether you call it a digital twin, a simulation environment, or just a test harness, you need a way to validate your logic before deploying it to physical hardware. This doesn't have to be perfect. A basic physics simulator with simplified sensor models caught most of my bugs before they ever touched real equipment. The trick is matching your simulation fidelity to your validation needs. Don't build a full CFD model if a lumped-parameter thermal model will tell you the same thing for half the compute cost. Step five is the integration and testing phase. This is where the easy part ends. You connect the simulated or real sensors to your processor, hook up the actuators, and watch everything break in interesting ways. Start with hardware-in-the-loop testing. Feed your controller recorded sensor data and verify it produces the correct actuator commands. Then move to real hardware with disabled actuators so you can observe outputs without risking damage. Only after both pass do you enable the physical interaction, and even then, start with the safest possible configuration.
Common Pitfalls That Will Cost You Time and Money
There are several patterns I've seen repeat across projects. The first is underestimating how noisy the physical world is. Sensors don't give clean readings. They give readings with noise, drift, temperature dependence, and occasional outright failures. Your software needs to handle all of that gracefully. A simple median filter or Kalman filter isn't optional. It's required. The second is treating the system as purely software. Cyberphysical systems fail at the intersection. A processor might compute the right output, but if the power supply sags when the actuator draws current, your microcontroller could brown out and reset mid-cycle. I once debugged an intermittent fault for three days before realizing the issue was voltage droop on the rail shared by a stepper motor driver and the MCU. Separating the power domains solved it immediately. The third is ignoring cybersecurity until it's too late. These systems control physical things. A compromised cyberphysical system can cause real damage. Input validation, secure boot, encrypted communication — these aren't luxury additions. I've seen industrial controllers exposed to internal networks without authentication because the engineer assumed the factory floor was a trusted environment. It wasn't. Someone plugged an unauthorized device into a spare port and the controller started receiving malicious commands. The fix involved network segmentation and mutual TLS, but by then we'd already lost a shift.
What This Means for the Next Decade
The trajectory is clear and the applications are expanding faster than the talent pool can fill. Every sector that involves automation, monitoring, or autonomous decision-making in the physical world is moving toward cyberphysical architectures. Healthcare is the most obvious example outside of traditional industrial settings. Implantable devices, robotic surgery systems, and hospital infrastructure management all rely on the same principles. One thing worth noting that most people miss is the maintenance problem. Cyberphysical systems don't just get deployed and left alone. They degrade. Sensors drift. Actuators wear. Software needs updates. A well-designed system includes self-diagnostics and graceful degradation paths. When a sensor fails, the system should detect it and fall back to a safe mode rather than continuing to operate on bad data. This isn't always implemented because it adds complexity, but skipping it is a liability. The other counter-intuitive insight is that more automation doesn't always mean better outcomes. There's a sweet spot where human oversight actually improves system performance. Fully autonomous systems in unpredictable environments can get into situations they weren't trained for. A teleoperation backup or a human-in-the-loop override capability is often the difference between a minor incident and a major one. I recommend building that in from the start rather than trying to bolt it on later.

If you're looking to get started, the accessible entry points are development boards with sensor ecosystems. The Raspberry Pi Pico, STM32 Nucleo series, and similar platforms let you prototype the core concepts without significant investment. Open-source frameworks like ROS 2 provide tooling for sensor integration, simulation, and deployment. There's no official download link for the technology itself since it's an architectural approach rather than a product, but the libraries and tools are widely available. The field isn't going anywhere. The hardware is getting cheaper, the software tools are maturing, and the demand is real. The people who understand these systems well will be in demand for a long time. The ones who treat them like regular software projects will learn the hard way how different the physical world actually is.


