Understanding Rotational Motion Without the Textbook Fluff
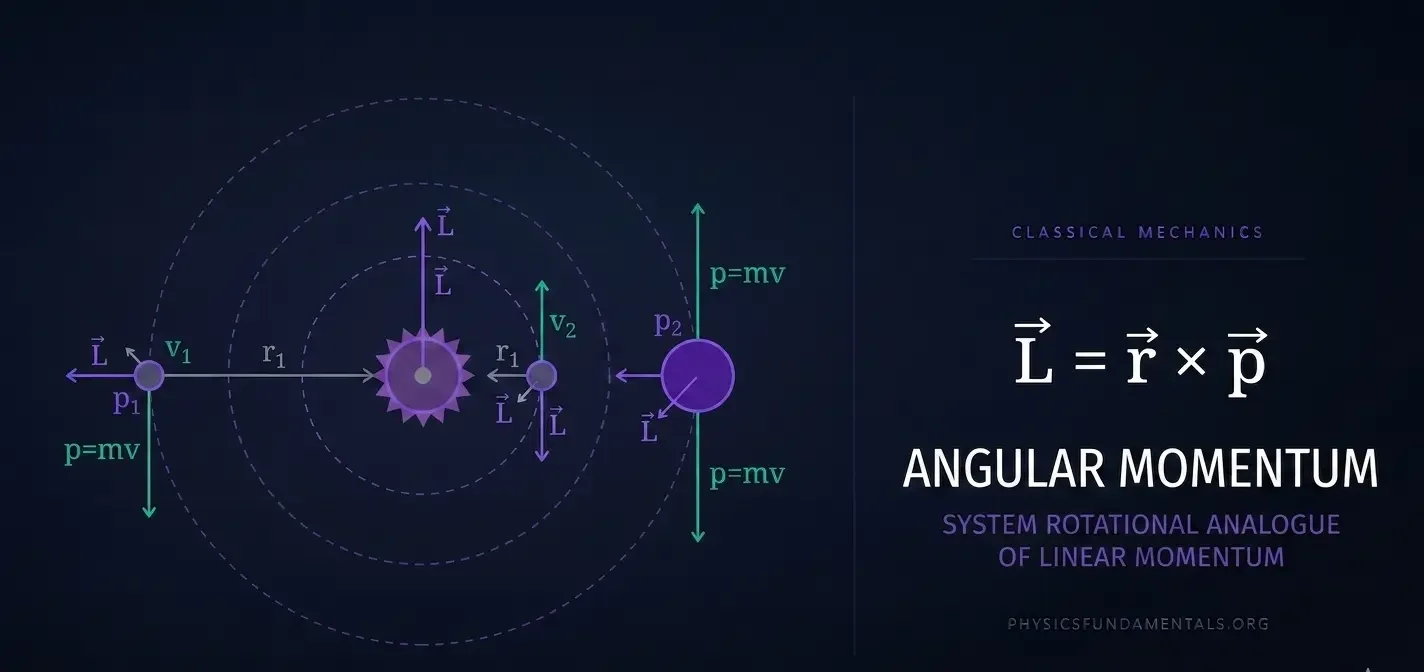
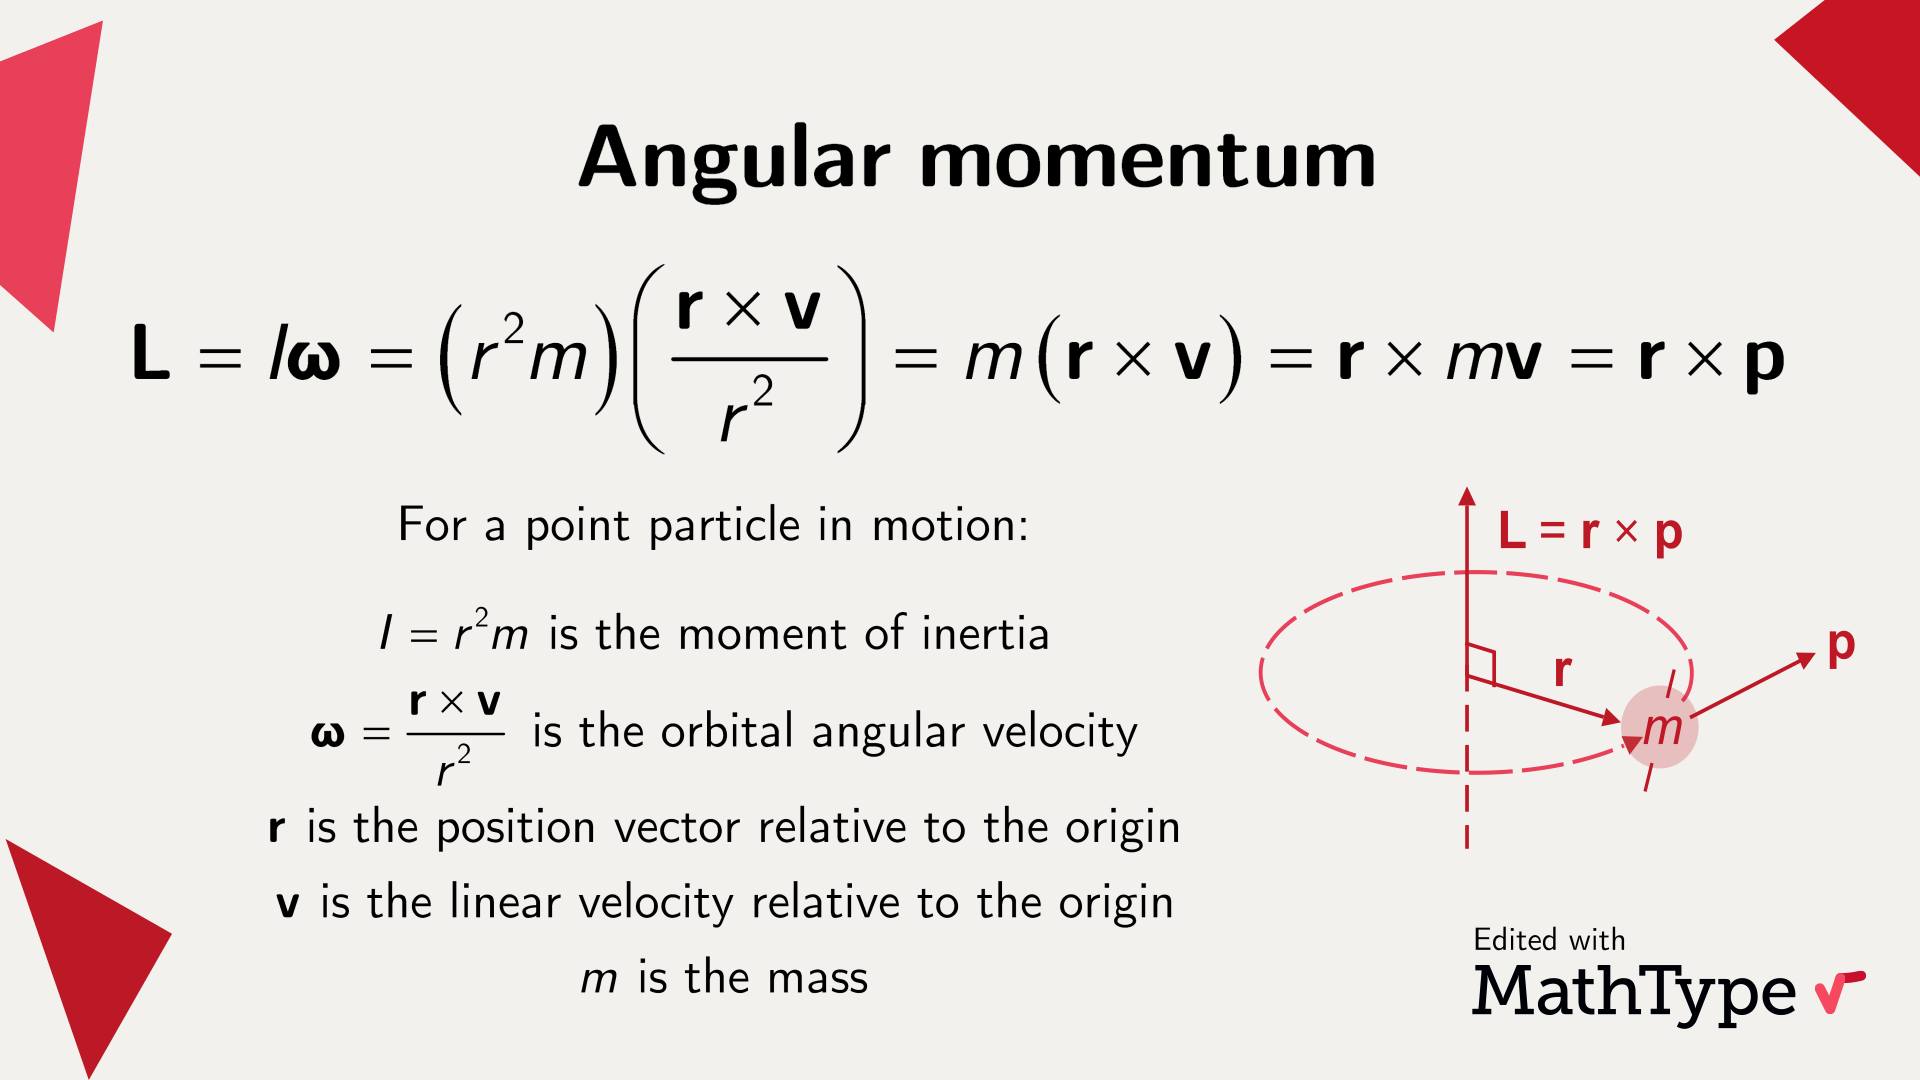
Angular momentum is a conserved quantity in rotational mechanics. The core equation is L = I, where L is angular momentum, I is the moment of inertia, and (omega) is angular velocity. That's the whole thing. Everything else is just applying it correctly to whatever shape or system you're looking at. I've spent years working with rotational dynamics in both academic settings and practical engineering work, and honestly, most people overcomplicate it. The moment of inertia, I, depends entirely on how mass is distributed relative to the axis of rotation. For a point mass it's just mr², but real objects require integration. A solid cylinder rotating about its central axis has I = ½mr². A thin hoop has I = mr². Same mass, same radius, double the angular momentum for identical spin rate because all the mass sits at the maximum distance from the center. This matters more than people realize. Let me walk through how this actually works in practice. Say you're analyzing a figure skater pulling their arms in during a spin. Conservation of angular momentum means L stays constant if no external torque acts on the system. So when I decreases by tucking, must increase proportionally. The math is straightforward. The tricky part is knowing which axis to use and whether your system is truly isolated.
I ran into a specific problem a few years back working on a project involving a flywheel energy storage system. The design called for a composite rotor spinning at around 20,000 RPM. The initial calculations used the standard cylindrical approximation for moment of inertia, but when we actually measured the angular momentum using laser Doppler vibrometry, the values were about 8% off. Turns out the hub geometry and the spindle attachments contributed significantly to the effective I, and those components were heavier near the outer diameter than the simple model accounted for. The workaround was to model each component separately using the parallel axis theorem and sum the individual moments of inertia. That brought the prediction within 1.2% of the measured value. It's a reminder that real geometries rarely match textbook shapes perfectly. Here's something beginners consistently miss: angular momentum is a vector quantity. The direction matters, and it points along the axis of rotation according to the right-hand rule. When you see a skateboarder doing an ollie with a kickflip, the board's rotation direction is determined by the torque applied during the flick. The angular momentum vector points perpendicular to the plane of rotation. If you ignore the vector nature and only calculate magnitude, you'll get confused whenever multiple rotations happen simultaneously. Two-dimensional problems stay manageable. Three-dimensional ones demand you track all three components. Another counter-intuitive point involves the relationship between torque and angular momentum change. The equation = dL/dt tells us that torque is the rate of change of angular momentum, not directly related to angular velocity. This distinction causes problems when people try to apply linear intuition to rotational systems. A large torque doesn't necessarily mean high spin speed. It means the spin is changing rapidly. A gyroscope demonstrates this clearly — applying a horizontal torque to a spinning gyroscope produces precession rather than simply tilting the axis downward like you'd expect from linear mechanics.
When dealing with extended rigid bodies, you need to consider whether the rotation axis is a principal axis. If it isn't, you get dynamic imbalance that produces wobbling forces. This is why car wheels are balanced — the rotation axis needs to align with a principal axis of inertia, or you'll see vibrations that increase with rotational speed. The correction involves adding mass at calculated positions to shift the principal axes into alignment with the intended rotation axis. In practice, this usually takes a wheel balancer that spins the tire and measures vibration amplitude at different angular positions. The conservation principle applies universally, but only when the net external torque is zero. This condition is easy to violate in real systems. Air resistance creates drag torque. Bearing friction creates torque. Gravitational forces on asymmetric objects create torque when the center of mass doesn't align with the pivot point. A spinning top falls over precisely because gravity exerts a torque on it. The precession you observe is the system's response to that torque, not a violation of angular momentum conservation — the total angular momentum of the top plus Earth system is still conserved, it's just redistributed. For orbital mechanics, angular momentum conservation explains Kepler's second law. A planet moves faster at perihelion because it's closer to the sun and its moment of inertia is smaller. The product of distance squared and tangential velocity remains constant throughout the orbit. This is exactly the same principle as the ice skater pulling in her arms, just applied to an object moving along an elliptical path rather than a rotating rigid body.
Get the Full Details

Galaxies operate on the same principle but on scales that make direct measurement difficult. The rotational curves of spiral galaxies show that stars at the outer edges move faster than the visible mass distribution predicts. This discrepancy led to the dark matter hypothesis, though modified gravity theories remain an alternative explanation. The angular momentum calculation itself is unambiguous — it's the interpretation of what the numbers mean that generates debate. A common pitfall is confusing angular momentum with rotational kinetic energy. Both depend on moment of inertia and angular velocity, but the energy equation is KE = ½I² while angular momentum is L = I. They scale differently with . Doubling the spin rate doubles the angular momentum but quadruples the kinetic energy. This distinction is critical when you're sizing motors or brakes for rotating equipment. A system that can store a certain amount of angular momentum might require a dramatically larger energy capacity to control safely. Another practical issue arises when objects change shape dynamically. The moment of inertia becomes time-dependent, and you can't treat I as a constant in your equations. Rockets burning fuel, collapsing stars, or even a person extending their legs mid-air all have changing I values. The conservation equation still holds, but you need to solve a differential equation rather than a simple algebraic one. In engineering applications, numerical integration is usually the most practical approach unless the geometry change follows a simple known function.
If you need to calculate angular momentum for an arbitrary object, the most reliable method is finite element analysis. Most modern CAD packages include moment of inertia calculation as a built-in feature. You define the geometry, assign material density, select the axis of rotation, and the software integrates over the volume. This handles complex shapes that would be impractical to analyze by hand. The trade-off is that you need an accurate 3D model, and the results are only as good as the mesh quality and boundary assumptions you build into the simulation. For quick hand calculations, the standard formulas for common shapes are worth memorizing. Solid sphere: mr². Hollow sphere: mr². Thin rod about center: ml². Thin rod about end: ml². Disk about center: ½mr². These cover roughly 90% of introductory problems. Beyond that, you're either working with custom geometry or you should be using computational tools. The units work out to kg·m²/s or equivalently N·m·s. Make sure you're consistent. Mixing grams with meters or revolutions per minute with radians per second is the single most common error I see in student work. Always convert to SI base units before plugging into the equation. One conversion mistake and your answer is wrong by factors of 1000 or more, and tracking down which one it is wastes far more time than doing the conversions correctly the first time.
There are also cases where angular momentum conservation doesn't give you enough information to solve a problem. If multiple objects interact rotationally, you have one conservation equation but potentially multiple unknown angular velocities. You need additional constraints, usually from energy conservation or from kinematic relationships between the interacting bodies. Collision problems involving rotation are particularly tricky because you need to decide whether the collision is elastic, inelastic, or somewhere in between before you know which equations are valid to apply. Quantum mechanics introduces a completely different framework for angular momentum, where it becomes quantized in units of ħ. The classical formula breaks down at atomic scales. But for any object you can see with the naked eye, the classical treatment is accurate to many decimal places. The universe doesn't care about your units as long as you're consistent, and it doesn't care about your coordinate system choices either. Pick something convenient, stick with it, and your results will be correct.