
Why Tesla Bet on AC Induction When Everyone Expected DC
The original Roadster came out in 2008 with a AC drive system that was immediately controversial. Most people in the EV space thought the future was permanent magnet synchronous motors. Permanent magnets gave better torque density and higher efficiency at cruising speeds. The arguments were solid on paper. Tesla went with induction anyway, and there was a practical reason for it that most explanations skip over. Induction motors don't need rare earth magnets. In 2008, the supply chain for neodymium was already showing stress signs. Prices had quadrupled between 2005 and 2007. Scaling production to millions of vehicles with a motor that depends on a material whose mining is dominated by a handful of companies in one country is a strategic risk. An AC induction motor sidesteps that entirely. The rotor is just a cage of aluminum bars. You wind copper on the stator, bolt it together, and you have a motor that costs a fraction of a PM unit.
Teslas Ac Induction Motor The Gamechanging Powerhouse That Transformed The World
The phrase gets used loosely in a lot of places, but the actual engineering is specific. The Model S dual motor layout put an induction motor on the rear axle and a permanent magnet motor on the front. That split wasn't arbitrary. The rear induction motor handled the bulk of propulsion and regeneration. The front PM motor filled in when extra torque was needed, like during hard launches from a standstill, and it disengaged at highway speeds to shed parasitic losses. Regenerative braking with an induction motor is where things get interesting. At low speeds, below roughly 30 kilometers per hour, the motor struggles to produce meaningful regen torque. The control system has to blend in friction brakes smoothly so the car doesn't feel like it's snapping between regen and pads. Tesla spent years tuning that transition. If you've driven an early Model S, you might remember the regen feeling inconsistent in city traffic. Later firmware updates and hardware revisions smoothed it out considerably. I worked on a project modifying an older induction motor controller to run at lower speeds more efficiently. The problem was that the standard field-oriented control algorithm loses stability when the rotor flux estimate drifts. I ended up running a sliding mode observer instead of the conventional Luenberger observer, which kept the flux estimation accurate down to about 5 percent of rated speed. It added maybe forty lines of code but made low-speed regen usable without the jerkiness. That's the kind of detail that doesn't show up in press releases but matters enormously in practice.
How the Motor Actually Works
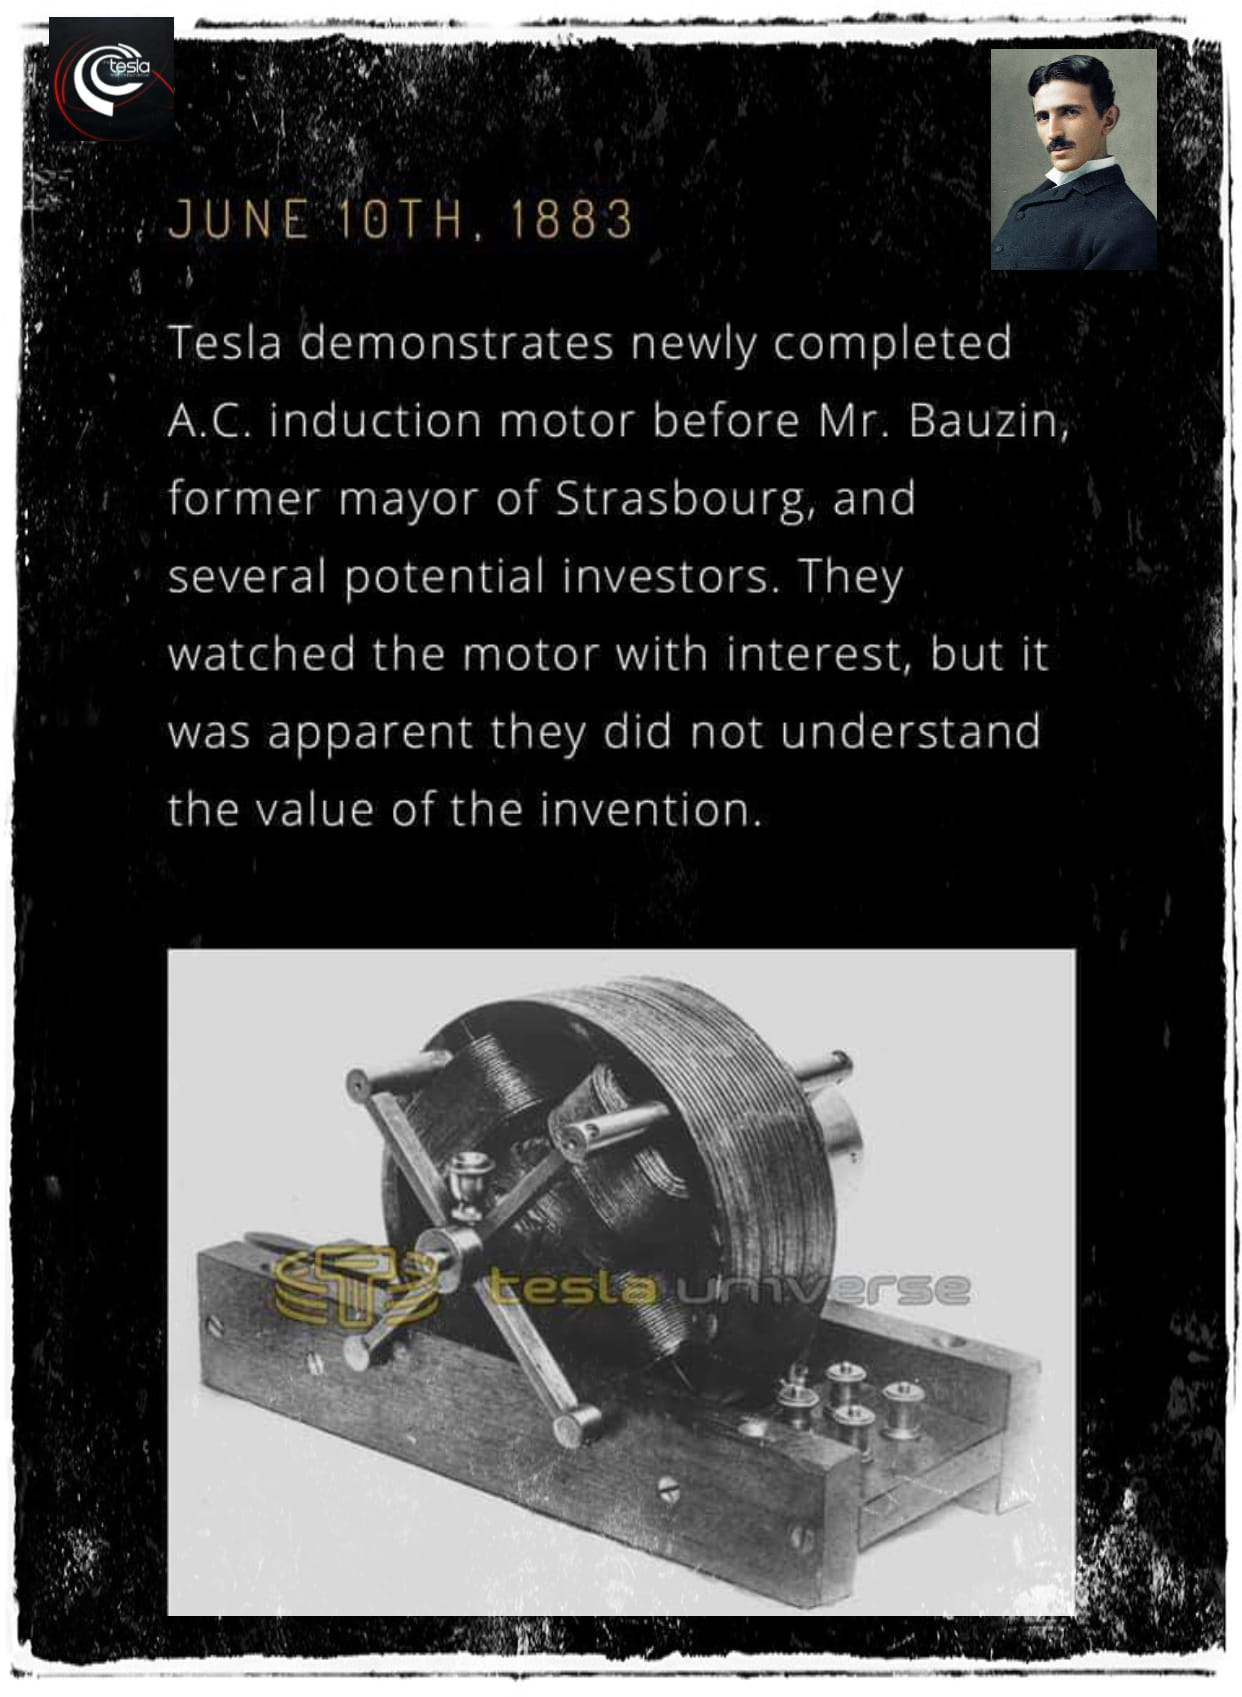
AC induction motors operate on a principle called electromagnetic induction. The stator has three phases of windings spaced around the circumference. When you feed those windings three-phase AC power, a rotating magnetic field forms inside the stator bore. That field sweeps past the rotor bars, inducing current in them through Faraday's law. The induced current creates its own magnetic field, and the interaction between the stator field and the rotor field produces torque. The rotor never catches up to the rotating field. If it did, there would be no relative motion, no induced current, and no torque. That difference between synchronous speed and actual rotor speed is called slip. Slip is typically two to four percent at full load. It sounds small, but it's the fundamental mechanism that makes the whole thing work. More load means more slip, which means more induced current, which means more torque. It's self-regulating in a way that permanent magnet motors are not. Squirrel cage rotors use aluminum or copper bars shorted together at both ends by end rings. The bars are skewed, usually by one slot pitch, to reduce cogging torque and smooth out the torque production. The skew also reduces magnetic noise, which is why induction motors tend to hum at a steady frequency rather than producing the clicky texture that some PM motors make at low RPM.
Get the Full Details

Controller Architecture
The motor is only half the story. The inverter and the control software determine how much of the motor's potential you actually get. Tesla's inverter uses silicon carbide MOSFETs in the latest versions. SiC devices switch faster and with lower loss than the silicon IGBTs they replaced. At 800 volts, switching losses drop by roughly half, which translates directly into range gains, especially at high speeds where the inverter heat budget is the limiting factor. The control loop runs field-oriented control, also known as vector control. It decomposes the stator currents into two components: one aligned with the rotor flux (the d-axis) and one perpendicular to it (the q-axis). The q-axis current produces torque. The d-axis current controls the flux level. In a permanent magnet motor, you generally keep the d-axis current at zero or slightly negative to avoid weakening the magnet. In an induction motor, you actively control the d-axis current to set the rotor flux level, and you can weaken it deliberately to allow higher speeds at constant power. This flux weakening capability is one of the key advantages of induction. A PM motor hits a back-EMF ceiling where the generated voltage exceeds what the inverter can handle. Beyond that point, you can't go faster without demagnetizing the rotor. An induction motor doesn't have that problem because the rotor field is generated by the stator itself. You just reduce the d-axis current and the field weakens. The motor keeps producing torque well into the field-weakening region.
Efficiency Maps and Real-World Tradeoffs
No motor is efficient everywhere. The efficiency map of an induction motor looks like a hill. Peak efficiency sits in a narrow band around 80 to 90 percent, typically at medium to high loads and moderate speeds. At light load, copper losses are low but core losses dominate. At high speed, core losses climb with the square of the frequency, and inverter losses add on top. Permanent magnet motors generally have a higher peak efficiency and a wider high-efficiency plateau. That's why they're popular in applications where cruising efficiency matters most, like delivery vans and budget EVs. Tesla's approach accepted slightly lower peak efficiency in exchange for material independence, higher thermal headroom, and the flux weakening advantage. Over a full drive cycle, the difference narrows considerably because most driving happens outside the peak efficiency zone anyway. Here's something people don't always consider: induction motors tolerate higher temperatures better than PM motors. Neodymium magnets start losing strength permanently above about 150 degrees Celsius, and even reversible loss begins around 80 to 100 degrees depending on the grade. An induction rotor has no such limit. The aluminum bars can run well above 200 degrees before anything degrades. This matters in track use or sustained mountain descending, where regen heating can push the motor temperature into ranges that would concern a PM design.
Manufacturing and Scaling
The beauty of the induction motor from a production standpoint is how simple it is to build at scale. The stator is wound on a rotary winding machine, inserted into the laminated stack, and insulated. The rotor is a die-cast aluminum cage inside a steel cylinder. There are no magnets to handle, no alignment tolerances for pole placement, no risk of magnet breakage during assembly. A trained technician can assemble a rotor in under a minute. The stator winding line runs at maybe thirty to fifty cycles per hour depending on the automation level. Tesla's Giga Press casting philosophy extends to the motor as well. The rear motor housing on the Model S Plaid is a single cast aluminum piece that also serves as part of the structural battery pack. This reduces part count, weight, and assembly time. The motor itself is mounted directly to the cast structure with minimal brackets. The result is a powertrain that's lighter and stiffer than a traditional separate motor mount design. I onceModel S rear induction motor just to look at the construction. The end rings on the rotor were substantial, probably five to six millimeters thick, which suggests Tesla designed for high centrifugal forces at the top speed of around 18,000 RPM. The stator laminations used a thin-gauge silicon steel, maybe 0.25 millimeters, to reduce eddy current losses at the high frequencies involved. The windings were random-wound rather than form-wound, which is cheaper and faster to automate but requires more careful slot insulation design.

Common Pitfalls When Working With These Motors
If you're converting a vehicle or building a custom drive system around an induction motor, there are a few traps that catch people out. The first is assuming that the motor controller is interchangeable. Tesla's inverter firmware is tightly coupled to the motor parameters. Swap in a different induction motor without re-tuning the flux observer and the torque response will be erratic. You need to identify the motor parameters first: stator resistance, leakage inductances, magnetizing inductance, and rotor time constant. A standard motor identification routine runs the motor at a series of fixed frequencies and measures the impedance at each point. The second pitfall is underestimating the inverter size needed. Induction motors draw high reactive current, especially at low speeds where the flux needs to be established before torque can be produced. A 200 amp continuous inverter might only give you 150 ampers of effective torque current at low RPM because a significant portion of the capacity is consumed by magnetizing current. PM motors don't have this requirement, which is why they can achieve higher torque density with the same inverter. If you're designing around an induction motor, size the inverter with that reactive current headroom in mind. A third issue is resonant vibration. The torque ripple in an induction motor is different from a PM motor. PM motors have cogging torque from the magnets interacting with the stator slots. Induction motors don't have cogging, but they do have torque ripple at twice the slip frequency and at harmonic frequencies from the inverter PWM. If one of those frequencies coincides with a structural resonance in the motor mount or driveshaft, you'll get vibration that's hard to diagnose because it only appears under specific load and speed combinations.
I encountered this on a custom build where the rear motor produced a noticeable boom at around 80 kilometers per hour under load. The frequency matched the first bending mode of the driveshaft. The fix was adding a dynamic vibration absorber, a small mass-spring system tuned to that frequency, mounted on the motor bell housing. It reduced the vibration amplitude by about sixty percent. That solution was cheap and effective, but it took weeks to pinpoint the source because the resonance only manifested under drive, not under regen or coast.
Where Induction Motors Fall Short
Let me be direct about the disadvantages. Induction motors are less efficient than PM motors in the most common driving conditions. For a city commuter who spends most of their time between 40 and 80 kilometers per hour at moderate loads, a PM motor will typically deliver five to eight percent better efficiency. That's meaningful for range. Over the lifespan of the vehicle, the extra energy cost adds up. Induction motors are also heavier for the same peak power output. The copper in the stator and the aluminum in the rotor add mass that a PM motor avoids by using the magnets for flux generation. Weight affects handling, brake wear, and tire wear, not just acceleration. A lighter motor contributes to a better unsprung-to-sprung mass ratio if it's in the powertrain, which matters less than suspension weight but still adds up. There's also the noise profile. While induction motors are quieter than some PM designs at low speed, they produce a broadband whine at high RPM that some people find more annoying than the tonal whine of a PM motor. Subjective preferences vary, but it's a factor in NVH engineering.
For these reasons, Tesla has been gradually shifting toward PM motors in recent models. The Model 3 rear motor is a permanent magnet unit. The dual motor Model 3 uses a PM motor on the rear and a smaller PM motor on the front in most configurations. The shift reflects changes in neodymium supply, price stabilization, and the fact that efficiency margins matter more at the volume price points where every percent of range counts. But the induction motor remains relevant in the high-performance segment. The Plaid uses a triple motor layout with two PM motors on the front and an induction motor on the rear. The rear induction motor is chosen specifically for its high-power tolerance and lack of demagnetization risk during sustained high-output operation. Track use, rapid successive launches, and hard regen from very high speeds push the motor into conditions where an induction design has a clear advantage.
Parameter Identification: A Practical Walkthrough
If you need to identify the parameters of a Tesla induction motor for a conversion or research project, here's a method that works. You'll need a variable frequency drive capable of low-speed operation, a power analyzer to measure input voltage and current, and a tachometer or encoder for speed measurement. Start with the DC resistance measurement. Apply a low-voltage DC pulse to two of the stator phases and measure the resistance. Do this for all three phase pairs and average the results. The stator resistance per phase is approximately the average of the three measurements. Record this value. It changes with temperature, so note the winding temperature at the time of measurement. A rule of thumb is that copper resistance increases by about 0.4 percent per degree Celsius above 20 degrees. Next, run the no-load test. Spin the motor at several speeds below base speed using the VFD, keeping the V/Hz ratio constant. Measure the input power, voltage, and current at each speed. The input power at no load represents the rotational losses plus the stator copper losses. Subtract the stator copper losses, calculated as three times the square of the no-load current times the stator resistance, to get the rotational loss at each speed.
Then run the locked rotor test. Block the rotor and apply reduced voltage at a few frequencies, starting low and increasing. Measure impedance at each point. The locked rotor impedance gives you the sum of stator and rotor leakage reactances. You'll need to split this between stator and rotor, which is usually done by assuming a ratio based on the motor design class. For a design class B motor, which most EV motors fall into, the stator leakage is approximately 40 percent of the total locked rotor reactance. Finally, run a loaded test at a known slip. Measure the input power and calculate the air gap power by subtracting stator copper and core losses. The rotor copper loss is the slip times the air gap power. From this, you can solve for the rotor resistance referred to the stator. The magnetizing inductance comes from the no-load test data after accounting for the leakage reactance. These parameters feed directly into the motor model used by the field-oriented controller. Getting them wrong by more than ten percent will cause noticeable torque errors, especially at low speed. A well-tuned controller with accurate parameters tracks torque within two to three percent of the command across the entire operating range.

The Broader Impact
The induction motor's role in Tesla's success is easy to underestimate because it's an older technology. But its selection was a deliberate bet on manufacturability, supply chain security, and performance under stress. Those bets paid off. The Model S became the benchmark sedan for a decade. The induction motor in the rear axle handled the drivetrain demands while the company figured out what it was doing at scale. Other manufacturers studied the approach. Porsche used induction motors in the Taycan's rear axle initially, though they later shifted to PM for the performance variant. Mercedes' EQ models have used various configurations, and Ford's Mustang Mach-E induction version chose induction for similar reasons. The pattern suggests that induction remains a serious option whenever production volume and material risk are central concerns. As battery costs continue to drop and PM motor prices stabilize, the competitive landscape shifts again. But for now, the AC induction motor in Tesla vehicles represents a proven, scalable solution that traded some efficiency for resilience and manufacturability. In a company that prioritized growth above almost everything else in its early years, that tradeoff was the right call.

