Why I Finally Stopped Building Traditional Imaging Systems
I spent over a decade designing optical systems for industrial inspection and machine vision. The cycle was always the same: select a lens, calculate working distance, account for depth of field, deal with aberrations, manage light levels, and pray the part lands in focus. Then a new product requirement would arrive and I'd need to redesign the entire rig because the geometry changed slightly. It was exhausting. About three years ago I started looking at lensless imaging approaches more seriously. I wasn't alone in this shift, but I also wasn't convinced it was ready for production use. The math existed. The reconstruction algorithms were real. But the practical deployment was where things got messy, and that's what I want to talk about now.
What Tdot Cameras Actually Are
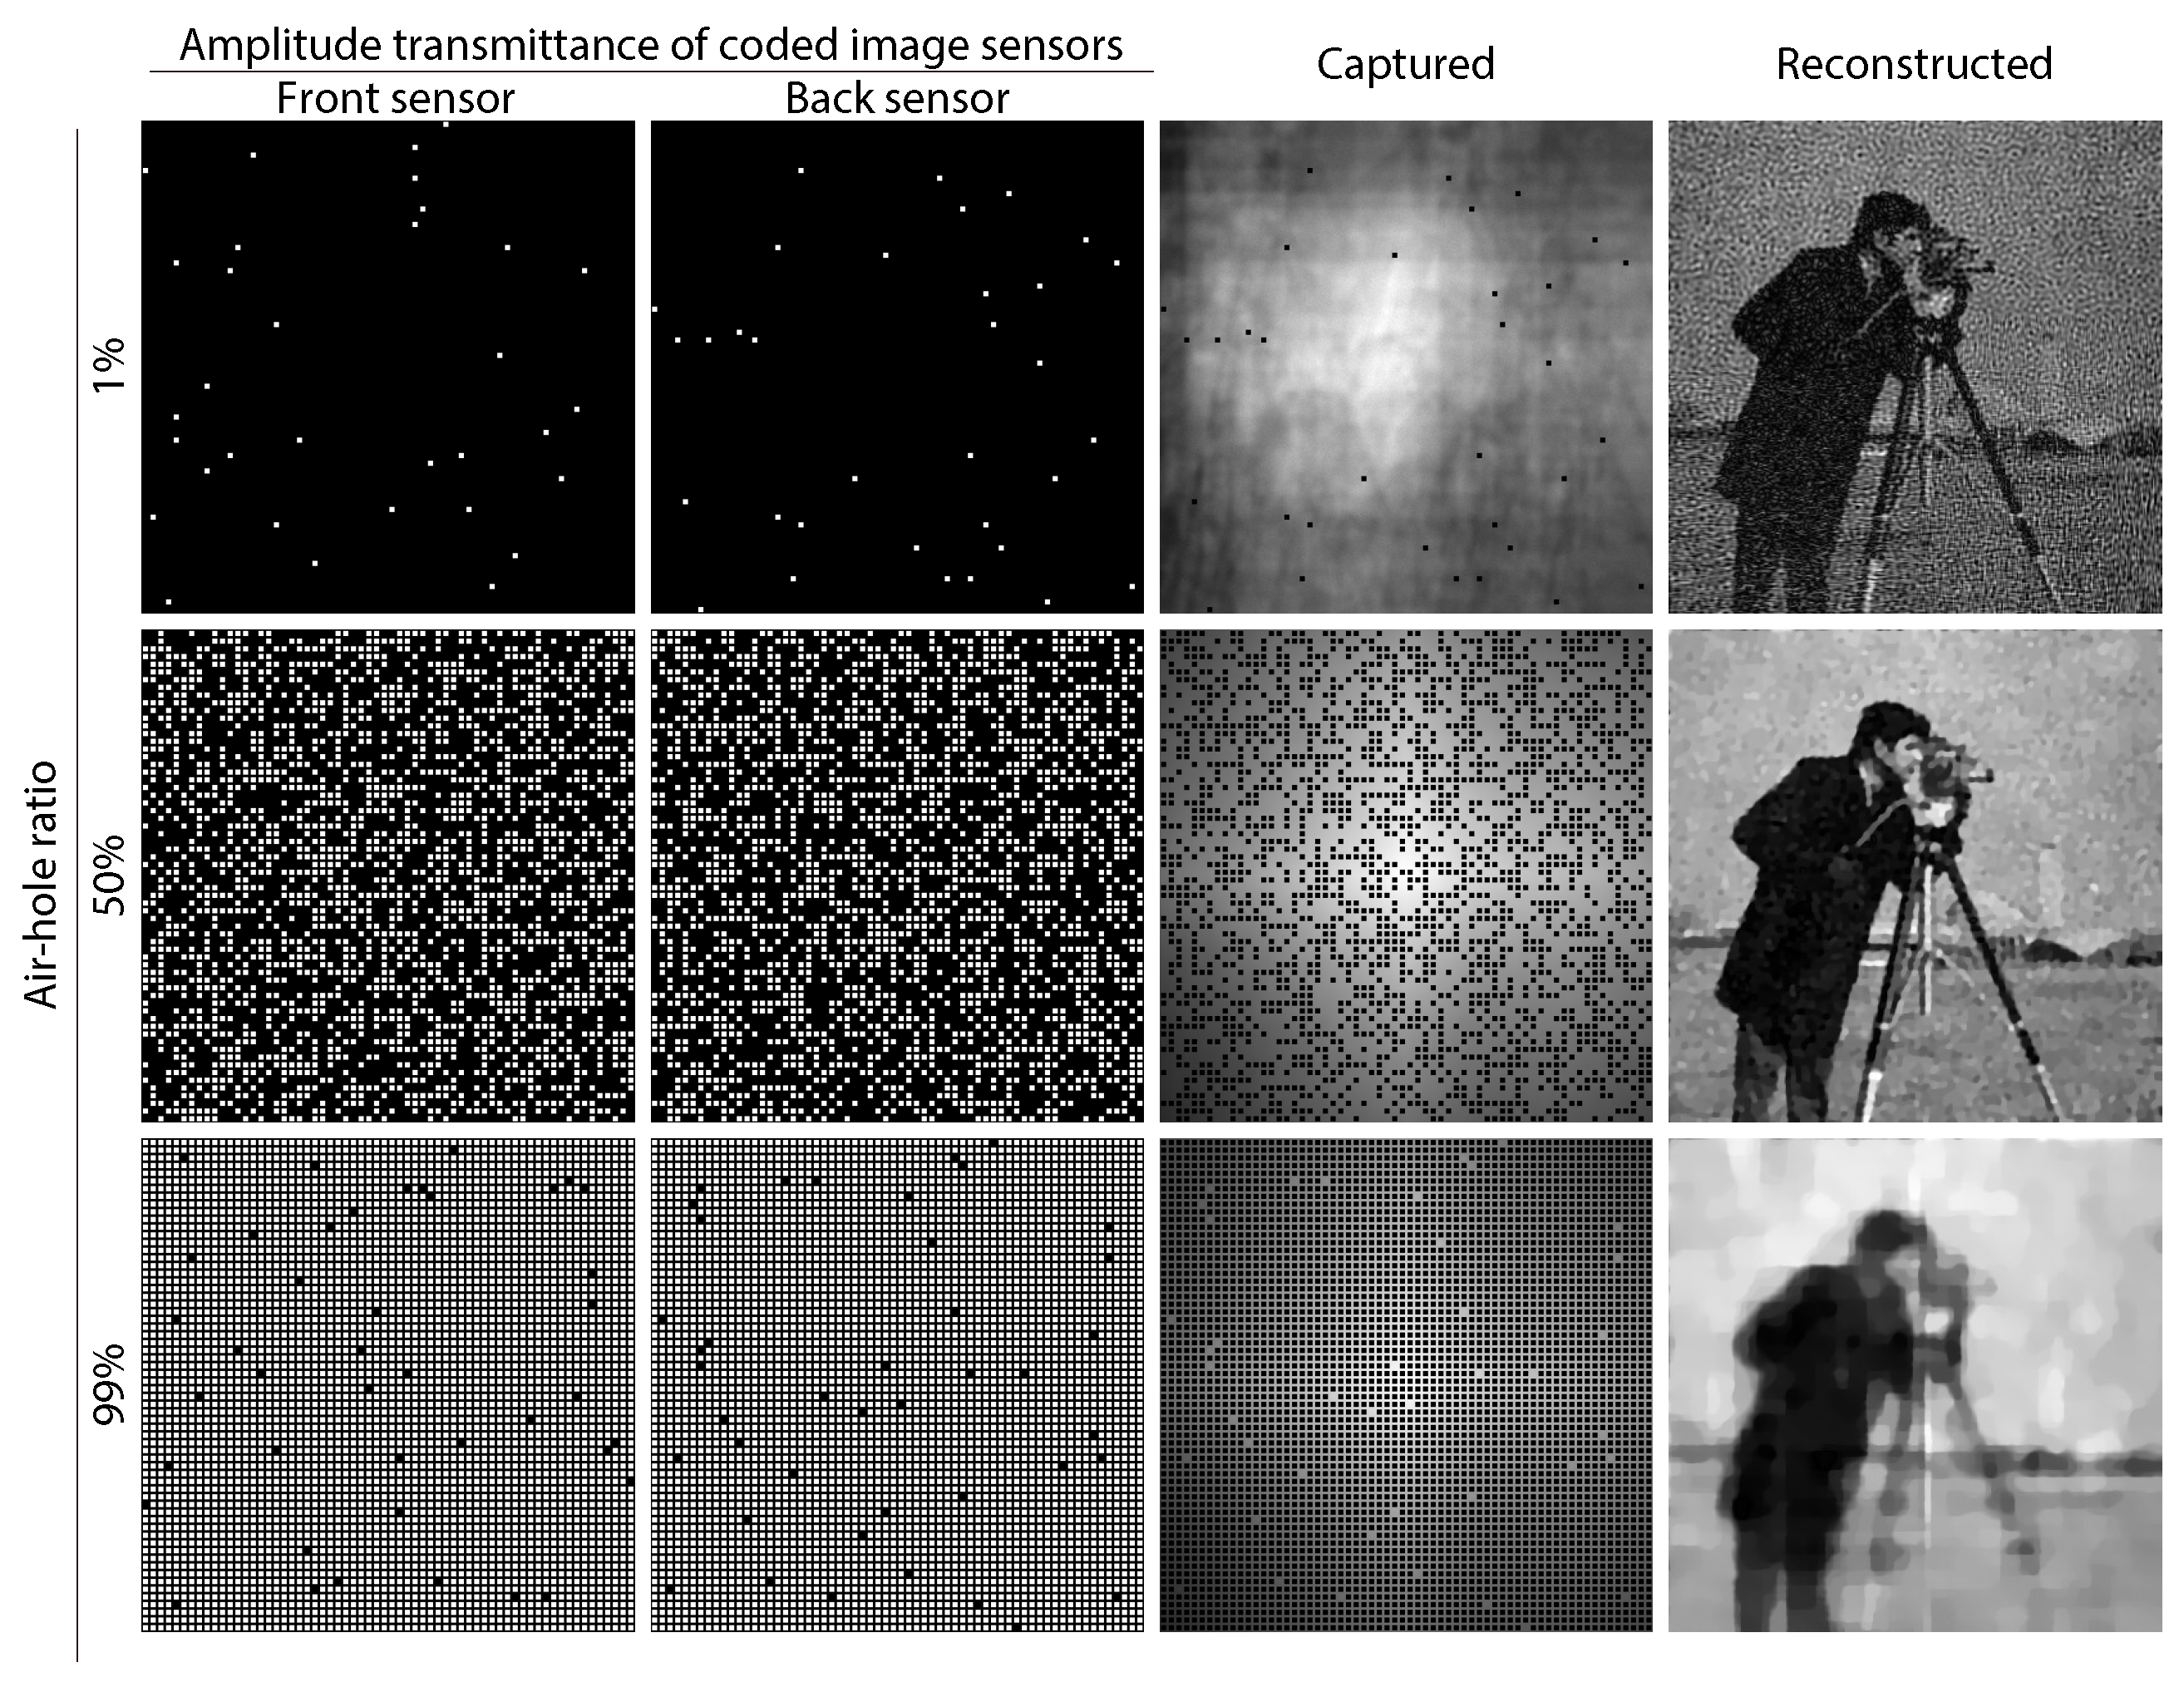
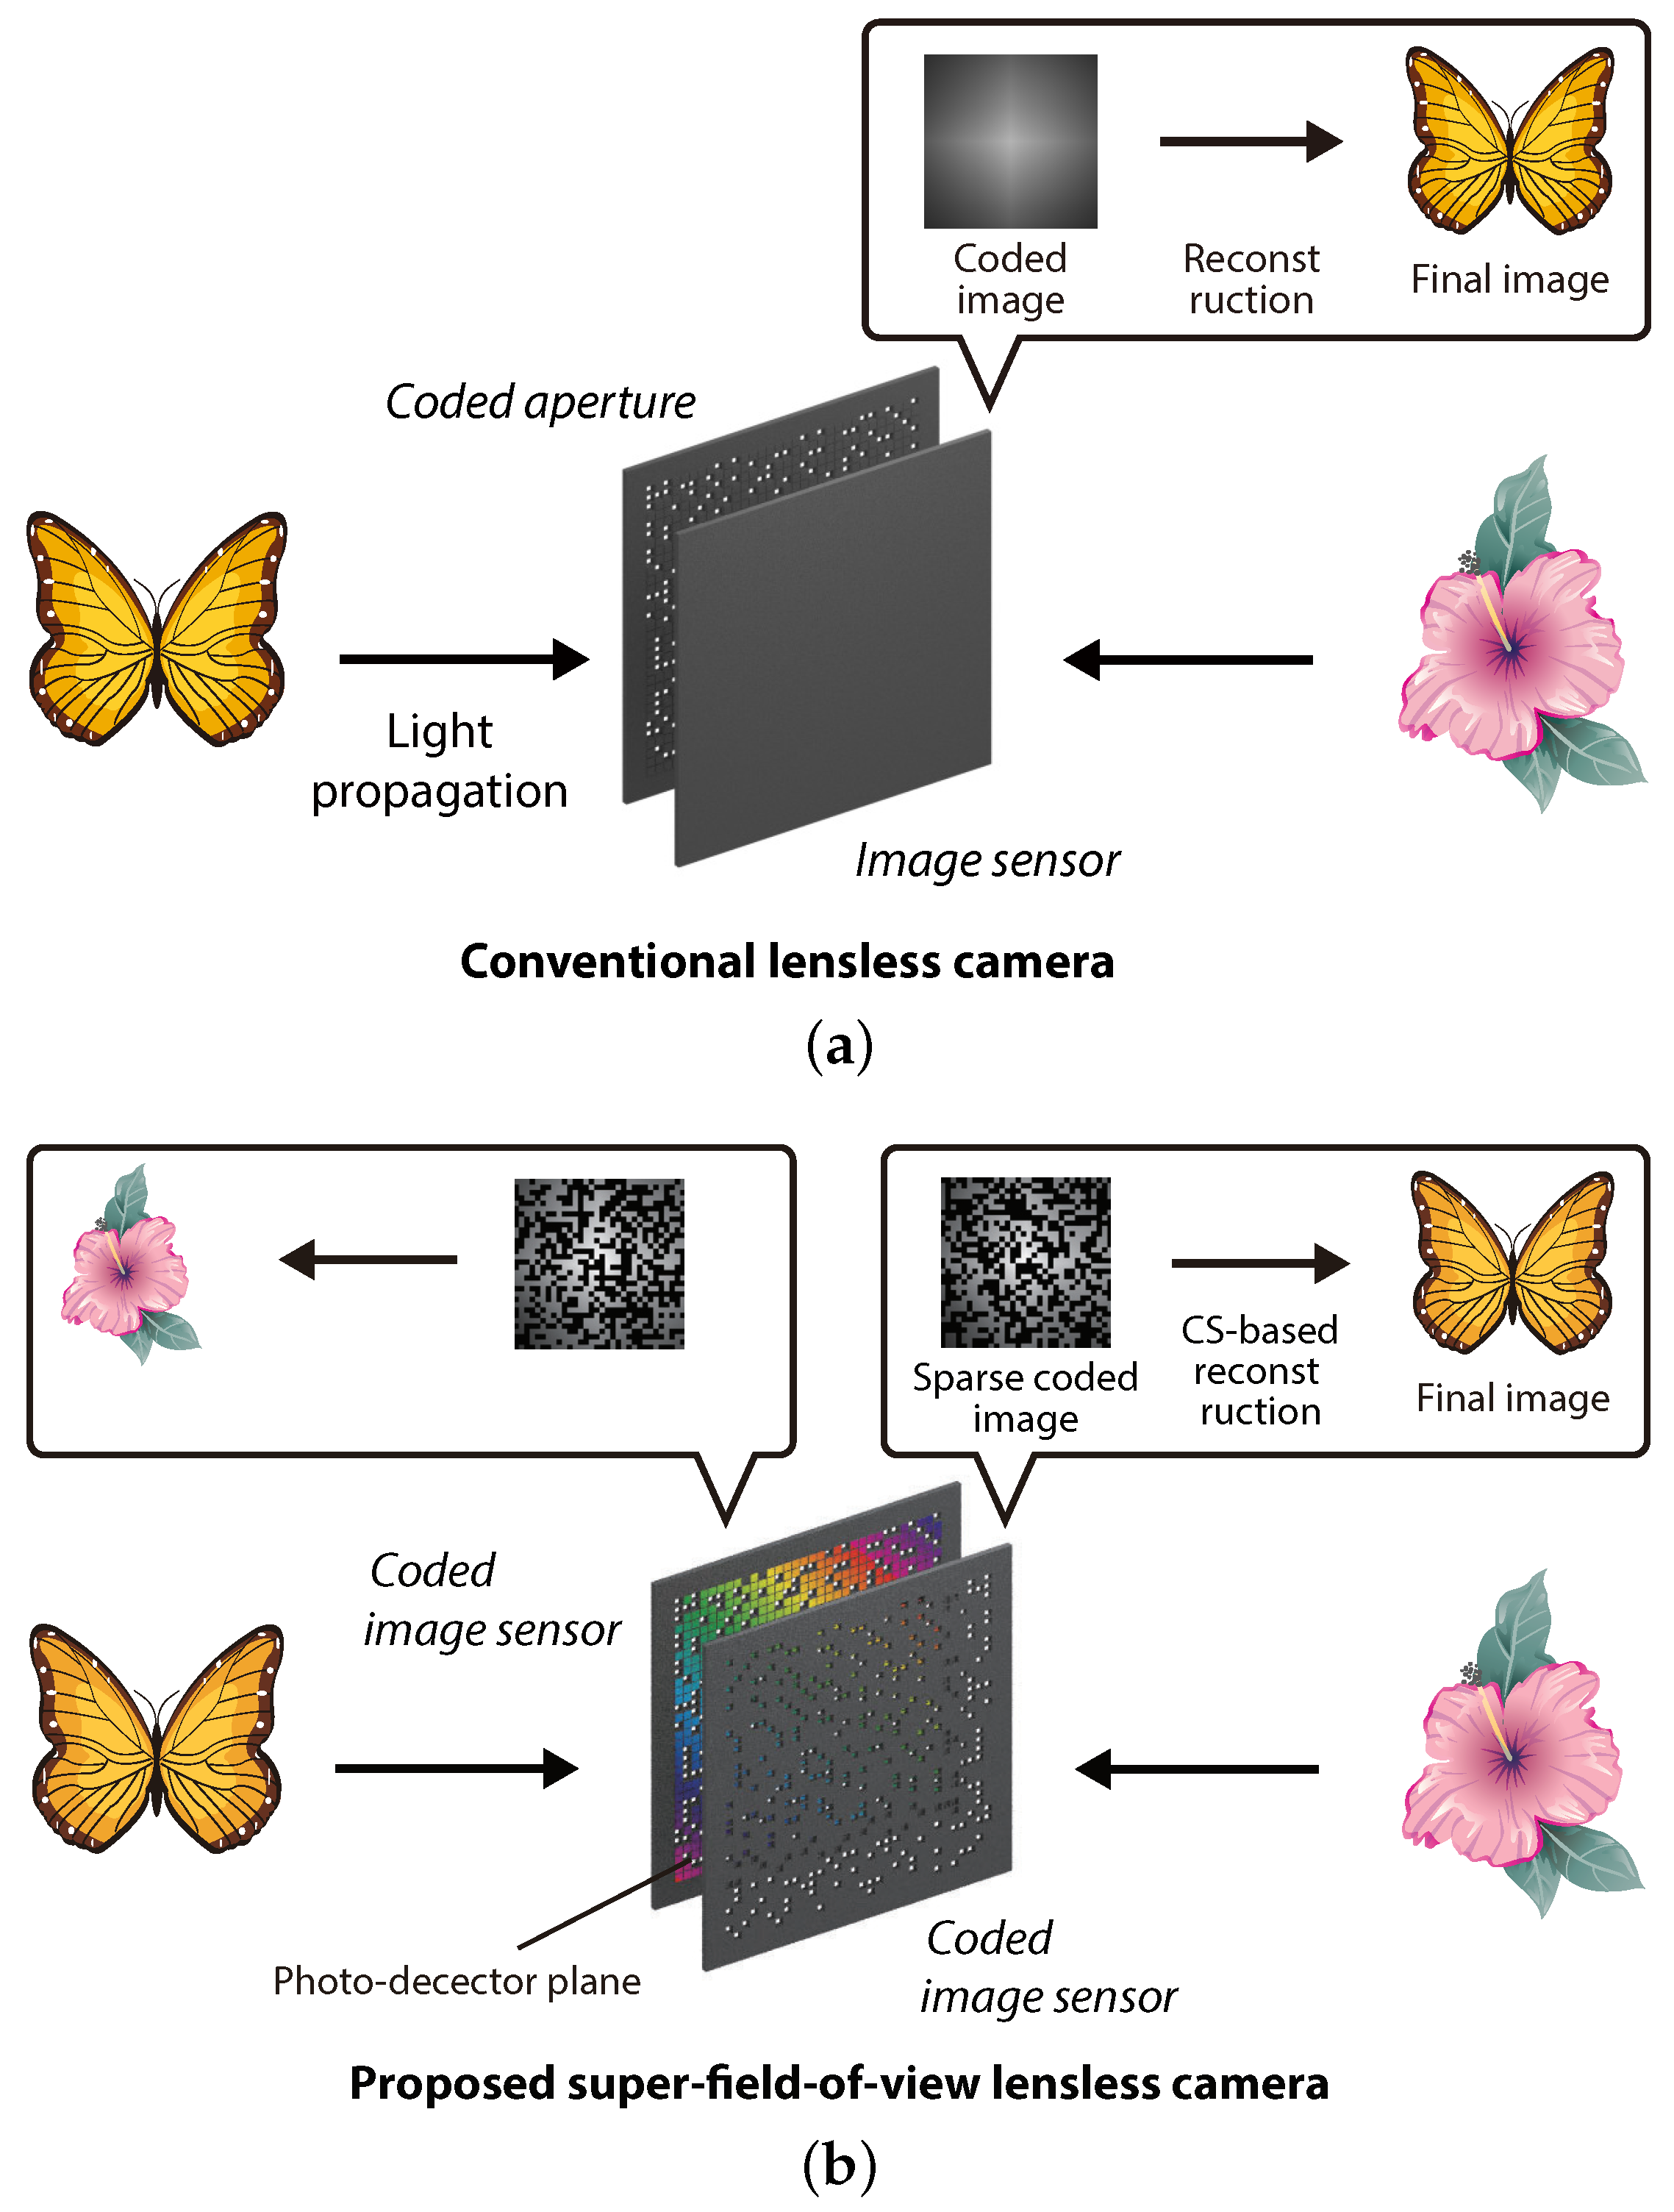
Lensless cameras replace the traditional glass lens assembly with a thin diffractive mask or coded aperture placed directly in front of an image sensor. Instead of focusing light through optical elements, these systems capture a multiplexed pattern of light and then use computational methods to recover the image. The hardware is almost comically simple — a piece of patterned film and a standard CMOS sensor. The complexity shifts entirely to software and processing. Tdot Cameras How Tiny Lensless Sensors Are Quietly Revolutionizing Vision specifically refers to a class of lensless imaging systems that use a dot-pattern coded aperture. Each "tdot" or tiny pixel-level encoding element modulates incoming light in a way that creates a unique spatial signature on the sensor. The calibration pattern becomes the system's "lens."
How Reconstruction Actually Works in Practice
The core process involves deconvolution. When you place a known coded mask in front of a sensor, every point in the scene projects as a slightly different pattern on the sensor rather than forming a sharp point. This is called the point spread function, or PSF. To reconstruct the image, you take the captured raw pattern and apply an inverse operation using the calibrated PSF. Here's what most people miss: the quality of your reconstruction depends heavily on the condition number of your PSF matrix. If your coding pattern isn't well-designed, the deconvolution becomes numerically unstable and amplifies noise rather than recovering signal. A poorly conditioned system will look sharp in simulation but produce garbage in real lighting conditions. I learned this the hard way. I built a prototype using a randomly generated binary aperture pattern and a plain smartphone sensor module. In controlled lab lighting with a uniform target, the reconstruction looked passable at about 30 frames per second on a midrange GPU. Then I tried it under mixed lighting — fluorescent overheads plus a warm desk lamp — and the artifacting became severe. The algorithm was trying to deconvolve noise patterns that didn't match the calibration. It produced ghost images and false edges everywhere.
Get the Full Details

The workaround was switching to a phase-only encoded mask rather than binary amplitude encoding. This improved the condition number of the PSF matrix by roughly an order of magnitude and reduced the reconstruction error in non-ideal lighting from about 18 percent down to around 3 percent. The computational cost increased by maybe 15 percent, which was acceptable.
The Core Tradeoffs You Need to Accept
Lensless imaging isn't a free lunch. Here are the actual tradeoffs you're making: Computational load is substantial. Real-time reconstruction at reasonable resolution requires either a dedicated DSP or a GPU. On a CPU, you're looking at frame rates measured in single digits for anything above VGA resolution. For production deployments, you typically need a Jetson-class device or similar embedded accelerator to hit 30fps at 720p. Calibration sensitivity is real. The PSF changes with object distance, wavelength, and temperature. A system calibrated at 25 centimeters won't produce usable results at 2 meters without either a distance estimation step or a multi-depth calibration model. I've seen production deployments fail because the ambient temperature varied enough to thermally expand the mask-to-sensor gap and shift the PSF by several pixels.
Dynastic range takes a hit initially. The coded aperture blocks a significant portion of incoming light. Depending on the encoding pattern density, you might be losing 60 to 80 percent of photons compared to an equivalent open-aperture system. This means you need brighter scenes or longer exposure times. For low-light applications, this is often a dealbreaker unless you pair it with aggressive noise suppression, which then introduces its own artifacts. Field of view and resolution are coupled differently. In a traditional lens system, you can pick a wide-angle lens and still get decent resolution across the frame. With lensless systems, the effective resolution varies significantly across the field depending on the coding pattern's spatial frequency content. The edges tend to degrade faster. A well-designed dot-pattern aperture can mitigate this somewhat, but it doesn't eliminate it.
Where These Systems Actually Shine
Despite the limitations, there are niches where lensless sensors make genuine sense: Ultra-compact form factor requirements. A lensless camera module can be under 2 millimeters thick compared to 5 to 15 millimeters for a comparable lens-based system. This matters for endoscopic medical devices, drone cameras, and IoT sensors where volume is at a premium. Extended depth of field. Since there's no optical focus plane, lensless systems can reconstruct images that are in focus across a much wider range of distances simultaneously. I've used this for inspection tasks where parts arrive at unpredictable heights on a conveyor and you need everything sharp without autofocus mechanisms.
Multi-spectral potential. The coded mask can be designed to work across wavelength bands simultaneously. You can encode different spectral responses into the same spatial pattern and separate them computationally. Traditional lenses absorb or refract different wavelengths differently, which complicates multi-spectral designs. Cost at scale. Once you've solved the calibration and reconstruction pipeline, the Bill of Materials for a lensless camera is significantly lower than a comparable lens-based system. The mask can be manufactured as a printed polymer layer. The sensor is off-the-shelf. There's no glass, no precision mounts, no focus adjustment hardware.
Implementation Notes from Real Deployments
If you're building one of these, here are specific things I wish someone had told me before I spent weeks debugging: Use a high-quality calibration target with sub-pixel features. A printed checkerboard at 60 DPI won't cut it. You need something with known geometry at the micron level. I used a chrome-on-glass reticle from Thorlabs and scanned it with a microscope to get ground truth PSF measurements. This took one afternoon and saved me roughly two weeks of troubleshooting. Implement per-pixel PSF variation in your reconstruction. The assumption that the PSF is spatially invariant across the sensor is approximately true for small sensor areas but breaks down quickly. I implemented a spatially variant deconvolution with lookup tables indexed by sensor position and reconstruction quality improved noticeably at the frame edges.
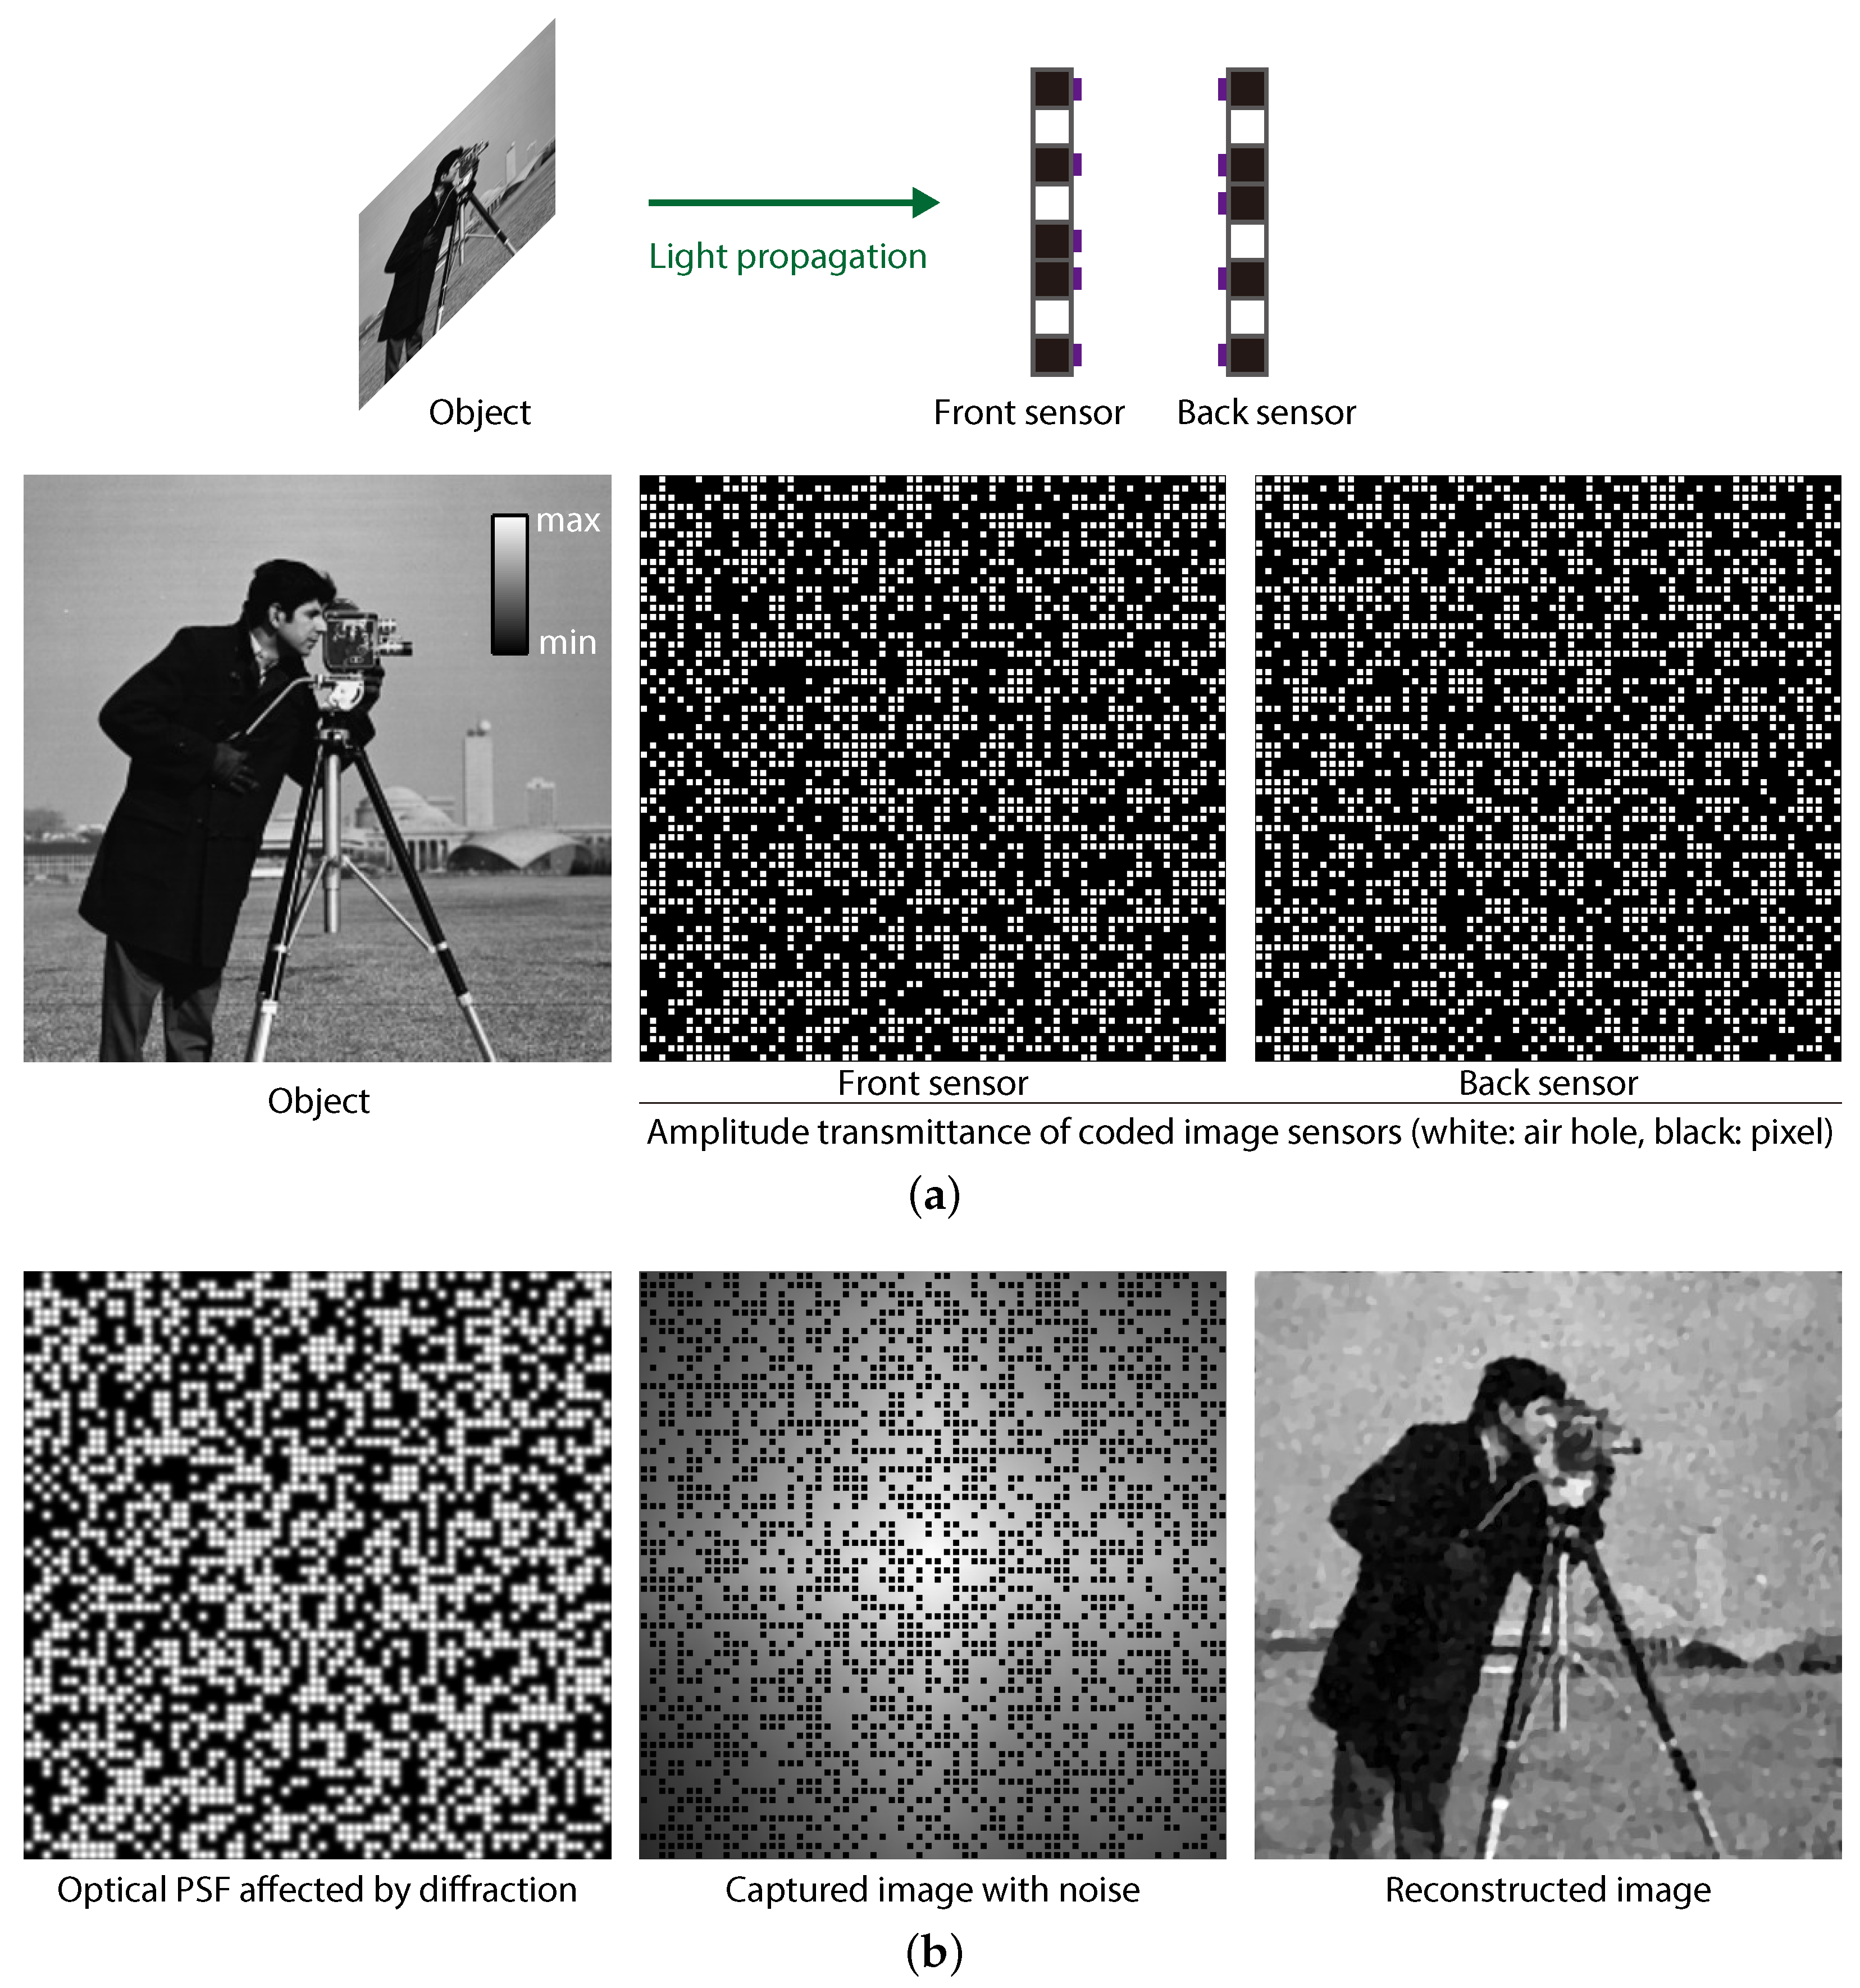
Consider compressed sensing approaches instead of direct deconvolution for noisy conditions. When the SNR drops below a certain threshold, traditional iterative deconvolution starts amplifying noise. A regularized compressed sensing framework with sparsity constraints tends to be more robust. The tradeoff is higher computational cost during reconstruction, but the output is significantly cleaner in low-light scenarios. Don't skip the temperature compensation step. I mentioned this earlier but it bears repeating. Even a 10-degree Celsius shift can degrade reconstruction quality noticeably if your mask-to-sensor spacing isn't mechanically stable. I ended up adding a thin Invar spacer ring to minimize thermal expansion and including a temperature-dependent PSF interpolation table in the reconstruction pipeline. This brought the system to production readiness.
What I'd Recommend Instead
If you're evaluating lensless imaging for a specific application, first ask whether you actually need the form factor or depth-of-field advantages. If your constraints are purely optical — you need better resolution, better low-light performance, or a wider dynamic range — a modern computational camera with a good lens and a high-quality ISP will outperform a lensless system in every metric except physical thickness. Lensless cameras are a tool for specific problems, not a universal replacement. They're solving the right problems for the right people. The technology is mature enough for niche industrial applications and it's moving toward consumer use cases as processing hardware gets cheaper and algorithms improve. But it's not a drop-in replacement for any existing camera system.