Three Ratios, One Circle, Everything Else Follows
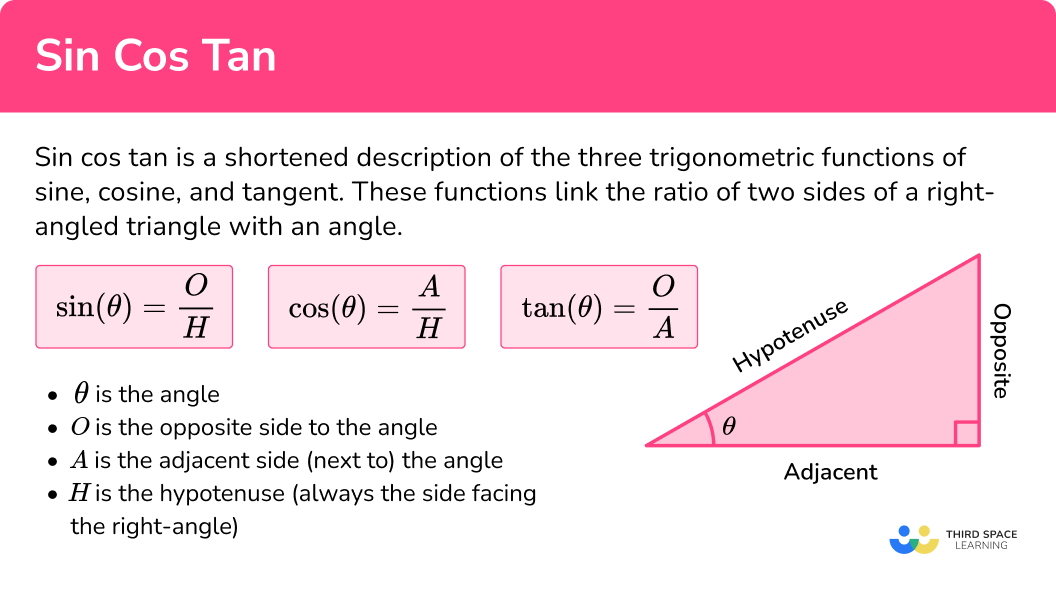
At a basic level, tan, sin, and cos are just ratios you get by slicing a right triangle. Draw an angle. Drop a perpendicular. The side opposite over the hypotenuse is sine. Adjacent over hypotenuse is cosine. Opposite over adjacent is tangent. That is it. Those three numbers, paired with an angle, have been keeping bridges from falling down and radios from tuning into dead air for roughly four hundred years. The part nobody mentions until they break it is the switch from triangles to the unit circle. Once you map sin and cos onto a circle with radius one, they stop being static triangle measurements and become functions that repeat. That shift is what lets engineers use them for signal processing, structural dynamics, Fourier analysis, and basically anything that oscillates. If you only ever learned them as SOHCAHTOA and never made the circle connection, you will hit a wall fast.
Tan Sin Cos The Foundational Trigonometric Triad Powering Modern Science
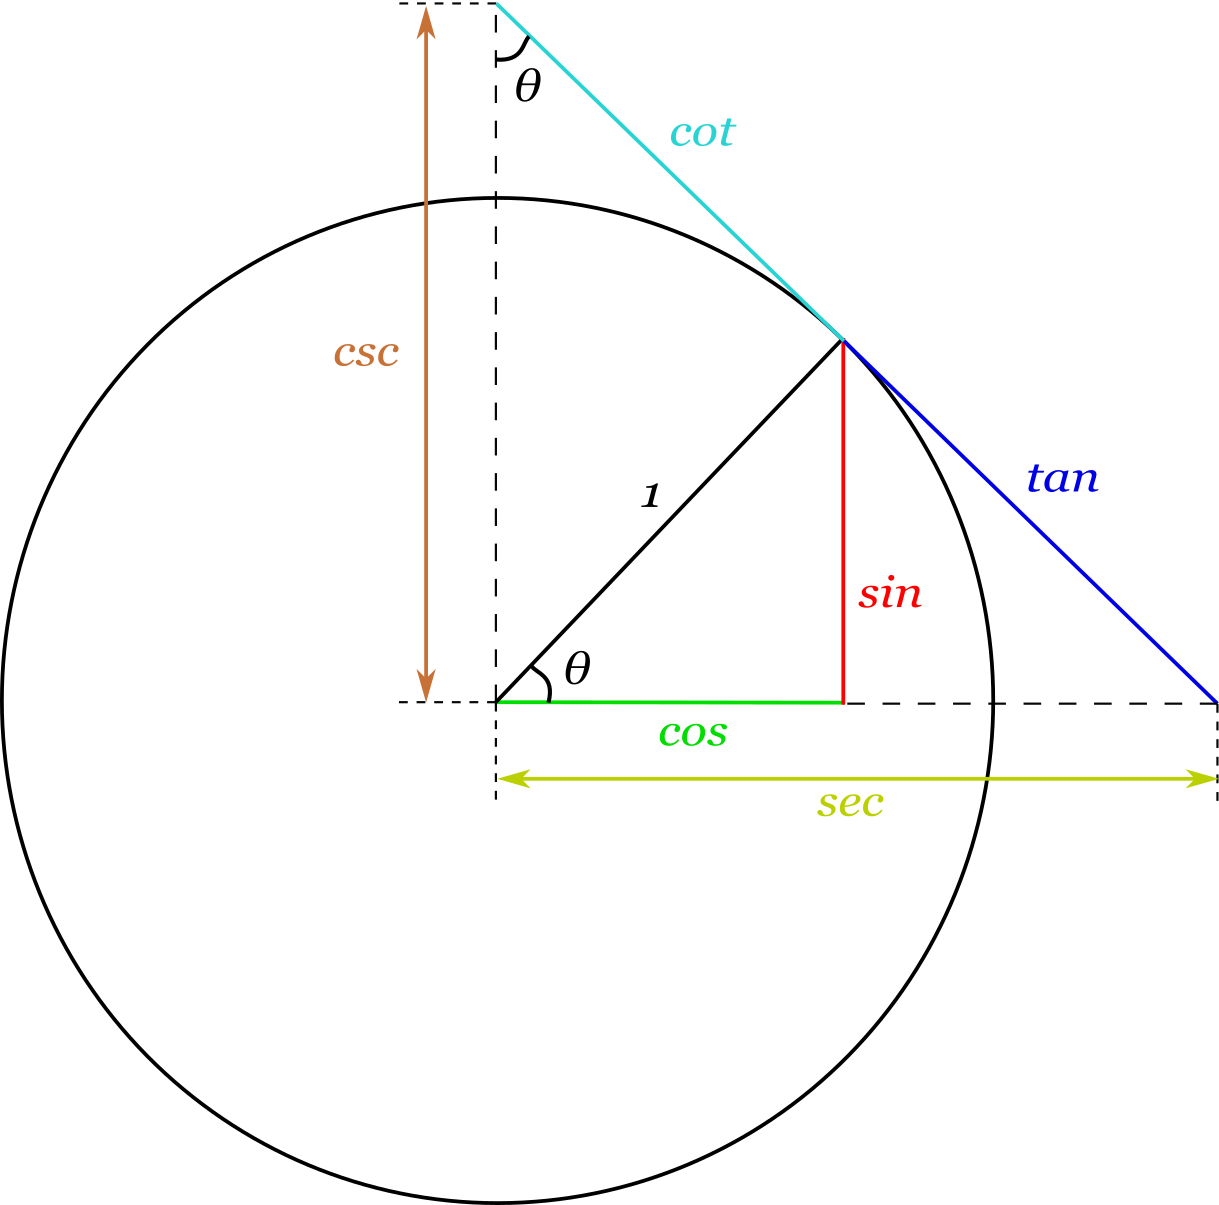
I see people treat these three like separate tools. They are not. They are projections of the same rotating vector. Sin is the vertical component. Cos is the horizontal component. Tan is the slope of the line from the origin to that point on the circle, extended until it hits the tangent line at x equals one. Once that visual clicks, a lot of the messy identities stop feeling arbitrary. My work involves a mix of simulation, signal filtering, and calibration routines. Trig shows up when I am decomposing forces on a joint, translating between phase and time delays, or unwrapping encoder data. I rarely reach for tan, sin, and cos in a vacuum. I usually pair them with a coordinate transform or a small state estimate. The math is the same, but the context changes how carefully I check edge cases. Here is a practical workflow I go through before trusting the output of any trig-heavy routine.
I normalize angles first. Most libraries accept radians, some accept degrees, and a few legacy systems still expect grads because reasons. I convert everything to radians immediately and store it that way internally. Mixing units in a single pass is how you get a motor to spin the wrong direction once a month and waste two days chasing it. I clamp inputs to the valid domain when I need stability. Functions like acos and asin throw domain errors if a floating point drift pushes a value slightly past negative one or one. I wrote a small wrapper that clamps to the range before calling those inverse functions. It has saved me more production incidents than I care to admit. I avoid computing tan when I only need a ratio. Tan is sin divided by cos. When cos is near zero, tan blows up. If your algorithm needs the ratio, pass sin and cos separately and divide inside the function, with a guard against dividing by a near-zero cos. This cuts runtime errors in feedback loops where angles approach pi over two.
Get the Full Details

A Real Problem I Hit, and What Worked
Last year I was building a calibration script for a rotational sensor array. The sensor reported angles in a wrapping range, and I needed to compute the relative offset between two sensors using cos of the difference. The formula I used was straightforward: theta minus phi, take the cos, then compute the dot product. The outputs kept drifting by about zero point zero zero four radians every cycle. Small, but enough to mess up a precision alignment task. I traced it through a few evenings and found the issue. The raw sensor values were close to the pi boundary, and when I subtracted two values near pi, the floating point rounding caused a tiny angle wrap error. The cos of that slightly wrong angle looked fine at first glance, but when chained across multiple sensors in a loop, the error compounded. The fix was not clever. I switched to using the atan2 formulation for angular distance. Instead of computing cos of the difference directly, I computed sin of half the difference and cos of half the difference, then used atan2 to get the signed angular distance. This formulation is numerically stable across the full range, including near the wrap point. It also gives me the sign for free, which the original cos-only approach did not.
I added a unit test that checked the boundary case explicitly: two angles at positive pi minus epsilon and negative pi plus epsilon. The old implementation failed that test. The atan2 half-angle version passed consistently. I recommend writing that boundary test before you ship anything trig-heavy.
Counter-Intuitive Bits Beginners Miss
First, tan is not just the steepness of a triangle. In signal processing, the ratio of sin to cos shows up as the quadrature component in demodulators. When you are doing phase detection, thinking of tan as a simple slope hides that it is actually encoding phase information directly. A phase shift translates into a tan ratio shift, which is why certain PLL designs use tan-based detectors instead of multiplying the full waveforms. Second, people assume cos is always the adjacent side. That is true in a right triangle context, but in polar to Cartesian conversion, cos is the x projection and sin is the y projection. The labels swap depending on which axis you treat as the reference. If you anchor yourself to triangle terminology too rigidly, rotation matrices will feel unmotivated. They are not. They are just repeated applications of those two projections.

Where This Triad Breaks Down
I will be blunt about the failures because most tutorials gloss over them. Near ninety degrees, tan is useless for numerical work. The derivative goes to infinity. If you are fitting data or optimizing an angle parameter, a tan-based objective function will create a sharp ridge that stalling optimizers cannot cross. Use sin and cos instead, or switch to a half-angle tangent substitution if you must keep a scalar parameter. Inverse trig functions return only principal values. Asin returns results in negative pi over two to pi over two. Acos returns zero to pi. If your application needs angles outside those ranges, you have to infer the correct quadrant from the signs of sin and cos yourself. Using only one inverse function without quadrant logic will silently give you wrong answers in half the cases.
Floating point drift accumulates in iterative rotation systems. If you apply a small rotation step thousands of times using sin and cos directly, the result will slowly leave the unit circle. The vector will grow or shrink. The workaround is periodic renormalization: divide the current x and y components by their magnitude. It costs almost nothing and prevents long-running simulators from drifting into nonsense.
Quick Reference for Common Transformations
Polar to Cartesian: x equals r times cos of theta. Y equals r times sin of theta. Cartesian to polar: r equals the square root of x squared plus y squared. Theta equals atan2 of y over x. Angle addition for sin: sin of a plus b equals sin a cos b plus cos a sin b. The cosine version swaps the plus to a minus. Keep them side by side when you need to derive one from the other.
Half-angle forms: sin of theta over two equals plus or minus the square root of one minus cos theta, divided by two. The sign depends on the quadrant. Cosine half-angle is similar, with a plus one on top. These are useful when you need to reduce power in a Fourier term or simplify an integral.
Tools I Reach For
For quick prototyping, I use Python with NumPy and SciPy. The numpyDegrees package is handy when I need to validate old MATLAB scripts that assumed degrees. For embedded work, I avoid the standard library sin and cos when performance matters and use a Chebyshev polynomial approximation tuned to the target microcontroller. The built-in libc versions are accurate but slower than a properly scaled minimax approximation for tight loops. If you need something you can run offline without dependencies, there are small C implementations of double-precision trig functions available under permissive licenses. Look for implementations based on the fdlibm reference. They are well tested and give predictable results across platforms. For learning, I prefer working through derivations by hand before writing code. The identities lock in faster when you see where they come from rather than memorizing them. Try deriving the sum formulas from Euler's relation. It takes ten minutes and removes the need to remember which version has the plus and which has the minus.
When to Avoid Trig Altogether
Not every problem needs sin, cos, or tan. If you are only comparing directions, a dot product or cross product in vector form is often cleaner and avoids angle extraction entirely. If you are doing interpolation on a sphere, quaternions beat Euler angles for interpolation smoothness and dodge gimbal lock. Trig is the right tool when the phase or angular position is the thing you care about. It is the wrong tool when you can express the same relationship with vectors or complex numbers and keep the computation simpler. I keep a small checklist before committing to a trig-based approach. The signal oscillates or rotates. The geometry involves an angle explicitly. No cleaner algebraic substitute exists. If all three are true, I proceed. If one is false, I reconsider.

Final Practical Notes
Always write a boundary test for your trig code. Cover zero, pi over two, pi, negative pi over two, and values very close to each. Floating point behavior at those points is where bugs hide. Prefer atan2 over asin or acos when you need an angle from two coordinates. It handles quadrants correctly and does not crash when one coordinate is zero. Document whether your functions expect radians or degrees. Mixing them in a single file is the fastest way to introduce a subtle bug that looks correct until a client reports a one percent error on a calibration readout.
The tan sin cos triad is simple enough that beginners underestimate it and complex enough that experts still find edge cases. That is normal. The goal is not to master every identity. The goal is to know which formulation is numerically safe for the problem at hand, and to catch the failure modes before they reach production.

