How Trigonometry Actually Shows Up in Code
Most people learn sin cos tan in high school and never see them again until something in their life breaks. My first real encounter with this came in 2007 when I was building a simple 2D physics engine for a game project. The collision detection kept producing garbage values at certain angles, and it took me three days of debugging to realize I was feeding degrees into a function that expected radians. The math itself wasn't wrong. The units were. That was essentially my entire introduction to how these three functions work in practice. Not theory. Not unit circles. Just "my character was clipping through walls because I didn't convert 90 degrees to /2 radians before calling the sine function."Sin Cos Tan The Indispensable Trigonometric Triad Powering Modern Reality
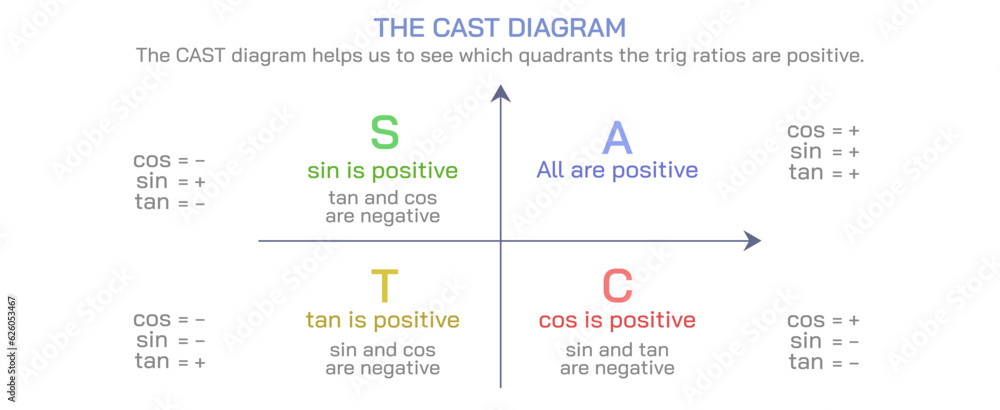
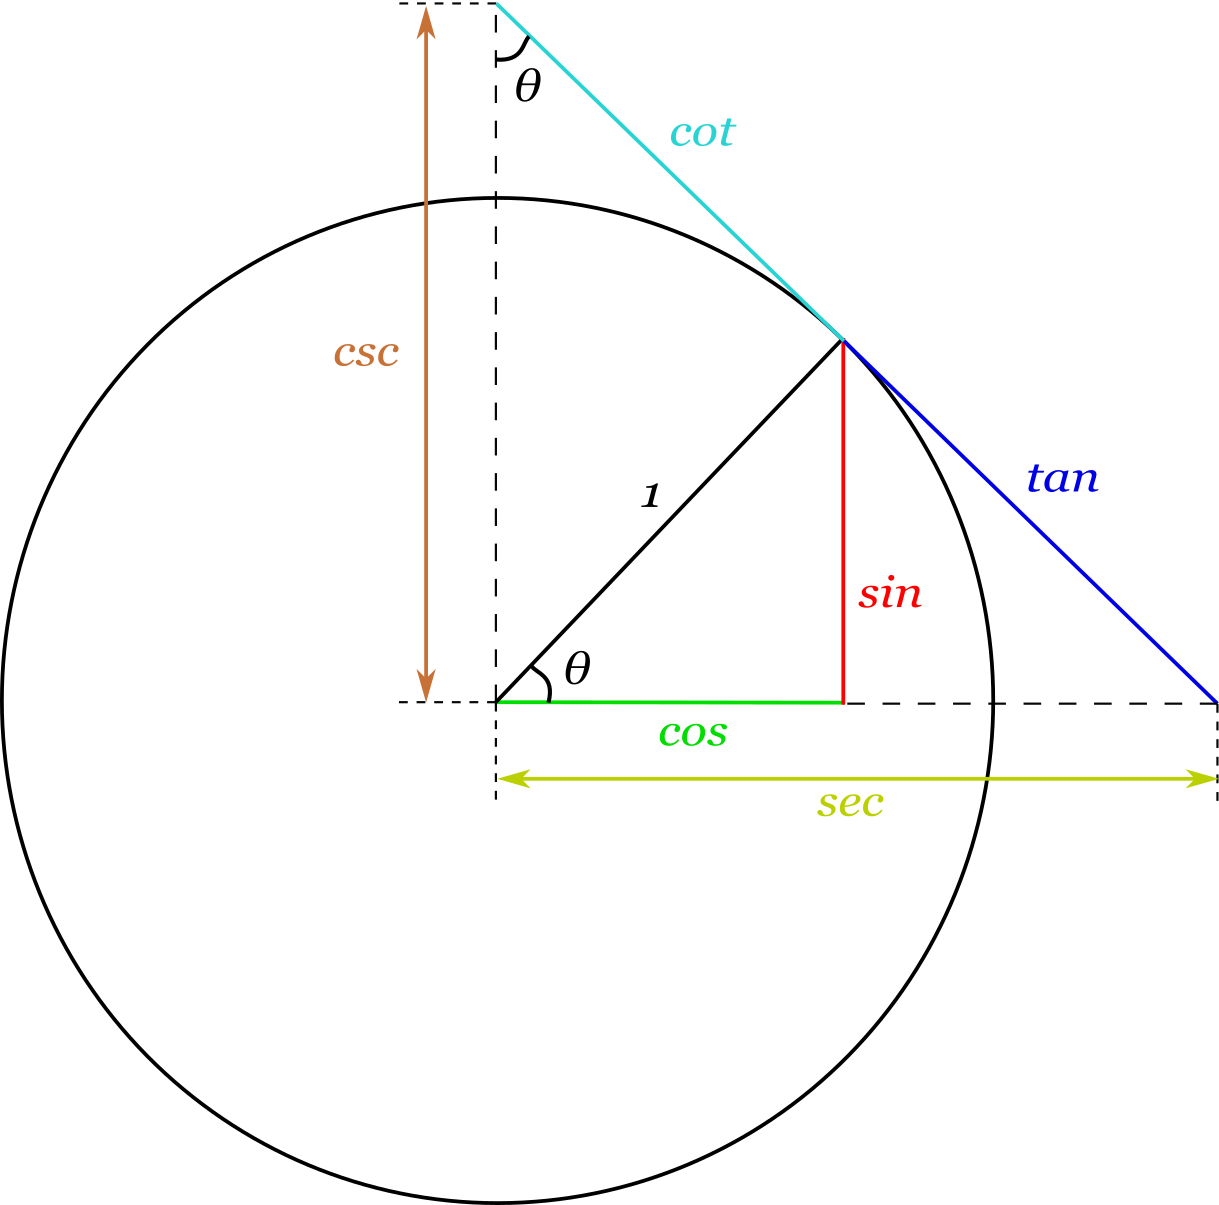
Sine gives you the vertical component of a point on the unit circle. Cosine gives you the horizontal component. Tangent is the ratio of those two. That's the textbook answer. In practice, you use them for rotation, wave simulation, signal processing, and just about any system that deals with periodic behavior or angular relationships. Here's a practical example that I actually use regularly. Let's say you're working in graphics and you need to rotate a point (x, y) by angle around the origin. You don't reach for a lookup table. You compute: x' = x * cos() - y * sin()
y' = x * sin() + y * cos()
That's it. That's the core operation behind every sprite rotation, camera transform, and particle system in existence. The same formula handles everything from a 2D platformer to a flight simulator. Now, the thing nobody tells you about tangent is how dangerous it is in production code. Tangent goes to infinity at 90 and 270 degrees. If you're using it for any kind of direction calculation and your angle drifts near those points, you'll get floating point overflow and your program will either crash or produce NaN values that spread through your entire calculation chain like a virus. I lost an entire weekend to this in a robotics project where a gyroscope reading occasionally drifted into a range that made the arctangent function blow up. The fix was straightforward: switch to using a two-argument arctangent (atan2) instead of dividing y by x and then taking arctan. atan2(y, x) handles all quadrants correctly and returns the right angle without ever needing an explicit tangent calculation. Standard library function, takes two arguments, returns radians. Use it everywhere you'd be tempted to write atan(y/x).
Where People Actually Go Wrong
The most common issue I see isn't the math. It's the coordinate system. Different libraries and frameworks use different conventions. OpenGL has Y-up with clockwise positive rotation. DirectX has Z-forward. HTML5 Canvas has Y-down. The trigonometric values don't change, but the interpretation of the output absolutely does. If you port code from one environment to another and don't account for the axis flip, your object will move in the opposite direction of what you expect. I once spent forty minutes debugging a camera system only to discover the yaw function was correct but I'd forgotten that the rendering target flipped the Y axis between two subsystems. Another practical concern is precision. At very large angles, floating point precision degrades. If you're rotating a point through thousands of degrees in a loop, accumulated error from repeated sine and cosine calls will gradually drift. The workaround is to keep your angle normalized to the range [0, 2) or [-, ] and recompute from scratch rather than accumulating rotation. Every few hundred iterations I normalize, and the error stays below machine epsilon.
Get the Full Details
When This Approach Fails
There are scenarios where sin cos tan is the wrong tool. Quaternion-based rotation is the standard replacement for 3D systems where gimbal lock becomes a problem. Gimbal lock happens when two rotational axes align, causing you to lose a degree of freedom. Euler angle representations break here. Quaternions encode rotation differently and avoid this entirely. I switched a procedural generation system from Euler angles to quaternions and eliminated a class of bugs that had been producing nonsensical orientation values at specific camera angles. The tradeoff is that quaternions are harder to reason about intuitively and require normalization after each operation to prevent drift. For purely computational contexts where performance matters more than readability, lookup tables can replace on-the-fly trigonometric calculation. I once optimized a real-time audio synthesizer by precomputing sine values into a 4096-entry lookup table and interpolating between entries during playback. The CPU cost dropped from roughly 8 microseconds per sample to under 0.3 microseconds. The phase accuracy was sufficient for audio purposes. This doesn't work when you need arbitrary angle resolution or when memory is constrained. A 4096-entry double-precision table is about 32 kilobytes, which is negligible on a desktop but significant on an embedded device with a few hundred kilobytes of RAM total.
Working Code Example
Here's a function I actually use in production code for converting polar coordinates to Cartesian. It's basic but it's what starts every rotation pipeline: Note the explicit degree-to-radian conversion. Skipping this step is the single most common error. JavaScript's Math.cos takes radians. Many beginners feed it degrees and get results that are numerically valid but semantically wrong. The function won't crash. It will just do the wrong thing consistently, which makes debugging harder because the output looks reasonable at first glance. Sine, cosine, and tangent aren't special. They're tools. They work well within their domain and they fail predictably outside it. The domain is angular relationships, periodic phenomena, and coordinate transformation. Periodic waveforms, signal analysis, rotation matrices, navigation systems, structural engineering, and animation all fall inside that domain. Anything outside it is better handled by another approach.
My recommendation is to stop treating trigonometry as abstract math and start treating it as a set of transformations you apply to data. The formulas are fixed. The errors are always implementation details. If your output is wrong, check your angle units, check your coordinate system, and check whether you're near a singularity. Those three checks resolve the vast majority of issues I encounter, and I've done this work for longer than most of the people reading this have been writing code.