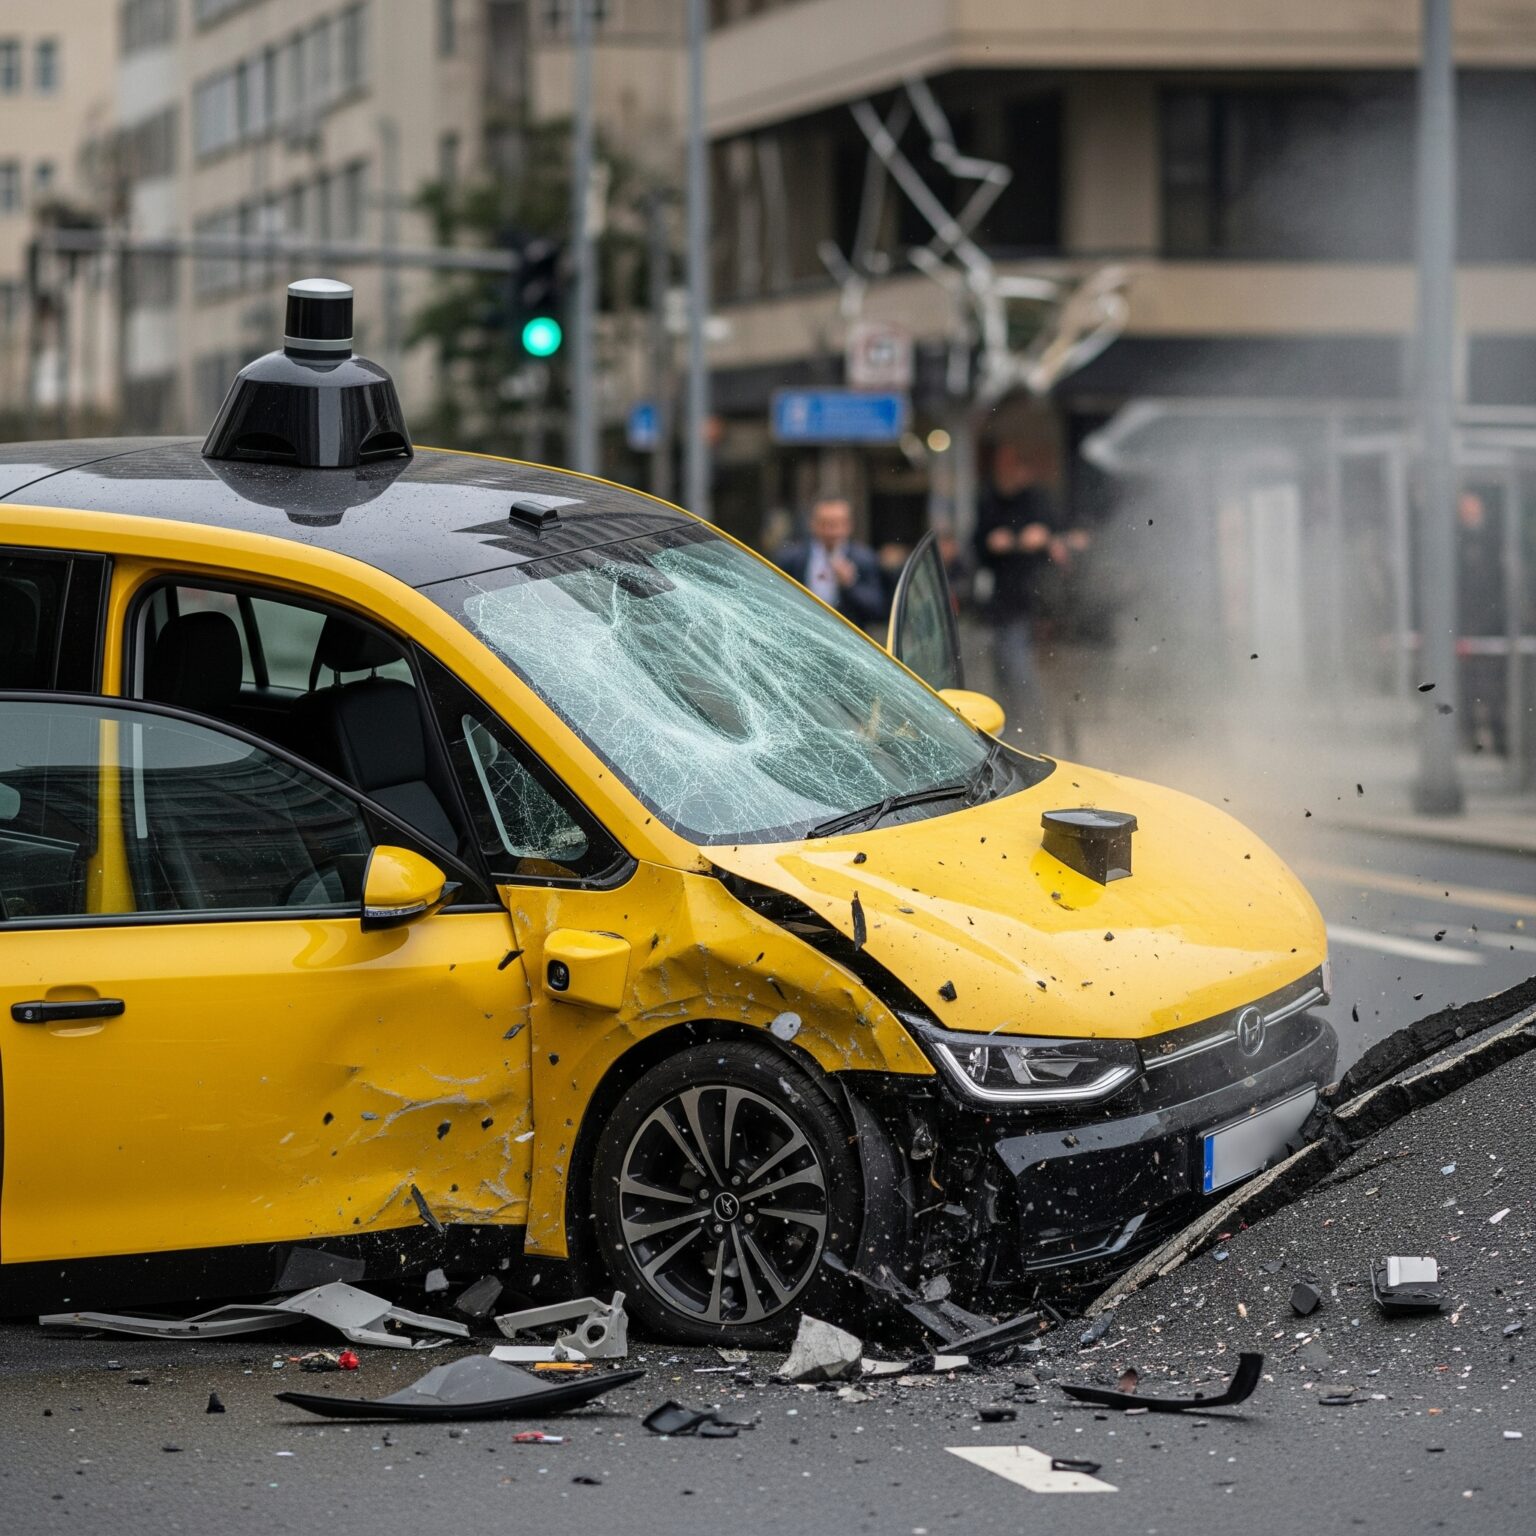
What Actually Happens When These Cars Get in Crashes
The landscape around autonomous vehicle incidents has shifted pretty dramatically over the last couple years. NHTSA data through early 2026 shows a meaningful drop in fatalities involving Level 4 systems in designated geofenced areas, but the nature of the crashes has changed rather than disappeared. They are less about high-speed highway pileups and more about low-speed urban failures that frustrate people more than they injure them. Waymo continues to operate in Phoenix, San Francisco, and Los Angeles with the highest miles between reported incidents among any publicly disclosed fleet. Their approach has always been conservative — the cars slow down, hesitate at intersections, and generally behave like someone who just got their license and is terrified of making a mistake. That caution is exactly why their injury rate sits where it is, but it also means the public perception problem is mostly about inconvenience, not terror.
Selfdriving Car Accidents Whats The Latest News
If you are looking for current information, the biggest recent developments center on two areas: regulatory fragmentation and the continued struggle with vulnerable road users. Several states passed new reporting requirements after the 2024 and 2025 legislative sessions, which has actually improved data quality but also created a confusing patchwork. California's DMV now requires incident reports within 24 hours instead of the previous 10-day window, and Texas introduced a novel provision allowing local municipalities to opt out of AV testing within their jurisdictions entirely. The other significant thread involves pedestrian and cyclist detection failures. These remain the hardest problem, and it shows in the crash data. A system can nail a lane change decision at 45 miles per hour and still fail to recognize a child on a bike crossing three car lengths ahead because the child is partially occluded by a parked truck. I have reviewed enough internal after-action reports from testing programs to tell you this is not a theoretical concern. Here is something most people covering this topic miss: the majority of what gets classified as an "autonomous vehicle accident" in the press is actually a human-driven vehicle striking a self-driving car that was already stopped or moving slowly. The narrative of the robot car careening through traffic has not been supported by the data since roughly 2022. The real stories are far more mundane and therefore harder to report compellingly.
The Technical Reality Behind the Headlines
Most AV systems rely on a sensor fusion pipeline that combines LiDAR point clouds, camera vision outputs, and radar returns before feeding them into a planning module. The failure modes are usually predictable once you understand how each layer contributes to the final decision. Camera models trained on daytime suburban imagery will degrade quickly in heavy rain or snow because those conditions were underrepresented in training datasets. LiDAR struggles with reflective surfaces and sometimes simply cannot penetrate certain materials. Radar fills in some gaps but introduces its own noise floor issues. The planning module then takes these imperfect inputs and attempts to generate a trajectory that satisfies safety constraints, traffic laws, and passenger comfort simultaneously. This is where most of the low-speed behavioral oddities come from. The system is constantly choosing between being right and being acceptable, and it often picks acceptability because passengers report differently when they feel jarred versus when they feel slightly uncertain. I spent about eighteen months reviewing post-crash telemetry from a mid-sized AV startup before they pivoted away from the public road program entirely. The thing that stood out was not a dramatic sensor failure or a catastrophic perception error. It was a series of small planning decisions that compounded over a three-block stretch. The car yielded too early at a crosswalk, which caused a line of human drivers behind it to become impatient, which led to one of them attempting an unsafe pass, which resulted in a sideswipe. The AV did nothing wrong by itself. It still shared responsibility for the outcome.
Get the Full Details

What the Data Actually Shows
Looking at published incident reports from the major operators, the breakdown tends to fall into a few categories. Perception failures account for maybe thirty to forty percent of incidents where the autonomous system bears primary or partial responsibility. Planning errors make up another twenty to thirty percent. The rest are either external factors — a human driver hitting the AV, weather conditions beyond the system's design limits, or infrastructure that was simply not designed with autonomous vehicles in mind. One counter-intuitive finding that keeps coming up: the more sophisticated the system, the more likely it is to encounter edge cases that cause unusual behavior. A basic adaptive cruise control system on a production car has very few failure modes because it does very little. A full self-driving stack makes dozens of decisions per second, and each decision is a potential point of failure. Complexity is both the solution and the problem. There is also a selection bias in the data that gets overlooked. Companies that publish incident reports tend to be the ones with more mature safety cultures, which means the worst actors are often the ones generating the loudest headlines without any transparency at all. When you see a story about a fatal crash involving an unbranded or poorly documented system, treat it with extra skepticism. The lack of detail is sometimes a red herring, but often it is simply poor operational discipline.
Where Things Are Heading
The industry is gradually moving toward standardized reporting frameworks, though progress has been slow. The SAE J3016 standard for levels of driving automation remains the baseline reference, but it was written in 2014 and does not adequately address the nuances of conditional automation in production vehicles. Several working groups are currently updating it, and those revisions will probably shift how we classify and discuss these incidents going forward. Insurance products designed specifically for autonomous operation are starting to appear in limited markets, but they are nowhere near mature. Claims handling for AV incidents requires different expertise than traditional auto claims because determining liability involves analyzing software logs, sensor data, and sometimes proprietary algorithms that the operating company may not willingly disclose. This creates friction in the claims process that benefits no one involved. The most practical advice I can offer to anyone following this beat is to look past the fatality count and examine the circumstances around each incident. A crash where a pedestrian steps into the road unexpectedly at night in the rain is fundamentally different from one where the system failed to recognize a stopped emergency vehicle. Both make news. Only one tells you much about the actual state of the technology. The difference matters more than most coverage gives it credit for.


