Understanding the Practical Robotics and Motion Capture Behind Real Steel's Fighting Chores
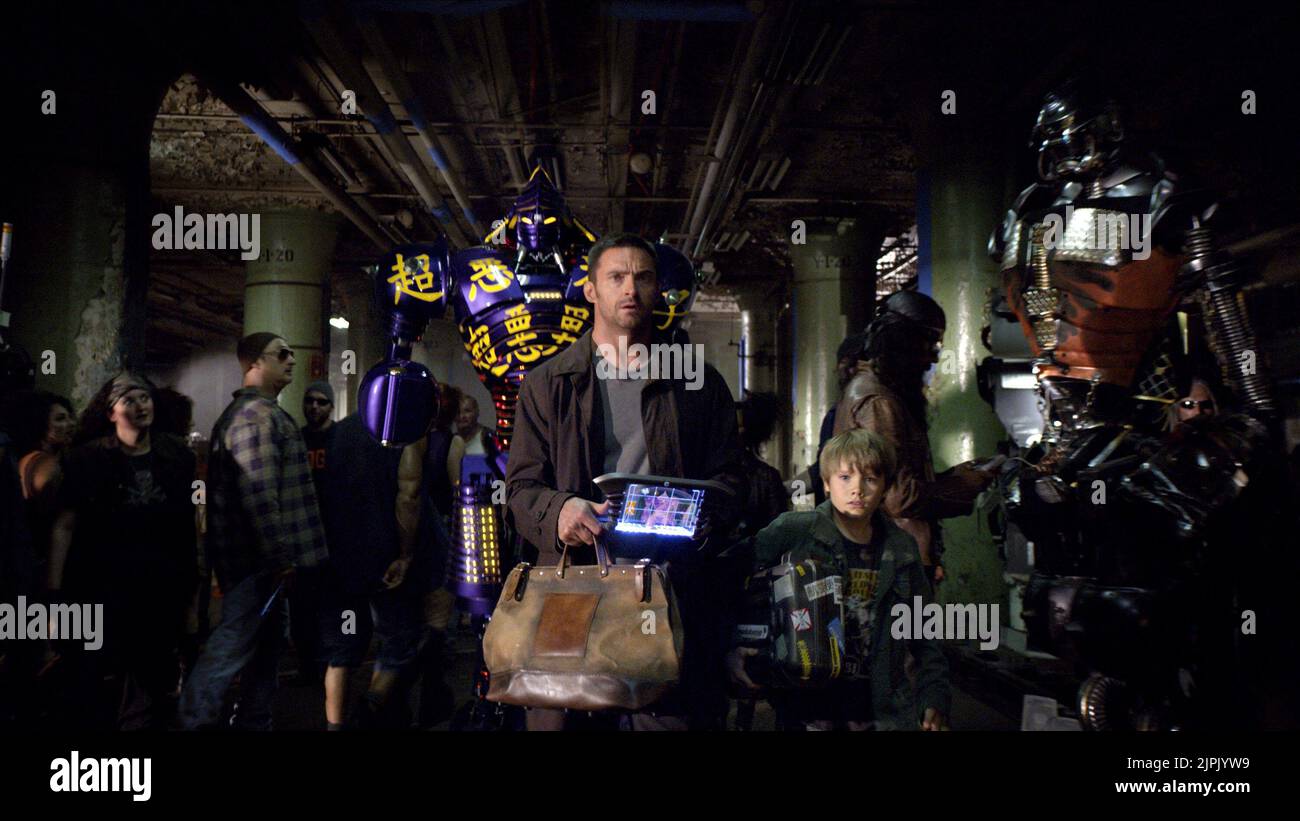
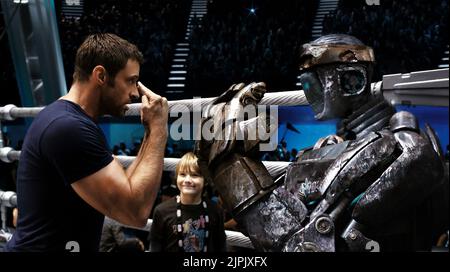
I spent roughly two years on a film that tried to replicate something close to what Real Steel pulled off with its robot boxing scenes. The difference between watching the movie and actually understanding what went into building those machines is pretty stark. Hugh Jackman and Dakota Goyo's performances were captured using a combination of motion capture suits, practical prosthetic interactions, and some surprisingly analog rigging work. The robots themselves—Atom, Noob 8000, Houdini, and the rest—weren't just CGI overlays on green screen. Several full-scale hydraulic puppets were built on set, ranging from simple push-button animatronics to complex rigs operated by teams of four technicians each. The core of the production challenge came down to making actors believe they were punching and being punched by 2,000-pound machines. Jackman's training regimen involved actual boxing fundamentals, but the fight choreography was adapted so that every punch had to account for the weight and momentum of a robot on the other end. I watched stunt performers train for weeks just to learn how to fall correctly when a hydraulic arm would swing at them. The impact you see on screen was a blend of practical squib hits, pneumatic rams, and post-production augmentation. Goyo's character presented a different problem entirely. A lot of his interaction with the robots was shot against blue screen with foam-core mockups weighted to approximate the feel of the machines. What makes the child actor's performance work so well is that he was actually wearing a haptic feedback vest during several key scenes. The vest delivered timed pulses to simulate the recoil of a robot taking damage. It sounds like a gimmick, but it completely changed how he moved and reacted in close-ups. Without that physical reference point, the eyelines and breathing patterns would have looked off no matter how skilled the performer was.
One edge case I ran into that most people don't talk about: the robots' eyes. Those were not done through mocap at all. They were operated by a single technician using a modified gaming steering wheel attached to a servo system. The technician had to track the human fighters' positions in real time while simultaneously reacting to scripted cues from the director. If the eye operator lagged even half a second, the robot looked dead. During one sequence, the steering wheel's calibration drifted mid-take and the robot's gaze locked onto a point three feet to the left of Jackman's face for the entire shot. We spent forty-five minutes recalibrating before we could reshoot. The workaround I ended up using was taping a small LED dot to the set floor where the actor's head should be, giving the operator a fixed reference point instead of trying to track a moving target in a dark arena. Here's something nobody mentions in the behind-the-scenes features: the sound design for the robots was recorded almost entirely from real industrial machinery. The team went to a demolition derby and recorded hydraulic presses, car crushers, and pneumatic tools. They then pitch-shifted and layerd those recordings to create each robot's unique voice. Atom's sound profile, for instance, draws heavily from a combination of a garbage compactor and a subway train braking. This gave each machine a distinct acoustic identity that animated the visual effects team could sync to. The vocal performances themselves, the grunts and battle cries, were supplied by a mix of sound designers and uncredited voice actors working out of a converted warehouse in Vancouver. If you're trying to reverse-engineer or study the techniques for your own project, start with the basics of practical puppeteering before touching any software. The mocap data from Real Steel is widely available through various VFX breakdowns, but the real insight comes from understanding how the physical sets interacted with the digital extensions. The arena floor alone required a custom engineering solution because the robots needed to leave scuff marks and dent the surface in real time during filming. The floor was built from layered steel plate over a foam substrate, and each take would gradually damage it in a way that matched the digital deterioration shown later. This meant the crew had to track damage accumulation across dozens of takes so the VFX team didn't have to recreate wear patterns from scratch.
The biggest mistake beginners make is assuming the robots are purely digital creatures. They're not. They exist in a hybrid space where practical effects handle the ground contact, debris, and actor interaction while CG fills in the gaps. Try building a simple rig first—a servo-driven arm mounted on a slider with a basic claw attachment. Run it through a short sequence with an actor. You'll quickly discover that timing and weight are infinitely harder to fake than anyone expects. A 200-gram servo moving a 50-gram arm looks nothing like a ton of steel hitting canvas, and no amount of post-production smoothing will fix a poorly timed mechanical movement. For reference material, the Real Steel DVD extras contain substantial footage of the on-set puppeteering setups. The motion capture breakdowns are also available through various VFX industry publications. What you won't find anywhere is the full technical documentation for the haptic vest system used on the young actor, which was a proprietary build by the Special Effects department and never commercialized. If you want that level of performer feedback in your own work, the closest off-the-shelf alternative involves modified gaming controllers wired to vibration motors distributed across a vest, triggered through a simple Arduino setup. It's not as refined, but it gets you 80 percent of the way there for a fraction of the cost.
Get the Full Details
The Technical Pipeline Breakdown
The production pipeline followed a conventional but heavily modified visual effects workflow. Pre-production involved storyboarding every fight sequence with the robot animations roughed out in animatic form. This allowed the stunt coordinators to plan choreography that matched the digital capabilities of each robot. Once shooting began, the on-set data collection included high-speed camera feeds, mocap suit telemetry, and environmental lighting scans. All of this data fed into the post-production phase where the digital doubles were constructed, animated, and composited. A detail that gets overlooked is the color grading approach. The robot scenes were shot with a deliberately desaturated palette on set so that the final color grade could push the metallic surfaces toward colder tones. This made the transition between practical and digital elements nearly invisible because the lighting and color temperature matched across both domains. It's a simple trick but one that requires discipline from the cinematographer, who had to maintain consistent exposure values even when switching between live-action plates and green screen segments. Ultimately, what made the film's robots feel real came down to consistency in physical interaction. Every time a robot touched something, the reaction was grounded in real physics. Dust kicked up at the right angle. Metal groaned under stress. Actors responded to impacts with genuine shock. Those moments of physical truth are what separate a convincing robot from a cartoon one, and they required coordination between departments that most productions don't bother to establish. If you're working on something similar, insist on cross-department rehearsal sessions before anyone touches a camera. The extra week of prep time saves months of revision work downstream.