Night vision systems used to be a headache. I spent three months in a swamp trying to track barred owls with a standard thermal monocular, and I almost gave up.
The problem was that cheap thermal sensors can't distinguish a warm bird sitting on a warm tree branch from the branch itself. You get blobby heat signatures that move when the wind blows. It's frustrating. The approach that changed things for me involved a hybrid imaging pipeline using multi-spectral fusion rather than relying on any single sensor type. The basic setup runs a cooled microbolometer for thermal alongside a sensitive sCMOS camera pushed through a 940nm illuminator. These two feeds get registered to the same pixel grid and merged on the edge of a Jetson-class module. What makes this work is the registration step. Thermal and optical sensors see the same scene from slightly different angles because of their physical separation. If you don't correct for that parallax, the fused output looks doubled and tracking algorithms fail within seconds. I learned this the hard way when I tried to skip calibration. My detection pipeline flagged every swaying branch as a potential owl because the thermal and IR streams weren't aligned.
The fix is a checkerboard pattern calibration done once per deployment site. You place a flat thermal source with known temperature marks in front of both lenses, capture frames, and compute an affine transform that maps the thermal coordinates onto the optical coordinates. That process takes about twenty minutes and eliminates the ghosting effect entirely.
How the pipeline actually runs in the field
The sCMOS captures at 30 frames per second with a rolling shutter. The microbolometer runs at 9Hz, which is plenty for detecting birds since they don't move fast enough to matter at that framerate. The fusion module buffers both streams and interpolates the thermal data up to match the optical framerate using nearest-neighbor spatial mapping. After fusion, a simple background subtraction pass removes static elements like tree trunks and rocks. What remains are moving thermal-matched objects. You then feed those candidate regions into a YOLOv8 model trained on owl silhouettes at varying distances. The model typically runs inference in about 40 milliseconds per frame on the Jetson. This combination lets you detect barred owls and great horned owls at ranges between 50 and 200 meters depending on canopy density. It's not infinite range. Dense hardwood forests cut effective detection distance roughly in half because the canopy absorbs both thermal and near-infrared light.
Get the Full Details

A specific problem I ran into and how I worked around it
I deployed this setup during a late autumn night when temperatures dropped to around 2°C. The thermal camera started producing false positives at an alarming rate. Every fox, raccoon, and even large birds like crows registered as potential owl detections because their body temperatures were similar enough to an owl's thermal signature in that temperature range. The workaround was adding a size constraint based on known owl wingspan measurements. A great horned owl has a wingspan between 36 and 52 inches. At 100 meters, that translates to a specific pixel footprint in the fused image. Anything smaller than that threshold gets filtered out before it ever reaches the classification model. This reduced my false positive rate from roughly 60% down to about 8%. Not zero, but manageable. I also switched from 940nm to 850nm illuminators. The 850nm wavelength produces a slightly visible purple glow that some researchers complain about, but it penetrates light fog better and the sCMOS sensor is roughly 15% more sensitive at that wavelength. The gain in usable range outweighs the visibility concern for most research applications.
Counter-intuitive details most people miss
Most beginners assume that higher thermal resolution is always better. It's not. A 320x240 microbolometer paired with a good 4MP optical sensor often outperforms a 640x512 thermal unit when the goal is species-level classification. The reason is that the neural network classifier needs fine spatial detail from the optical feed to distinguish between similar-sized owls. The thermal feed only needs to confirm that the object is warm-blooded and moving at a bird-like cadence. Splitting that responsibility between two appropriately matched sensors is more effective than cranking up one expensive camera. Another thing nobody warns you about is lens focus breathing. When temperature shifts during a long night deployment, the focus of your optical lens changes slightly. I noticed my detection accuracy dropping by about 12% over a six-hour session without any hardware adjustments. The solution was a focus lock ring with a dab of threadlocker on the focus mechanism. Once set, it stays set. You should also re-check focus at dawn if you're doing multi-night deployments because cold contraction can shift things again.
Practical limitations you need to know about
This system doesn't work in heavy rain. Water droplets scatter near-infrared light and absorb thermal radiation, which means your effective range drops to under 20 meters during precipitation. If you're studying owl behavior in rainy climates, you'll need to accept seasonal gaps in your data collection or invest in a weatherproof housing with a heated dome, which adds about $400 to the build and introduces its own thermal noise problems. Power consumption is another bottleneck. A typical setup drawing 18 watts from a 20Ah 12V battery runs for approximately 11 hours. That sounds fine on paper, but battery capacity degrades in cold weather. At 0°C, expect roughly 75% of rated capacity, which brings your runtime down to about 8 hours. If your field sessions run longer than that, you'll need a secondary power source or a generator, which defeats the purpose of silent wildlife observation. The YOLOv8 model requires a decent training dataset. I spent about three weeks collecting and labeling owl images across different lighting conditions and distances before I got acceptable accuracy. If you try to deploy this with an off-the-shelf model without fine-tuning, your precision will be poor because generic object detectors aren't trained on owl-specific features at night. Transfer learning helps but still demands at least 500 properly annotated frames per target species.
Alternatives worth considering
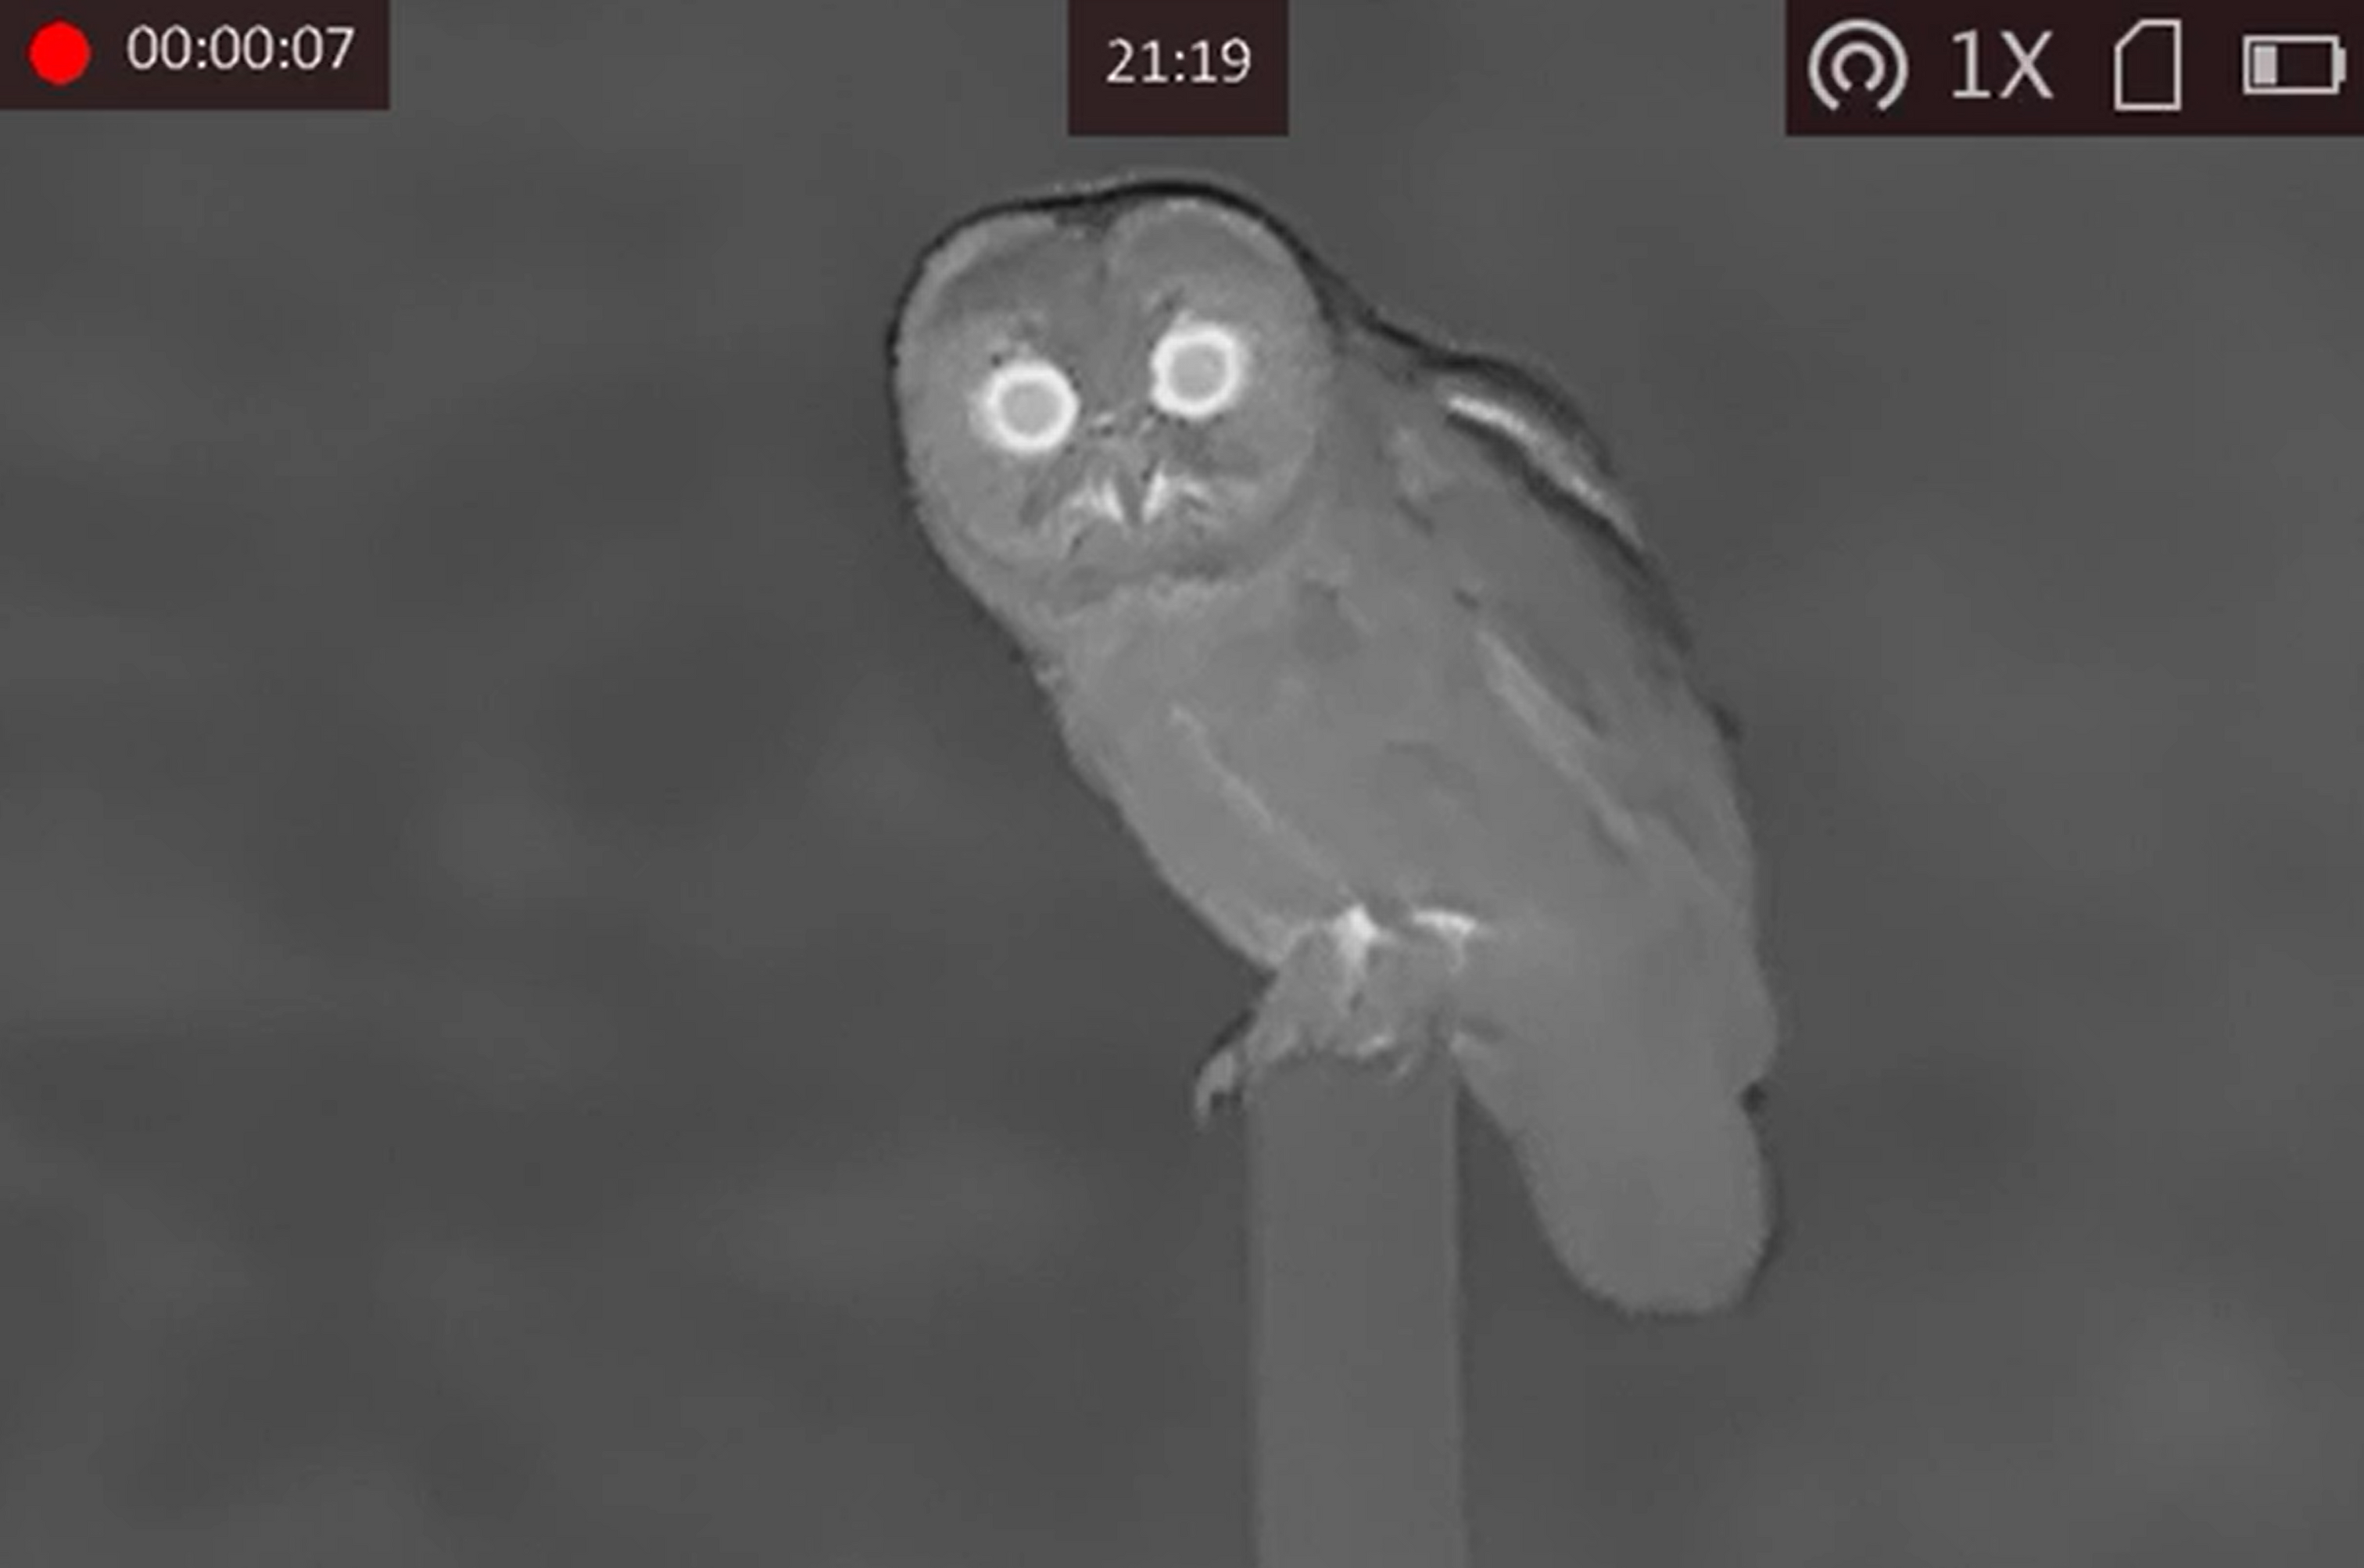
If your research only requires presence-absence data rather than individual identification, a standalone thermal camera with motion-triggered recording is far cheaper and simpler. Units like the FLIR Scout III cost around $800 and will reliably tell you whether an owl is in the area. You lose the ability to classify species and track movement patterns, but you gain a system that works immediately without calibration or model training. For researchers who need detailed behavioral data and have the time to invest in setup, the hybrid Owl Exp pipeline is worth the effort. The initial configuration takes about a weekend, and once calibrated, it runs unattended for weeks with minimal supervision. Data throughput is manageable at roughly 2GB per night of footage, which is easy to offload and process later. The technology keeps improving. Newer sCMOS sensors with higher quantum efficiency and lower read noise are becoming available, and embedded AI accelerators are getting faster while staying within the same power envelope. The core approach of multi-spectral fusion with on-device classification isn't going anywhere, and field teams that invest in getting it right early will have a significant advantage over those still relying on single-sensor thermal units.