What Oscillation Actually Means When You See It in Practice
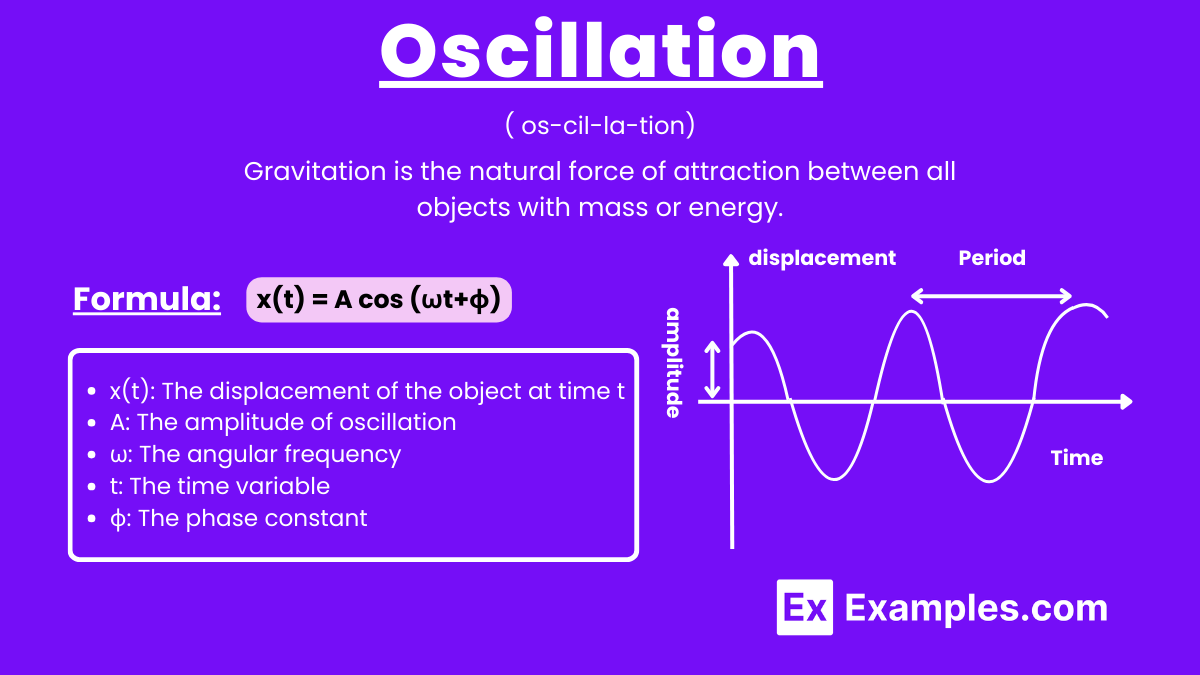
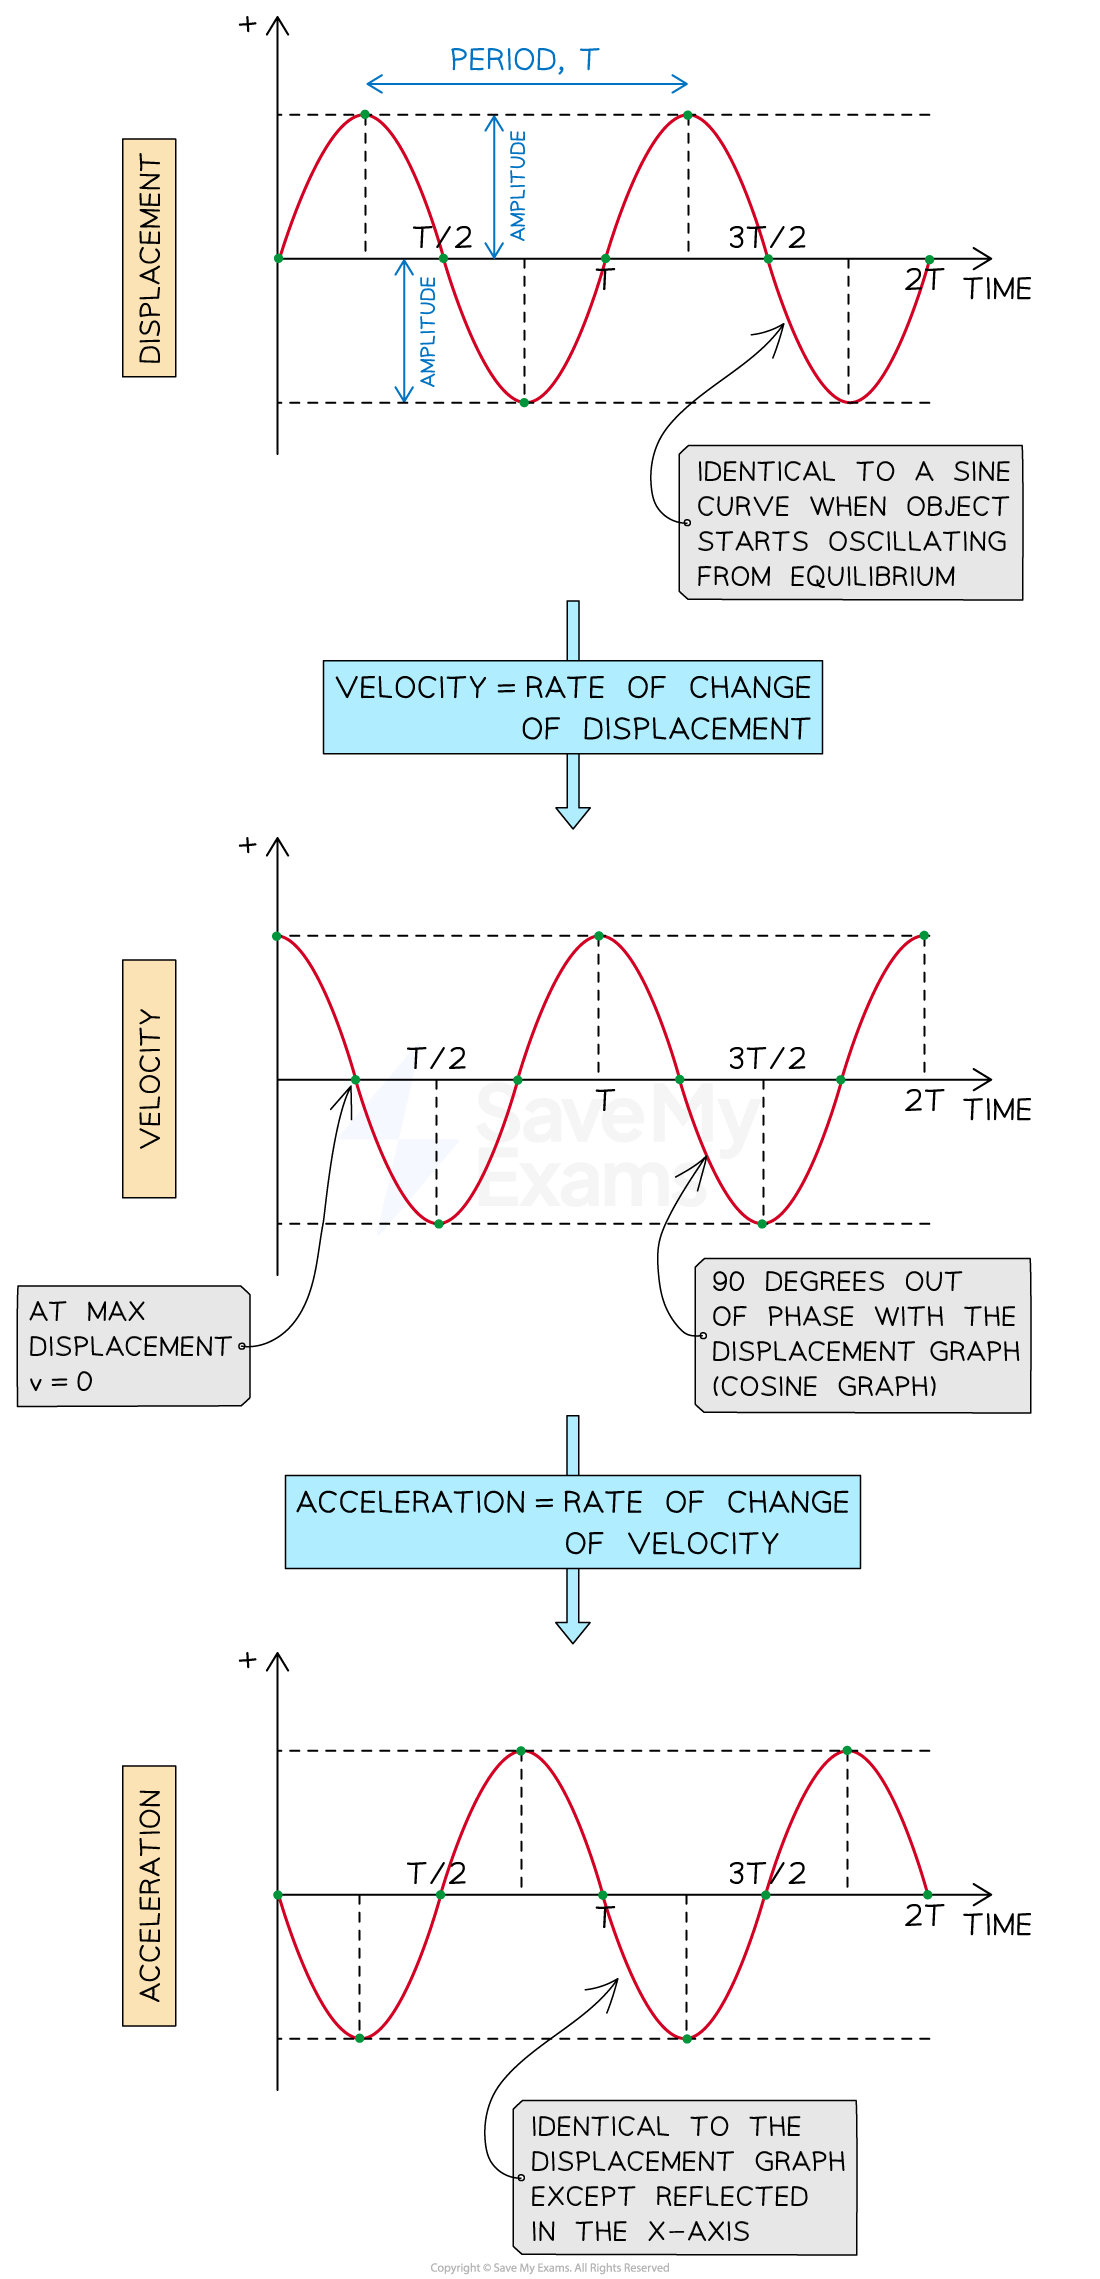
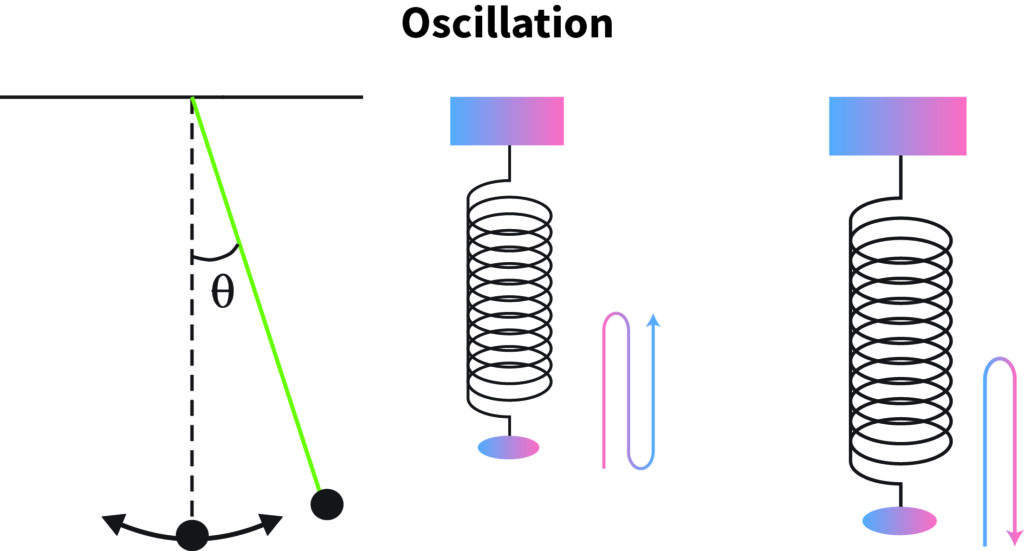
Most people encounter oscillation when they are debugging a control loop that will not settle, or when they watch a pendulum swing back and forth and assume the math is simple. It is not simple once you add damping, forcing functions, or nonlinear springs into the mix. I spent three days last year chasing a thermal control loop that jumped plus or minus eight degrees around a setpoint, and the root cause was not the PID tuning. The root cause was a relay that had a one hundred millisecond dead band, which created a limit cycle the simulator never showed because the simulation model assumed an ideal instantaneous switch. Once I added the dead band to the model, the simulated response matched the bench data exactly, and the workaround became obvious: replace the bang bang controller with a proportional band wide enough to absorb the hysteresis, or add a small amount of derivative smoothing so the controller does not overreact to the noise the dead band creates. At its core, oscillation is a repetitive variation around a central value. The variation can be sinusoidal, triangular, or something far uglier when nonlinearities enter the picture. The key parameters you need to track are amplitude, period, frequency, and phase. Amplitude tells you how far the signal swings. Period tells you how long one complete cycle takes. Frequency is just the inverse of period, measured in hertz. Phase tells you where the signal sits in its cycle relative to another signal or a reference point. If you drop those four numbers into a spreadsheet, you can describe almost any oscillation you will encounter in a mechanical, electrical, or thermal system without writing a single differential equation. The deeper layer is stability. An oscillation can be stable, meaning it stays bounded and repeats with the same amplitude forever, or it can be unstable, meaning the amplitude grows until something breaks or saturates. The boundary between those two states is what control engineers spend most of their careers trying to map. In a linear system, you can use the characteristic equation roots to predict the boundary. If all roots have negative real parts, the system is stable. If any root has a positive real part, the system is unstable. If a pair of roots sits exactly on the imaginary axis, the system is marginally stable and will oscillate at a constant amplitude in the absence of damping. That marginal case is the one that causes the most trouble in practice because real systems are never perfectly linear, and tiny nonlinearities will either damp the oscillation or push it into growth depending on the sign of the nonlinearity.
I learned that lesson the hard way with a feedback amplifier that would oscillate at fourteen megahertz only when the output was loaded with a cable longer than two meters. The schematic simulation was clean. The board oscillated. The difference was the cable capacitance, which was not in the simulation because I treated the cable as an ideal voltage source with zero output impedance. Once I added thirty picofarads per meter to the model, the phase margin collapsed to zero at fourteen megahertz, and the fix became a small series resistor of about fifty ohms at the amplifier output. That resistor killed the oscillation without affecting the audio bandwidth because the load impedance was low enough that the resistor formed a negligible voltage divider at the frequencies that matter.
How to Analyze an Oscillation Without Getting Lost in Math
Start with the time domain. Capture the waveform on an oscilloscope or a data logger and measure the peak to peak amplitude and the period. Do not trust the instrument's automatic measurements yet because they can be fooled by noise. Measure manually by placing cursors on consecutive peaks. If the peaks are drifting in amplitude, the oscillation is not steady state, which means you are dealing with a transient or an unstable system rather than a limit cycle. If the peaks are constant, you have a steady oscillation, which usually points to a nonlinear element sustaining it because a purely linear system with no damping would either decay to zero or grow to infinity, not stay at a fixed amplitude. Next move to the frequency domain. Take a fast Fourier transform of the captured waveform, or use a spectrum analyzer if you have one. Look for a dominant peak at the oscillation frequency and check the harmonic content. A pure sine wave will have a single peak with harmonics more than forty decibels down. If the harmonics are higher, the waveform is distorted, which usually means a nonlinear element is clipping or saturating part of the cycle. The shape of the distortion tells you something about the nonlinearity. Symmetric clipping produces odd harmonics. Asymmetric clipping produces even harmonics too. A relay with hysteresis produces a square wave rich in odd harmonics that decay at six decibels per octave. Then check the phase relationship. If you have access to both the input and output of the oscillating block, plot the phase versus frequency using a Bode plot or by measuring the time delay between zero crossings at multiple frequencies. A feedback system will oscillate when the loop gain is greater than or equal to one and the total phase shift around the loop is an odd multiple of one hundred eighty degrees. That is the Barkhausen criterion, and it is necessary but not sufficient because it ignores the startup condition. A system can satisfy Barkhausen and still not oscillate if the initial perturbation is zero or if nonlinearities reduce the gain below one at the operating amplitude. In practice, I use the criterion as a first filter, then I run a transient simulation with a small impulse injected at the start to see if the response grows, decays, or stays constant.
Get the Full Details

One thing beginners miss is that oscillation frequency is not always the frequency where phase shift is one hundred eighty degrees. In a system with multiple poles, the oscillation can jump to a different frequency if the gain profile changes with amplitude, which is what happens in relaxation oscillators. The timing capacitor charges until a threshold is reached, then the state flips, and the capacitor discharges in the opposite direction. The frequency is set by the RC time constant and the threshold voltages, not by a resonant peak. If you try to analyze a relaxation oscillator with Bode plots, you will be confused for a while until you realize the topology is fundamentally different from a sinusoidal oscillator.
Common Oscillation Types and What They Look Like
Sinusoidal oscillation is the ideal case. The waveform is a smooth sine wave, and the spectrum has a single dominant line. You see this in LC tanks, quartz resonators, and well designed crystal oscillators. The amplitude is determined by the balance between energy added by the active device and energy lost in the resonator and load. If the active device gain is too high, the sine wave clips, harmonics appear, and the oscillator may pull into a different mode or destabilize entirely. The workaround is usually a nonlinear gain control mechanism, such as an automatic gain control loop or a device that naturally compresses at high amplitude, like a thermistor or a JFET biased in the saturation region. Relaxation oscillation is the ugly case. The waveform jumps between two states, often with sharp edges and flat tops. You see this in 555 timer circuits, astable multivibrators, and many power supply feedback loops that are marginally stable. The frequency is set by charging and discharging a capacitor through a resistor, with thresholds set by a comparator or transistor pair. The spectrum is rich in harmonics, which can cause electromagnetic interference if the edges are fast. The workaround for EMI is usually a snubber network or a slow ramp generator that softens the edge transitions without changing the frequency significantly. I once had a buck converter that radiated spurs at the switching frequency and its harmonics because the MOSFET gate drive had no series resistor. Adding a ten ohm resistor in series with the gate reduced the spur amplitude by twenty decibels across the band, which was enough to pass certification without changing the converter topology or the component values. Limit cycle oscillation is what you get when a nonlinear element sustains a bounded oscillation in a feedback system. The amplitude and frequency are determined by the nonlinear element characteristics, not by linear small signal analysis. A classic example is a relay in a temperature controller. The relay switches on when the temperature falls below the setpoint minus half the differential, and off when it rises above the setpoint plus half the differential. The temperature oscillates around the setpoint with an amplitude equal to the differential plus the system lag. The frequency depends on the thermal time constant and the differential width. If the differential is too narrow, the relay chatters and wears out. If it is too wide, the temperature regulation is poor. The usual fix is to replace the relay with a solid state switch that has no mechanical wear, or to add a proportional control mode so the heating power varies smoothly instead of switching abruptly.
How to Stop an Undesired Oscillation
The first step is identification. You cannot fix an oscillation if you do not know what kind it is and what is sustaining it. Use the time domain and frequency domain measurements I described above to characterize the waveform, the spectrum, and the phase margin. If the oscillation appears only under certain load or temperature conditions, map those conditions to find the boundary. If it appears randomly, check for intermittent connections, power supply noise, or thermal drift that pushes the system across the stability boundary at unpredictable times. The second step is to increase damping. In a mechanical system, that means adding a damper or a viscous fluid. In an electrical system, it means adding resistance in series with an inductor or in parallel with a capacitor to reduce the Q factor. In a control system, it means adding a lag compensator or reducing the proportional gain until the phase margin is above forty five degrees, which is the usual rule of thumb for acceptable damping. If you need more phase margin without reducing bandwidth, you can add a lead compensator, which adds phase near the crossover frequency but also increases the gain at higher frequencies, so you may need to add a lag compensator afterward to roll off the high frequency gain and maintain noise immunity. The third step is to break the feedback path at the right point. Sometimes the oscillation is caused by a sensor noise coupling into the feedback path. Adding a low pass filter on the sensor input can kill the oscillation without affecting the control performance if the filter cutoff is below the oscillation frequency but above the signal bandwidth. I once had a pressure transducer that picked up radio frequency interference from a nearby transmitter, which caused the controller to oscillate at the carrier frequency and its sidebands. A simple RC filter with a cutoff of one kilohertz killed the oscillation and did not affect the pressure response because the pressure changes were slower than one hertz. The filter also improved the signal to noise ratio, which was a bonus.
If none of those steps work, you may need to change the topology. A feedback system that is inherently unstable over its operating range is better replaced with a feed forward controller, a gain scheduled controller, or a non linear control law that adapts to the operating point. Pole placement can move the unstable poles into the left half plane, but it requires an accurate model and robust gain margins because model uncertainties can push the poles back across the imaginary axis. H infinity synthesis can handle uncertainties explicitly, but it produces high order controllers that are hard to tune and implement, so I usually reserve it for safety critical systems where the cost of failure justifies the design complexity.
Where Oscillation Analysis Fails and What to Do Instead
Linear analysis fails when the oscillation amplitude is large enough that the system operates in a region where the linear model is invalid. A hard saturation, a dead zone, or a backlash can sustain an oscillation that small signal analysis predicts should decay. The workaround is describing function analysis, which approximates the nonlinear element as a gain that depends on the input amplitude. You plot the describing function locus and the negative inverse linear frequency response on the same Nyquist plane, and where they intersect is the predicted oscillation amplitude and frequency. It is not exact, but it is usually close enough to guide the design, and it is far faster than running hundreds of transient simulations. Linear analysis also fails when the system is time varying. A parameter that changes with temperature, wear, or aging can move the poles slowly across the stability boundary, causing oscillations that appear and disappear over hours or days. The workaround is robust control design that guarantees stability over the expected parameter range, or adaptive control that estimates the parameters online and adjusts the controller gains accordingly. Adaptive control is powerful but sensitive to noise and modeling errors, so I usually add a projection algorithm to keep the estimates within physical bounds and a leakage term to prevent windup when the excitation is insufficient. The biggest failure mode is ignoring the measurement chain. The oscillator may be in the sensor, the analog front end, or the ADC sampling clock, not in the plant or the controller. A classic example is aliasing, where a high frequency signal folds into the baseband and appears as a low frequency oscillation. The fix is an anti aliasing filter with a cutoff below half the sampling frequency, and enough attenuation at the folding frequency to bring the aliased component below the noise floor. I once spent a week chasing a false oscillation in a data acquisition system before I realized the sampling clock had a 10 kilohertz spurious tone that was aliasing with a 47 kilohertz sensor resonance to produce a seven kilohertz artifact in the recorded data. A simple analog low pass filter at twenty kilohertz removed the artifact and made the oscillation disappear from the recorded signal, which was the first clear indication that the problem was in the measurement chain, not in the plant.